Related Experiment Video
Updated: Mar 23, 2026
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Characterization of the L4-L5-S1 motion segment using the stepwise reduction method
Héctor Enrique Jaramillo1, Christian M Puttlitz2, Kirk McGilvray3
1Escuela de Ingeniería Civil y Geomática, Universidad del Valle, Cali 760032, Colombia; Departamento de Energética y Mecánica, Universidad Autónoma de Occidente, Cali 760031, Colombia.

Abstract:
The two aims of this study were to generate data for a more accurate calibration of finite element models including the L5-S1 segment, and to find mechanical differences between the L4-L5 and L5-S1 segments. Then, the range of motion (ROM) and facet forces for the L4-S1 segment were measured using the stepwise reduction method. This consists of sequentially testing and reducing each segment in nine stages by cutting the ligaments, facet capsules, and removing the nucleus. Five L4-S1 human segments (median: 65 years, range: 53-84 years, SD=11.0 years) were loaded under a maximum pure moment of 8Nm. The ROM was measured using stereo-photogrammetry via tracking of three markers and the facet contact forces (CF) were measured using a Tekscan system. The ROM for the L4-L5 segment and all stages showed good agreement with published data. The major differences in ROM between the L4-L5 and L5-S1 segments were found for lateral bending and all stages, for which the L4-L5 ROM was about 1.5-3 times higher than that of the L5-S1 segment, consistent with L5-S1 facet CF about 1.3 to 4 times higher than those measured for the L4-L5 segment. For the other movements and few stages, the L4-L5 ROM was significantly lower that of the L5-S1 segment. ROM and CF provide important baseline data for more accurate calibration of FE models and to understand the role that their structures play in lower lumbar spine mechanics.
More Related Videos
Related Concept Videos
 01:22
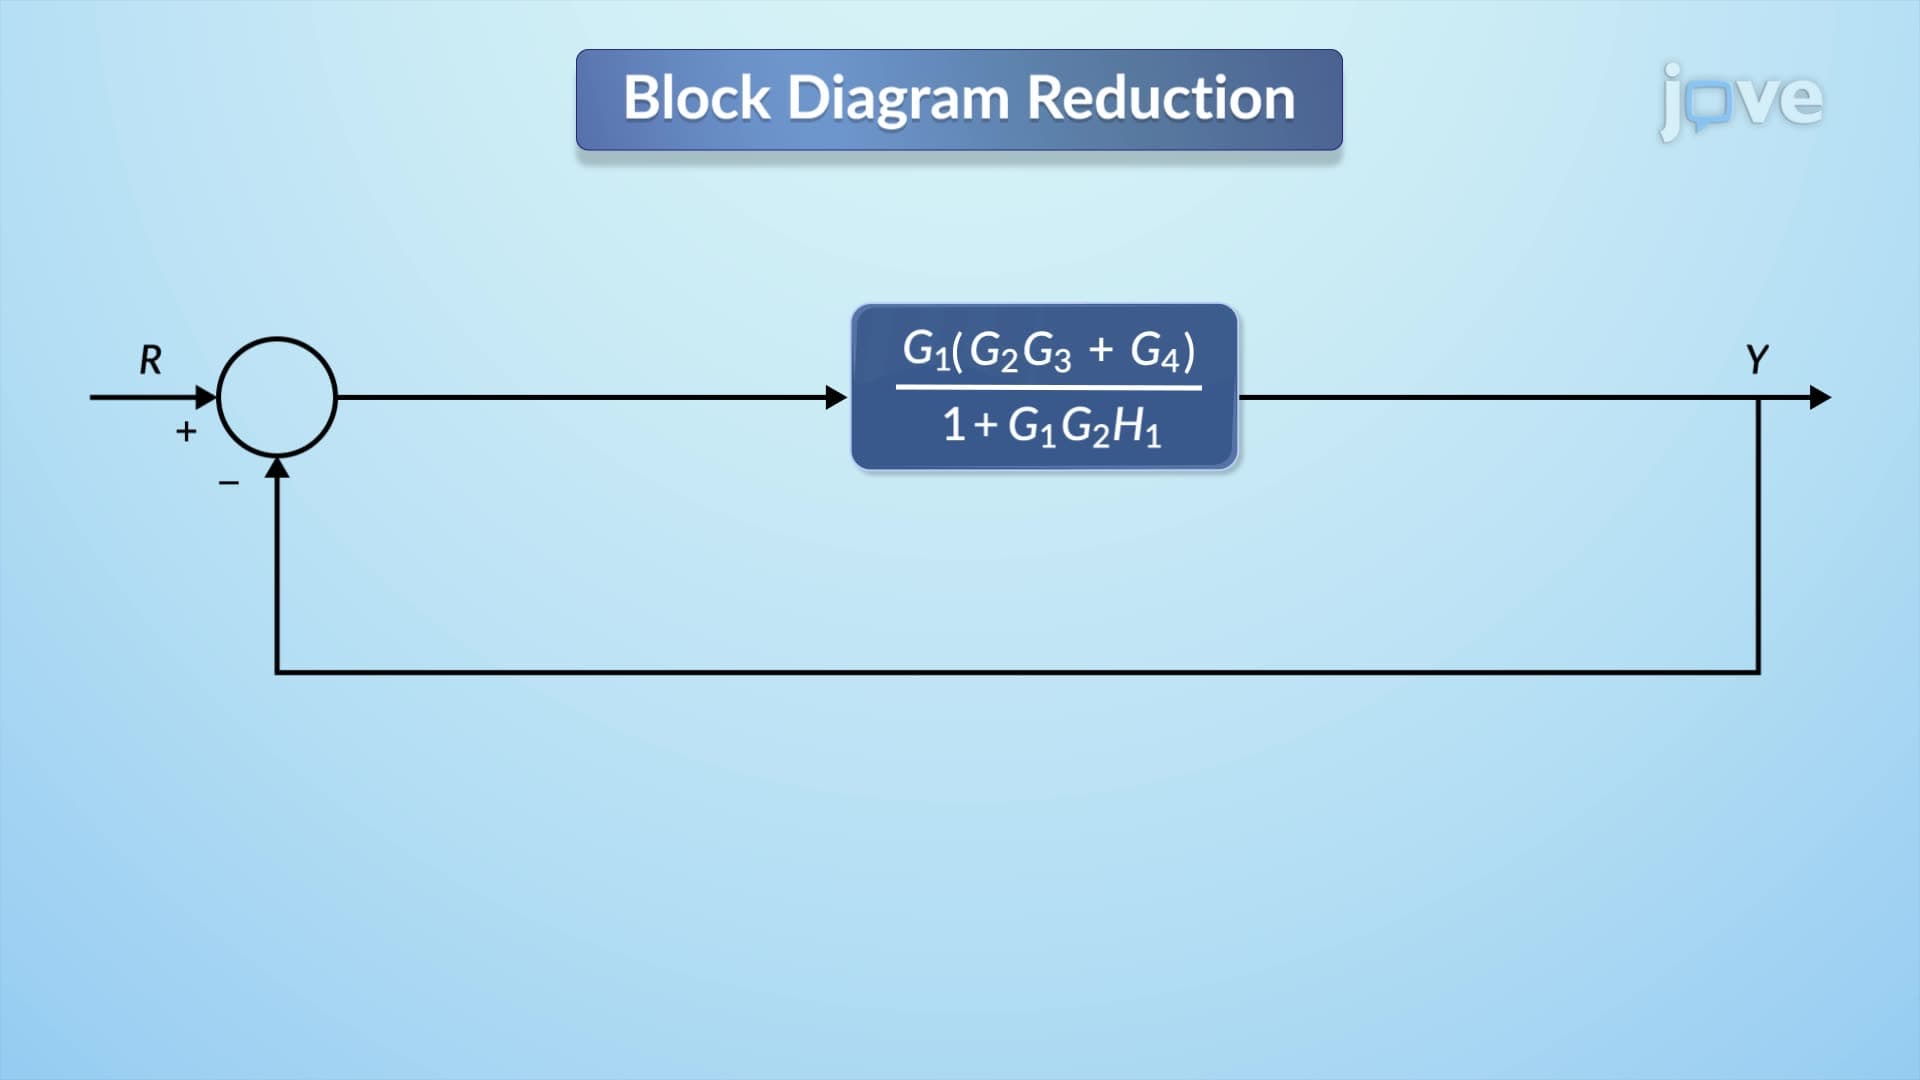
Block Diagram Reduction
The first step in this process is the identification and relocation of a branch point. A branch point, where a...
 01:10
Relative Motion Analysis - Acceleration
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...