Related Experiment Video
Updated: Mar 23, 2026

A Methodology for Capturing Joint Visual Attention Using Mobile Eye-Trackers
Published on: January 18, 2020
Homography Based Egomotion Estimation with a Common Direction

Abstract:
In this paper, we explore the different minimal solutions for egomotion estimation of a camera based on homography knowing the gravity vector between calibrated images. These solutions depend on the prior knowledge about the reference plane used by the homography. We then demonstrate that the number of matched points can vary from two to three and that a direct closed-form solution or a Gröbner basis based solution can be derived according to this plane. Many experimental results on synthetic and real sequences in indoor and outdoor environments show the efficiency and the robustness of our approach compared to standard methods.
More Related Videos
 09:46
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
 08:15
Capturing Dynamic Finger Gesturing with High-resolution Surface Electromyography and Computer Vision
Published on: March 28, 2025
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:26
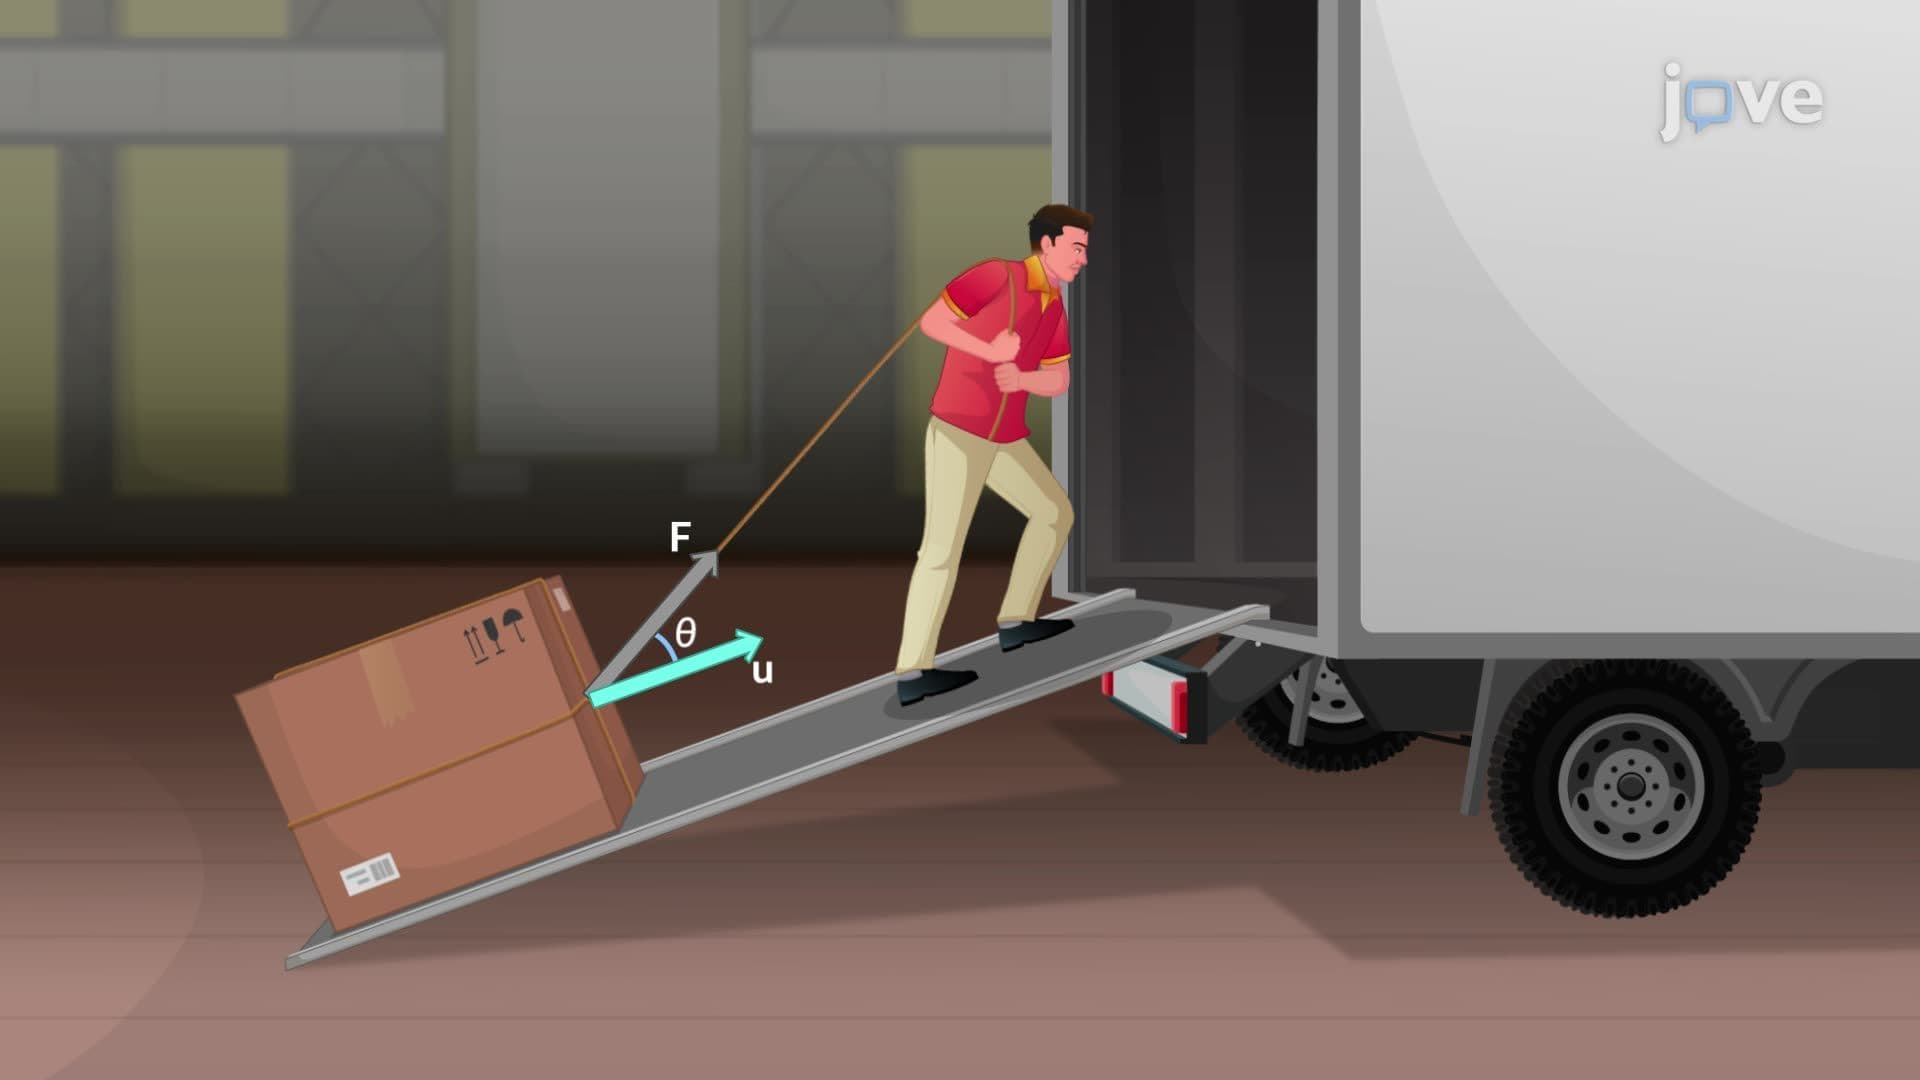
The Dot Product
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...