Related Experiment Video
Updated: Apr 29, 2026
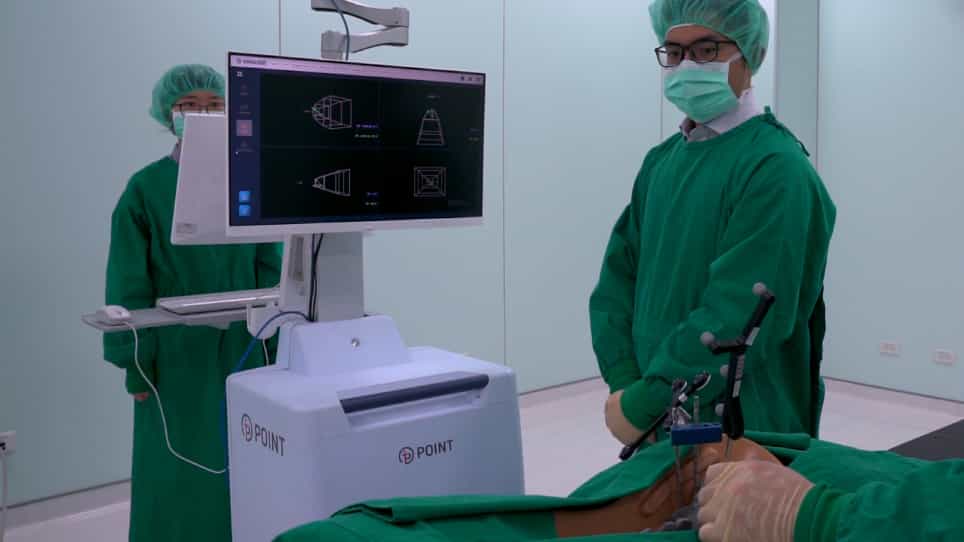

A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Markerless inside-out tool tracking for endoscopic spine surgery: a benchmarking study and clinical dataset
Peter Zhang1,2, Youyang Shen3, Frédéric Giraud4
1Computer Vision and Geometry Group, ETH Zurich, Zurich, Switzerland. pzhang@ethz.ch.

Purpose:
Markerless inside-out surgical instrument tracking using a tool-mounted camera offers a promising solution to the limited clinical adoption of the existing navigation systems, which primarily rely on outside-in optical tracking and are constrained by line-of-sight issues. However, its performance in the surgical environment, with its unique challenges, remains largely unexplored. This work benchmarks state-of-the-art inside-out methods, namely, visual Simultaneous Localization and Mapping (vSLAM) methods. To this end, we collected a first-of-its-kind dataset in spine endoscopy, providing ground-truth tool poses.
Methods:
We recorded endoscopic spine surgeries performed on a high-fidelity training model in a real operating room environment, containing synchronized stereo images from tool-mounted cameras, sub-millimetric ground truth pose data from a commercial optical tracking system, and the endoscopic feed. Using this dataset, the instrument tracking accuracy of a selected number of vSLAM algorithms was compared.
Results:
The best performing approach achieved a root mean squared absolute trajectory error of 2.0 mm and 1.47 degrees, reaching accuracies of around 1 mm and 1 degree on selected sequences. However, it shows degraded performance in the presence of challenges such as occlusions and scene-object dynamics.
Conclusions:
Markerless inside-out tracking using vSLAM demonstrated high accuracy, indicating potential feasibility for navigated endoscopic spine applications. Our evaluation revealed that current algorithms remain insufficiently robust for routine clinical use. The presented study and dataset establish a foundation for future research toward reliable, real-time inside-out navigation in minimally invasive surgery.