Related Experiment Video
Updated: Oct 2, 2026
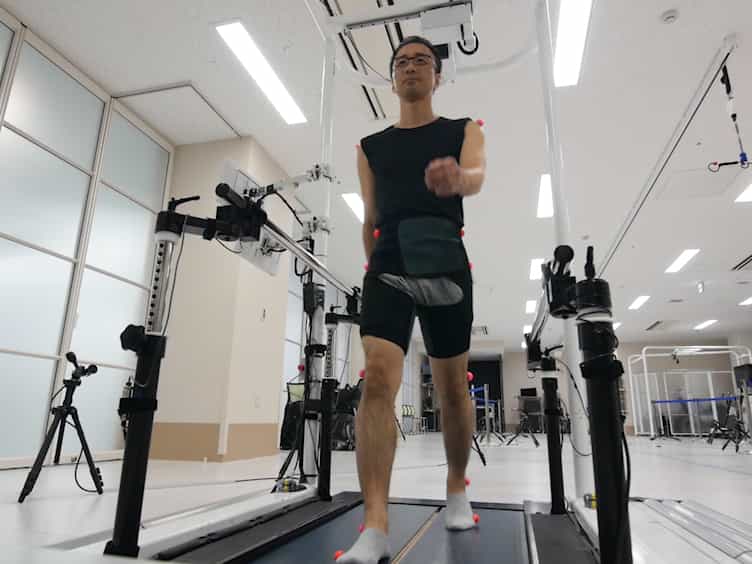

Clinical-oriented Three-dimensional Gait Analysis Method for Evaluating Gait Disorder
Published on: March 4, 2018
Kinematic Analysis of a Six-Degrees-of-Freedom Model Based on ISB Recommendation: A Repeatability Analysis and
Magdalena Żuk1, Celina Pezowicz1
1Department of Biomedical Engineering, Mechatronics and Theory of Mechanisms, Faculty of Mechanical Engineering, Wrocław University of Technology, Łukasiewicza 7/9, 50-371 Wrocław, Poland.

Abstract:
Objective. The purpose of the present work was to assess the validity of a six-degrees-of-freedom gait analysis model based on the ISB recommendation on definitions of joint coordinate systems (ISB 6DOF) through a quantitative comparison with the Helen Hays model (HH) and repeatability assessment. Methods. Four healthy subjects were analysed with both marker sets: an HH marker set and four marker clusters in ISB 6DOF. A navigated pointer was used to indicate the anatomical landmark position in the cluster reference system according to the ISB recommendation. Three gait cycles were selected from the data collected simultaneously for the two marker sets. Results. Two protocols showed good intertrial repeatability, which apart from pelvic rotation did not exceed 2°. The greatest differences between protocols were observed in the transverse plane as well as for knee angles. Knee internal/external rotation revealed the lowest subject-to-subject and interprotocol repeatability and inconsistent patterns for both protocols. Knee range of movement in transverse plane was overestimated for the HH set (the mean is 34°), which could indicate the cross-talk effect. Conclusions. The ISB 6DOF anatomically based protocol enabled full 3D kinematic description of joints according to the current standard with clinically acceptable intertrial repeatability and minimal equipment requirements.
Related Concept Videos
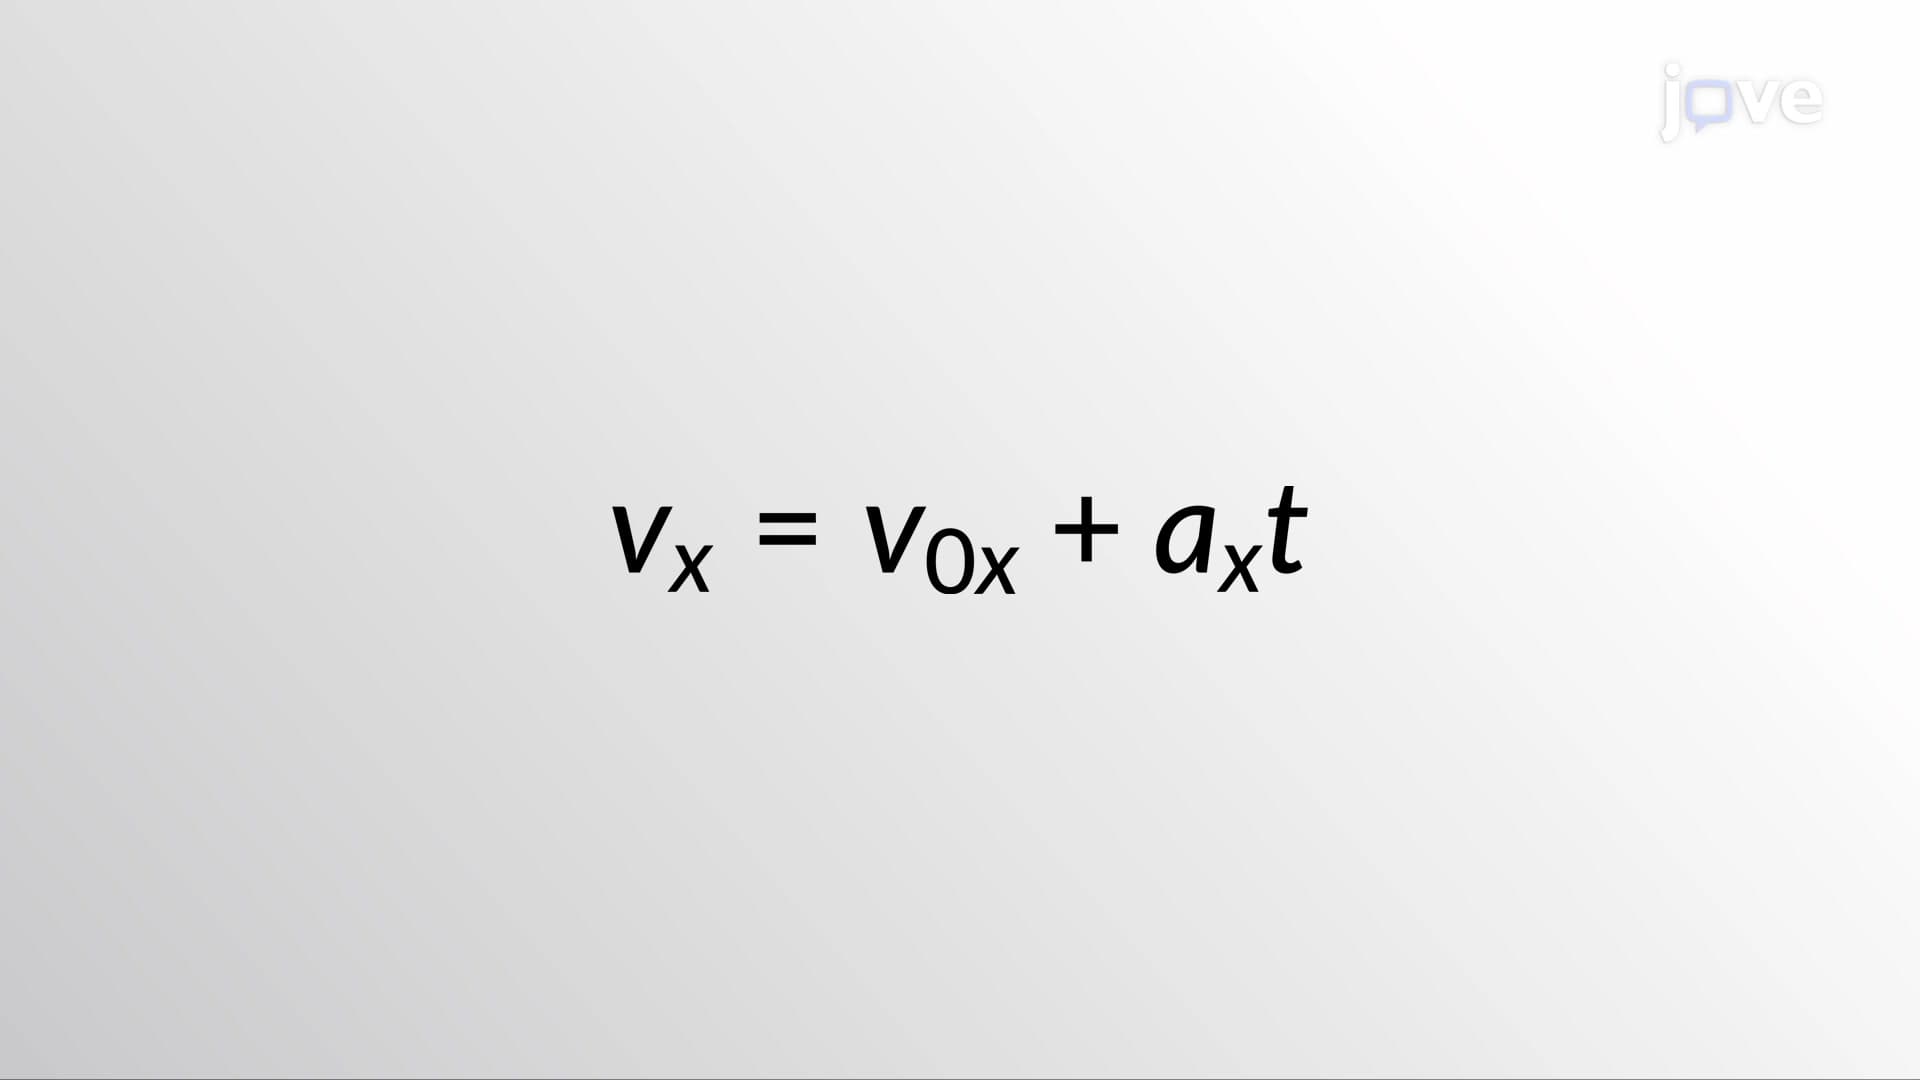 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving