Related Experiment Video
Updated: Mar 20, 2026
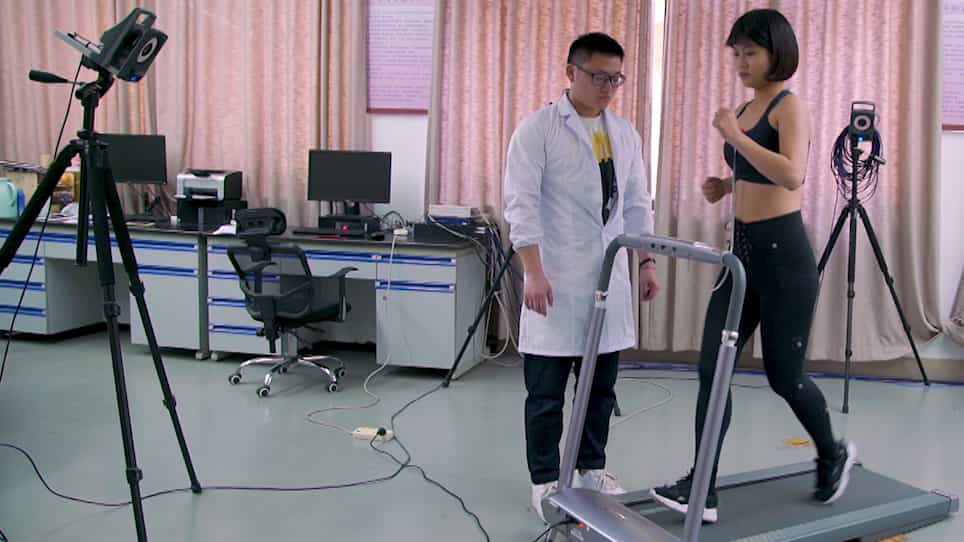

Comparative Analysis of Lower Limb Kinematics between the Initial and Terminal Phase of 5km Treadmill Running
Published on: July 17, 2020
Side-sloped surfaces substantially affect lower limb running kinematics
Mohsen Damavandi1, Mansour Eslami2, David J Pearsall3
1a Faculty of Physical Education and Sport Sciences , Hakim Sabzevari University , Sabzevar , Iran.

Abstract:
Running on side-sloped surfaces is a common obstacle in the environment; however, how and to what extent the lower extremity kinematics adapt is not well known. The purpose of this study was to determine the effects of side-sloped surfaces on three-dimensional kinematics of hip, knee, and ankle during stance phase of running. Ten healthy adult males ran barefoot along an inclinable runway in level (0°) and side-sloped (10° up-slope and down-slope inclinations, respectively) configurations. Right hip, knee, and ankle angles along with their time of occurrence were analysed using repeated measures MANOVA. Up-slope hip was more adducted (p = 0.015) and internally rotated (p = 0.030). Knee had greater external rotations during side-sloped running at heel-strike (p = 0.005), while at toe-off, it rotated externally and internally during up-slope and down-slope running, respectively (p = 0.001). Down-slope ankle had greatest plantar flexion (p = 0.001). Up-slope ankle had greatest eversion compared with down-slope (p = 0.043), while it was more externally rotated (p = 0.030). These motion patterns are necessary to adjust the lower extremity length during side-sloped running. Timing differences in the kinematic events of hip adduction and external rotation, and ankle eversion were observed (p = 0.006). Knowledge on these alterations is a valuable tool in adopting strategies to enhance performance while preventing injury.
More Related Videos
 07:43
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
 06:35
Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
Related Concept Videos
 01:16
Bones of the Lower Limb: Femur and Patella
 01:15
Kinematic Equations: Problem Solving
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:10
Bones of the Lower Limb: Tibia and Fibula
 01:26
Kinematic Equations - I