Related Experiment Video
Updated: Jul 9, 2026
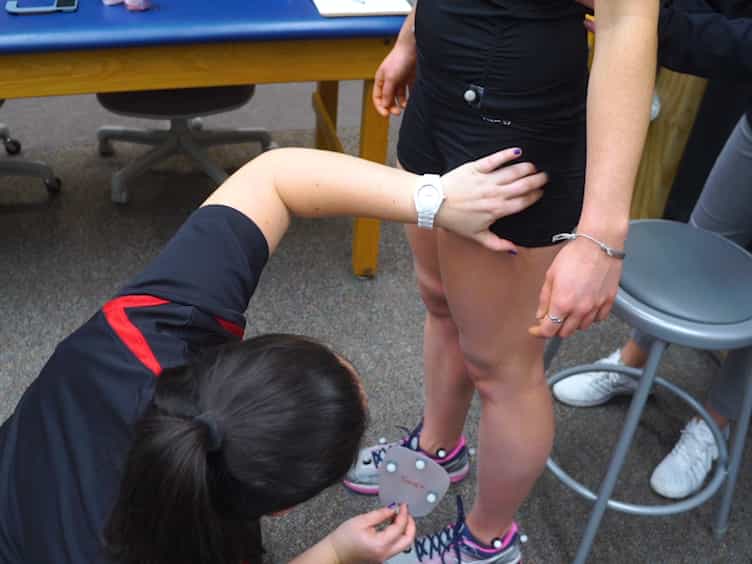
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Three-dimensional kinematic modelling of the human shoulder complex--Part II: Mathematical modelling and solution via
1Mechanical Engineering Department, King Saud University, Riyadh, Saudi Arabia.

Abstract:
In this paper, individual joint sinus cones associated with the sternoclavicular, claviscapular, and glenohumeral joints of the three-dimensional kinematic model introduced in Part I for the human shoulder complex are quantitatively determined. First, mathematical description of the humerus orientation with respect to torso is given in terms of eight joint variables. Since the system is a kinematically redundant one, solution for the joint variables satisfying a prescribed humerus orientation is possible only if additional requirements are imposed; and the "minimum joint motion" criterion is introduced for this purpose. Two methods, namely the Lagrange multipliers and flexible tolerance methods, are formulated and tested for the optimization problem. The statistical in-vivo data base for the circumductory motion of the upper arm is employed to determine a set of joint variables via optimization, which are then utilized to establish the sizes and orientations of the elliptical cones for the individual joint sinuses. The results are discussed and compared with those given on the basis of measurements made on cadaveric specimens.
Related Concept Videos
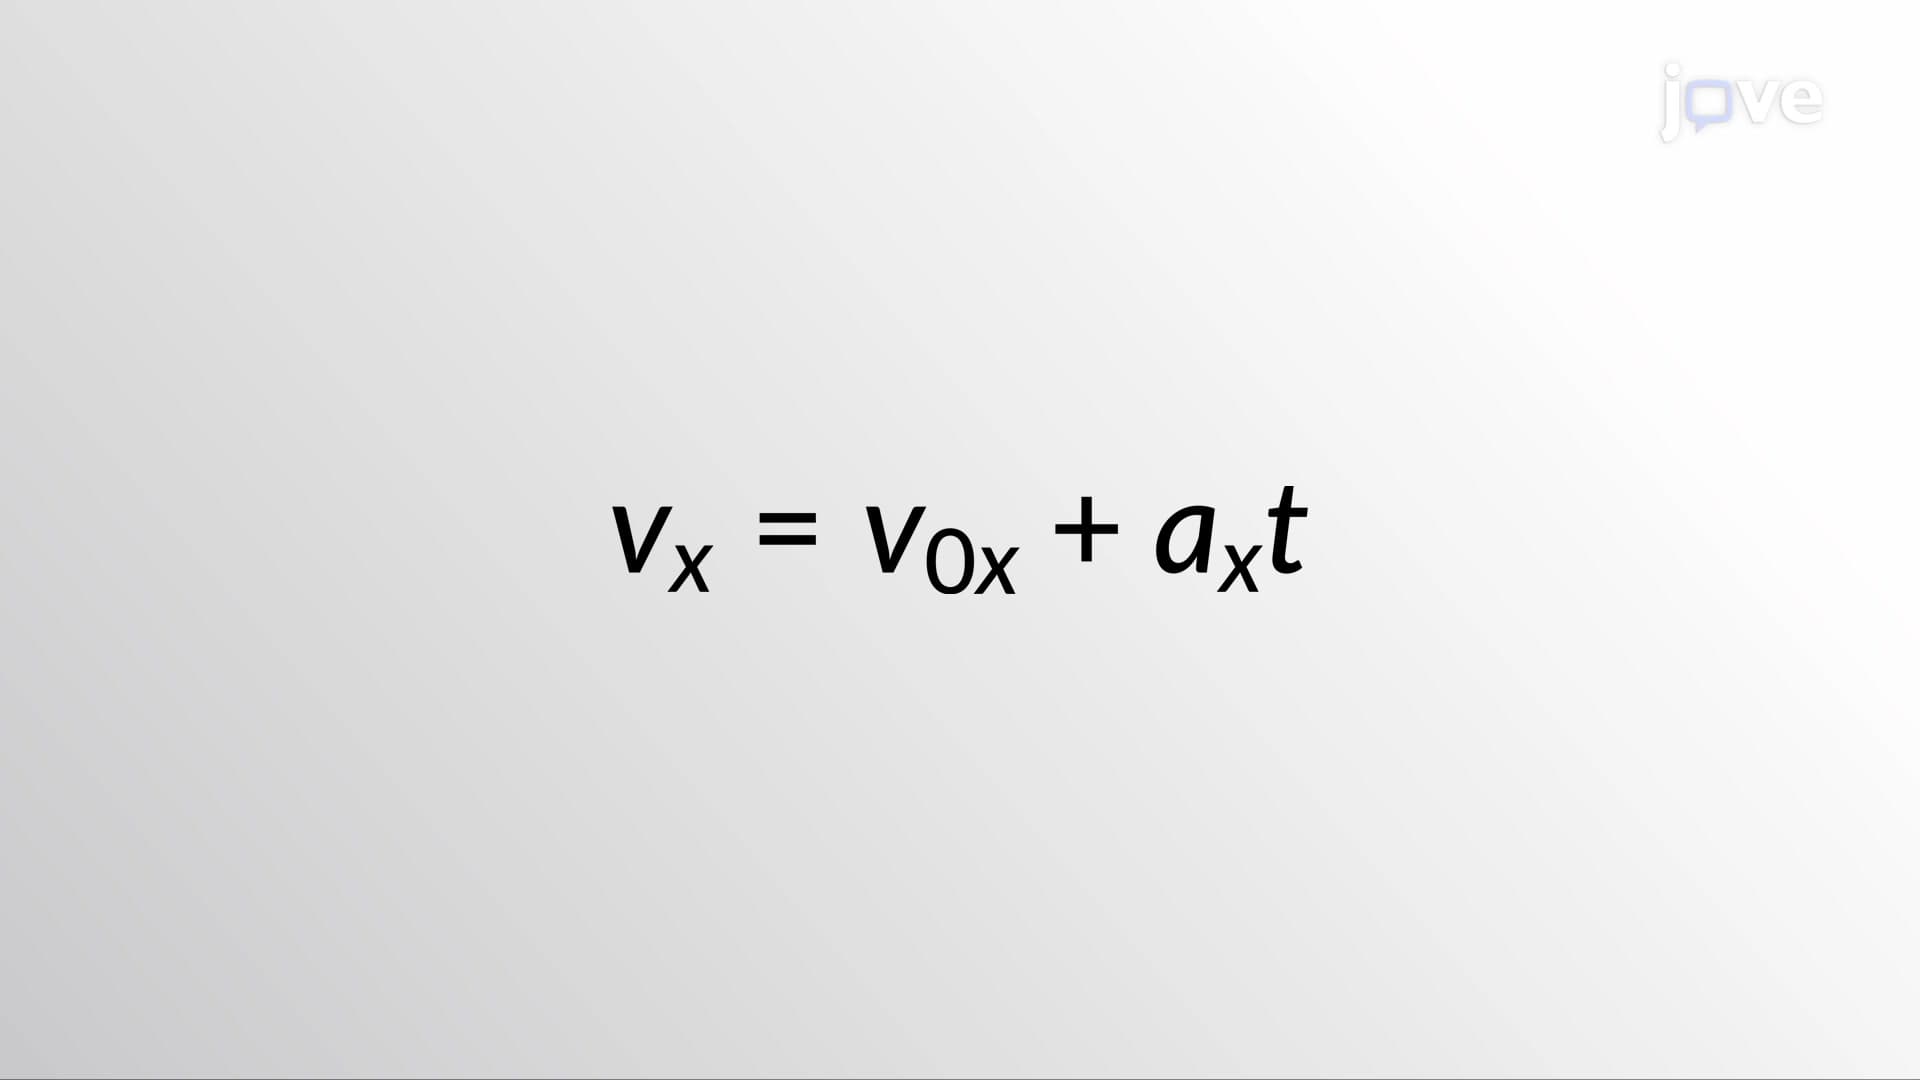 01:26
Kinematic Equations - I
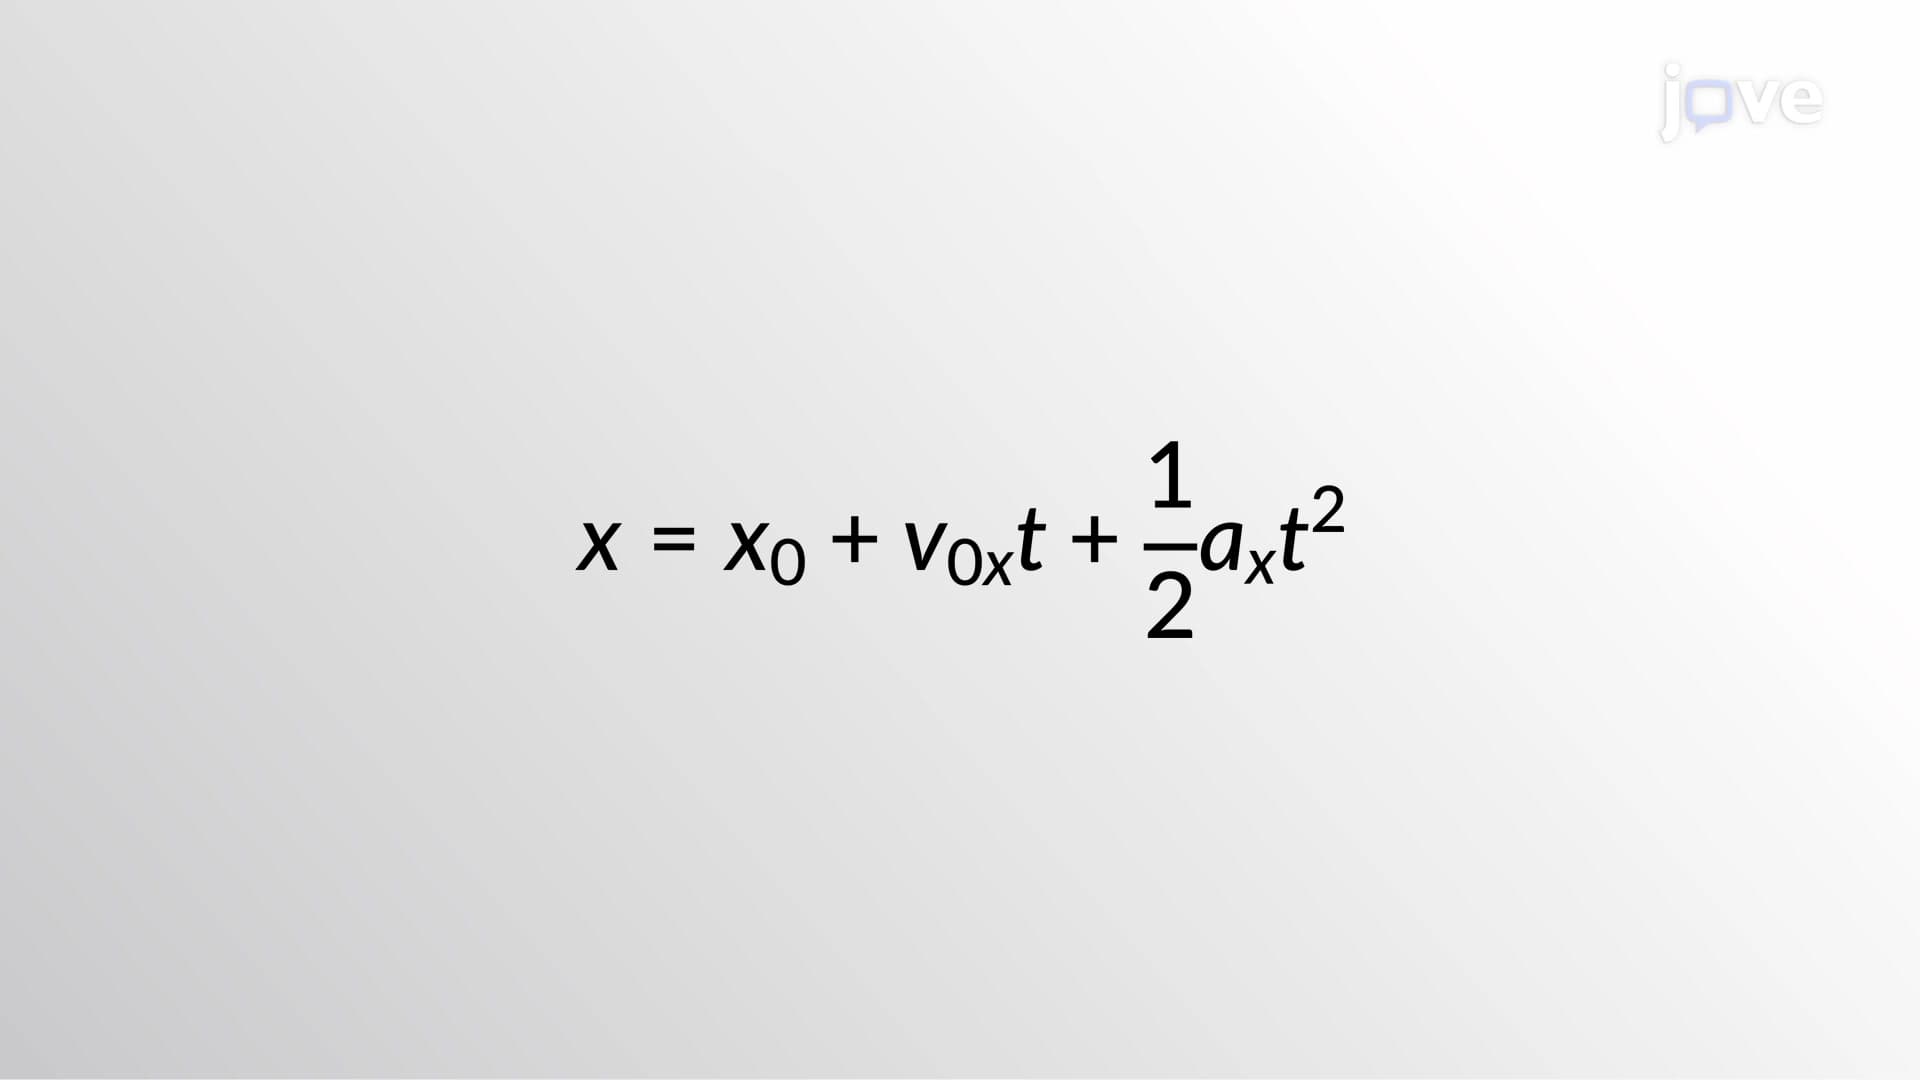 01:17
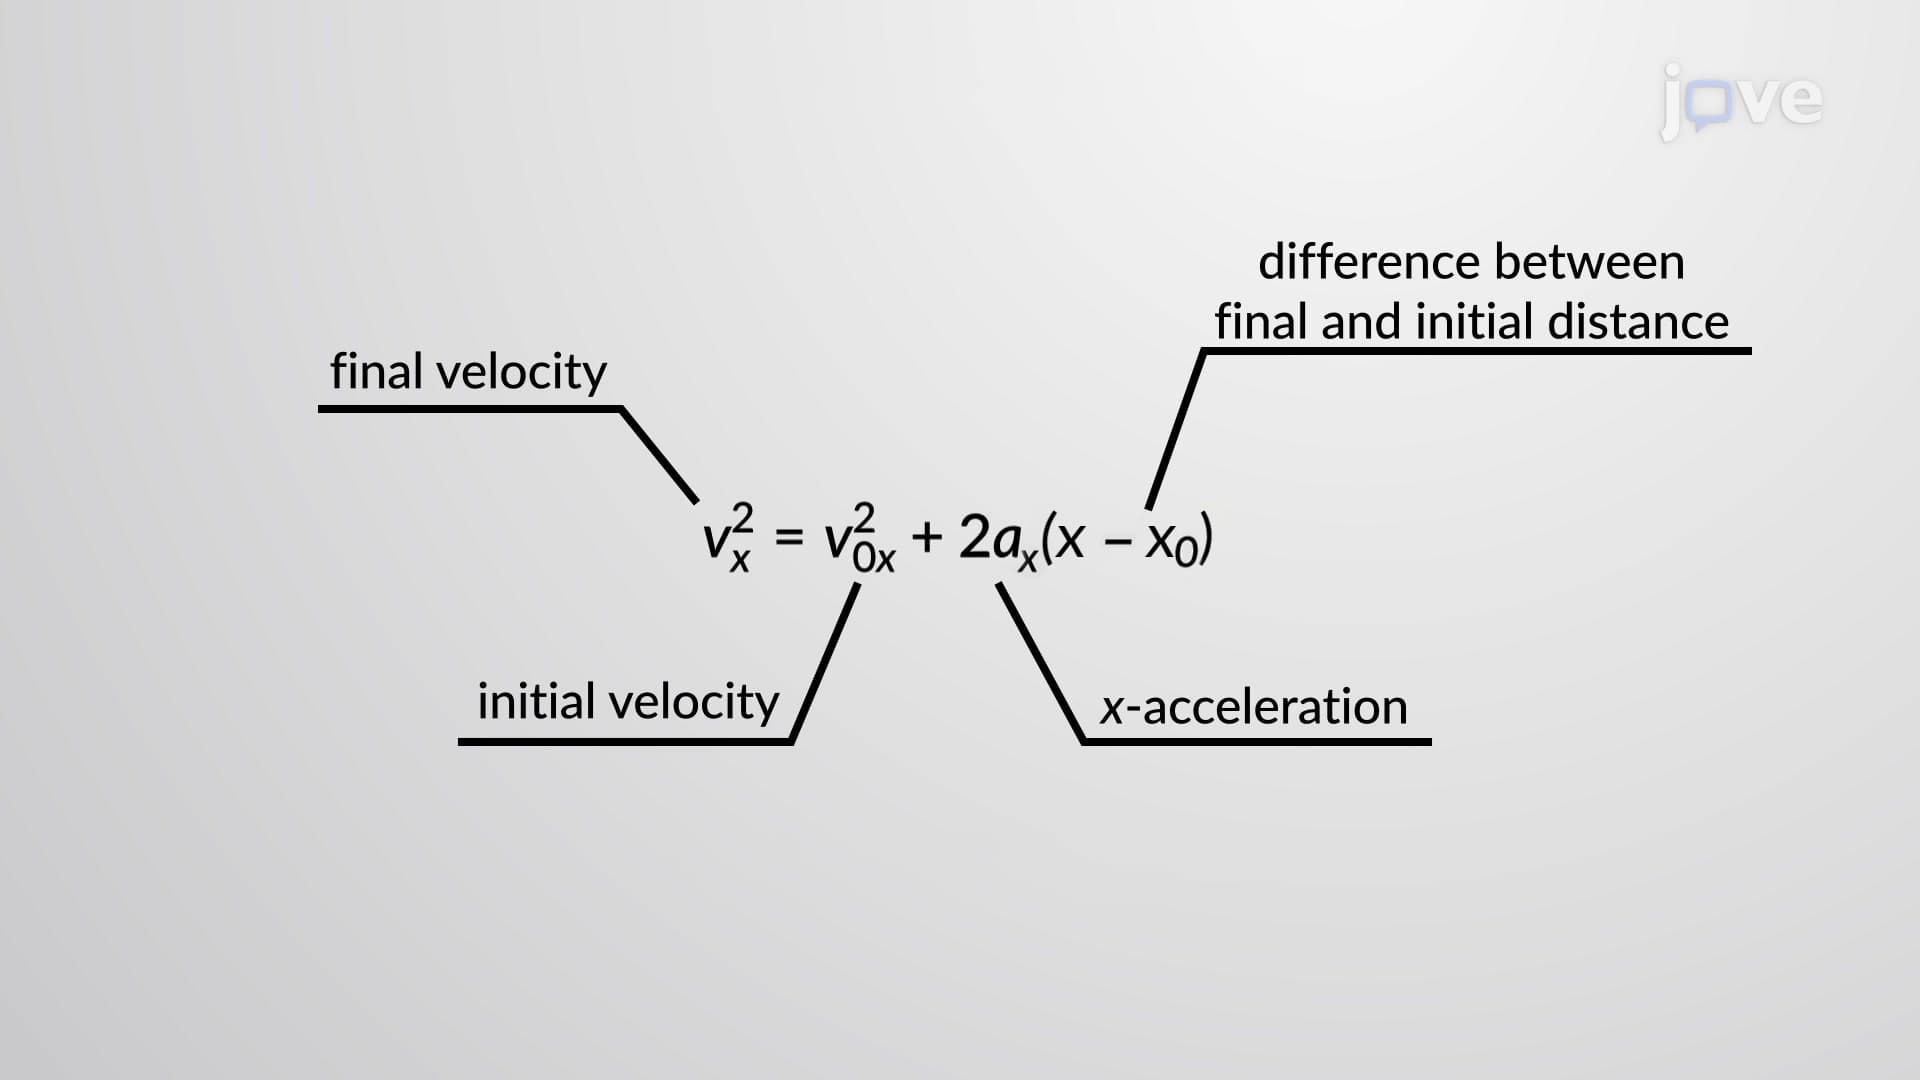
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...