Related Experiment Video
Updated: Mar 18, 2026


Author Spotlight: UAV Remote Sensing for Efficient Invasive Plant Biomass Estimation
Published on: February 9, 2024
Determining position, velocity and acceleration of free-ranging animals with a low-cost unmanned aerial system
Richard J Harvey1, Kyle Roskilly1, Chris Buse1
1Structure & Motion Laboratory, The Royal Veterinary College, University of London, Hatfield AL9 7TA, UK.

Abstract:
Unmanned aerial systems (UASs), frequently referred to as 'drones', have become more common and affordable and are a promising tool for collecting data on free-ranging wild animals. We used a Phantom-2 UAS equipped with a gimbal-mounted camera to estimate position, velocity and acceleration of a subject on the ground moving through a grid of GPS surveyed ground control points (area ∼1200 m(2)). We validated the accuracy of the system against a dual frequency survey grade GPS system attached to the subject. When compared with GPS survey data, the estimations of position, velocity and acceleration had a root mean square error of 0.13 m, 0.11 m s(-1) and 2.31 m s(-2), respectively. The system can be used to collect locomotion and localisation data on multiple free-ranging animals simultaneously. It does not require specialist skills to operate, is easily transported to field locations, and is rapidly and easily deployed. It is therefore a useful addition to the range of methods available for field data collection on free-ranging animal locomotion.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:34
Velocity and Position by Graphical Method
 01:29
Application of Linearization and Approximation
 01:00
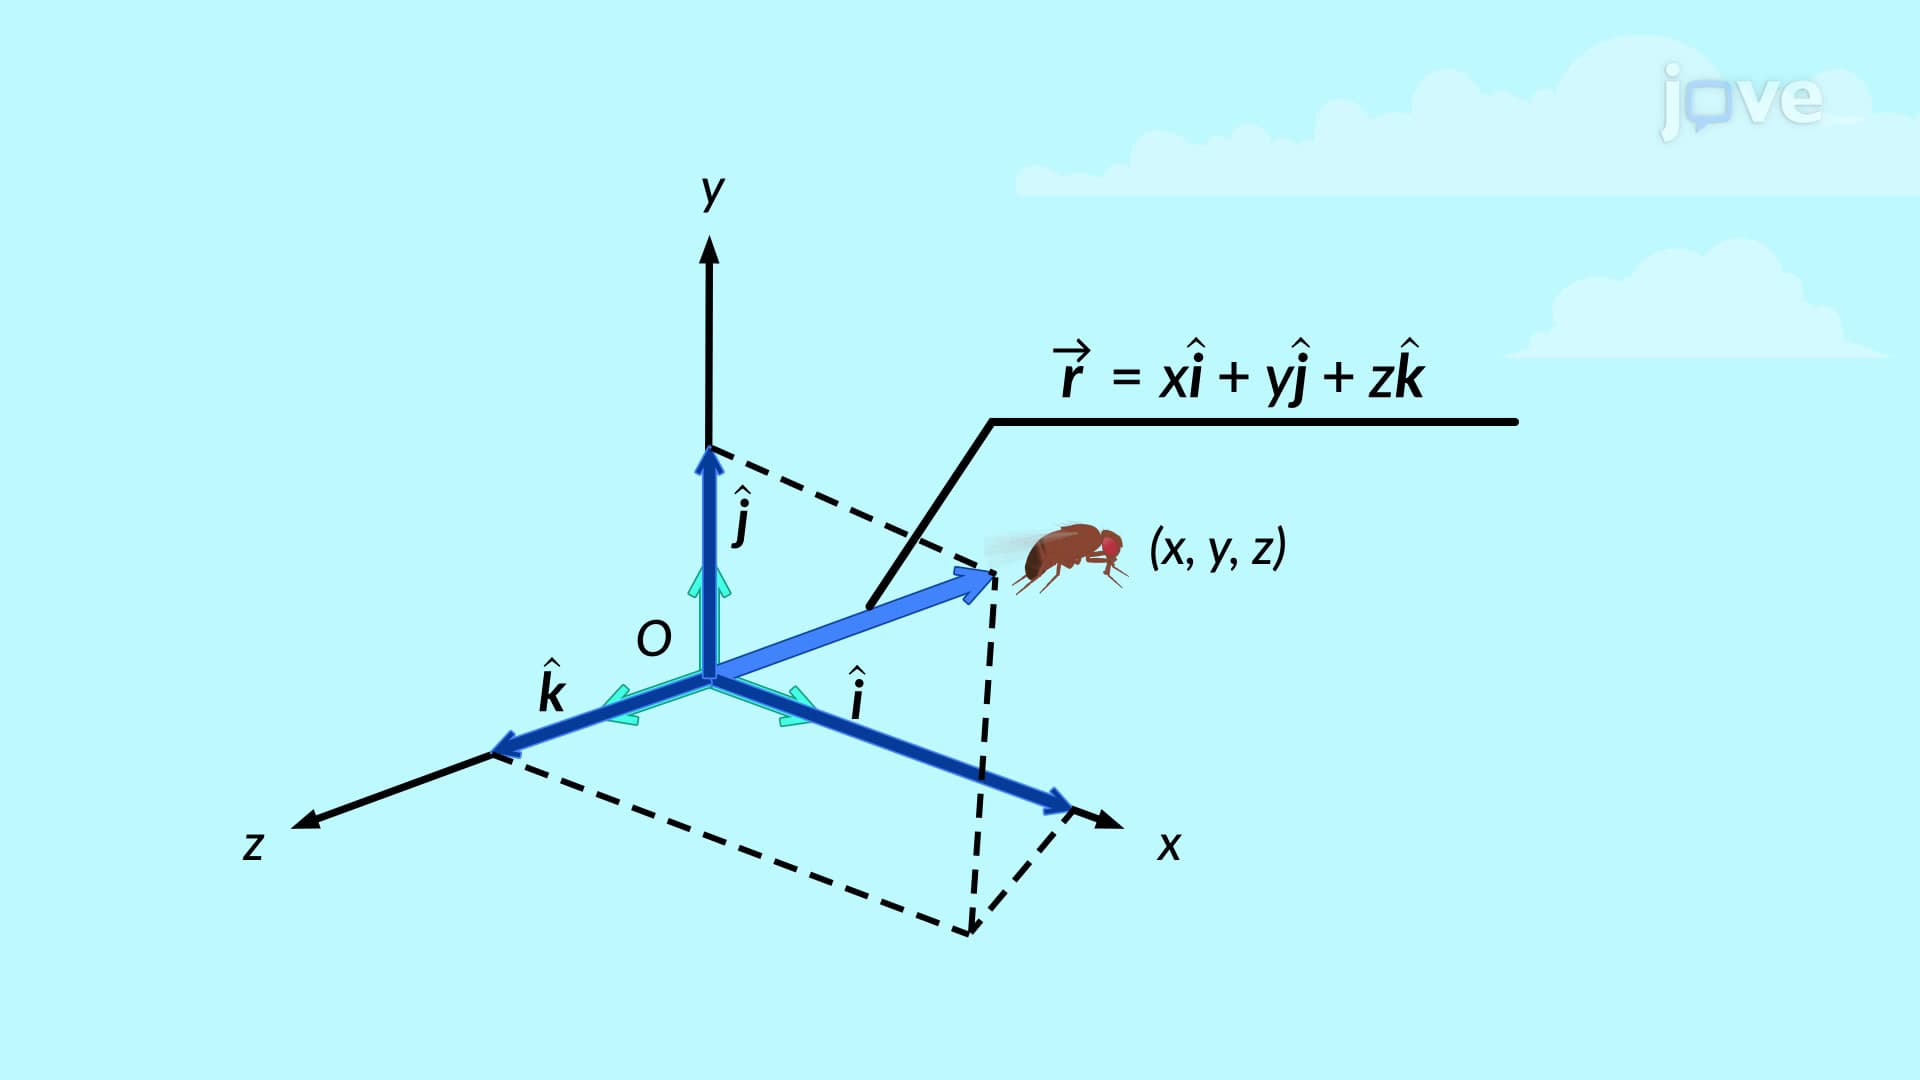
Position and Displacement Vectors
Further, several important kinds of...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...