Related Experiment Video
Updated: Mar 18, 2026


Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Control Synthesis of Discrete-Time T-S Fuzzy Systems: Reducing the Conservatism Whilst Alleviating the Computational

Abstract:
The augmented multi-indexed matrix approach acts as a powerful tool in reducing the conservatism of control synthesis of discrete-time Takagi-Sugeno fuzzy systems. However, its computational burden is sometimes too heavy as a tradeoff. Nowadays, reducing the conservatism whilst alleviating the computational burden becomes an ideal but very challenging problem. This paper is toward finding an efficient way to achieve one of satisfactory answers. Different from the augmented multi-indexed matrix approach in the literature, we aim to design a more efficient slack variable approach under a general framework of homogenous matrix polynomials. Thanks to the introduction of a new extended representation for homogeneous matrix polynomials, related matrices with the same coefficient are collected together into one sole set and thus those redundant terms of the augmented multi-indexed matrix approach can be removed, i.e., the computational burden can be alleviated in this paper. More importantly, due to the fact that more useful information is involved into control design, the conservatism of the proposed approach as well is less than the counterpart of the augmented multi-indexed matrix approach. Finally, numerical experiments are given to show the effectiveness of the proposed approach.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:16
SFG Algebra
Each node in an SFG corresponds to a variable, and the interactions between nodes are represented by branches with associated gains. When multiple branches lead into a node, the value at that node is the sum of the...
 01:21
Transfer Function in Control Systems
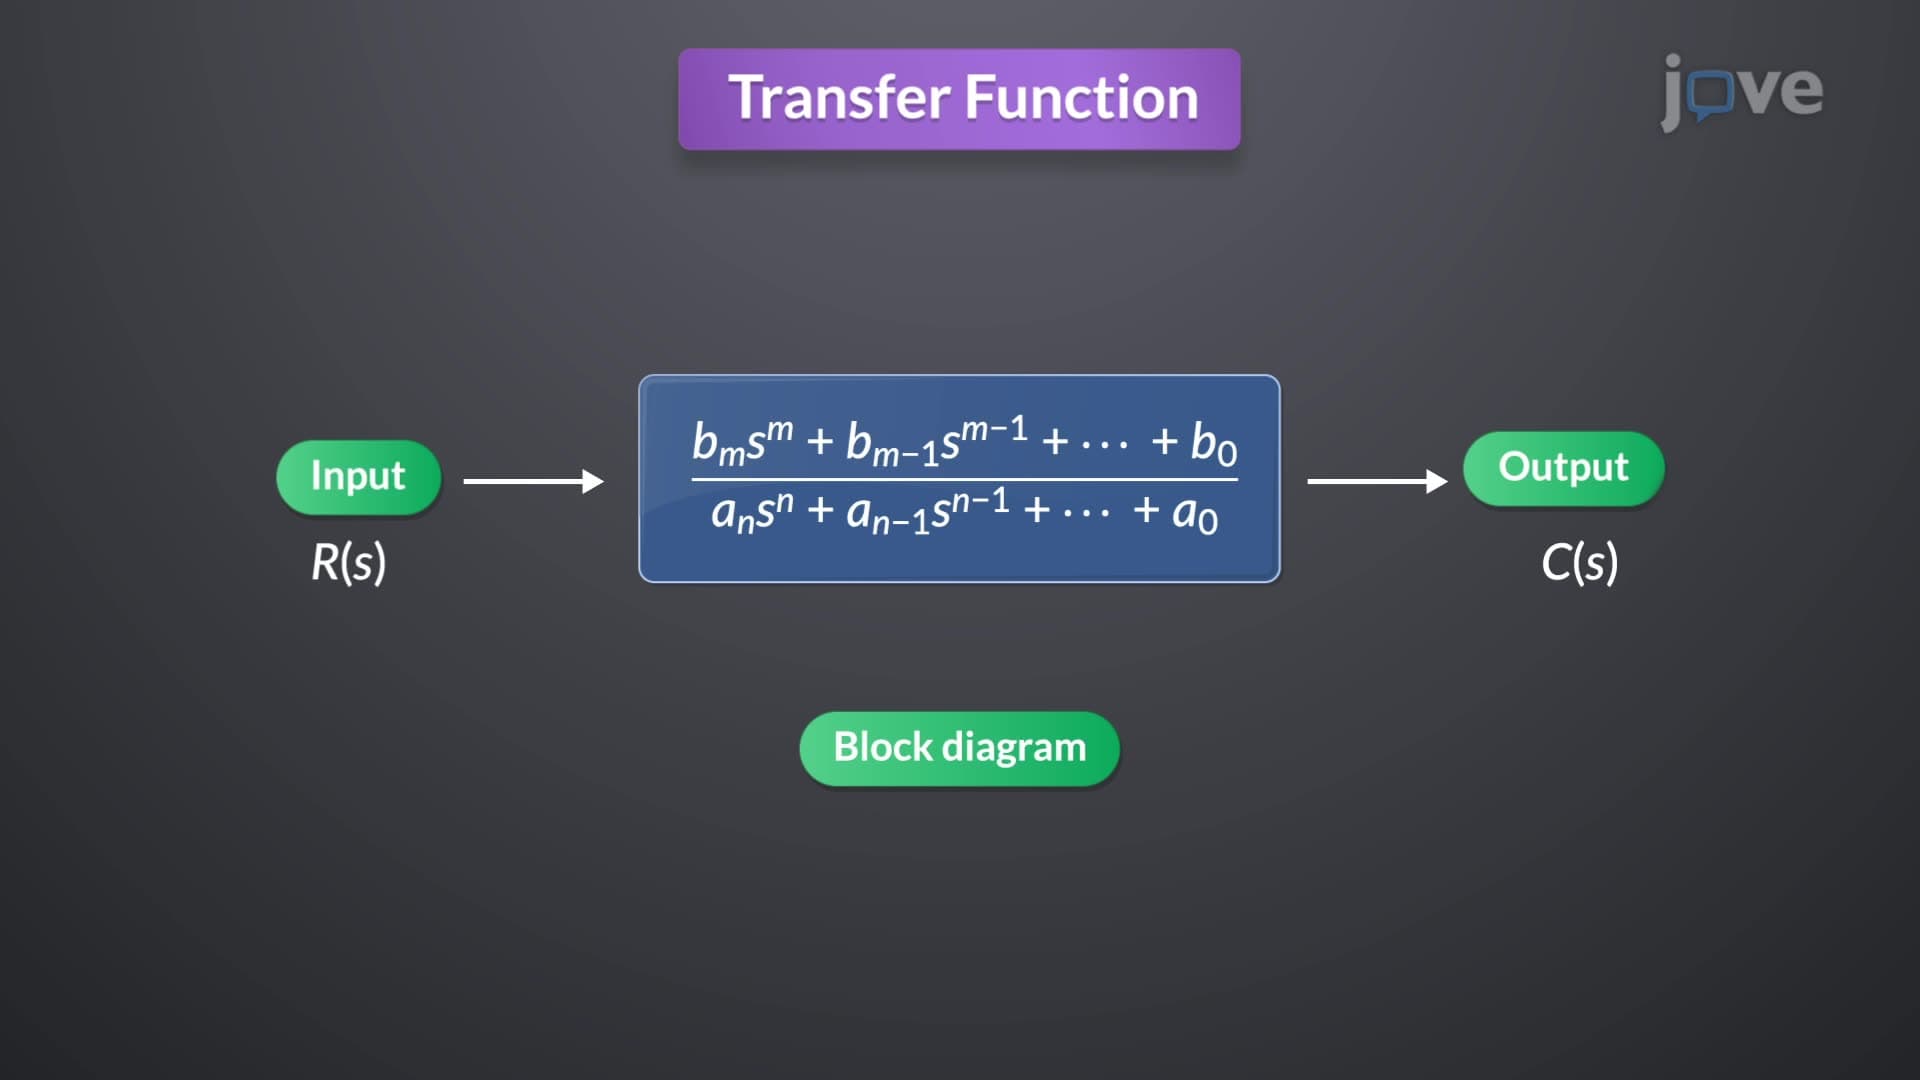
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:21
State Space to Transfer Function
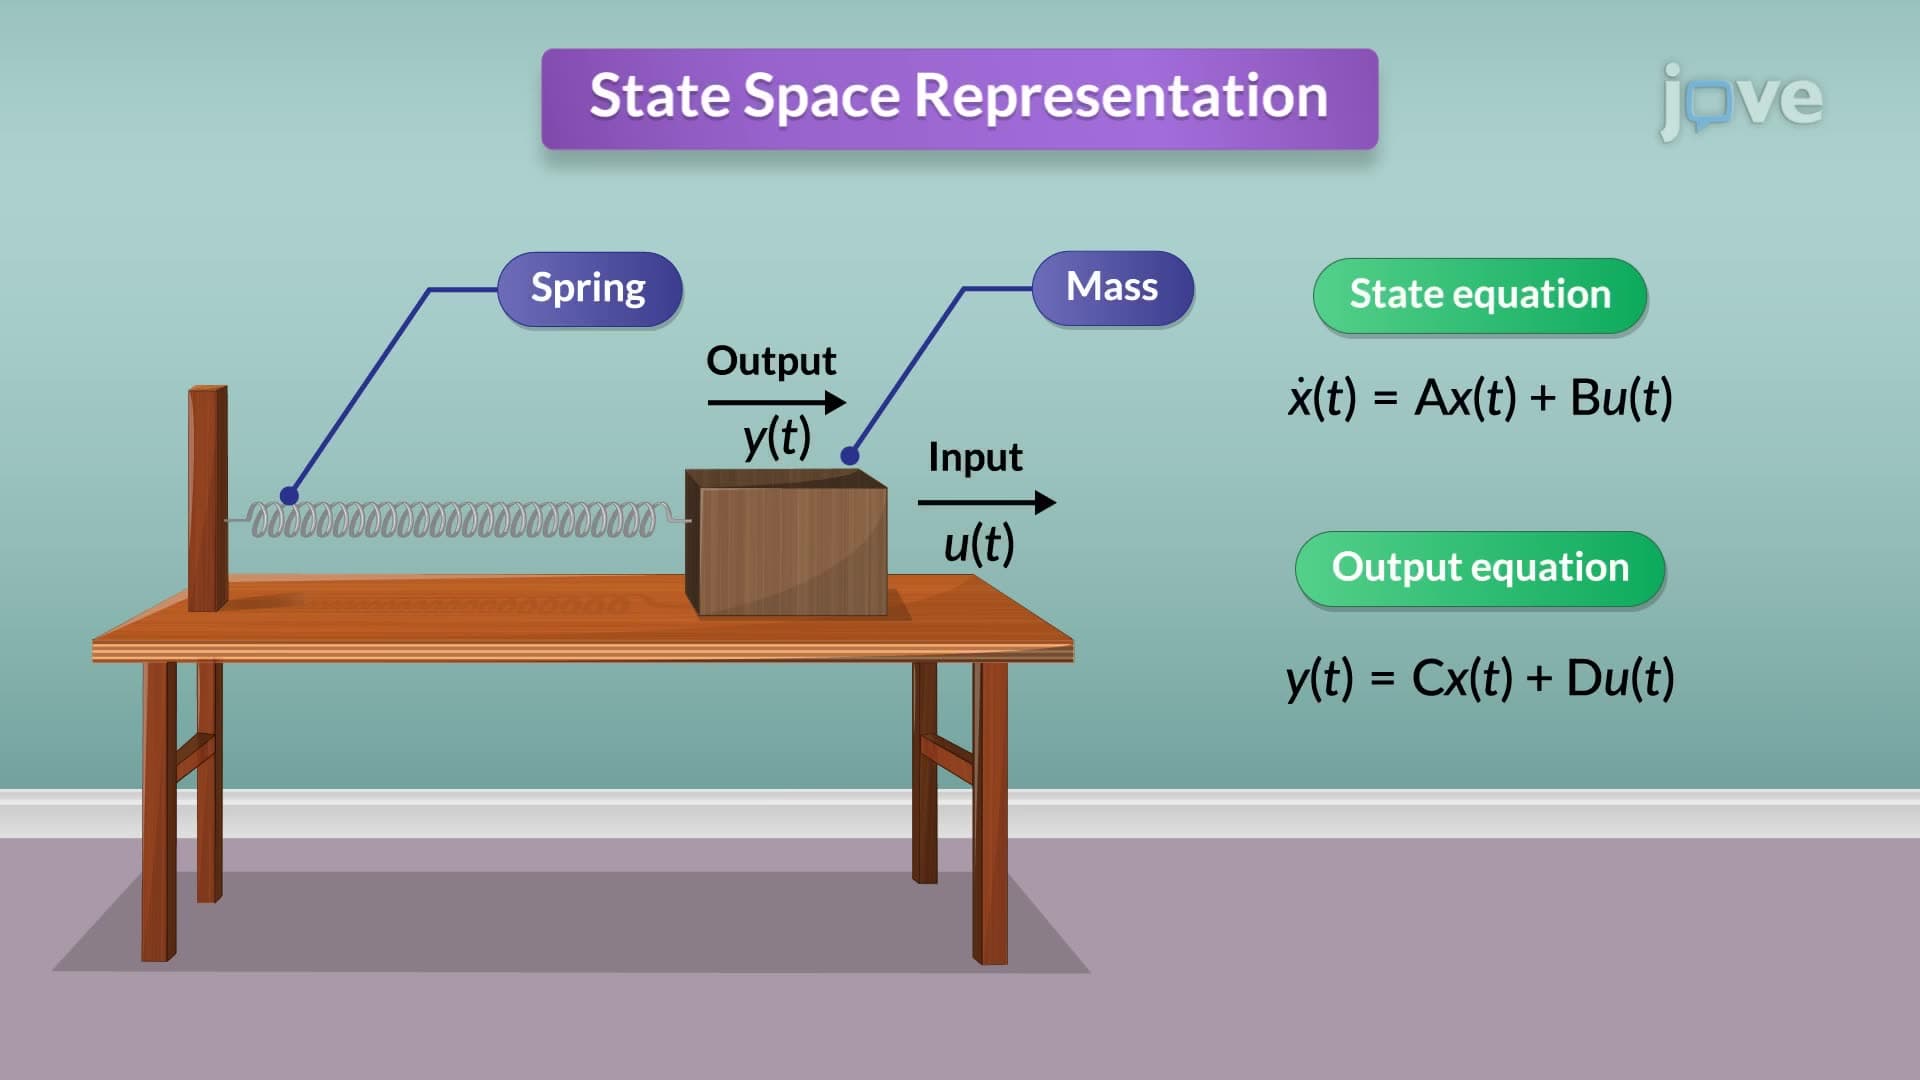
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
Transfer Function to State Space
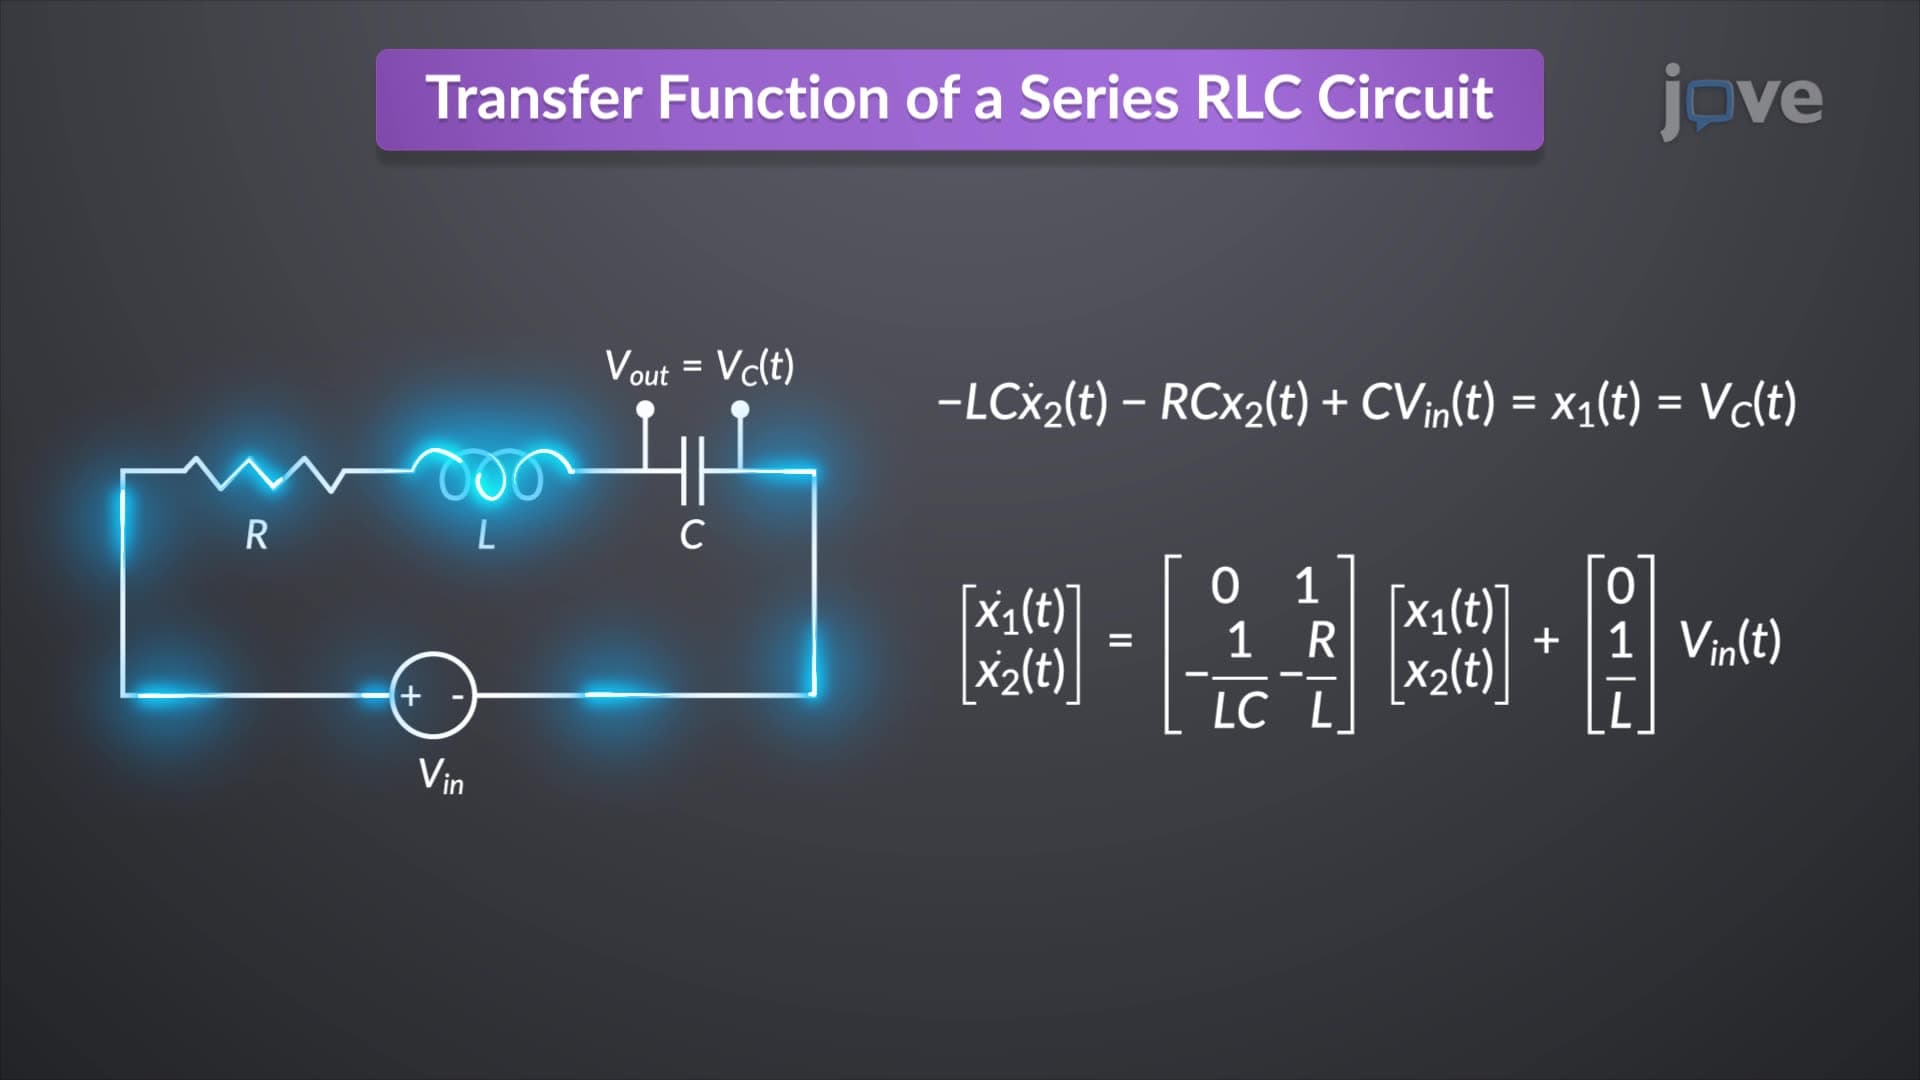
In an RLC...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...