Related Experiment Video
Updated: Mar 17, 2026


Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Passivity-based control of an omnidirectional mobile robot
Chao Ren1, Yi Sun2, Shugen Ma3
1School of Electrical Engineering and Automation, Tianjin University, 92 WeijinRoad, Tianjin, 300072 China.

Abstract:
This paper studies passivity-based trajectory tracking control of an omnidirectional mobile robot. The proposed control design is simple to be implemented in practice, because of an effective exploitation of the structure of robot dynamics. First, the passivity property of the prototype robot is analyzed. Then the control system is designed based on the energy shaping plus damping approach. We find that the prototype robot itself has enough damping forces. As a result, only energy shaping is needed in our proposed controller, while the damping injection is unnecessary for our robot. In other words, the disadvantages of differential feedback, such as amplifying the measurement noise, can be avoided. Globally asymptotic stability is guaranteed. Both simulations and experimental results show the effectiveness of the proposed control design.


Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:13
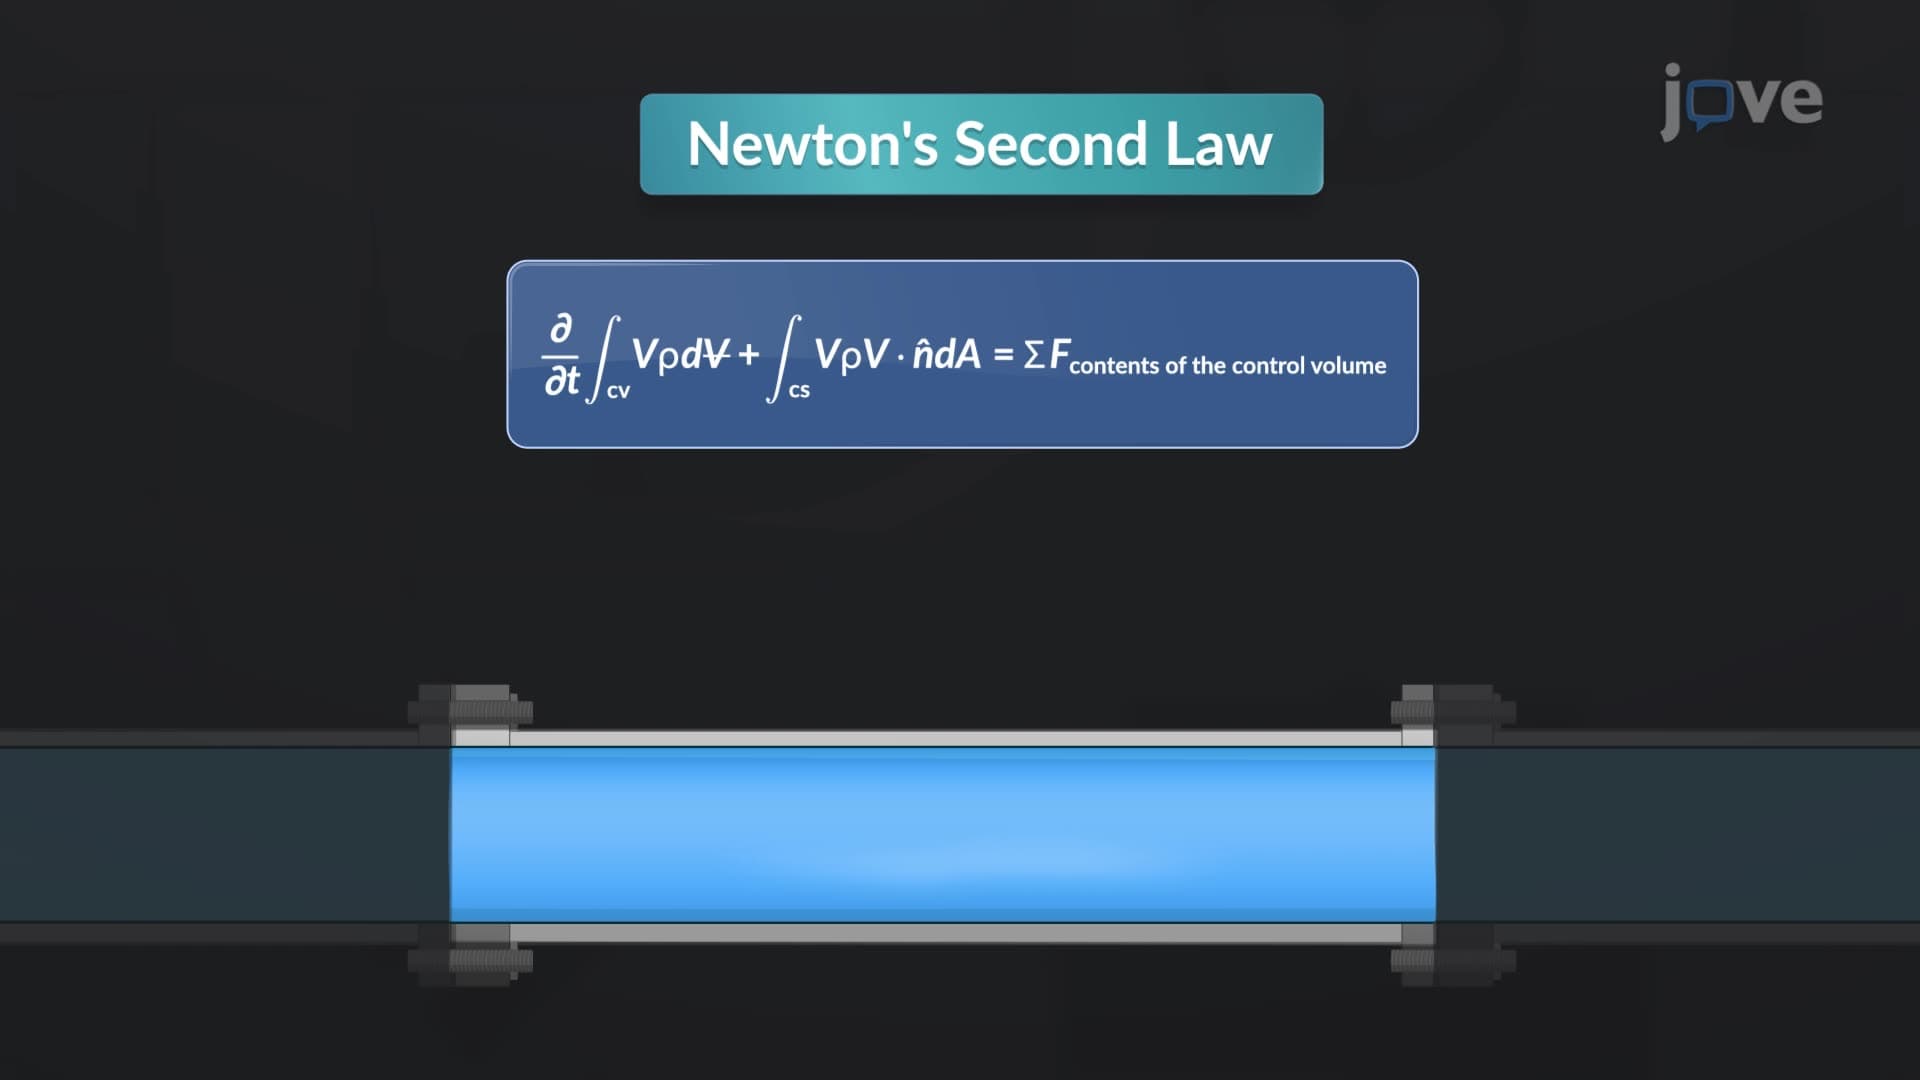
Linear Momentum in Control Volume
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...