Related Experiment Video
Updated: Mar 17, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Driving with central field loss III: vehicle control
P Matthew Bronstad1, Amanda Albu2, Robert Goldstein1
1Schepens Eye Research Institute, Massachusetts Eye and Ear, Harvard Medical School, Boston, Massachusetts, USA.

Background:
Visual impairment associated with central field loss may make vehicle control more difficult due to the degraded view of the road. We evaluated how central field loss affects vehicle control in a driving simulator.
Methods:
Nineteen participants with binocular central field loss (acuity 6/9 to 6/60) and 15 controls with normal vision drove 10 scenarios, each about eight to 12 minutes. Speed, lane offset and steering wheel reversal rate were measured on straights, left and right curves, along city (approximately 50 km/h) and rural highway (approximately 100 km/h) routes. Following distance was measured on two city straight segments.
Results:
Subjects with central field loss had higher steering wheel reversal rates (0.55 versus 0.45 reversals per second, p = 0.015), suggesting that the steering task was more demanding for them, requiring more steering corrections; however, they did not differ in other performance measures. Nearly all maintained a safe following distance, although they were more likely than controls with normal vision to lose sight of the lead car in scenarios that required following a car.
Conclusions:
Most measures of vehicle control did not significantly differ between participants with central field loss and those with normal vision; however, the higher steering wheel reversal rates suggest that, in compensating for their vision impairment, drivers with central field loss had to allocate extra steering effort to maintain their lane position, which in turn could reduce attentional resources for other driving tasks.


Related Concept Videos
 01:14
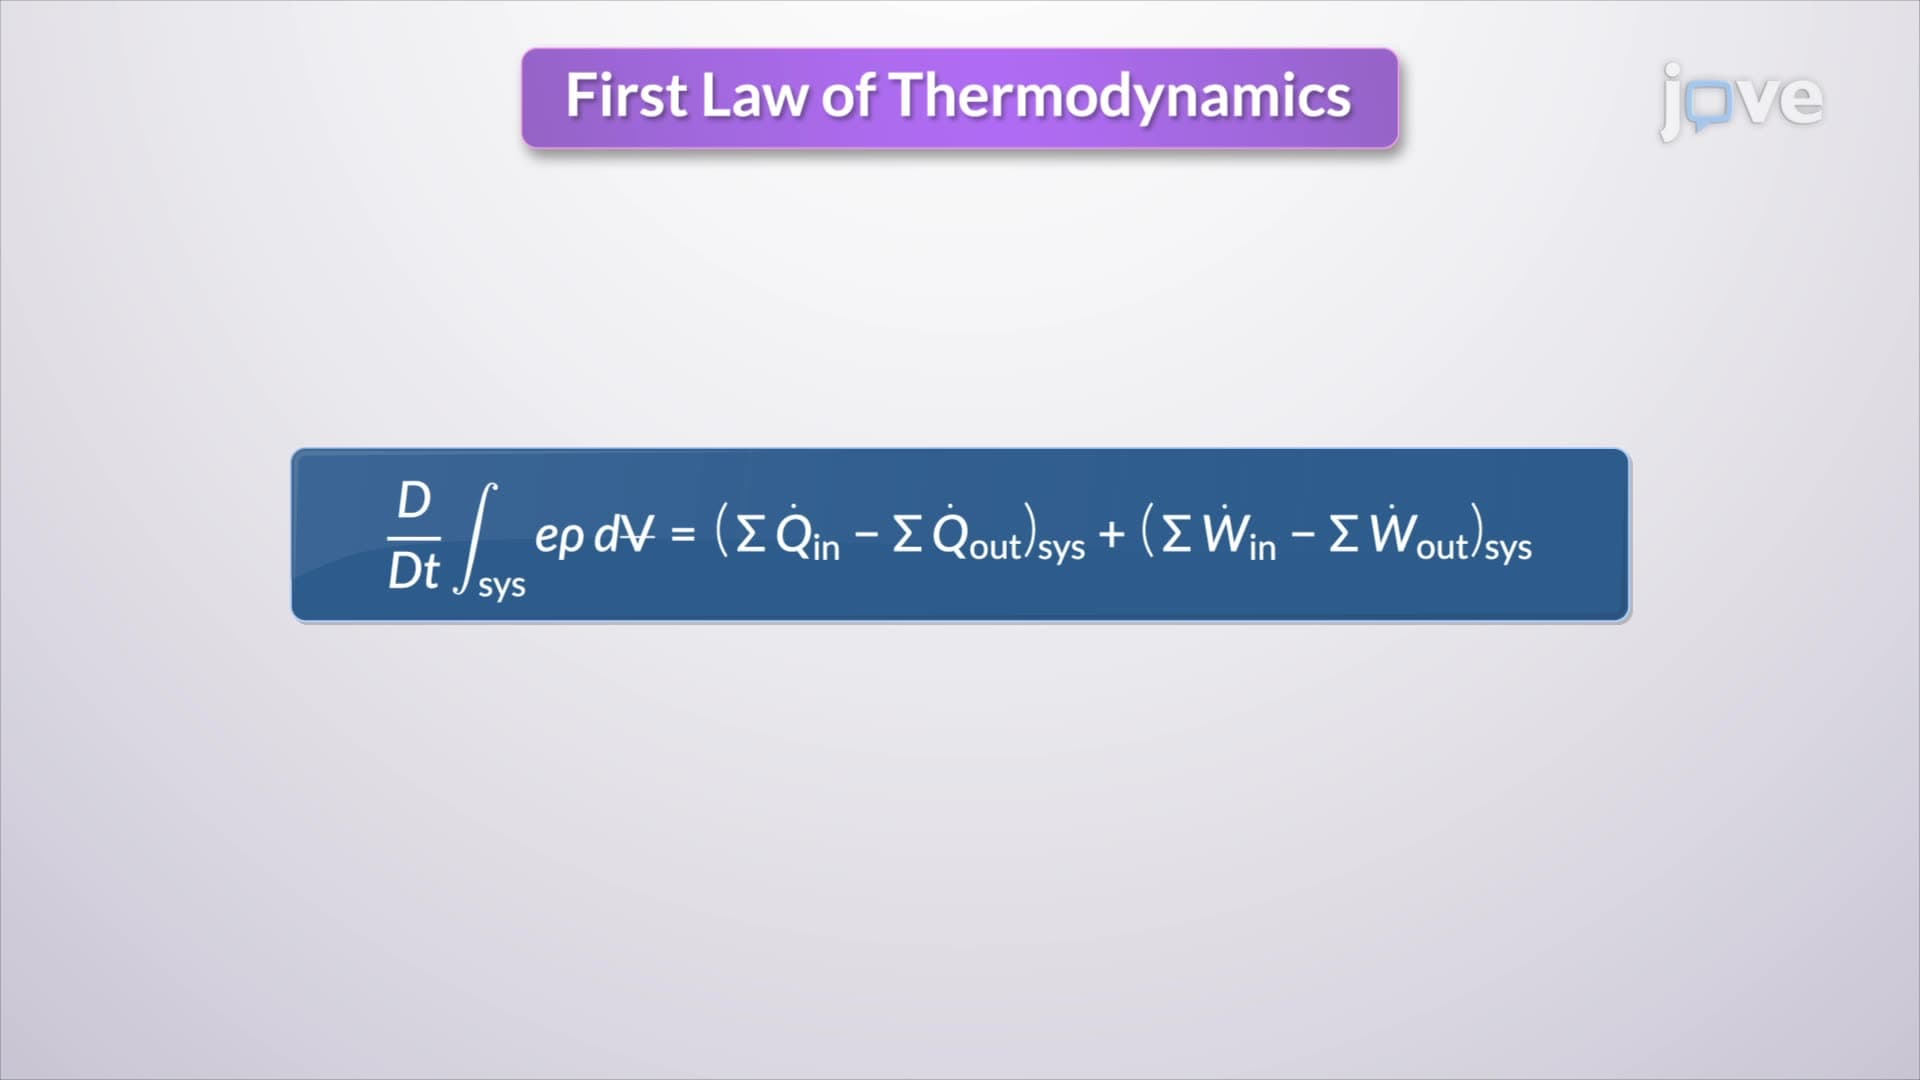
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:13
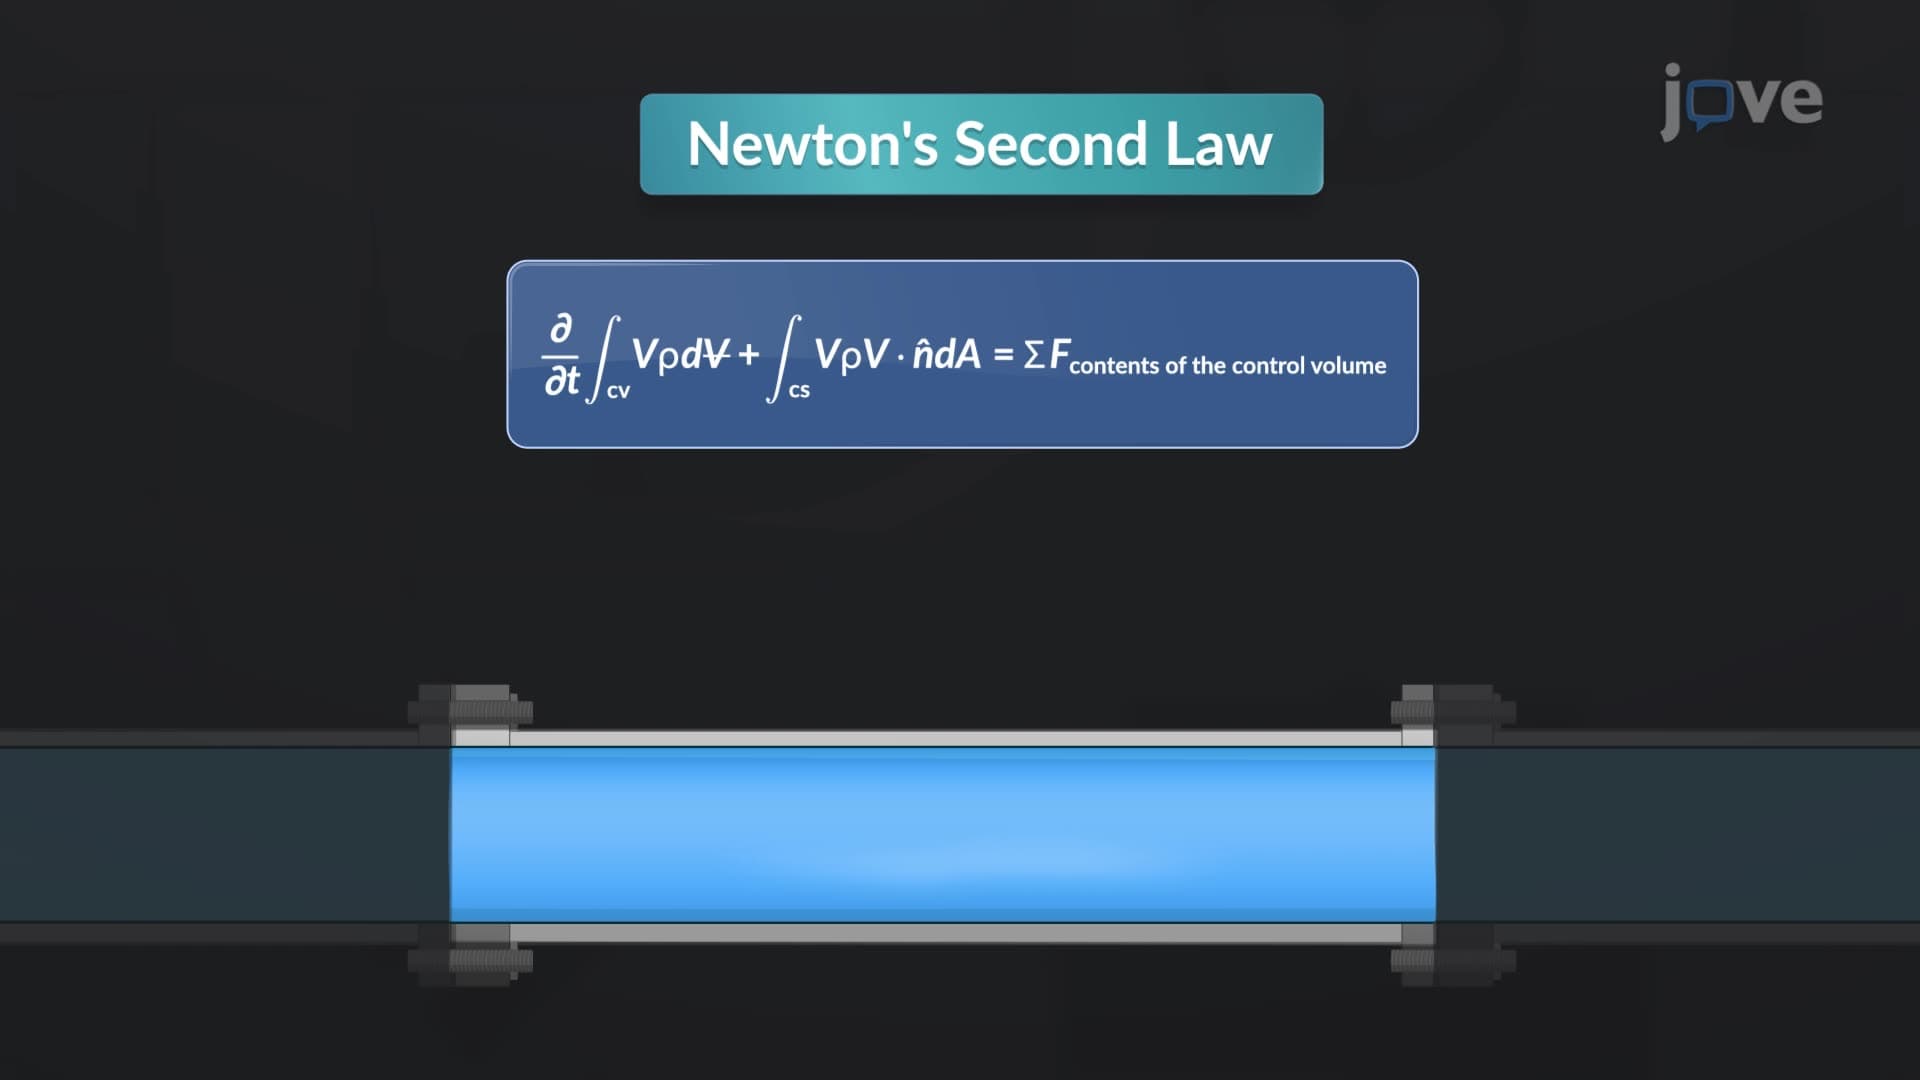
Linear Momentum in Control Volume
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
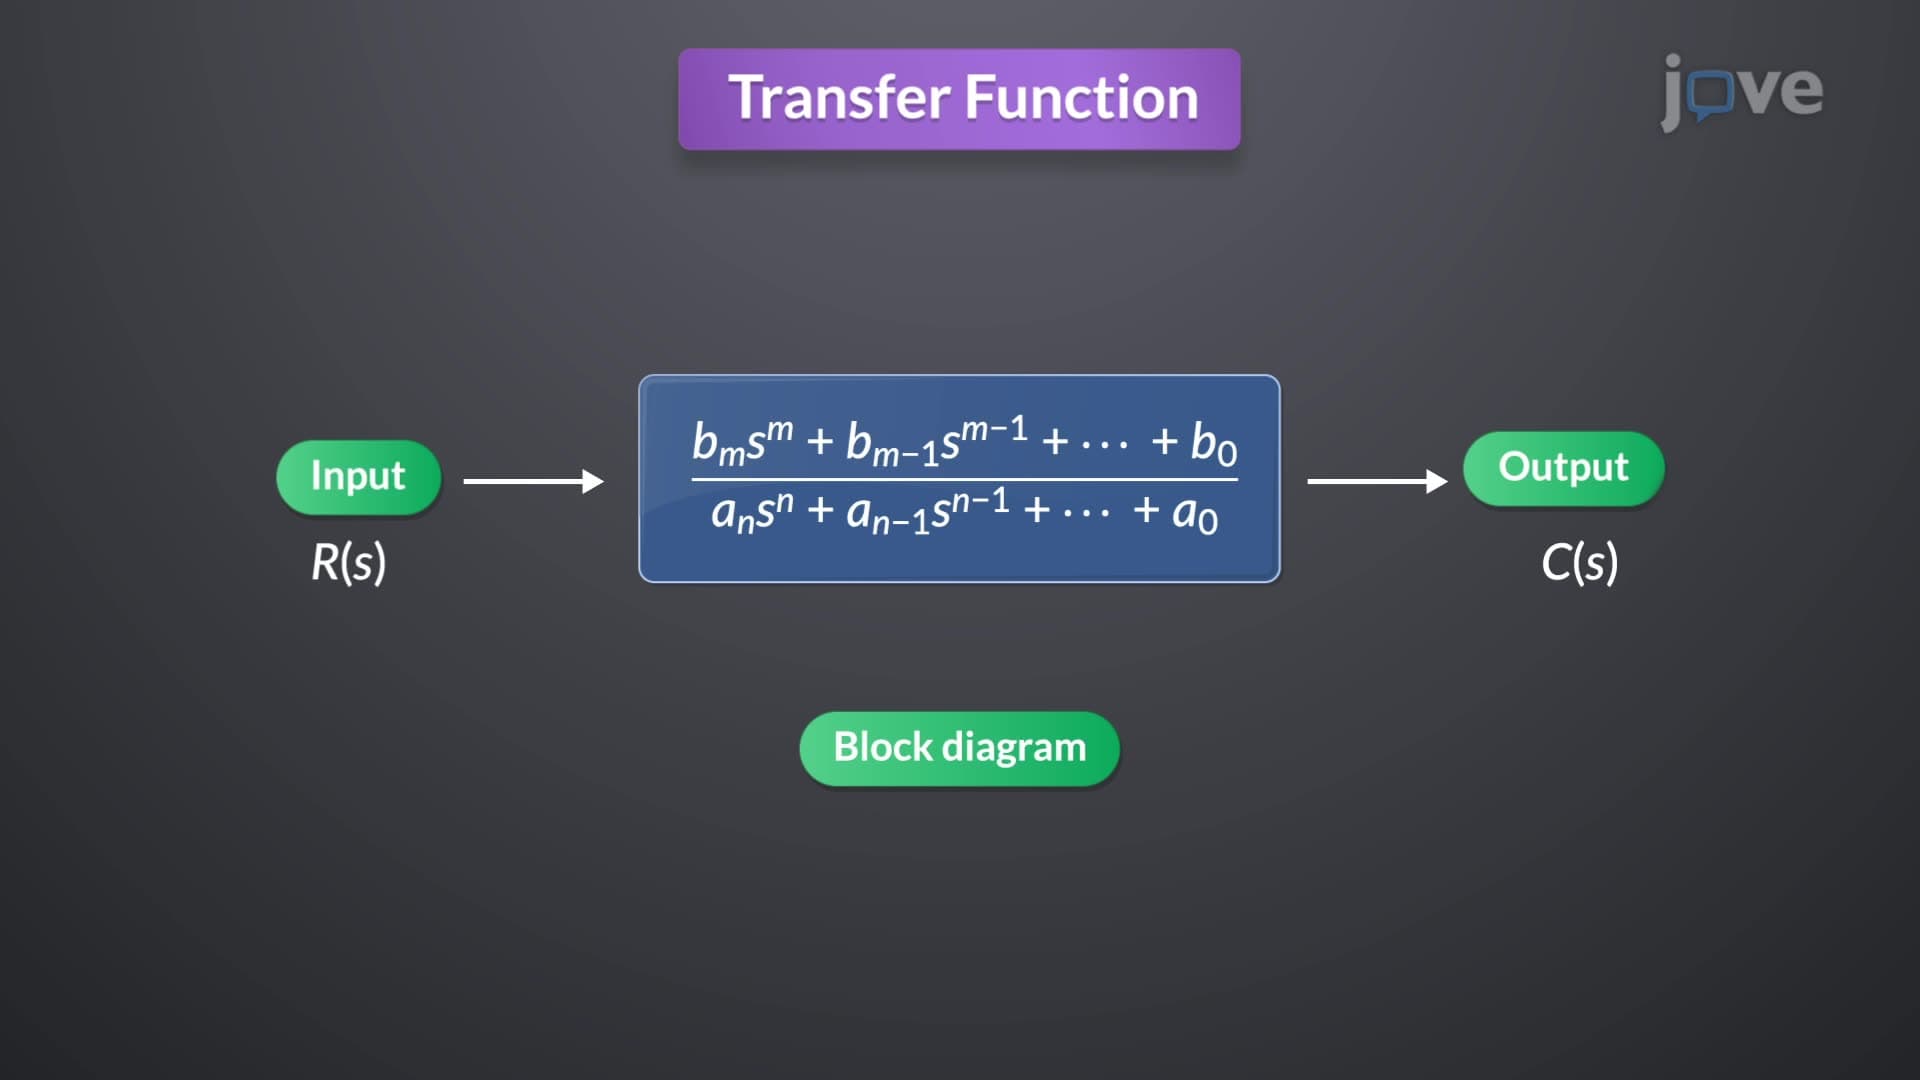
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...