

Gain-compensated sinusoidal scanning of a galvanometer mirror in proportional-integral-differential control using the

Abstract:
We propose a method to achieve precise sine-wave path tracking for real-time motion-blur compensation to extend the corresponding frequency spectrum in proportional-integral-differential (PID) control by using a pre-emphasis technique. We calculate pre-emphasis coefficients in advance to follow a sine wave with a gain of 0 dB and multiply the input signal by these pre-emphasis coefficients. In experiments, we were thus able to extend the greatest frequency from 100 to 500 Hz and achieve gain improvement of approximately 3 dB at 400 and 500 Hz. For the application of inspection, we confirmed that motion blur is significantly reduced when the system operates at high frequency, and we achieved a responsiveness 3.3 times higher than that of our previous system.
Related Concept Videos
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:24
PI Controller: Design
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:24
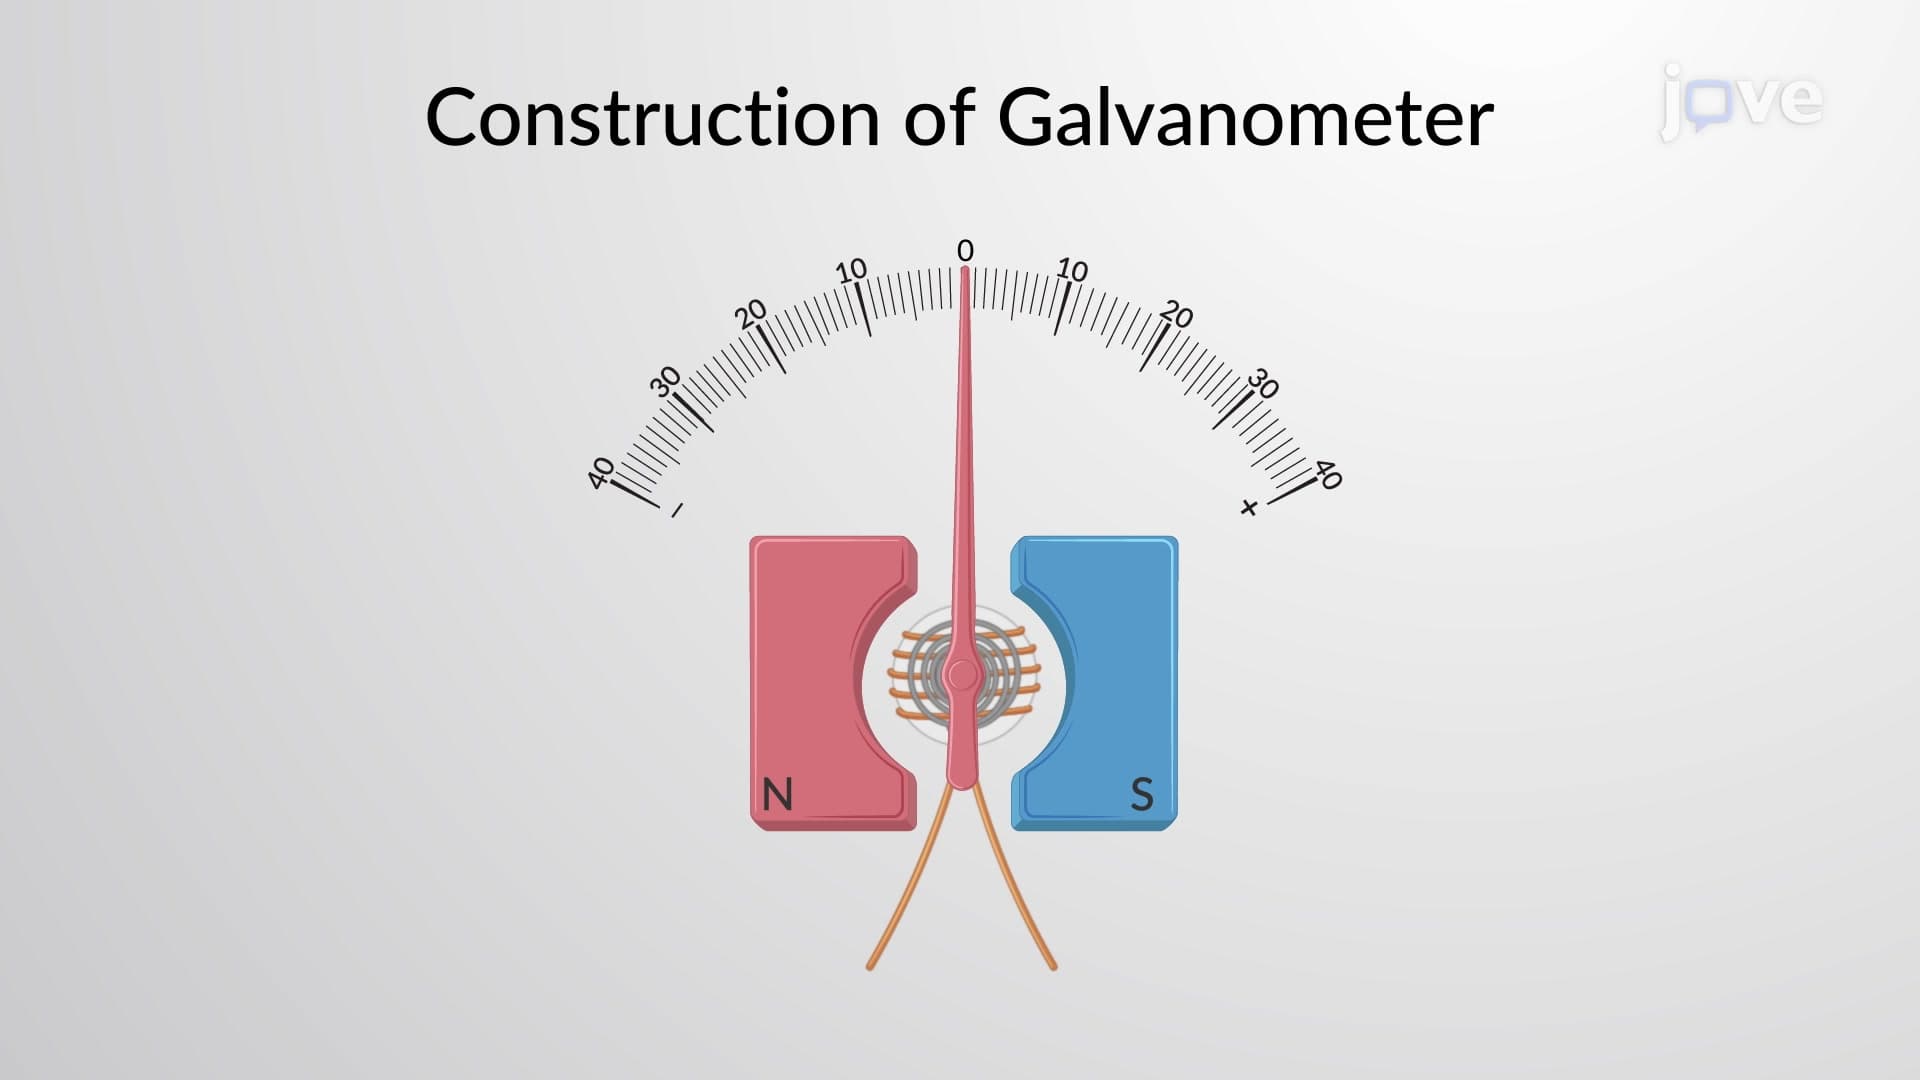
Galvanometer
The galvanometer consists of two concave-shaped permanent magnets, providing a uniform radial magnetic field in the annular region. In the center, a pivoted coil of fine copper wire is placed in the uniform...
 01:19
PID Controller