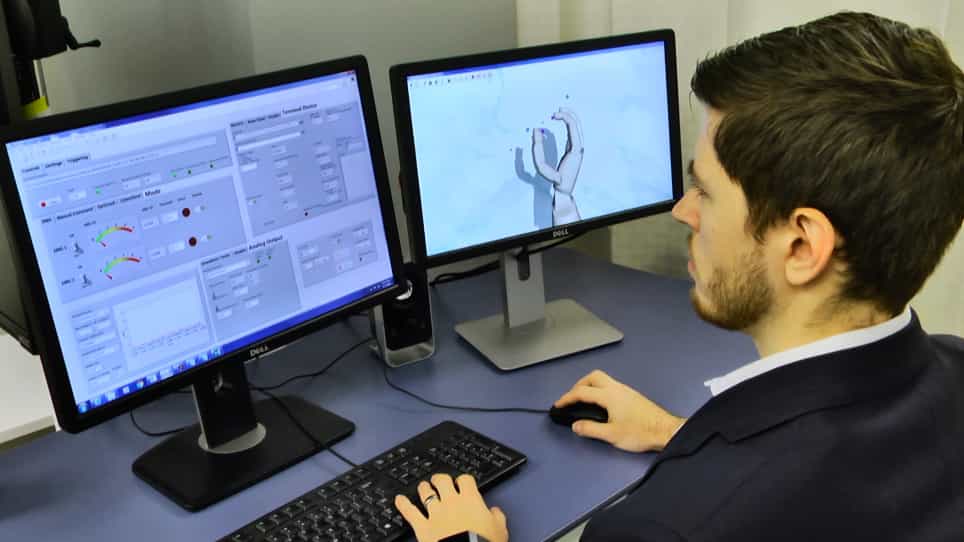
Real-time simulation of hand motion for prosthesis control
Related Experiment Video
Updated: Mar 11, 2026

A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Dimitra Blana1, Edward K Chadwick1, Antonie J van den Bogert2
1a Institute for Science and Technology in Medicine , Keele University , Keele , UK .

Abstract:
Individuals with hand amputation suffer substantial loss of independence. Performance of sophisticated prostheses is limited by the ability to control them. To achieve natural and simultaneous control of all wrist and hand motions, we propose to use real-time biomechanical simulation to map between residual EMG and motions of the intact hand. Here we describe a musculoskeletal model of the hand using only extrinsic muscles to determine whether real-time performance is possible. Simulation is 1.3 times faster than real time, but the model is locally unstable. Methods are discussed to increase stability and make this approach suitable for prosthesis control.