Related Experiment Video
Updated: Mar 11, 2026

An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Estimation of the center of rotation using wearable magneto-inertial sensors
1Department of Electrical and Electronic Engineering, University of Cagliari, Piazza d'Armi, 09123 Cagliari, Italy.

Abstract:
Determining the center of rotation (CoR) of joints is fundamental to the field of human movement analysis. CoR can be determined using a magneto-inertial measurement unit (MIMU) using a functional approach requiring a calibration exercise. We systematically investigated the influence of different experimental conditions that can affect precision and accuracy while estimating the CoR, such as (a) angular joint velocity, (b) distance between the MIMU and the CoR, (c) type of the joint motion implemented, (d) amplitude of the angular range of motion, (e) model of the MIMU used for data recording, (f) amplitude of additive noise on inertial signals, and (g) amplitude of the errors in the MIMU orientation. The evaluation process was articulated at three levels: assessment through experiments using a mechanical device, mathematical simulation, and an analytical propagation model of the noise. The results reveal that joint angular velocity significantly impacted CoR identification, and hence, slow joint movement should be avoided. An accurate estimation of the MIMU orientation is also fundamental for accurately subtracting the contribution owing to gravity to obtain the coordinate acceleration. The unit should be preferably attached close to the CoR, but both type and range of motion do not appear to be critical. When the proposed methodology is correctly implemented, error in the CoR estimates is expected to be <3mm (best estimates=2±0.5mm). The findings of the present study foster the need to further investigate this methodology for application in human subjects.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:24
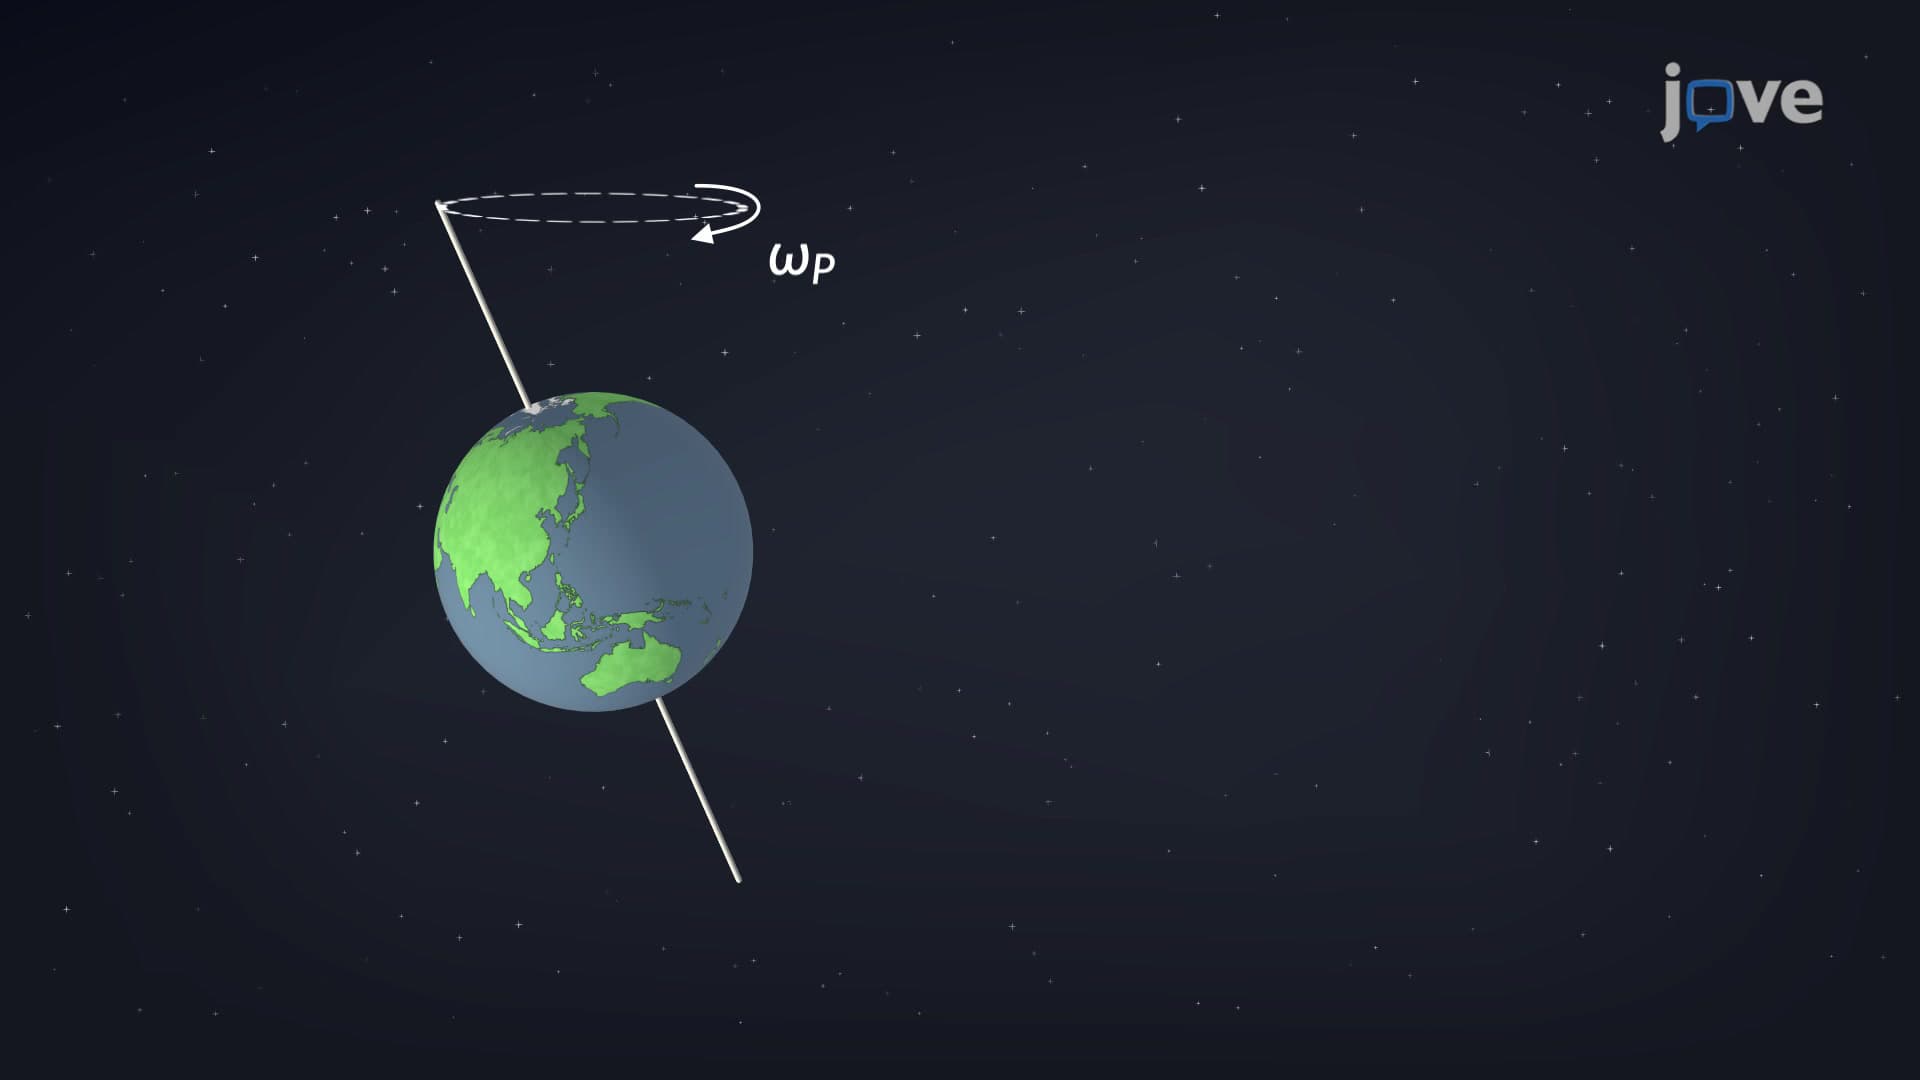
Gyroscope: Precession
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
 01:03
Finding the Center of Gravity
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:02
Gyroscope