Related Experiment Video
Updated: Mar 10, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Verifying the equivalence of representations of the knee joint moment vector from a drop vertical jump task
Julia K Nichols1, Oliver M O'Reilly2
1Department of Mechanical and Aerospace Engineering, University of California at Los Angeles, Los Angeles, CA 90095, USA.

Abstract:
Biomechanics software programs, such as Visual3D, Nexus, Cortex, and OpenSim, have the capability of generating several distinct component representations for joint moments and forces from motion capture data. These representations include those for orthonormal proximal and distal coordinate systems and a non-orthogonal joint coordinate system. In this article, a method is presented to address the challenging problem of evaluating and verifying the equivalence of these representations. The method accommodates the difficulty that there are two possible sets of non-orthogonal basis vectors that can be used to express a vector in the joint coordinate system and is illuminated using motion capture data from a drop vertical jump task.

Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:27
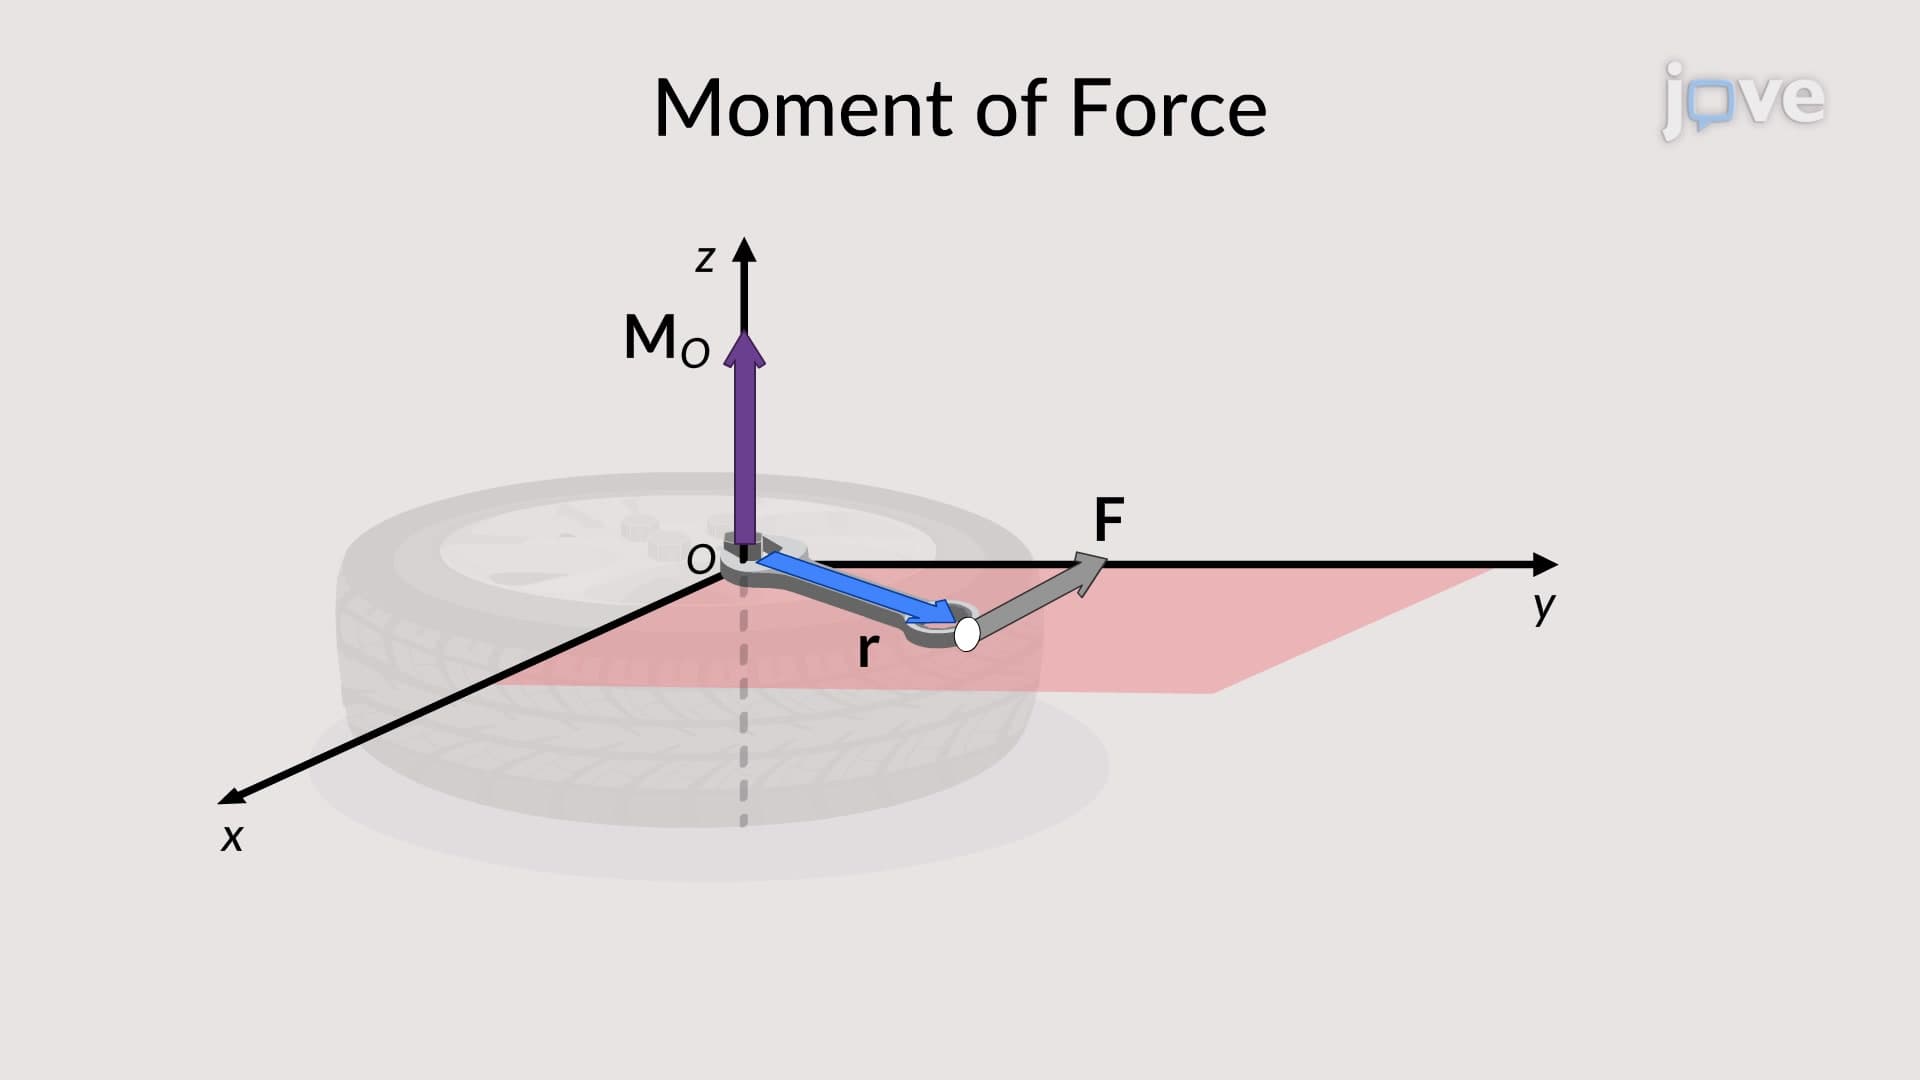
Moment of a Force: Vector Formulation
The vector formulation of the moment of force is the cross-product of the position and force vectors. The...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:21
Relation Between Moment of a Force and Angular Momentum
The temporal...