Related Experiment Video
Updated: Mar 9, 2026
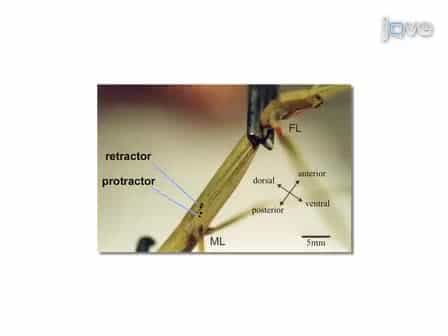
Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
The effect of leg compliance in multi-directional jumping of a flea-inspired mechanism
Gwang-Pil Jung1, Hong-Cheol Choi, Kyu-Jin Cho
1School of Mechanical and Aerospace Engineering/Institute of Advanced Machines and Design, Seoul National University, Seoul 151-742, Republic of Korea.

Abstract:
Inspired by the relationship between leg compliance and jumping performance in the false stick insect, this paper describes how variations in leg compliance and jumping direction affect the performance of a flea-inspired jumping mechanism. The amount of energy lost during jumping was determined by examining the ratio of kinetic energy to input energy (also called conversion efficiency). Leg compliance is modeled based on the compliant mechanics to determine energy transfer during jumping and determined the optimum degree of leg compliance for maximizing performance. Jumping experiments are then performed using six different legs with progressively greater degrees of stiffness and three different jumping directions. The experiments show that conversion efficiency decreases by approximately 3-5% as leg stiffness increases, compared to the optimal case. In the most compliant legs (i.e. stiffness of 0.0338 Nm rad-1 or less), conversion efficiency rapidly drops to near 0% because the leg bends so much that it cannot support the thrusting force. The optimal conversion efficiency tends to increase when the mechanism jumps vertically owing to reduced slippage and increased ground reaction force. These investigations show that optimizing leg compliance can improve the performance of a jumping robot by up to 5% by enabling more of the initially stored energy in the leg to be used. This finding will likely prove helpful for choosing the leg stiffness for a small-scale jumping robot.
More Related Videos
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
 08:04
Fully Automated Leg Tracking in Freely Moving Insects using Feature Learning Leg Segmentation and Tracking FLLIT
Published on: April 23, 2020
Related Concept Videos
 01:16
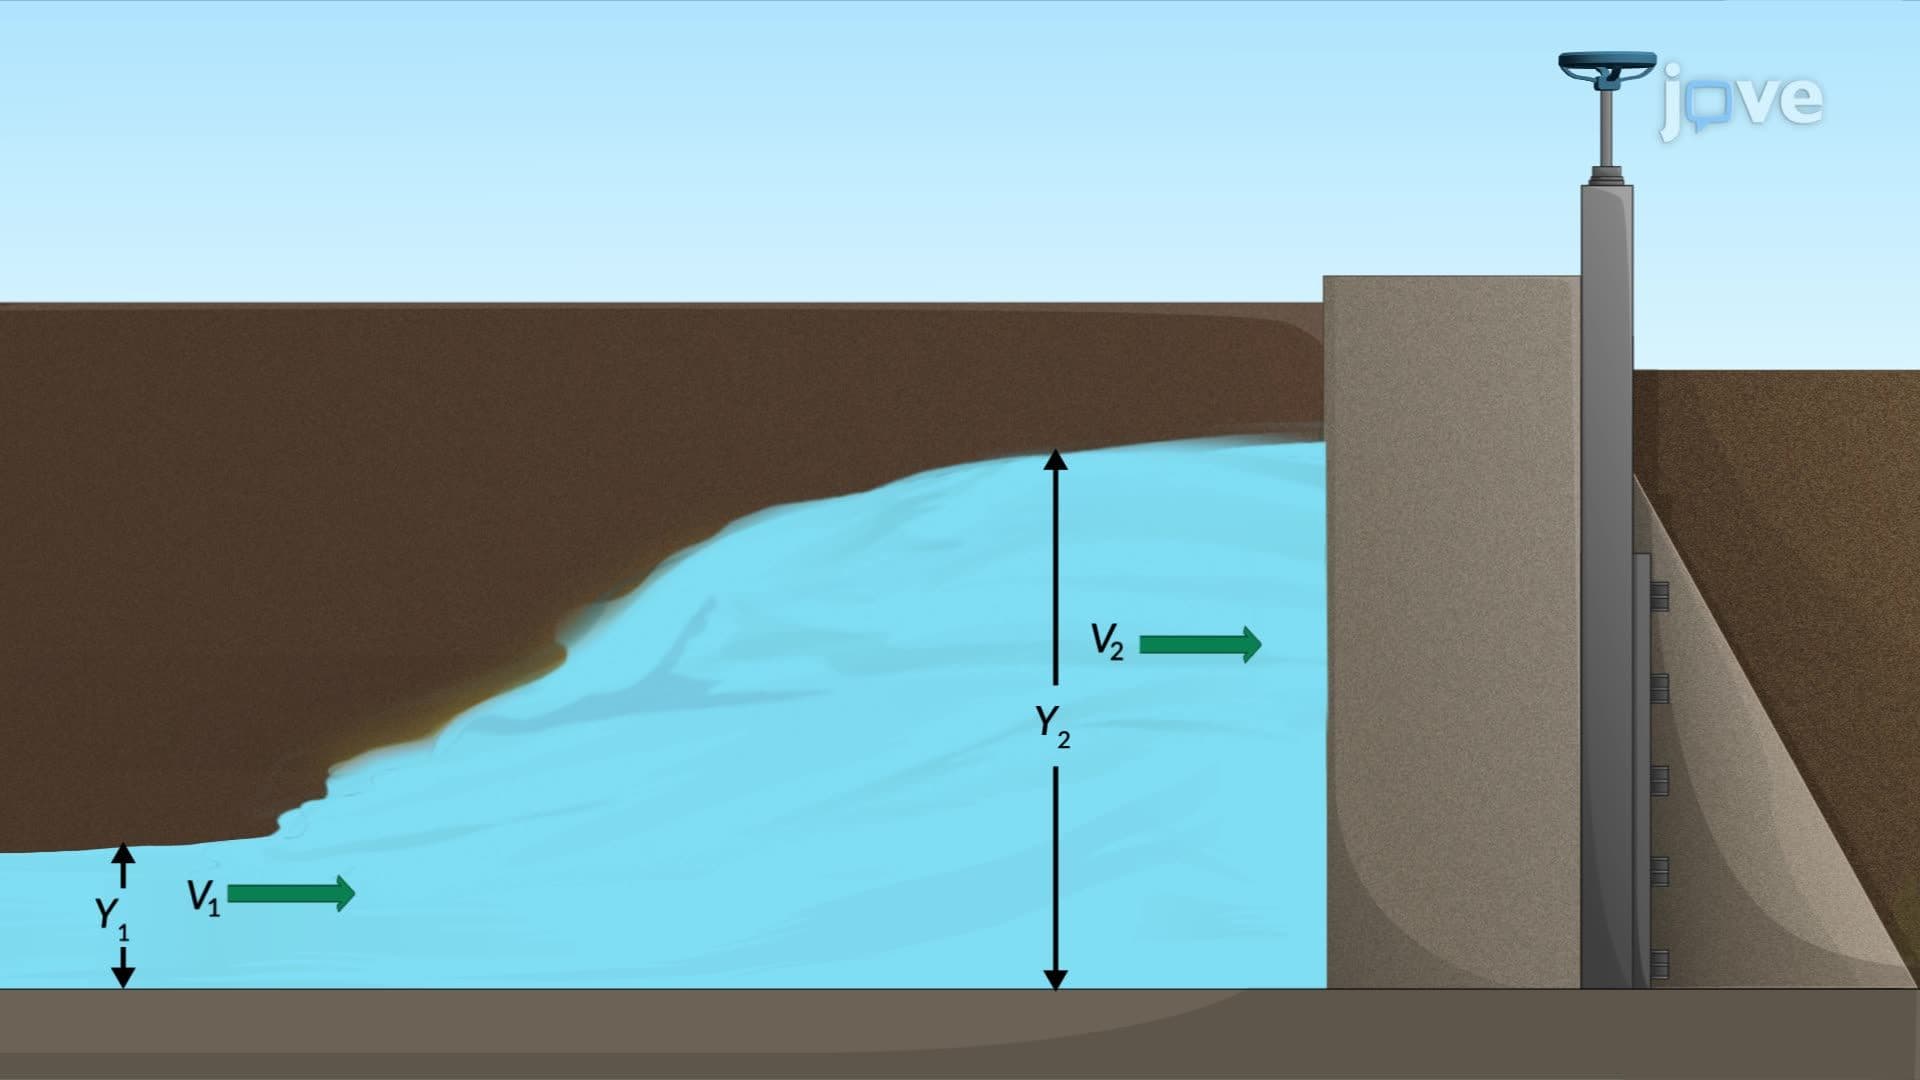
Hydraulic Jump: Problem Solving
 01:05
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:10
Relative Motion Analysis - Acceleration
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...
 01:23
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:23
Principle of Linear Impulse and Momentum for a Single Particle: Problem Solving