An Efficient Globally Optimal Algorithm for Asymmetric Point Matching
Related Experiment Video
Updated: Mar 8, 2026

Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013

Abstract:
Although the robust point matching algorithm has been demonstrated to be effective for non-rigid registration, there are several issues with the adopted deterministic annealing optimization technique. First, it is not globally optimal and regularization on the spatial transformation is needed for good matching results. Second, it tends to align the mass centers of two point sets. To address these issues, we propose a globally optimal algorithm for the robust point matching problem in the case that each model point has a counterpart in scene set. By eliminating the transformation variables, we show that the original matching problem is reduced to a concave quadratic assignment problem where the objective function has a low rank Hessian matrix. This facilitates the use of large scale global optimization techniques. We propose a modified normal rectangular branch-and-bound algorithm to solve the resulting problem where multiple rectangles are simultaneously subdivided to increase the chance of shrinking the rectangle containing the global optimal solution. In addition, we present an efficient lower bounding scheme which has a linear assignment formulation and can be efficiently solved. Extensive experiments on synthetic and real datasets demonstrate the proposed algorithm performs favorably against the state-of-the-art methods in terms of robustness to outliers, matching accuracy, and run-time.


Related Concept Videos
 01:24
The Midpoint Formula
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:11
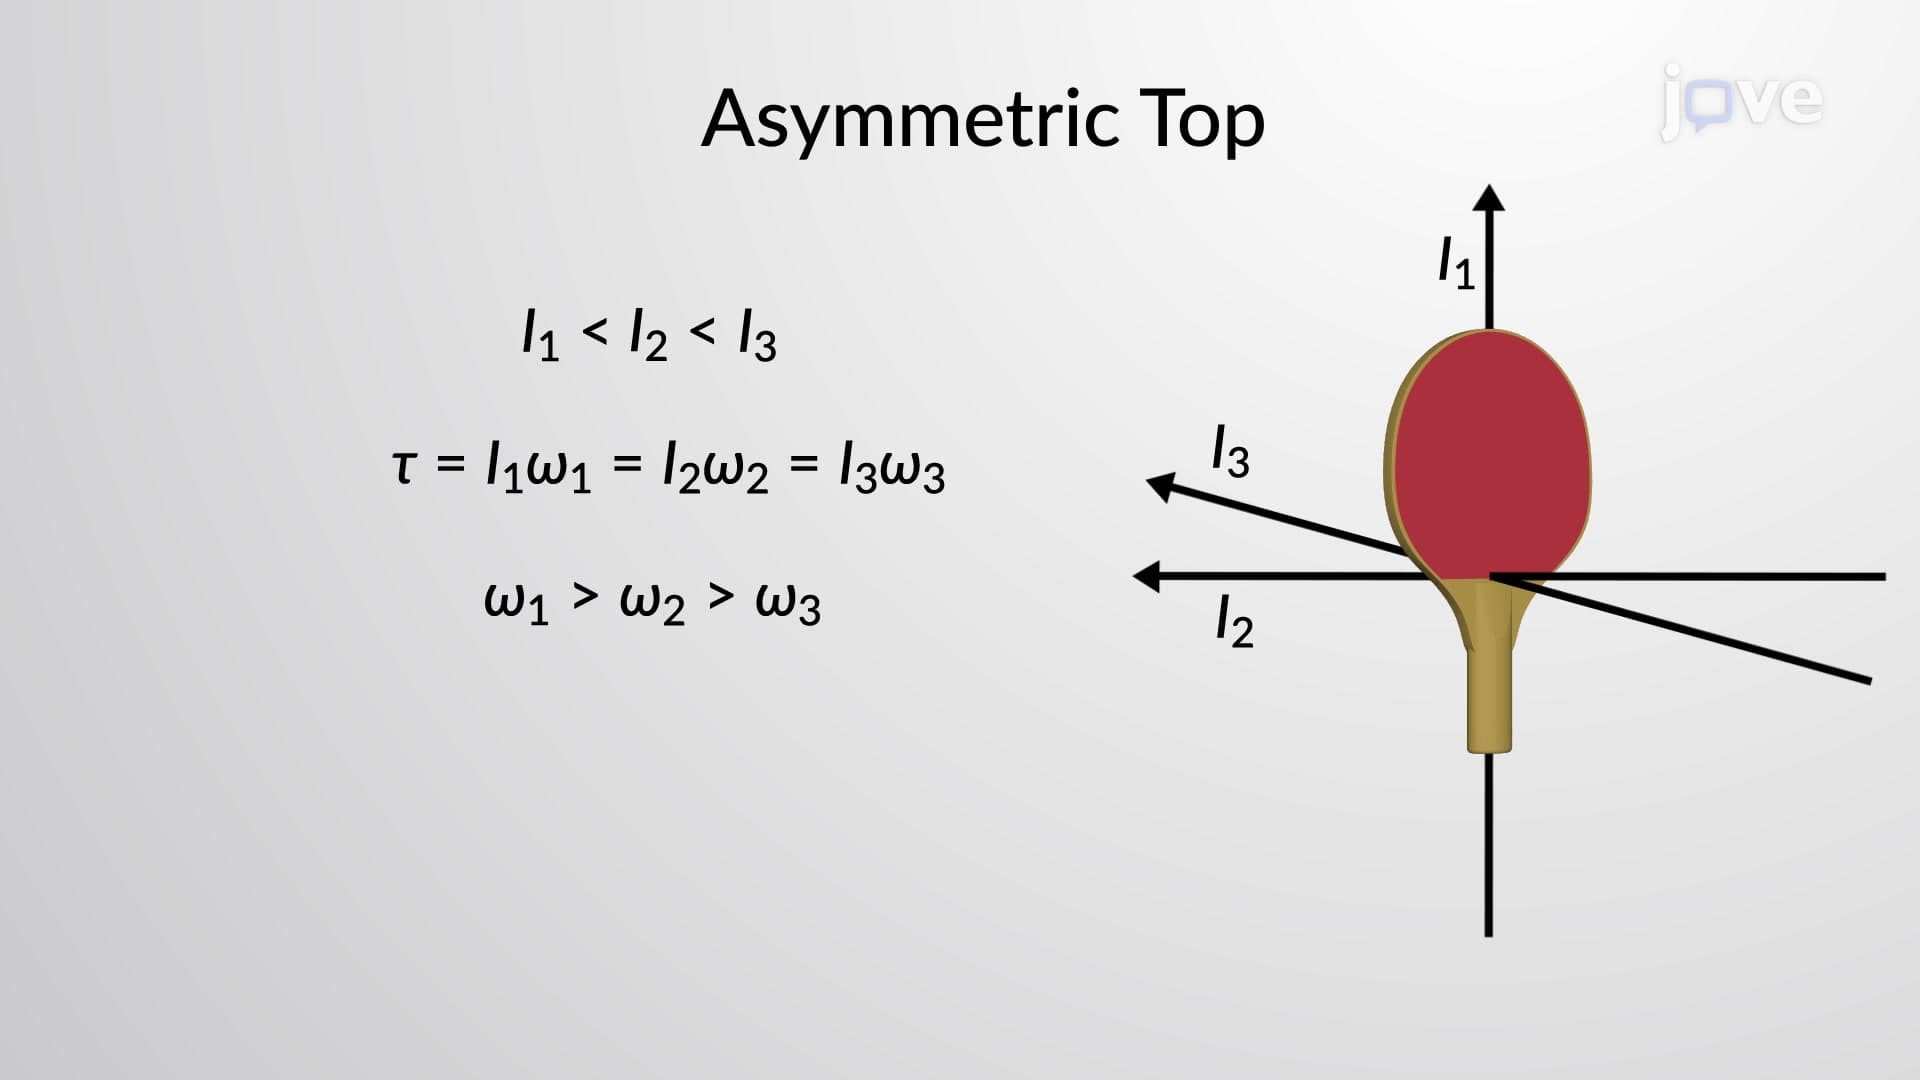
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:19
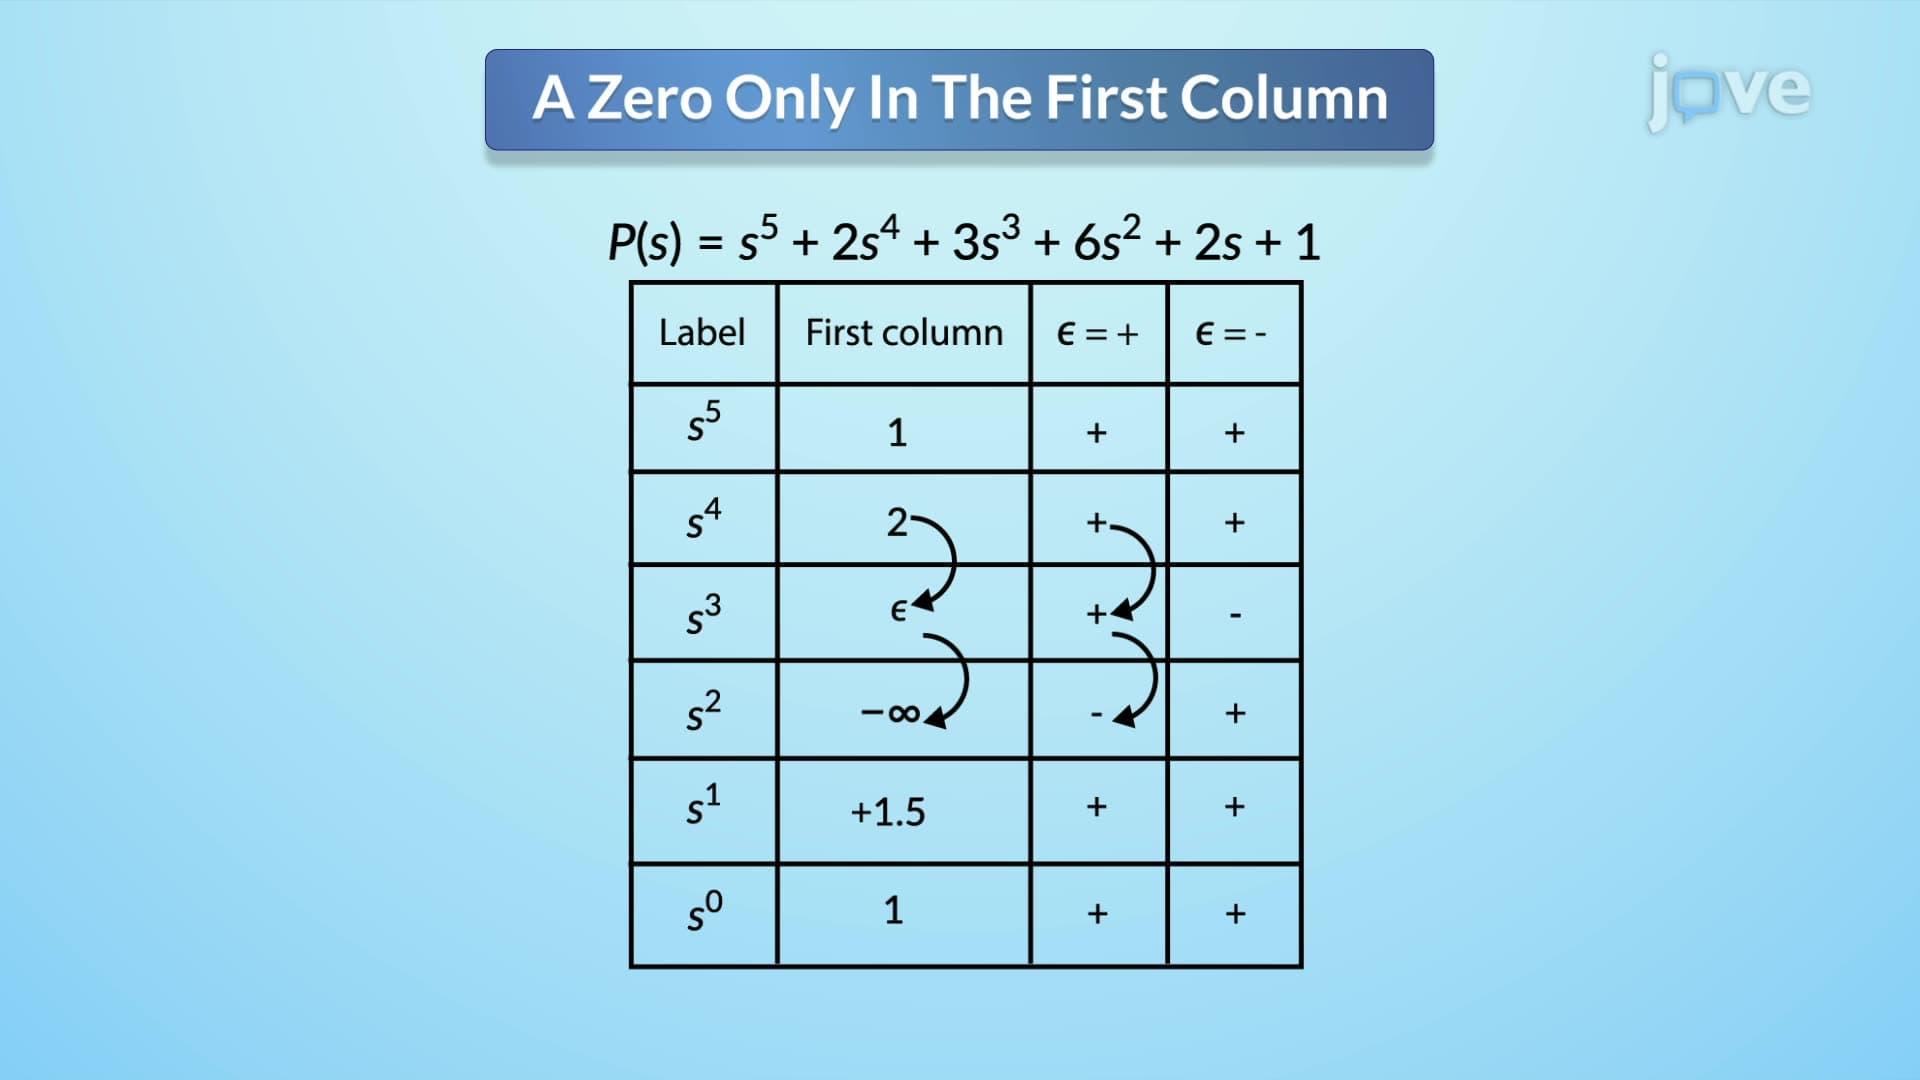
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 00:48
Optimal Foraging
 01:15
Routh-Hurwitz Criterion I
To apply the Routh-Hurwitz criterion, a Routh table is constructed. The table's rows are labeled with powers of the complex frequency variable s, starting from the...