Related Experiment Video
Updated: Mar 8, 2026
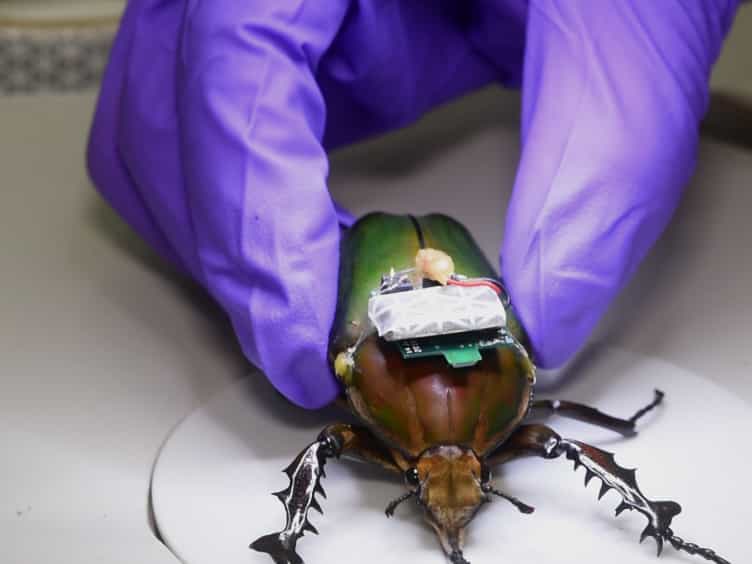

Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Dynamics and flight control of a flapping-wing robotic insect in the presence of wind gusts
Pakpong Chirarattananon1, Yufeng Chen2, E Farrell Helbling2
1Department of Mechanical and Biomedical Engineering , City University of Hong Kong , Hong Kong.

Abstract:
With the goal of operating a biologically inspired robot autonomously outside of laboratory conditions, in this paper, we simulated wind disturbances in a laboratory setting and investigated the effects of gusts on the flight dynamics of a millimetre-scale flapping-wing robot. Simplified models describing the disturbance effects on the robot's dynamics are proposed, together with two disturbance rejection schemes capable of estimating and compensating for the disturbances. The proposed methods are experimentally verified. The results show that these strategies reduced the root-mean-square position errors by more than 50% when the robot was subject to 80 cm s-1 horizontal wind. The analysis of flight data suggests that modulation of wing kinematics to stabilize the flight in the presence of wind gusts may indirectly contribute an additional stabilizing effect, reducing the time-averaged aerodynamic drag experienced by the robot. A benchtop experiment was performed to provide further support for this observed phenomenon.

Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:05
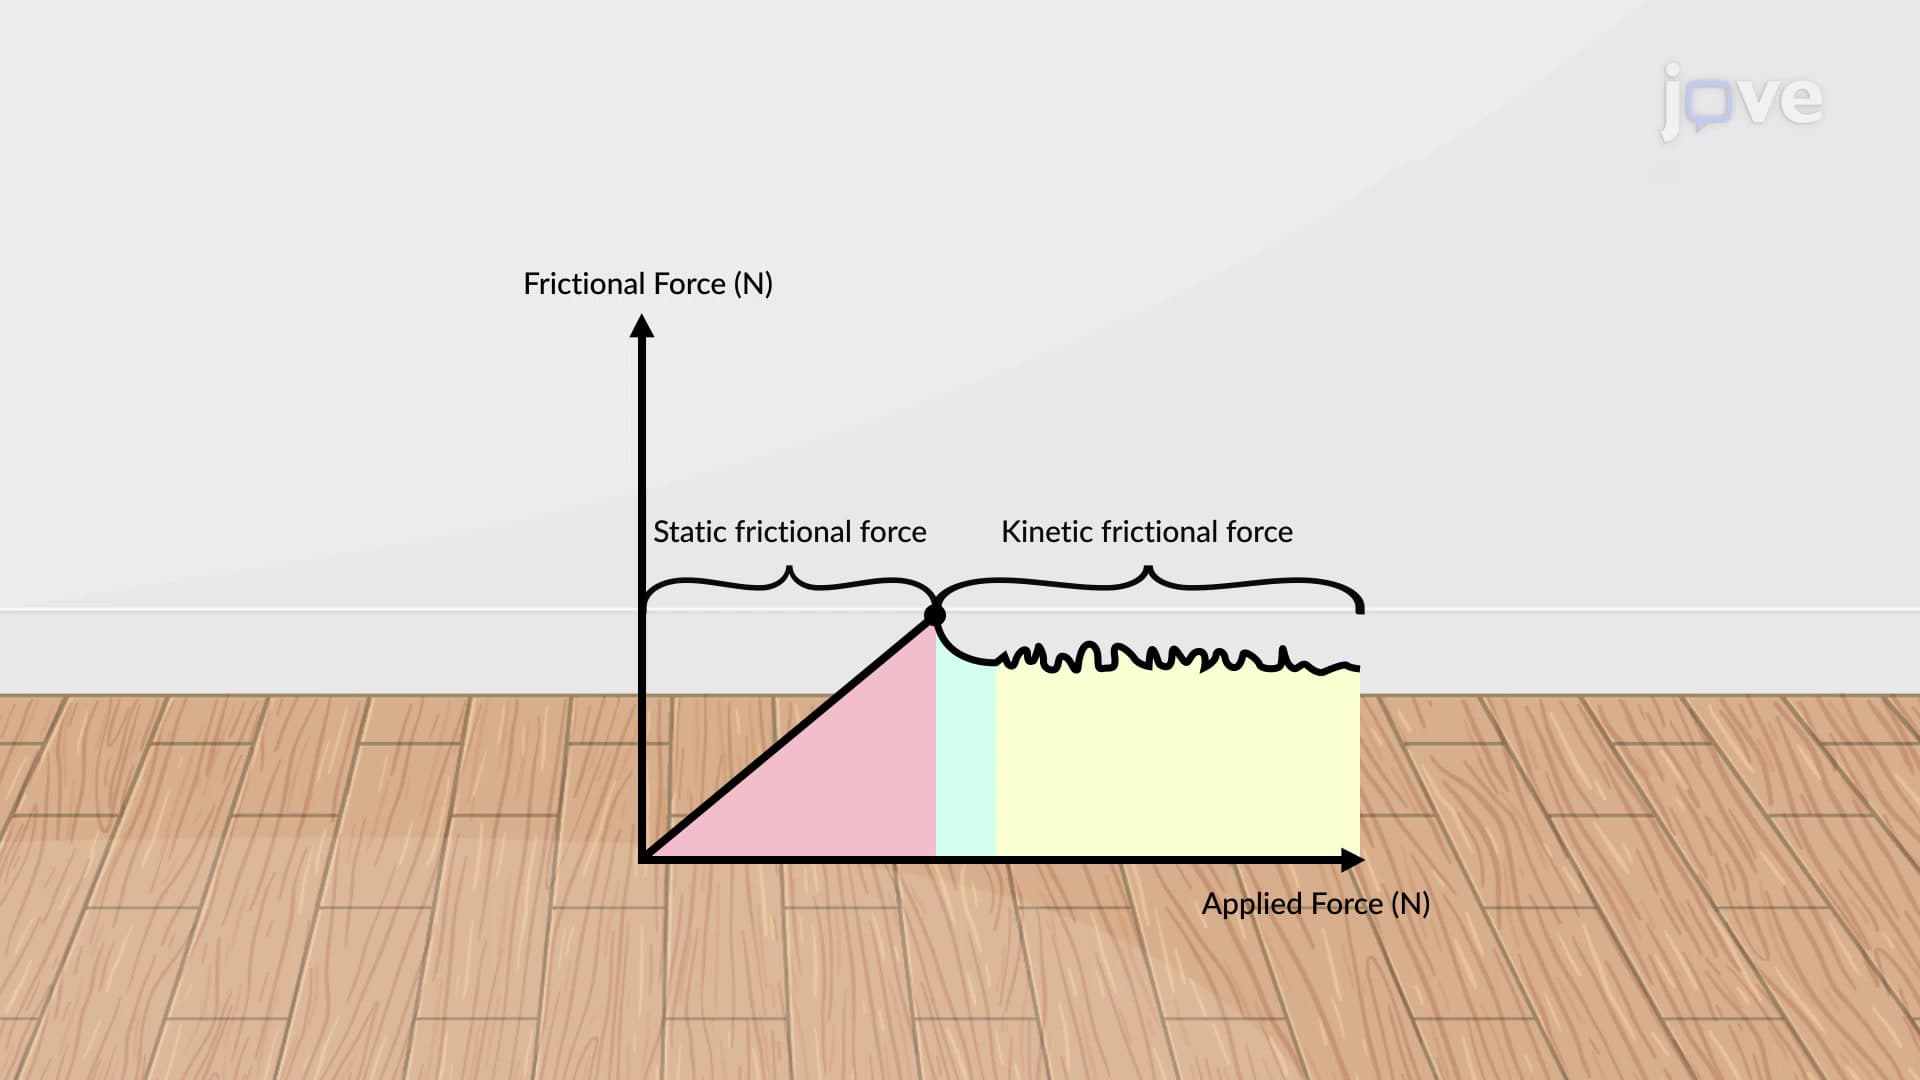
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:23
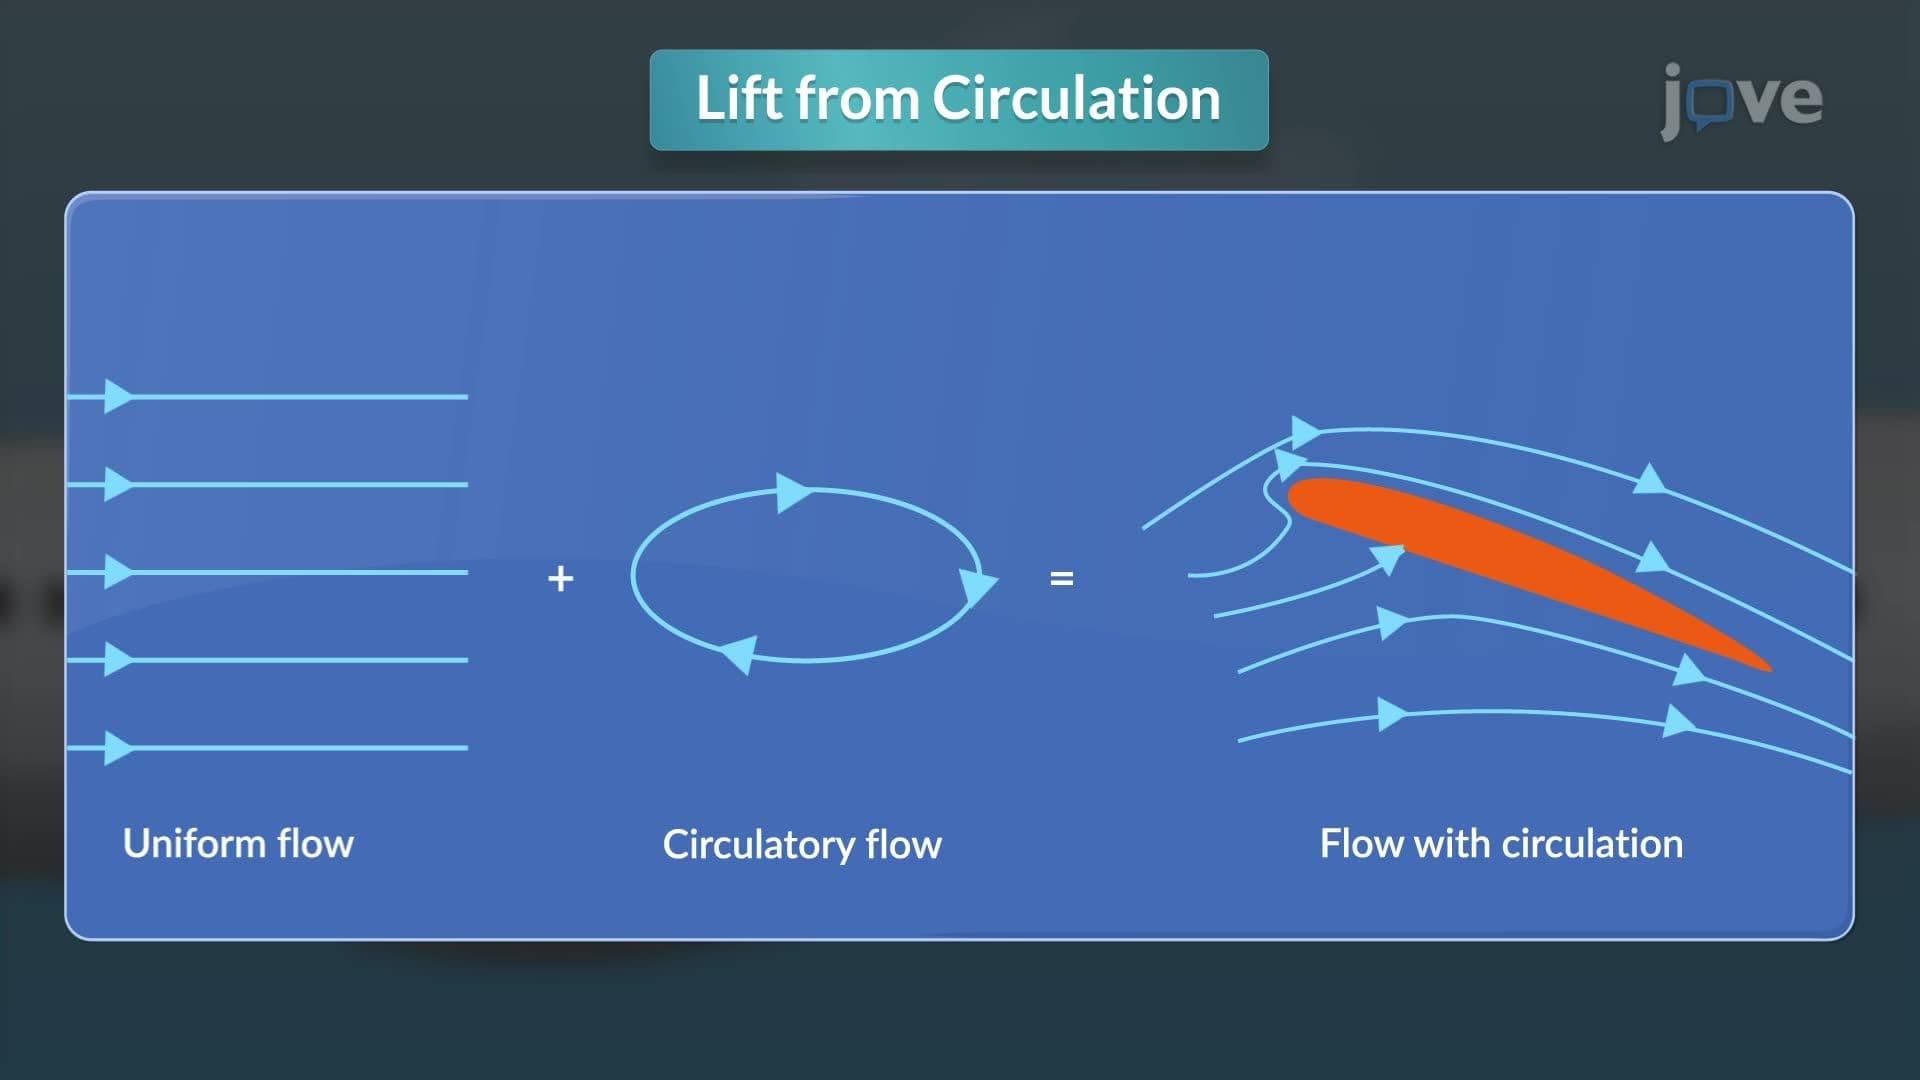
Lift
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Dynamics Of Circular Motion: Applications