Related Experiment Video
Updated: Mar 7, 2026


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Weight compensation characteristics of Armeo®Spring exoskeleton: implications for clinical practice and research
Bonnie E Perry1, Emily K Evans1, Dobrivoje S Stokic2
1Center for Neuroscience and Neurological Recovery, Methodist Rehabilitation Center, 1350 East Woodrow Wilson Drive, Jackson, MS, 39216, USA.

Background:
Armeo®Spring exoskeleton is widely used for upper extremity rehabilitation; however, weight compensation provided by the device appears insufficiently characterized to fully utilize it in clinical and research settings.
Methods:
Weight compensation was quantified by measuring static force in the sagittal plane with a load cell attached to the elbow joint of Armeo®Spring. All upper spring settings were examined in 5° increments at the minimum, maximum, and two intermediate upper and lower module length settings, while keeping the lower spring at minimum. The same measurements were made for minimum upper spring setting and maximum lower spring setting at minimum and maximum module lengths. Weight compensation was plotted against upper module angles, and slope was analyzed for each condition.
Results:
The Armeo®Spring design prompted defining the slack angle and exoskeleton balance angle, which, depending on spring and length settings, divide the operating range into different unloading and loading regions. Higher spring tensions and shorter module lengths provided greater unloading (≤6.32 kg of support). Weight compensation slope decreased faster with shorter length settings (minimum length = -0.082 ± 0.002 kg/°; maximum length = -0.046 ± 0.001 kg/°) independent of spring settings.
Conclusions:
Understanding the impact of different settings on the Armeo®Spring weight compensation should help define best clinical practice and improve fidelity of research.
More Related Videos
 06:00
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
 05:54
Mimicking a Space Mission to Mars Using Hindlimb Unloading and Partial Weight Bearing in Rats
Published on: April 4, 2019
Related Concept Videos
 01:23
Euler's Formula to Columns: Problem Solving
The system comprises two vertical rigid bars, AB and BC, of...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:19
Mass and Weight
 01:13
Principle of Virtual Work: Problem Solving
To apply the principle of virtual work,...
 01:10
Work and Energy for Variable Forces
 01:20
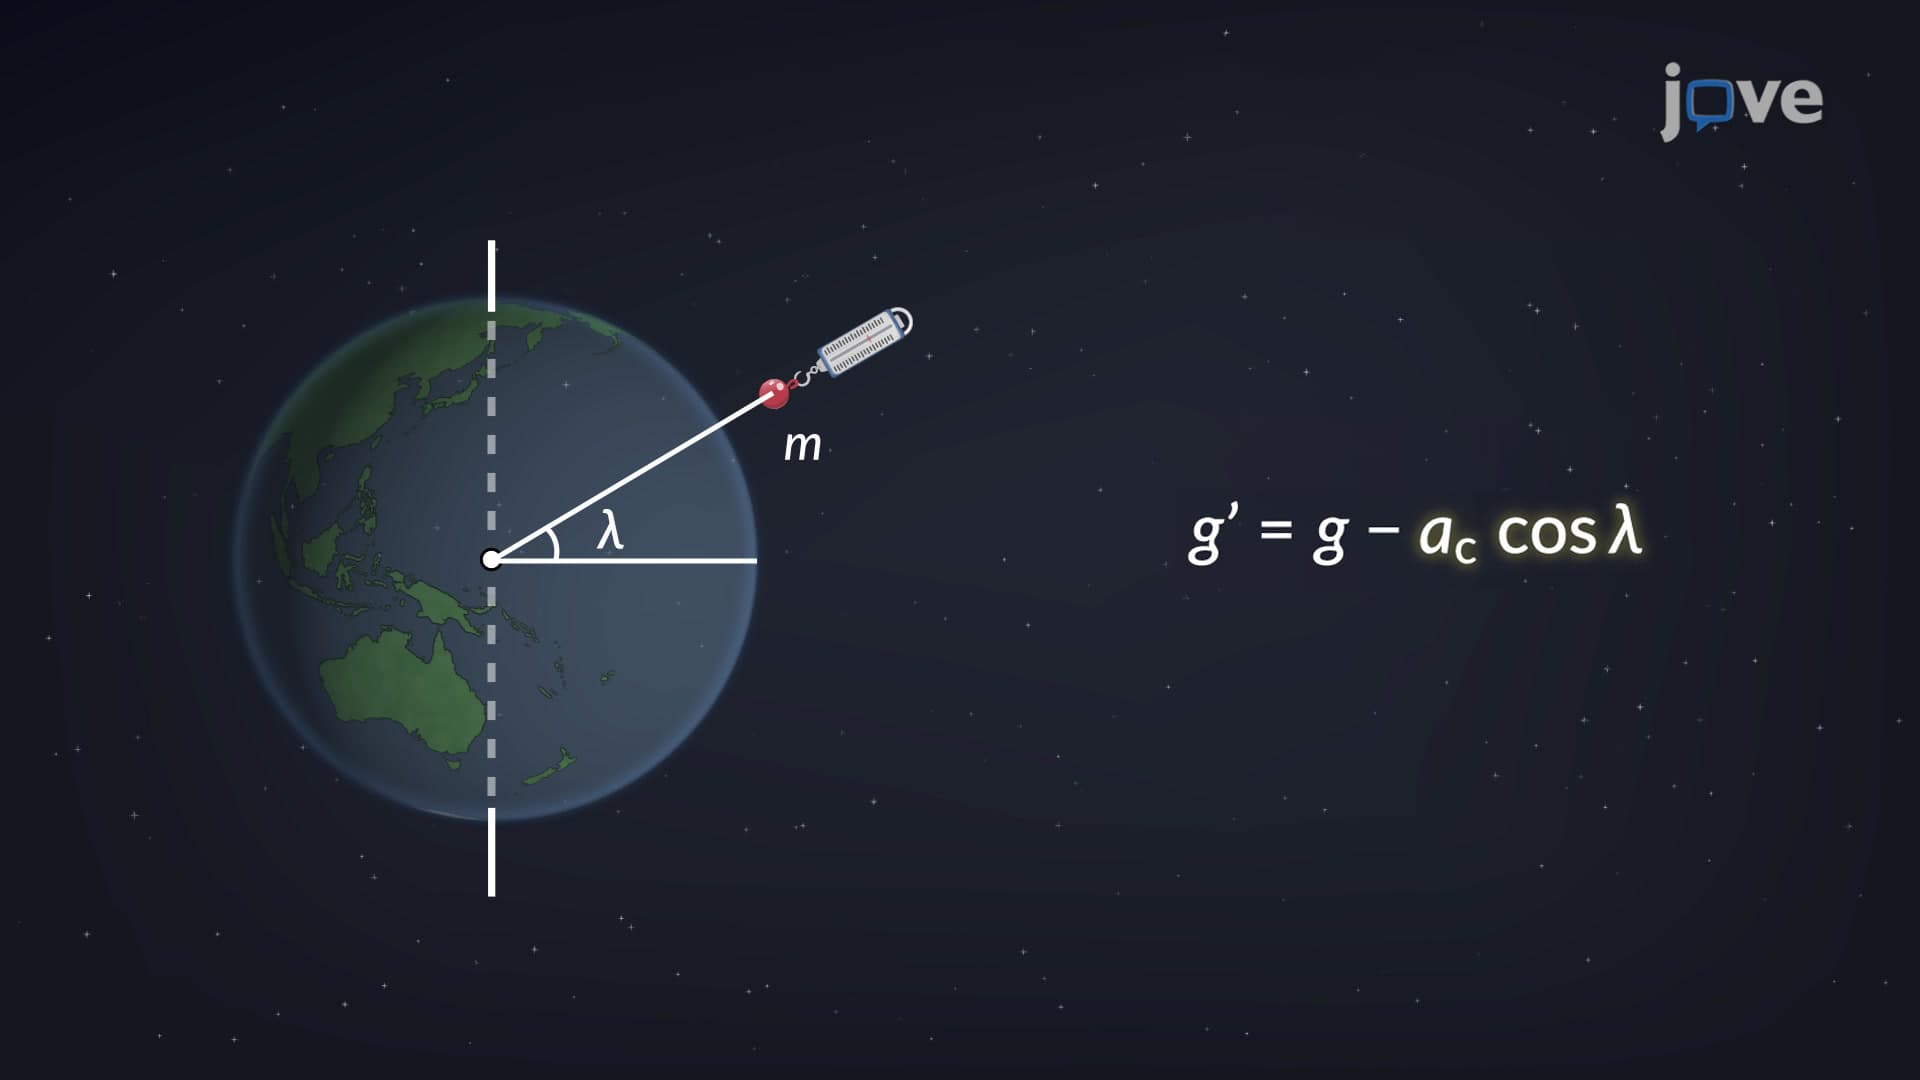
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's...