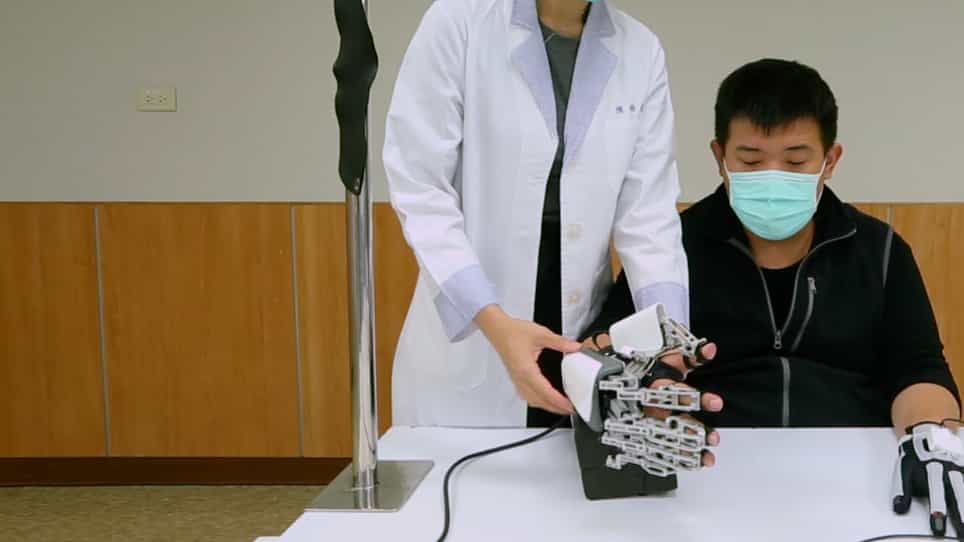
Related Experiment Video
Updated: Mar 6, 2026

Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
Robust Control of a Cable-Driven Soft Exoskeleton Joint for Intrinsic Human-Robot Interaction

Abstract:
A novel, cable-driven soft joint is presented for use in robotic rehabilitation exoskeletons to provide intrinsic, comfortable human-robot interaction. The torque-displacement characteristics of the soft elastomeric core contained within the joint are modeled. This knowledge is used in conjunction with a dynamic system model to derive a sliding mode controller (SMC) to implement low-level torque control of the joint. The SMC controller is experimentally compared with a baseline feedback-linearised proportional-derivative controller across a range of conditions and shown to be robust to un-modeled disturbances. The torque controller is then tested with six healthy subjects while they perform a selection of activities of daily living, which has validated its range of performance. Finally, a case study with a participant with spastic cerebral palsy is presented to illustrate the potential of both the joint and controller to be used in a physiotherapy setting to assist clinical populations.