Related Experiment Video
Updated: Feb 2, 2026
Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
Comparing Physical Human-Robot Interaction with Spring-and Elastomer-Based Series Elastic Actuators

Abstract:
Physical human-robot interaction (pHRI) is an important consideration in the design of rehabilitation exoskeletons. Series Elastic Actuators (SEAs) are seen as a promising method of introducing compliance and comfort to robotic exoskeletons. Recently, authors have proposed the use of elastomers in SEAs, rather than springs, but there is a dearth of literature comparing how the two compliant elements are perceived by humans. In this paper, we quantitatively and qualitatively compare human interaction with an elastomer and a spring in terms of comfort and motion smoothness, with the aim of informing future SEA design. Two mechanisms were designed to compare human interaction with a spring and elastomer, and a cross-over experimental design was used to help eliminate any learning effects. Overall, the elastomer appeared to be slightly more comfortable and allow slightly smoother motion than the spring, holding promise for the use of elastomers as a means of improving pHRI in exoskeletons actuated by SEAs.
Related Concept Videos
 01:17
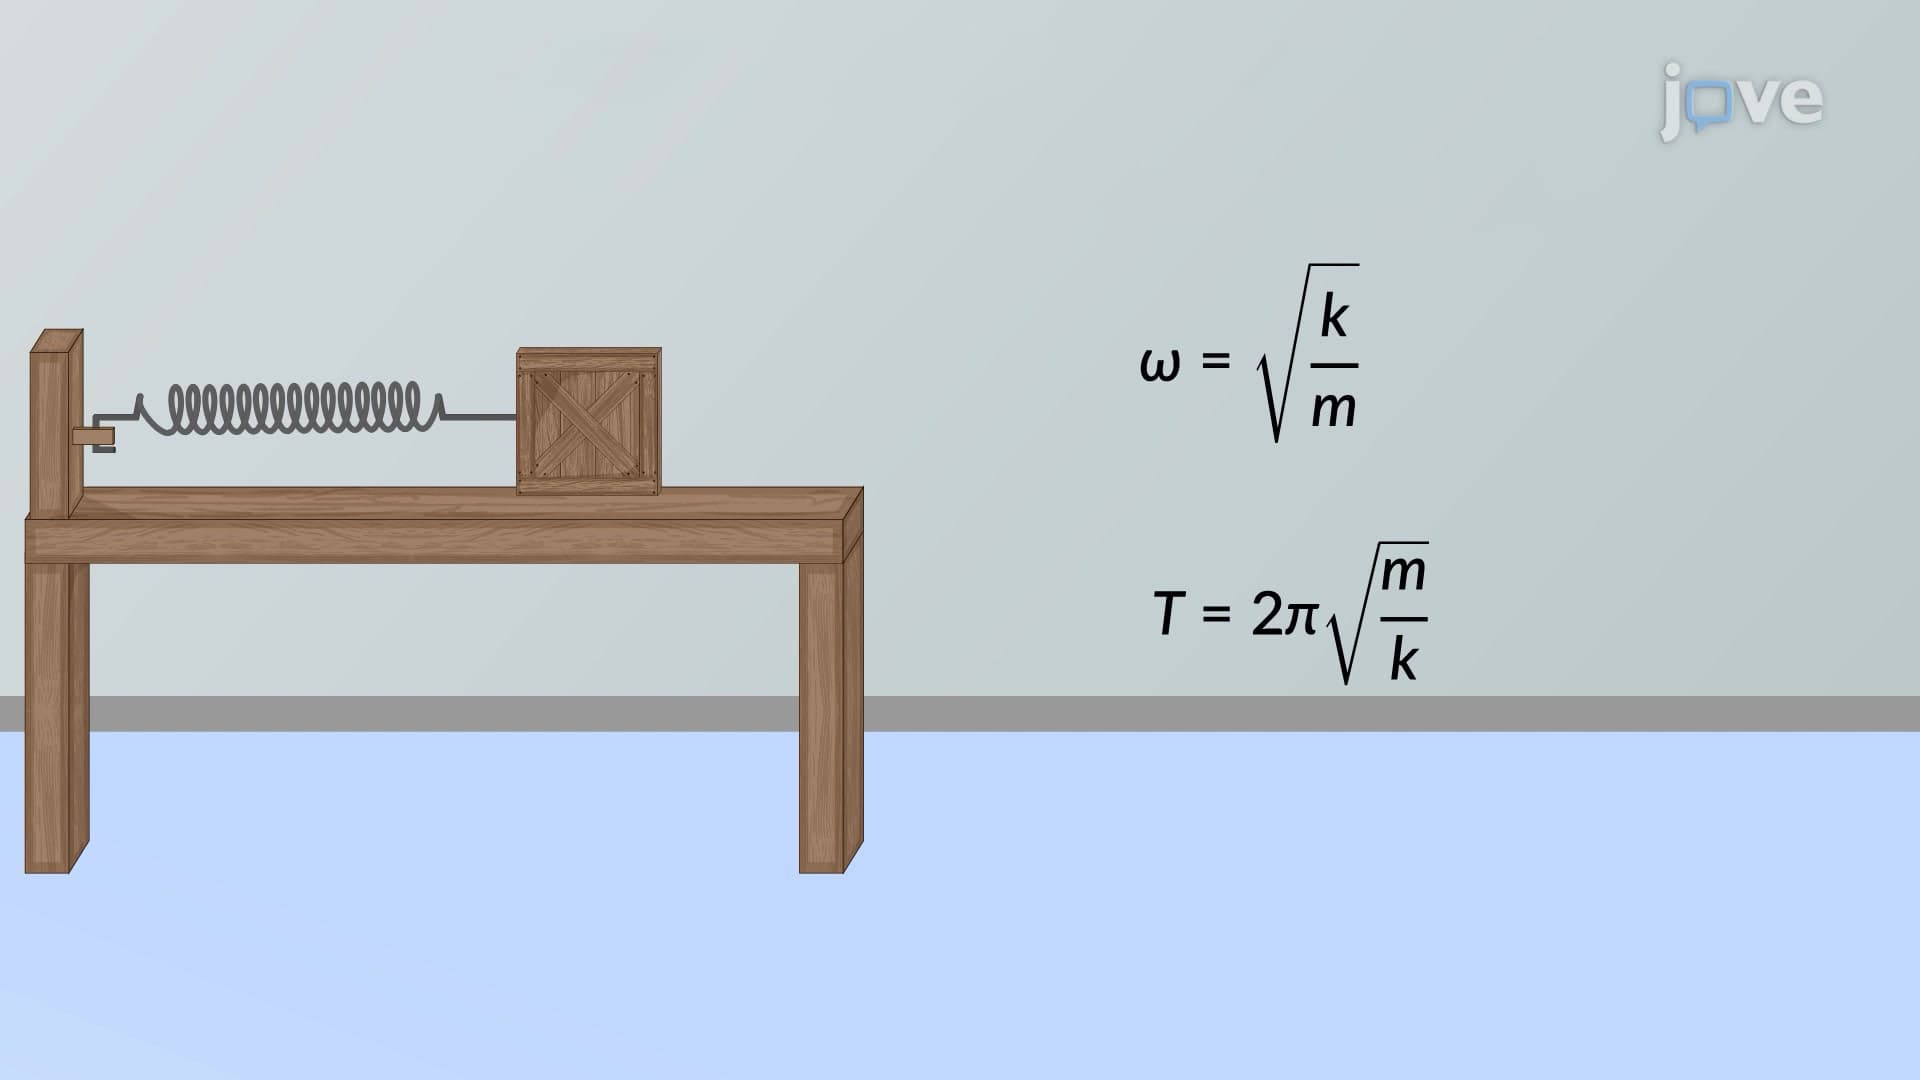
Frequency of Spring-Mass System
Consider a block on a spring on a frictionless surface. There...
 02:57
Physical and Chemical Properties of Matter
 01:12
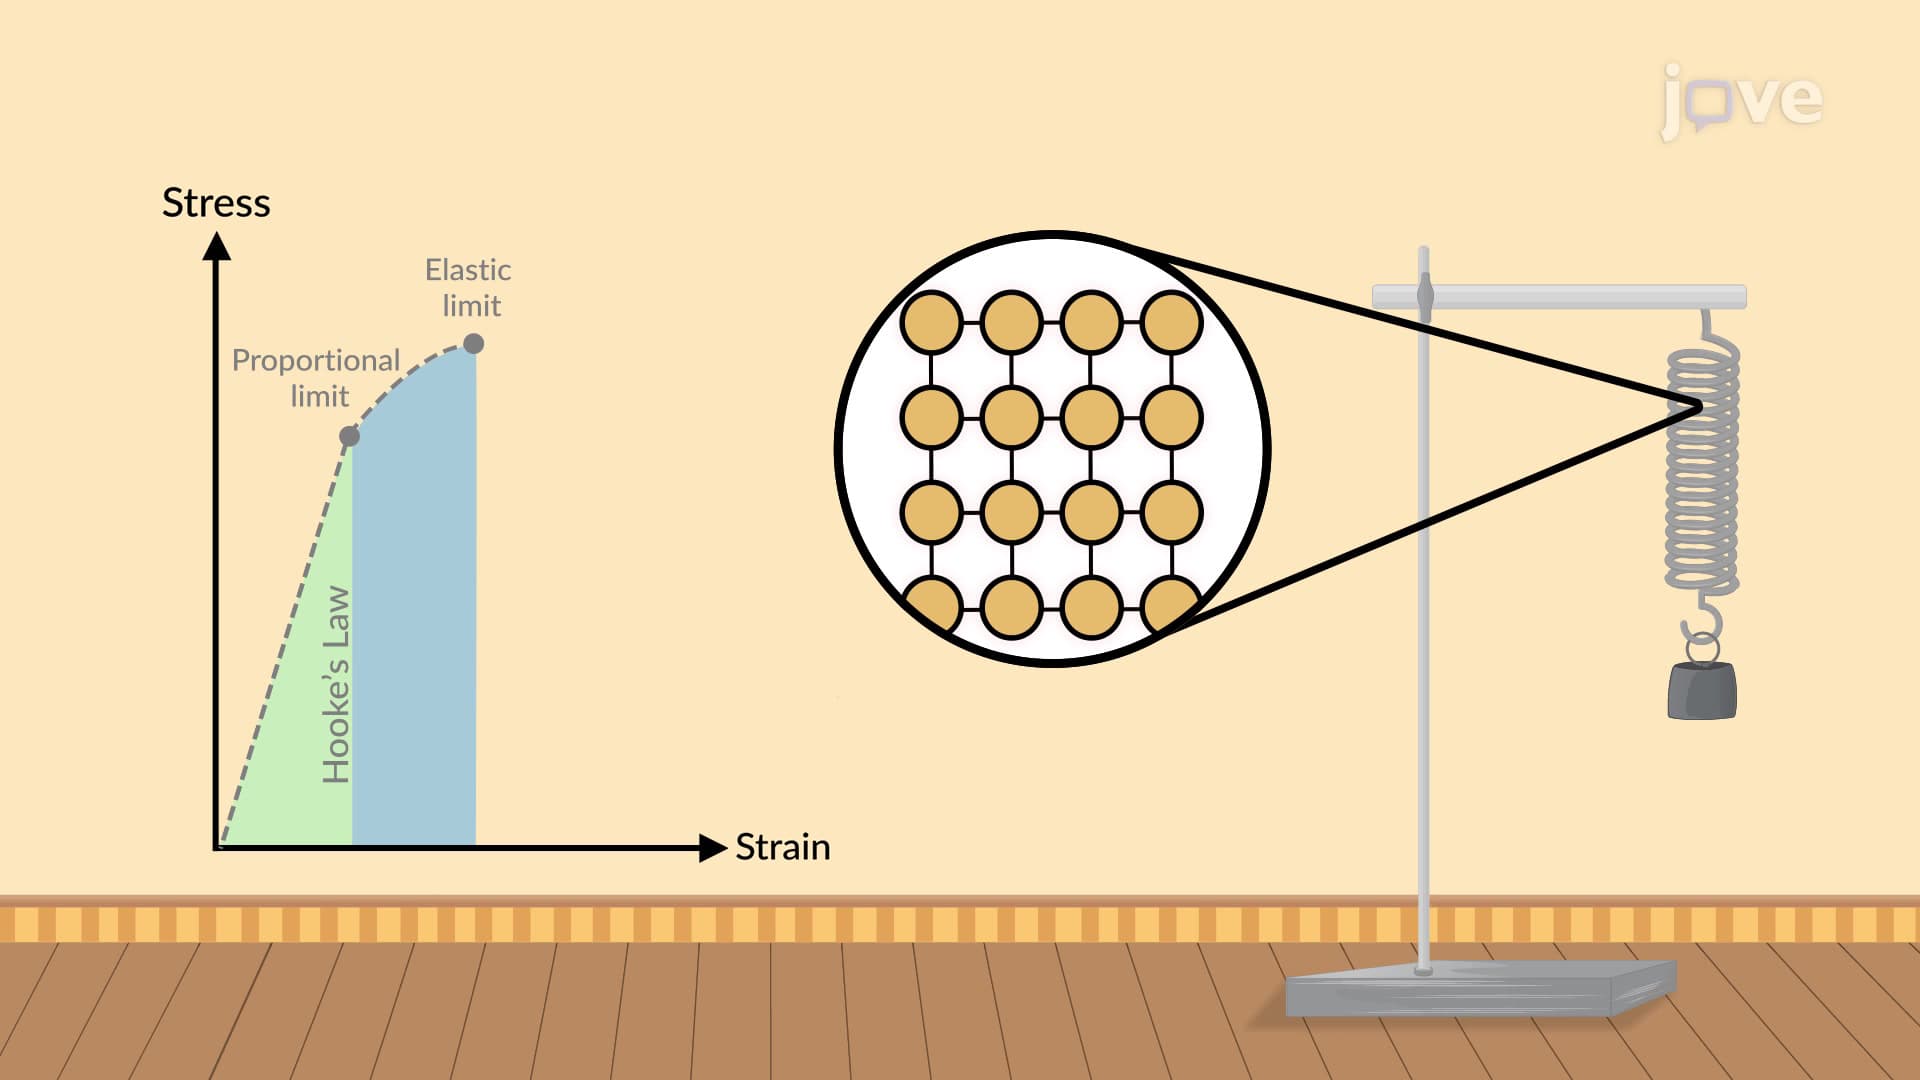
Elasticity
The elasticity of an object can be described by a stress-strain curve, which represents the relationship between stress...
 01:10
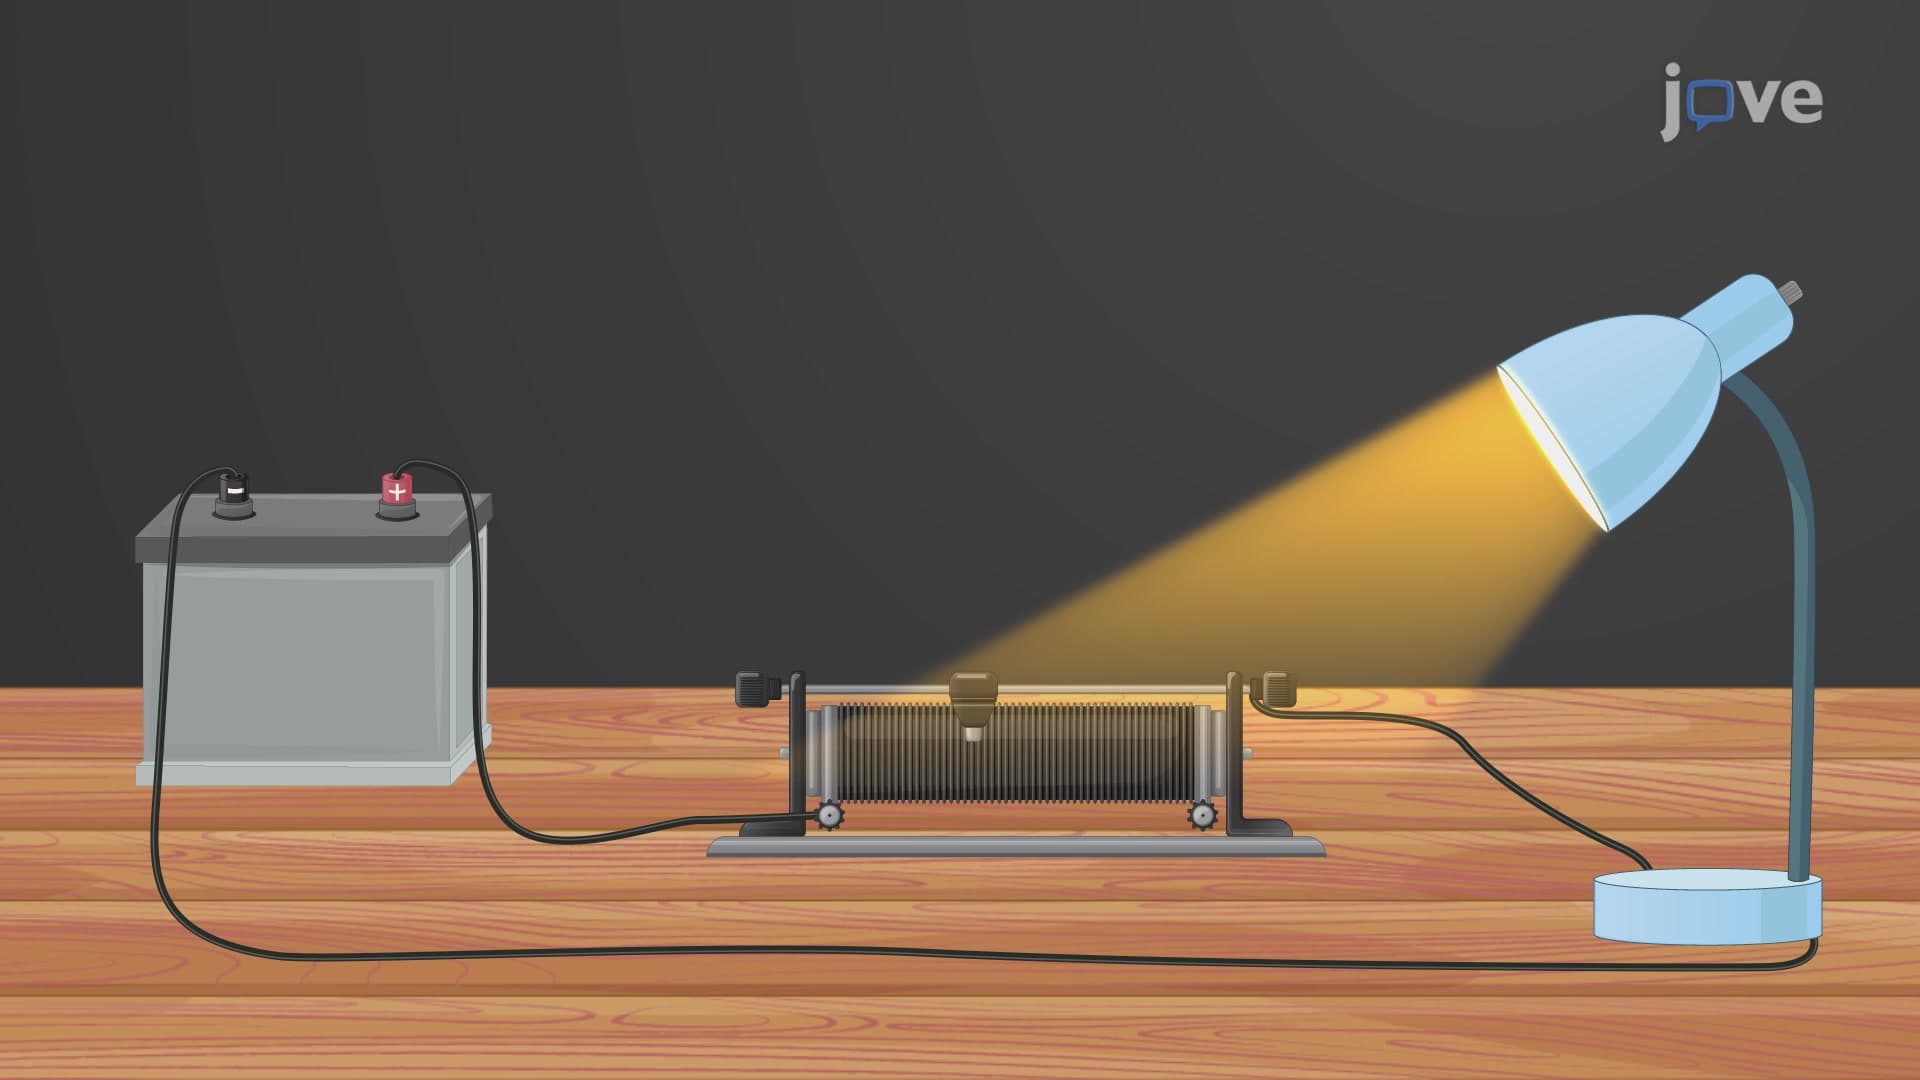
Resistors In Series
In a series circuit, the...
 01:20
Elasticity in Concrete
 02:34
Comparing Intermolecular Forces: Melting Point, Boiling Point, and Miscibility
Temporary attractive forces like dispersion are present in all molecules, whether they are polar or nonpolar. They...