Related Experiment Video
Updated: Mar 6, 2026
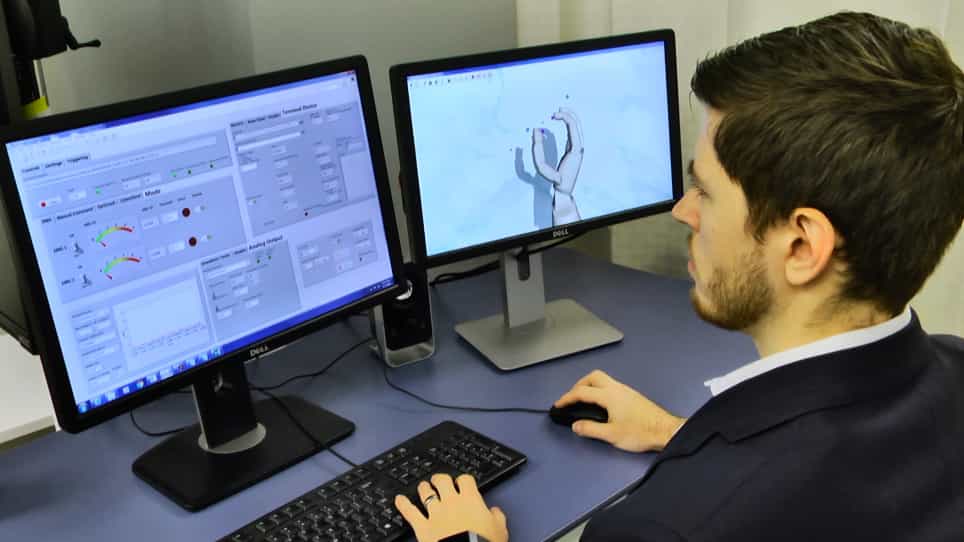

Characterization of the Sense of Agency over the Actions of Neural-machine Interface-operated Prostheses
Published on: January 7, 2019
Adaptation to random and systematic errors: Comparison of amputee and non-amputee control interfaces with varying
Reva E Johnson1, Konrad P Kording2,3,4, Levi J Hargrove2,3
1Department of Mechanical Engineering, Valparaiso University, Valparaiso, Indiana, United States of America.

Abstract:
The objective of this study was to understand how people adapt to errors when using a myoelectric control interface. We compared adaptation across 1) non-amputee subjects using joint angle, joint torque, and myoelectric control interfaces, and 2) amputee subjects using myoelectric control interfaces with residual and intact limbs (five total control interface conditions). We measured trial-by-trial adaptation to self-generated errors and random perturbations during a virtual, single degree-of-freedom task with two levels of feedback uncertainty, and evaluated adaptation by fitting a hierarchical Kalman filter model. We have two main results. First, adaptation to random perturbations was similar across all control interfaces, whereas adaptation to self-generated errors differed. These patterns matched predictions of our model, which was fit to each control interface by changing the process noise parameter that represented system variability. Second, in amputee subjects, we found similar adaptation rates and error levels between residual and intact limbs. These results link prosthesis control to broader areas of motor learning and adaptation and provide a useful model of adaptation with myoelectric control. The model of adaptation will help us understand and solve prosthesis control challenges, such as providing additional sensory feedback.
More Related Videos
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Related Concept Videos
 01:20
Random and Systematic Errors
 03:37
Uncertainty in Measurement: Accuracy and Precision
 01:10
Control Systems
At the heart...
 01:15
Systematic Error: Methodological and Sampling Errors
Sampling errors originate from improper sampling methods or the wrong sample population. These errors can be minimized by refining the sampling strategy. Defective instruments or faulty calibrations are the sources of instrumental...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...