Related Experiment Video
Updated: Mar 6, 2026

Computational Modeling of Retinal Neurons for Visual Prosthesis Research - Fundamental Approaches
Published on: June 21, 2022
Simplification of Visual Rendering in Simulated Prosthetic Vision Facilitates Navigation
Victor Vergnieux1, Marc J-M Macé1, Christophe Jouffrais1
1Université de Toulouse and CNRS, IRIT, UMR5505, Toulouse, France.

Abstract:
Visual neuroprostheses are still limited and simulated prosthetic vision (SPV) is used to evaluate potential and forthcoming functionality of these implants. SPV has been used to evaluate the minimum requirement on visual neuroprosthetic characteristics to restore various functions such as reading, objects and face recognition, object grasping, etc. Some of these studies focused on obstacle avoidance but only a few investigated orientation or navigation abilities with prosthetic vision. The resolution of current arrays of electrodes is not sufficient to allow navigation tasks without additional processing of the visual input. In this study, we simulated a low resolution array (15 × 18 electrodes, similar to a forthcoming generation of arrays) and evaluated the navigation abilities restored when visual information was processed with various computer vision algorithms to enhance the visual rendering. Three main visual rendering strategies were compared to a control rendering in a wayfinding task within an unknown environment. The control rendering corresponded to a resizing of the original image onto the electrode array size, according to the average brightness of the pixels. In the first rendering strategy, vision distance was limited to 3, 6, or 9 m, respectively. In the second strategy, the rendering was not based on the brightness of the image pixels, but on the distance between the user and the elements in the field of view. In the last rendering strategy, only the edges of the environments were displayed, similar to a wireframe rendering. All the tested renderings, except the 3 m limitation of the viewing distance, improved navigation performance and decreased cognitive load. Interestingly, the distance-based and wireframe renderings also improved the cognitive mapping of the unknown environment. These results show that low resolution implants are usable for wayfinding if specific computer vision algorithms are used to select and display appropriate information regarding the environment.
More Related Videos
 07:12
Development of a Gaze-Contingent Display Framework Designed for Perceptual and Oculomotor Research with Simulated Central Vision Loss
Published on: April 11, 2025
 07:09
Integrating Visual Psychophysical Assays within a Y-Maze to Isolate the Role that Visual Features Play in Navigational Decisions
Published on: May 2, 2019
Related Concept Videos
 01:26
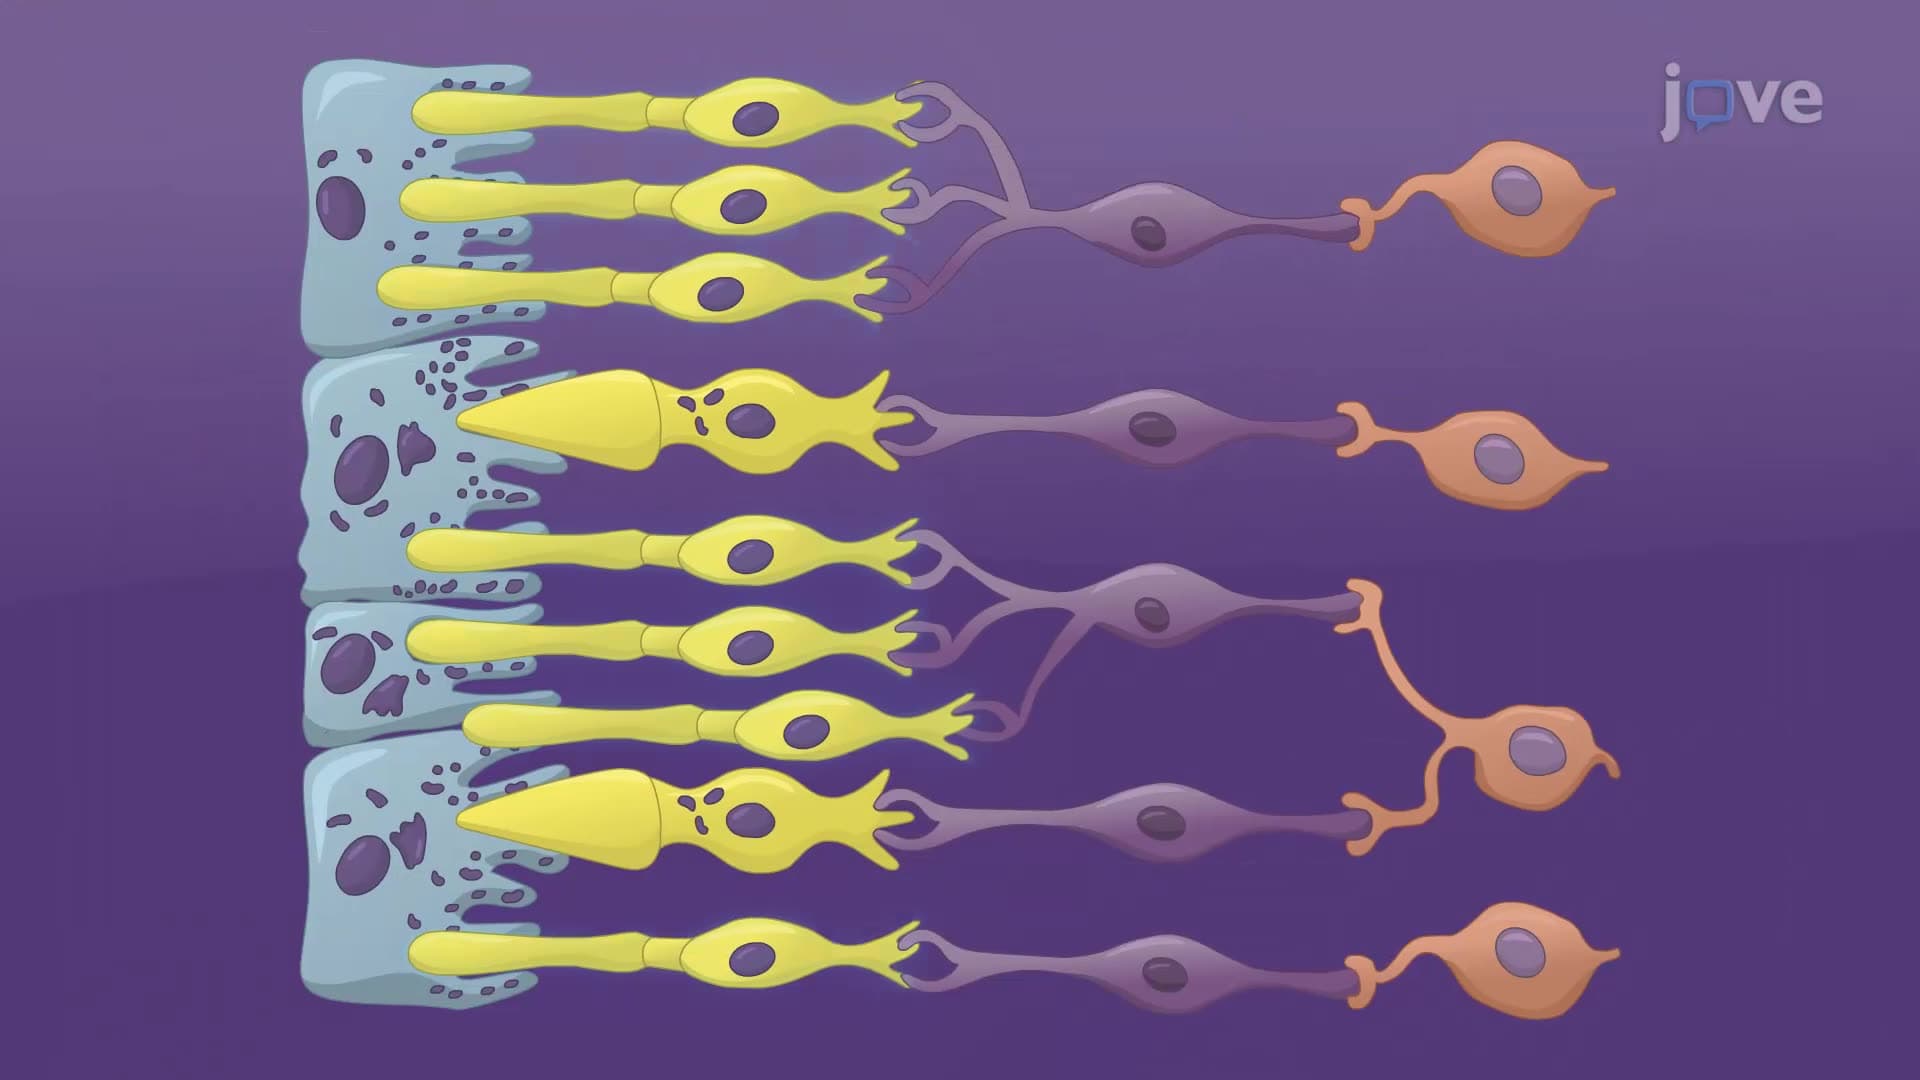
Visual System
Once through the pupil, the light passes through the lens, a...
 01:24
Vision
 01:15
Depth Perception and Spatial Vision