Related Experiment Video
Updated: Mar 5, 2026


Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
H∞ control for a class of singular systems with state time-varying delay
Shaohua Long1, Shouming Zhong2
1School of Mathematics and Statistics, Chongqing University of Technology, Chongqing 400054, PR China.

Abstract:
This paper is concerned with the H∞ control problem for a class of singular systems. The systems under consideration involve state time-varying delay. The aim of this paper is to design a dynamic feedback controller such that the resultant closed-loop system is regular, impulse-free and stable with given H∞ performance index. By using the Lyapunov-Krasovskii functional method, some delay-dependent sufficient criteria which guarantee the existence of the dynamic feedback controller and determine explicitly the parameters of the dynamic feedback controller are presented. Finally, some numerical examples are provided to show the effectiveness of the presented approaches.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:31
Classification of Systems-II
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
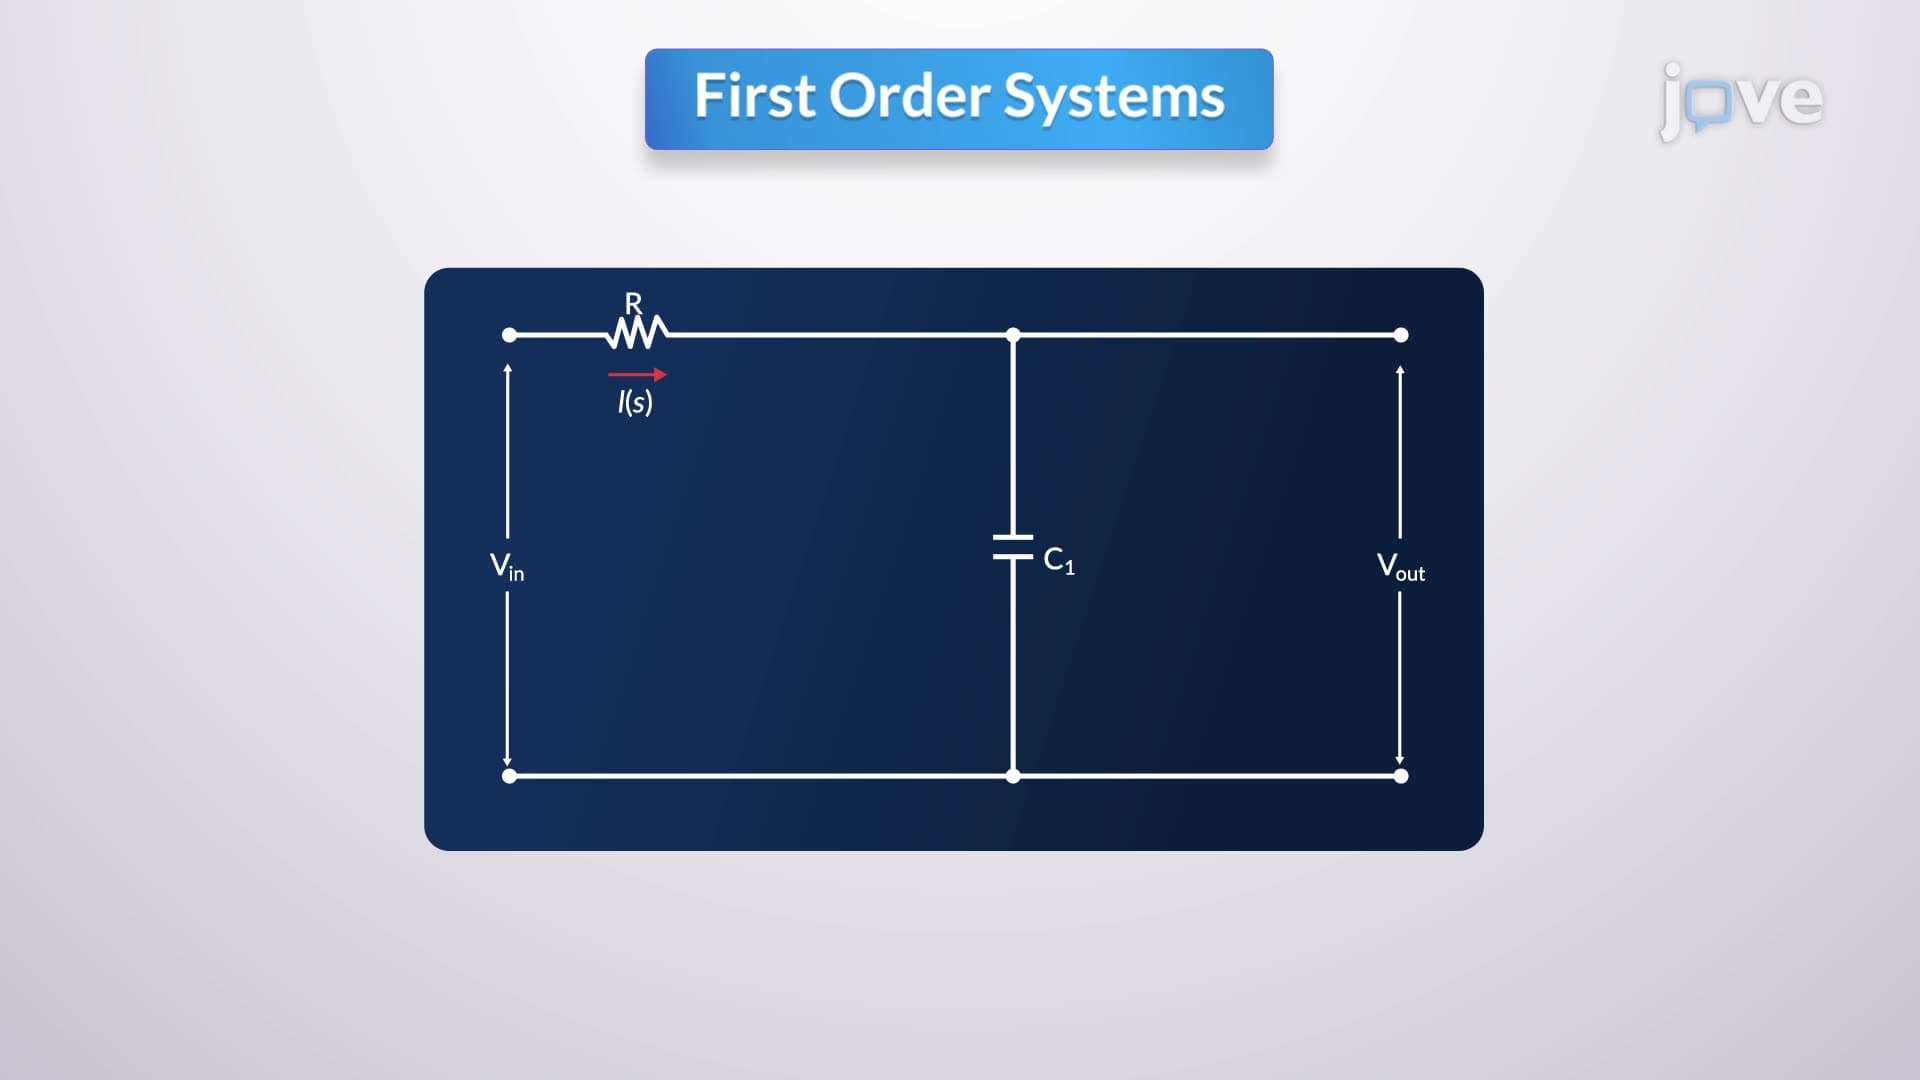
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...