Related Experiment Video
Updated: Aug 9, 2026
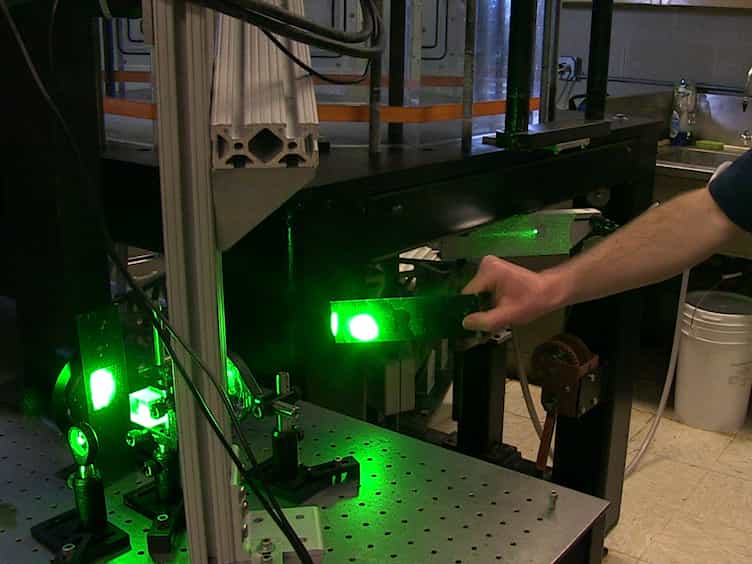
Methods for Measuring the Orientation and Rotation Rate of 3D-printed Particles in Turbulence
Published on: June 24, 2016
Robust Relative Rotation Averaging

Abstract:
This paper addresses the problem of robust and efficient relative rotation averaging in the context of large-scale Structure from Motion. Relative rotation averaging finds global or absolute rotations for a set of cameras from a set of observed relative rotations between pairs of cameras. We propose a generalized framework of relative rotation averaging that can use different robust loss functions and jointly optimizes for all the unknown camera rotations. Our method uses a quasi-Newton optimization which results in an efficient iteratively reweighted least squares (IRLS) formulation that works in the Lie algebra of the 3D rotation group. We demonstrate the performance of our approach on a number of large-scale data sets. We show that our method outperforms existing methods in the literature both in terms of speed and accuracy.
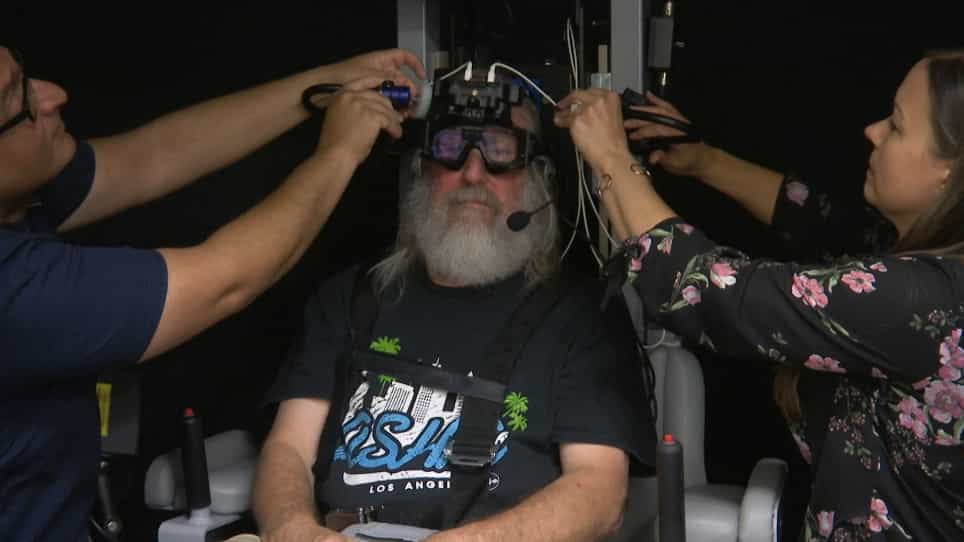
Related Concept Videos
 01:37
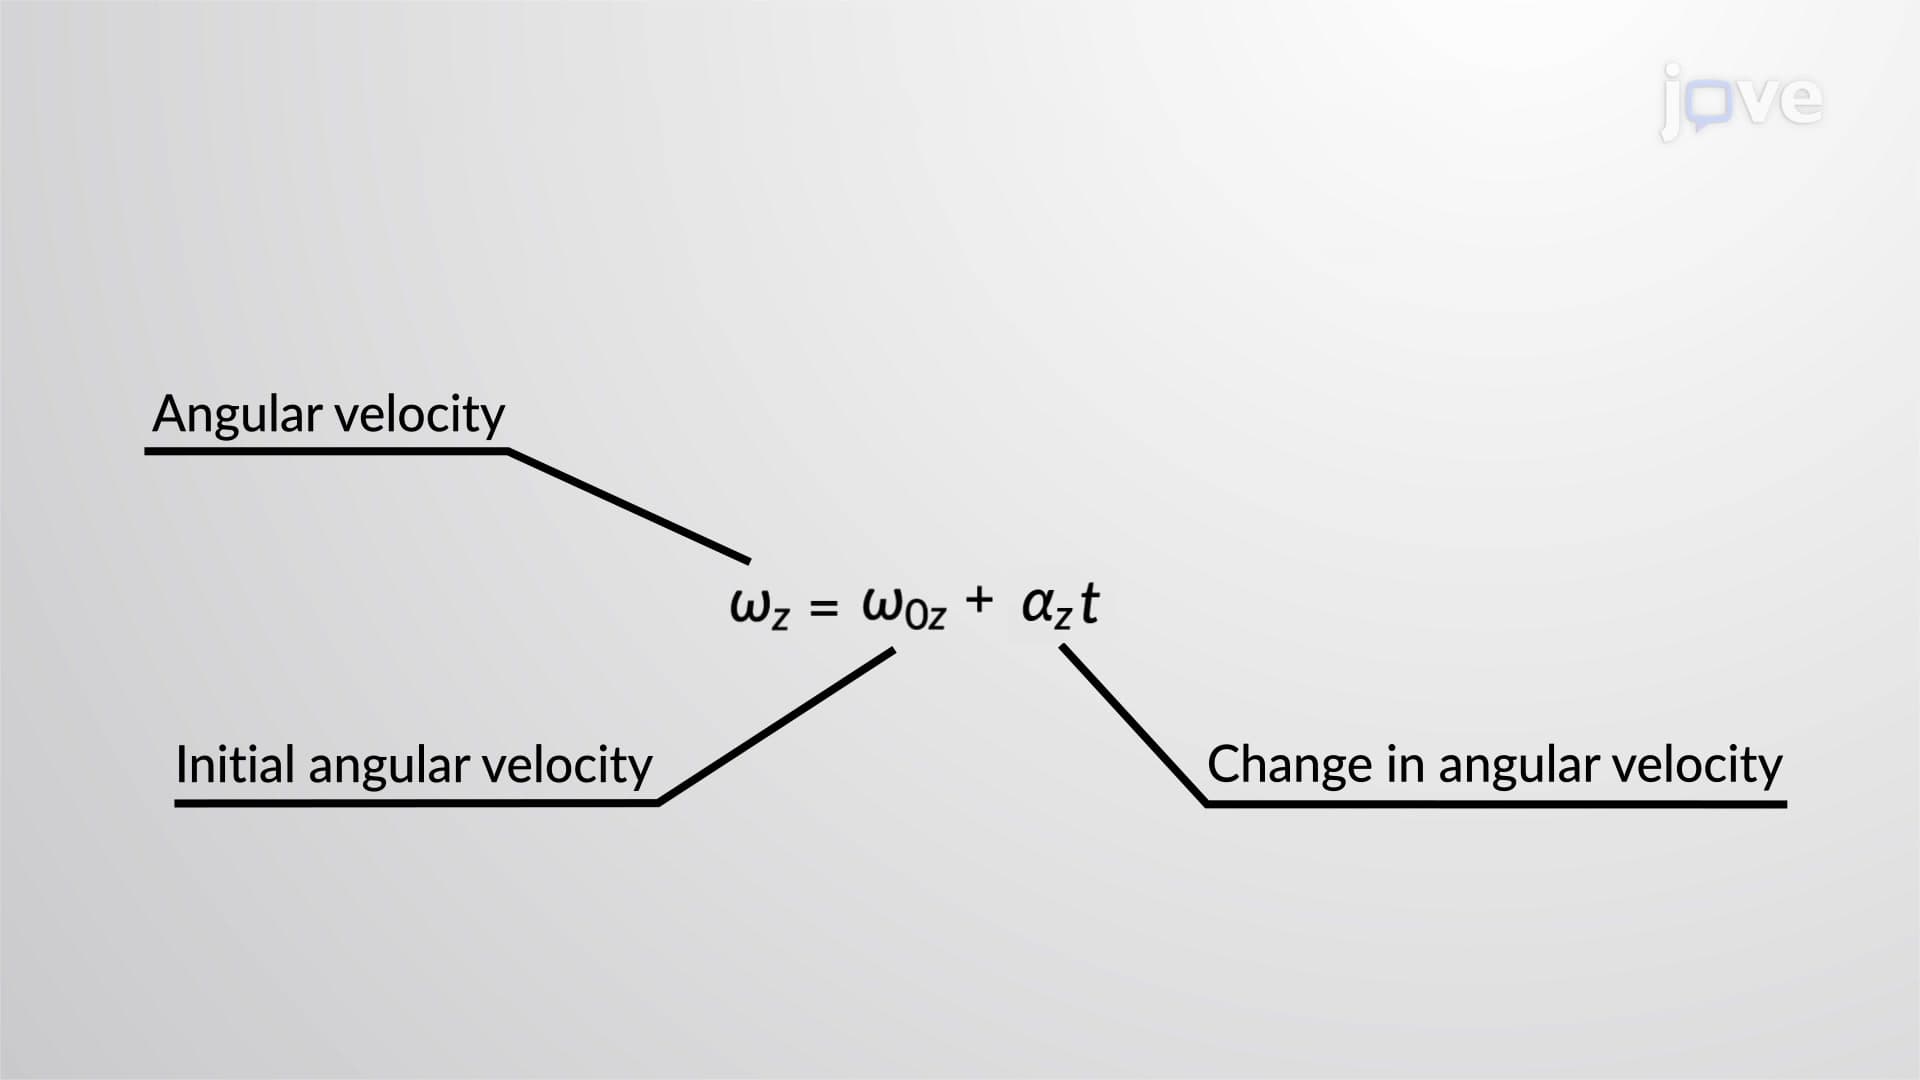
Rotation with Constant Angular Acceleration - I
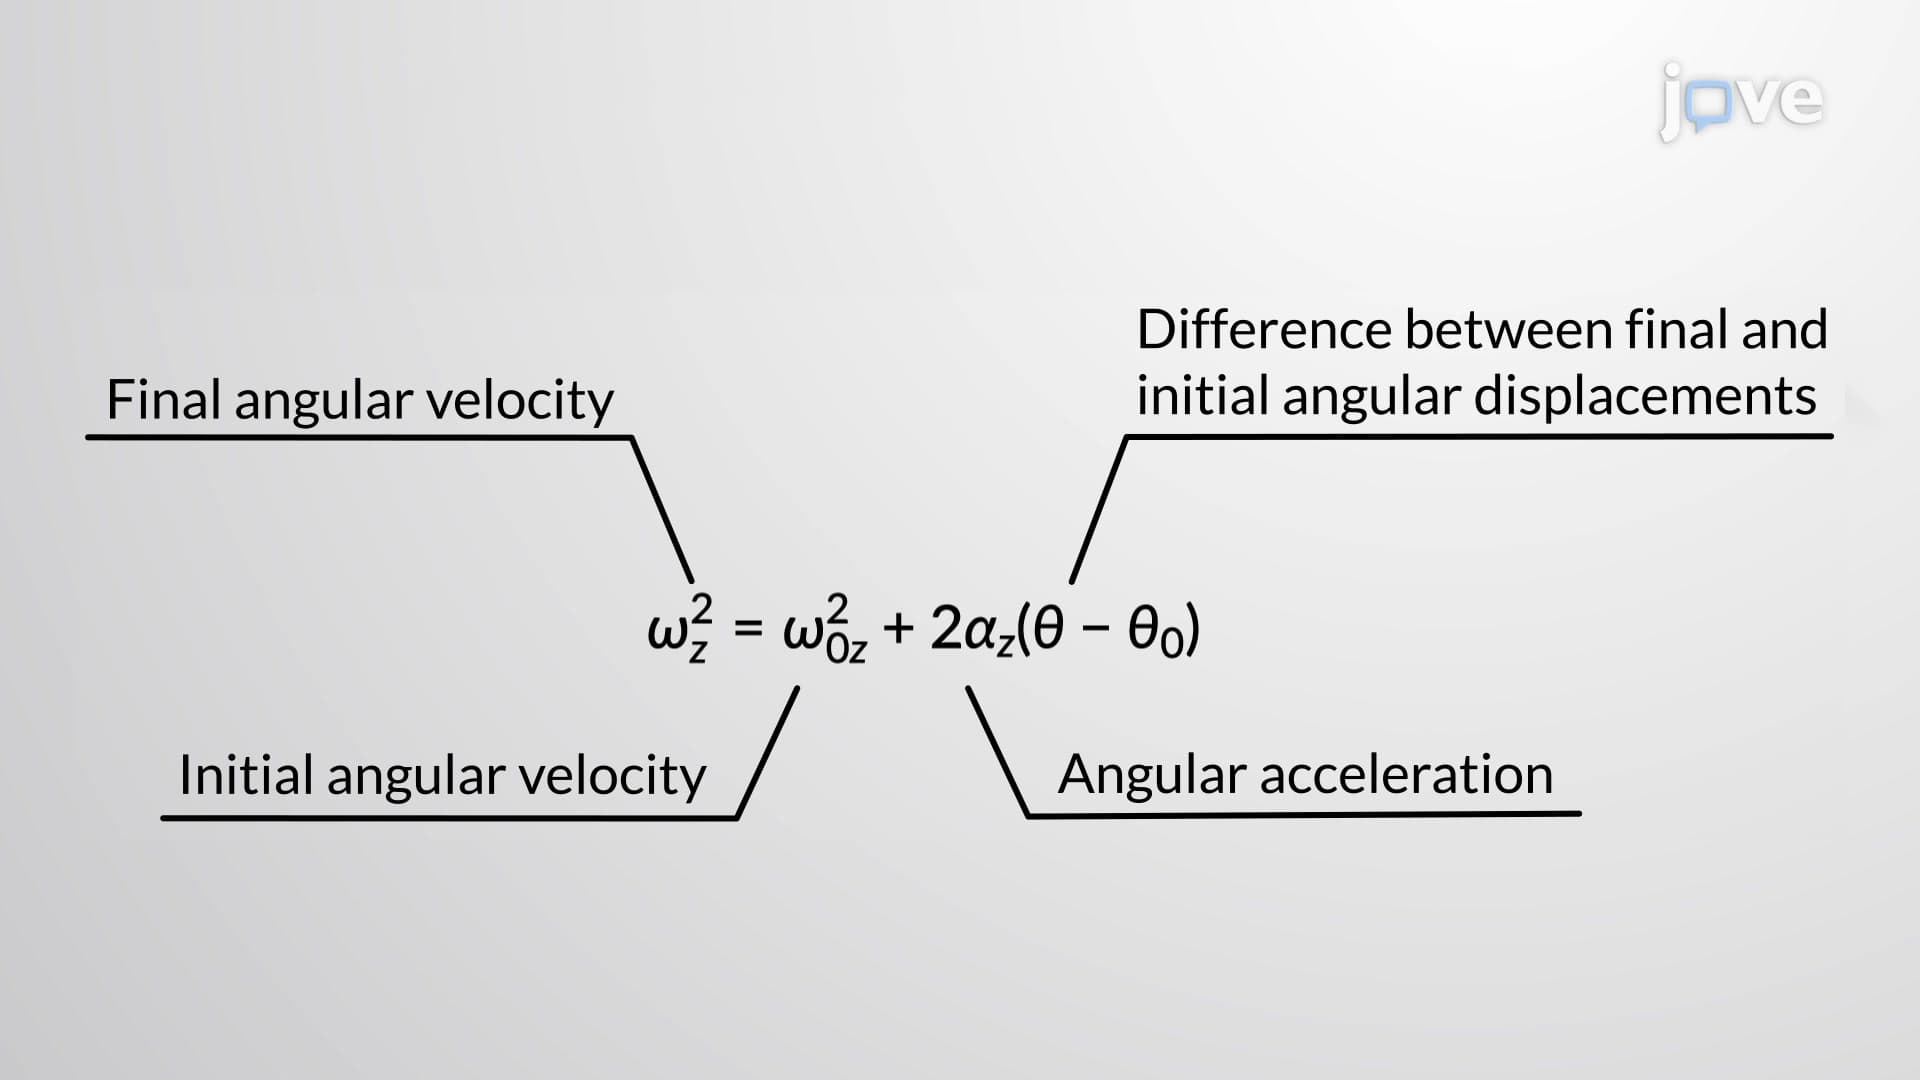
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:16
Rotation with Constant Angular Acceleration - II
The first...
 01:26
Rotational Motion about a Fixed Axis
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...