Related Experiment Video
Updated: Mar 3, 2026

A Millimeter Scale Flexural Testing System for Measuring the Mechanical Properties of Marine Sponge Spicules
Published on: October 11, 2017
On the dynamics and control of mechanical properties of hierarchical rotating rigid unit auxetics
Krzysztof K Dudek1,2, Ruben Gatt1, Luke Mizzi1
1Metamaterials Unit, Faculty of Science, University of Malta, Msida MSD 2080, Malta.

Abstract:
In this work, we investigate the deformation mechanism of auxetic hierarchical rotating square systems through a dynamics approach. We show how their deformation behaviour, hence their mechanical properties and final configuration for a given applied load, can be manipulated solely by altering the resistance to rotational motion of the hinges within the system. This provides enhanced tunability without necessarily changing the geometry of the system, a phenomenon which is not typically observed in other non-hierarchical unimode auxetic systems. This gives this hierarchical system increased versatility and tunability thus making it more amenable to be employed in practical application which may range from smart filtration to smart dressings.
Related Concept Videos
 01:11
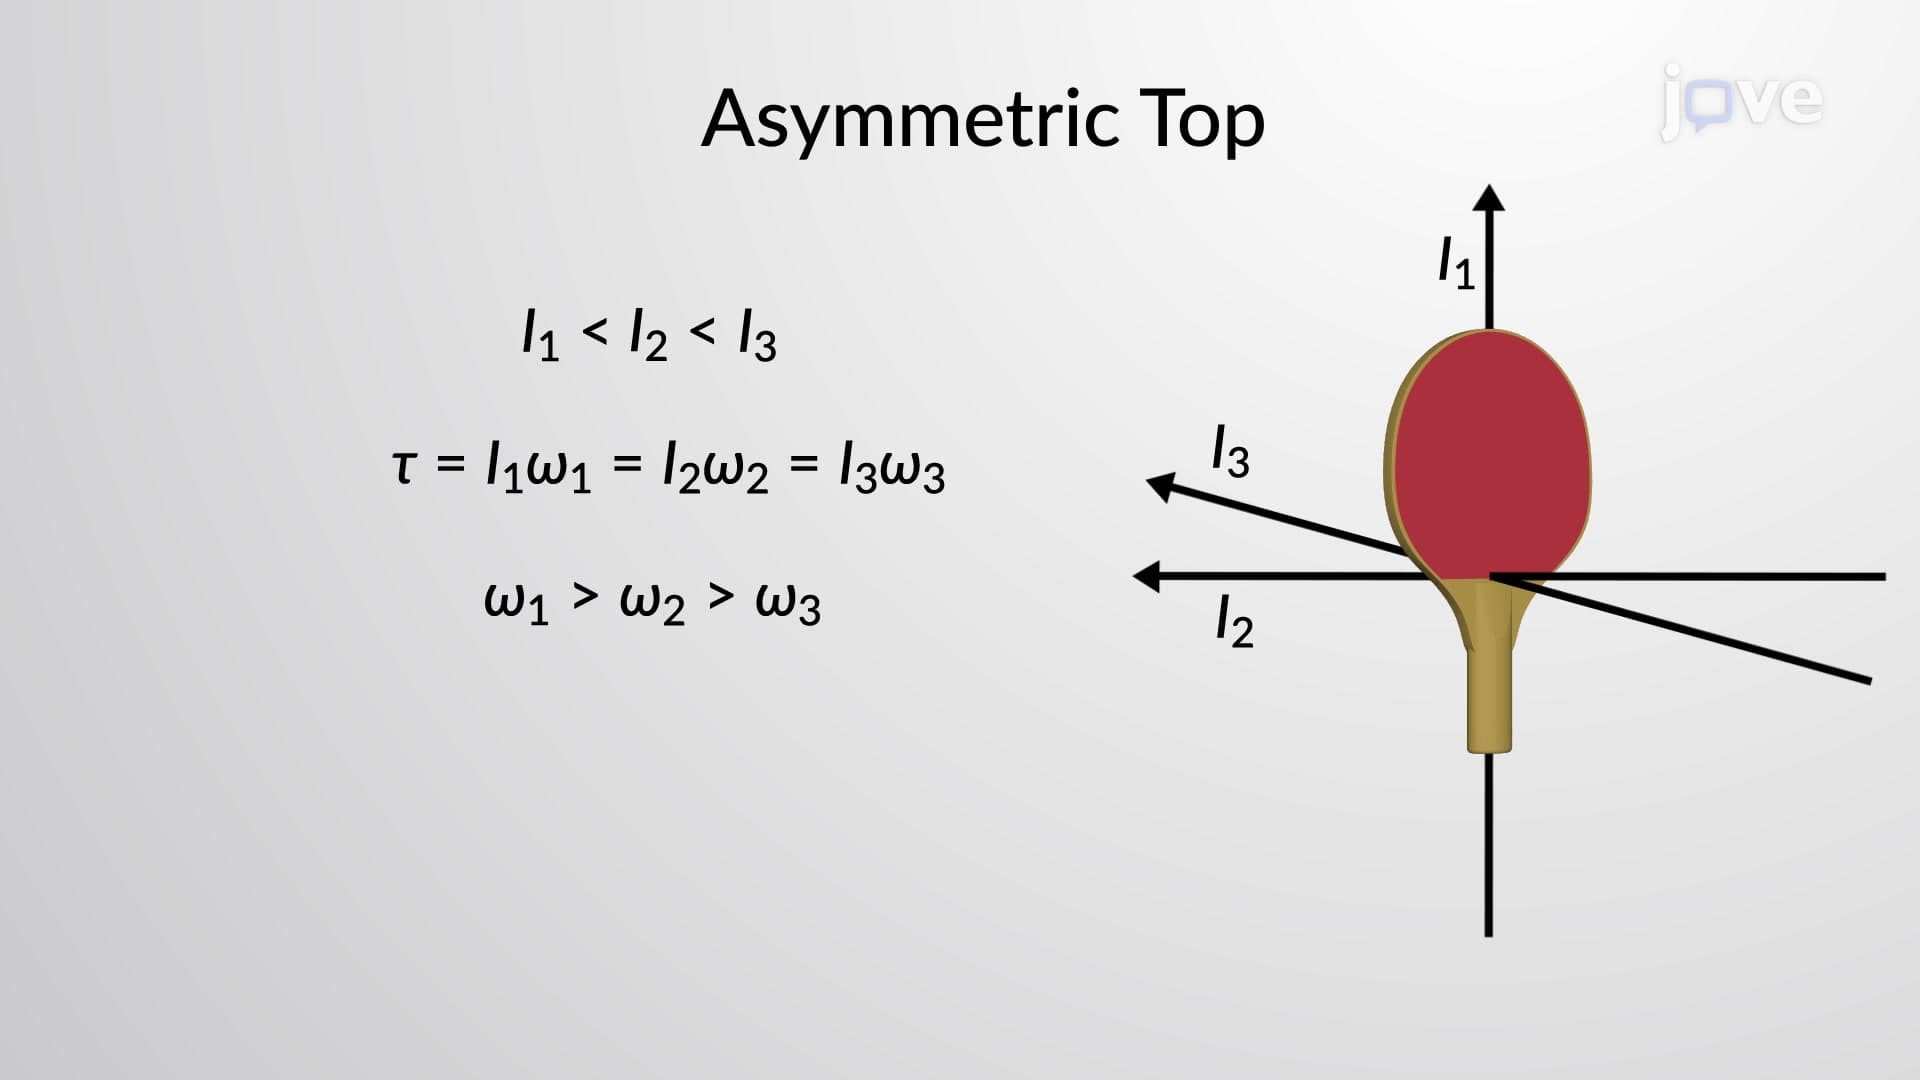
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:22
Mechanical Systems
 01:19
Euler Equations of Motion
 01:11
Angular Momentum: Rigid Body
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:24
Circular Shafts - Elastoplastic Materials
As torque on the...