Related Experiment Video
Updated: Feb 15, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
A flight-phase terrain following control strategy for stable and robust hopping of a one-legged robot under large
1Technion Autonomous Systems Program, Technion-Israel Institute of Technology, Haifa, 3200063, Israel.

Abstract:
This work demonstrates a simple, once per step, flight-control method for robots running on a planar unknown rough-terrain environment. The robot used to exemplify these control strategies is the ParkourBot, a spring loaded inverted pendulum (SLIP)-based robot. The SLIP model is widely used for the description of humans and animals running motion and has been the basis for many robots. A known control scheme for increasing robustness of the conservative, SLIP model is the swing leg retraction (SLR) method. Despite of the SLR's popularity, it is not intended to be used on the more realistic, non-conservative damped SLIP model. On the damped SLIP model, the SLR controller failed to provide adequate results, therefore, we have derived a new simple, flight-phase control method called polynomial energy insertion (PEI). The new PEI method is based on the dead-beat solution of the damped simplified instantaneous SLIP (iSLIP) model, which assumes an infinitely stiff spring. Unlike the SLR which, starting from apex, changes the leg angle monotonically during flight, the PEI requires the leg length (hence, energy insertion) to change monotonically throughout the flight phase. Interestingly, the leg angle remains nearly constant. In simulations and experiments, we have compared the newly developed PEI to the previous SLR method. We have found that since the SLR does not control the horizontal velocity, it looses its stability under rough terrain. The PEI method was able to control the horizontal velocity and height from ground and hence showed great improvement in robustness to rough terrain. Moreover, in both simulations and experiments the PEI methods showed an increase in the mean jumps to failure of more than 30% compared to SLR-based controllers.
Related Concept Videos
 02:53
Conservative Site-specific Recombination and Phase Variation
The recognition sites for Cre recombinase called LoxP...
 01:22
Phase-lead and Phase-lag Controllers
 01:14
What is Variation?
The range, standard deviation, standard error, and variance are the different measures of variation.
Range: The range is the difference between its maximum and...
 01:23
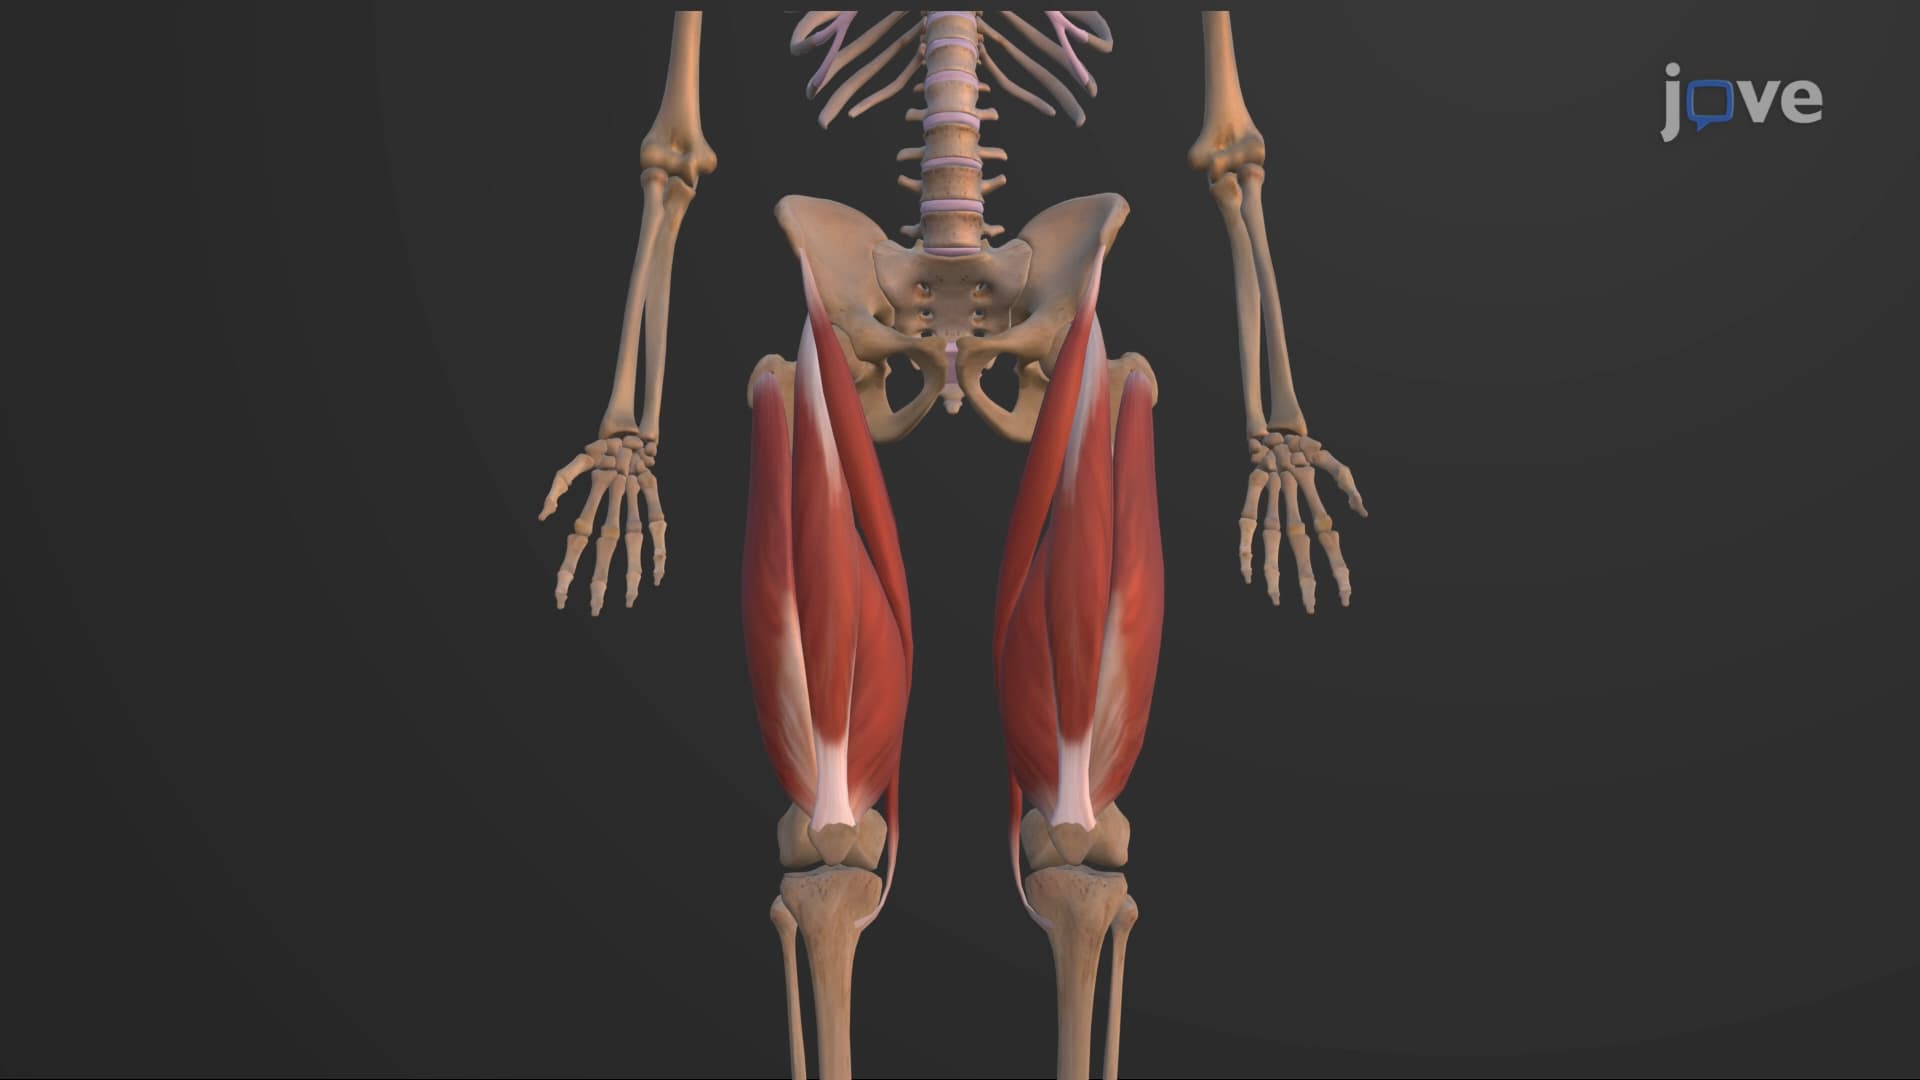
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:19
Variation
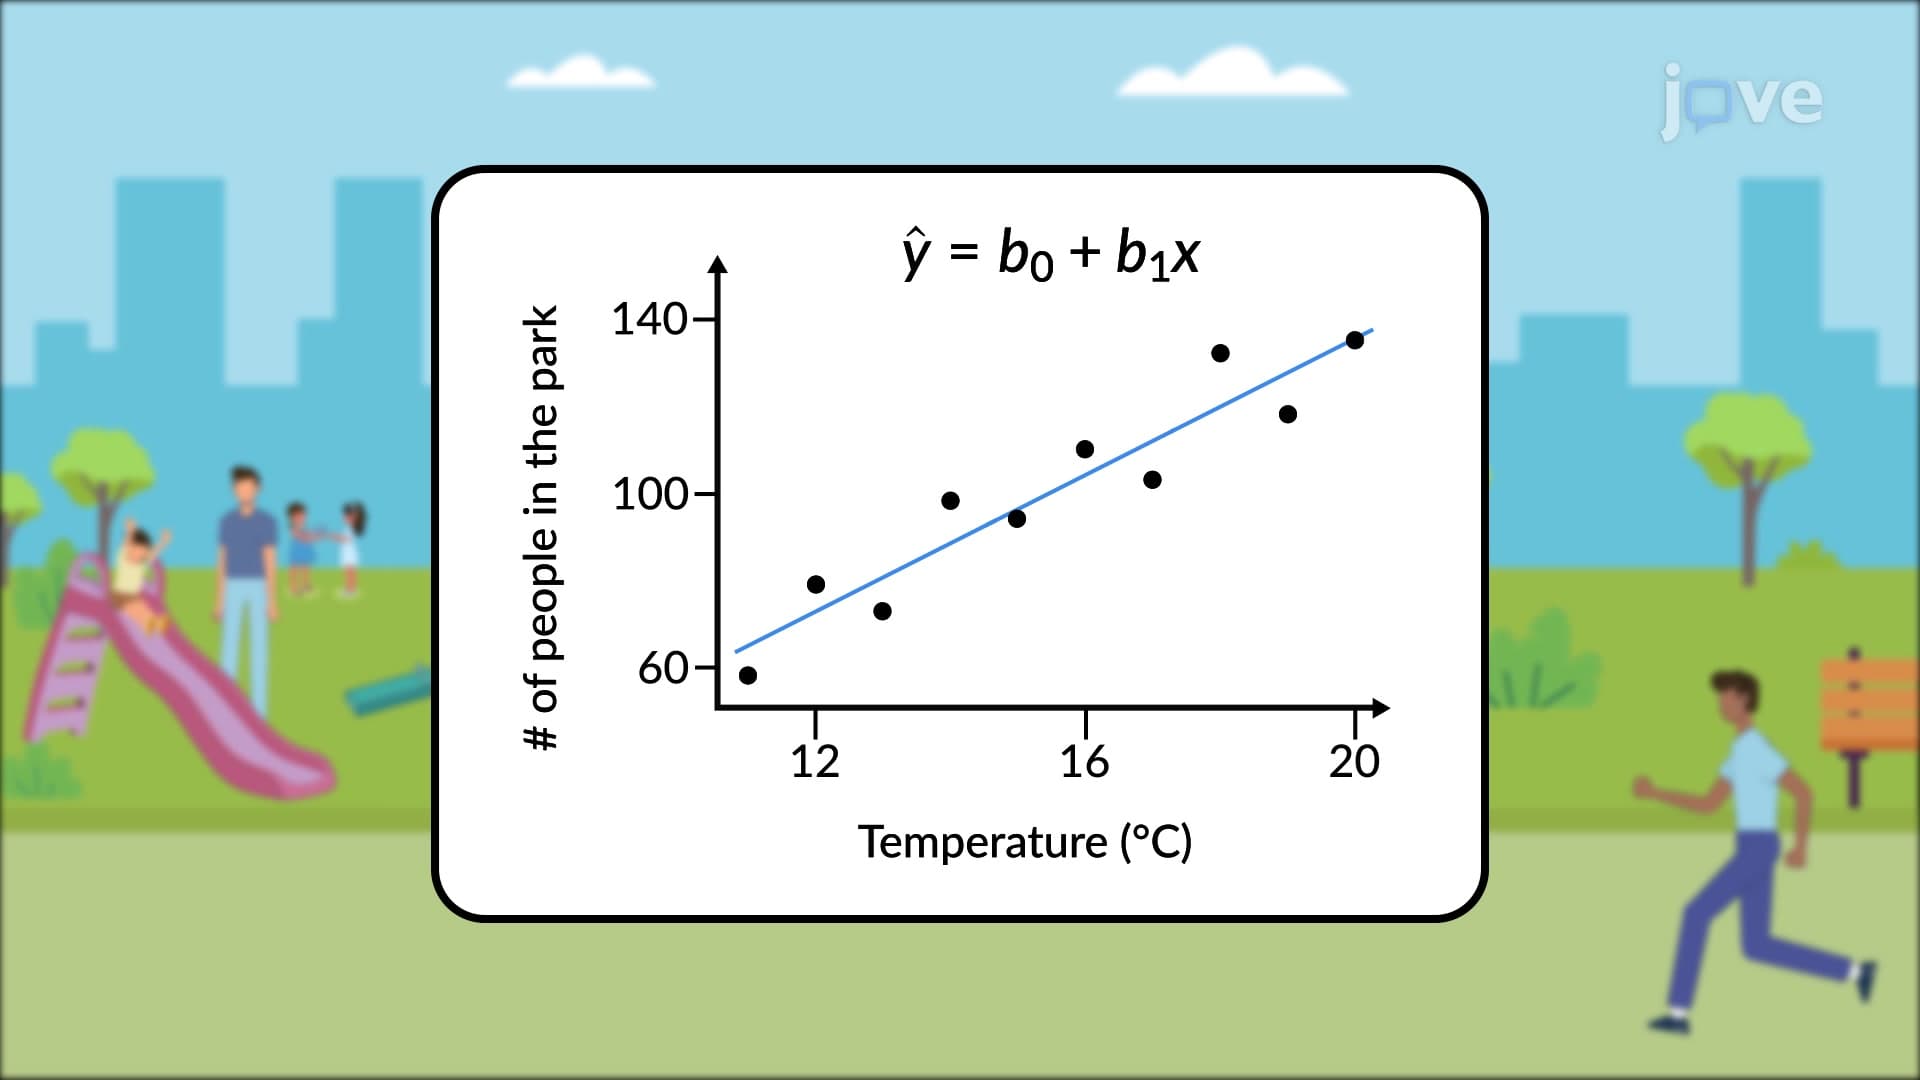
When independent and dependent variables are plotted on a scatter plot, the slope of a line is a value that describes the rate of change between the two...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...