3D Object Proposals Using Stereo Imagery for Accurate Object Class Detection
Related Experiment Video
Updated: Mar 1, 2026
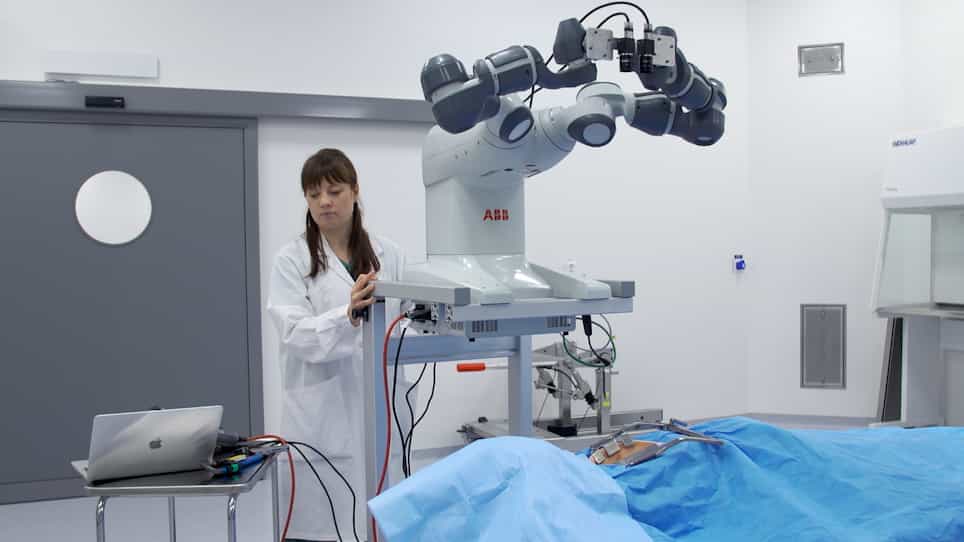
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021

Abstract:
The goal of this paper is to perform 3D object detection in the context of autonomous driving. Our method aims at generating a set of high-quality 3D object proposals by exploiting stereo imagery. We formulate the problem as minimizing an energy function that encodes object size priors, placement of objects on the ground plane as well as several depth informed features that reason about free space, point cloud densities and distance to the ground. We then exploit a CNN on top of these proposals to perform object detection. In particular, we employ a convolutional neural net (CNN) that exploits context and depth information to jointly regress to 3D bounding box coordinates and object pose. Our experiments show significant performance gains over existing RGB and RGB-D object proposal methods on the challenging KITTI benchmark. When combined with the CNN, our approach outperforms all existing results in object detection and orientation estimation tasks for all three KITTI object classes. Furthermore, we experiment also with the setting where LIDAR information is available, and show that using both LIDAR and stereo leads to the best result.