Related Experiment Video
Updated: Feb 28, 2026

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Architectures of soft robotic locomotion enabled by simple mechanical principles
Liangliang Zhu1, Yunteng Cao, Yilun Liu
1International Center for Applied Mechanics, State Key Laboratory for Strength and Vibration of Mechanical Structures, School of Aerospace, Xi'an Jiaotong University, Xi'an 710049, China.

Abstract:
In nature, a variety of limbless locomotion patterns flourish, from the small or basic life forms (Escherichia coli, amoebae, etc.) to the large or intelligent creatures (e.g., slugs, starfishes, earthworms, octopuses, jellyfishes, and snakes). Many bioinspired soft robots based on locomotion have been developed in the past few decades. In this work, based on the kinematics and dynamics of two representative locomotion modes (i.e., worm-like crawling and snake-like slithering), we propose a broad set of innovative designs for soft mobile robots through simple mechanical principles. Inspired by and going beyond the existing biological systems, these designs include 1-D (dimensional), 2-D, and 3-D robotic locomotion patterns enabled by the simple actuation of continuous beams. We report herein over 20 locomotion modes achieving various locomotion functions, including crawling, rising, running, creeping, squirming, slithering, swimming, jumping, turning, turning over, helix rolling, wheeling, etc. Some are able to reach high speed, high efficiency, and overcome obstacles. All these locomotion strategies and functions can be integrated into a simple beam model. The proposed simple and robust models are adaptive for severe and complex environments. These elegant designs for diverse robotic locomotion patterns are expected to underpin future deployments of soft robots and to inspire a series of advanced designs.


Related Concept Videos
 01:22
Mechanical Systems
 01:23
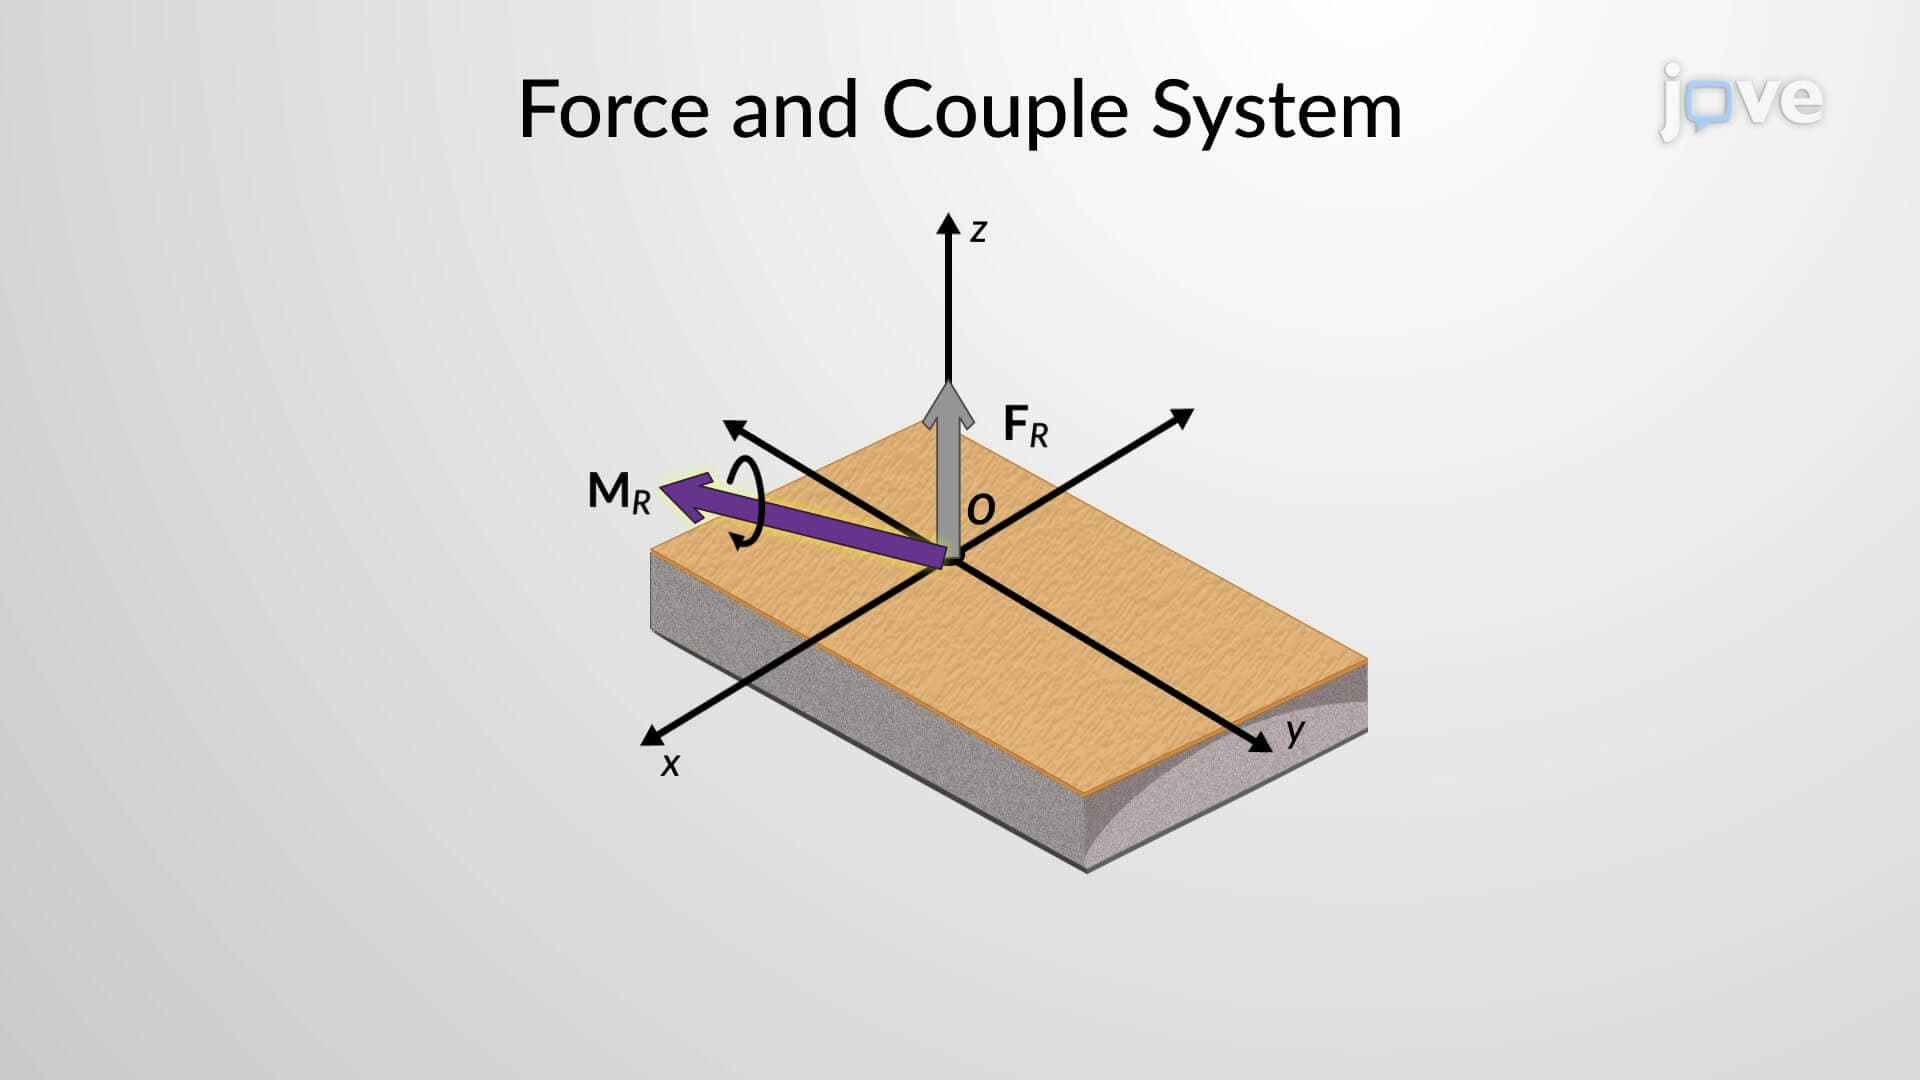
Simplification of a Force and Couple System: II
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:14
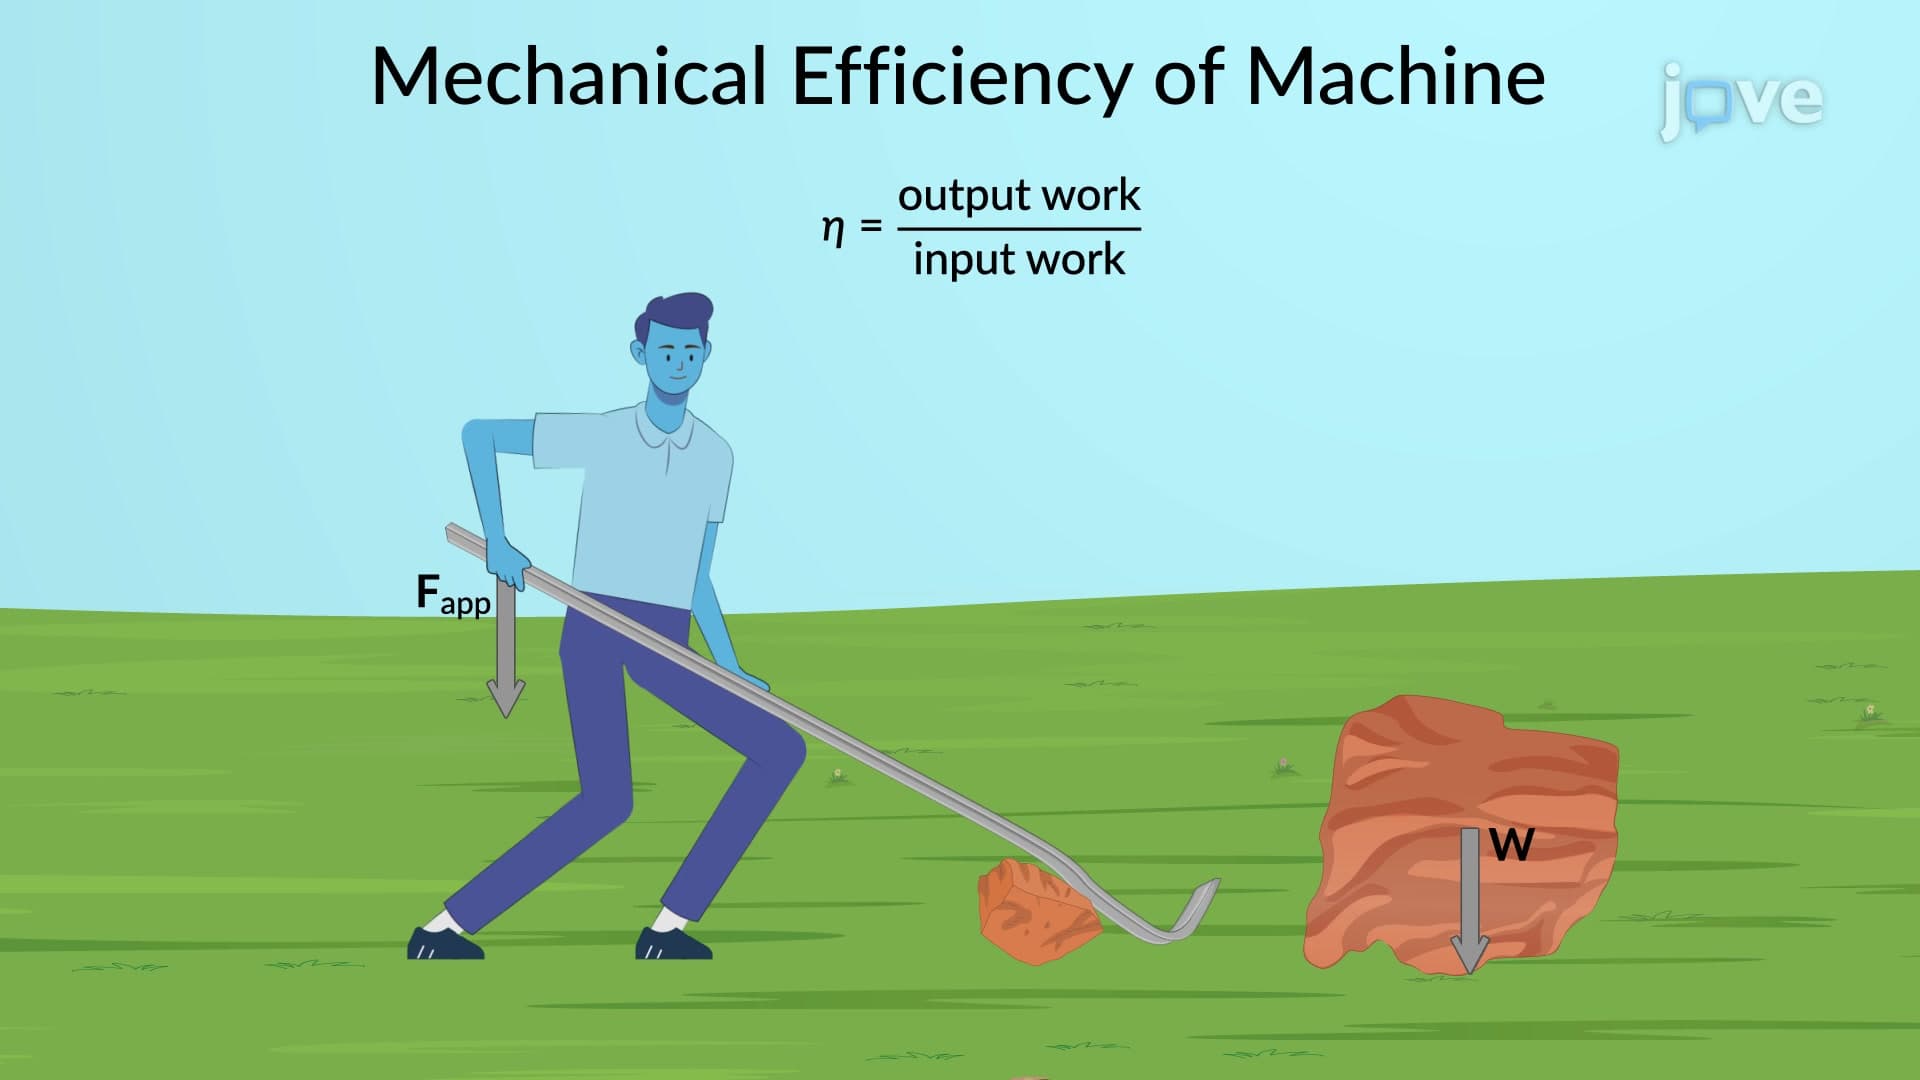
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:31
Mechanism of Lamellipodia Formation
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...