Error performances of a model-based biplane fluoroscopic system for tracking knee prosthesis during treadmill gait task
Related Experiment Video
Updated: Feb 26, 2026
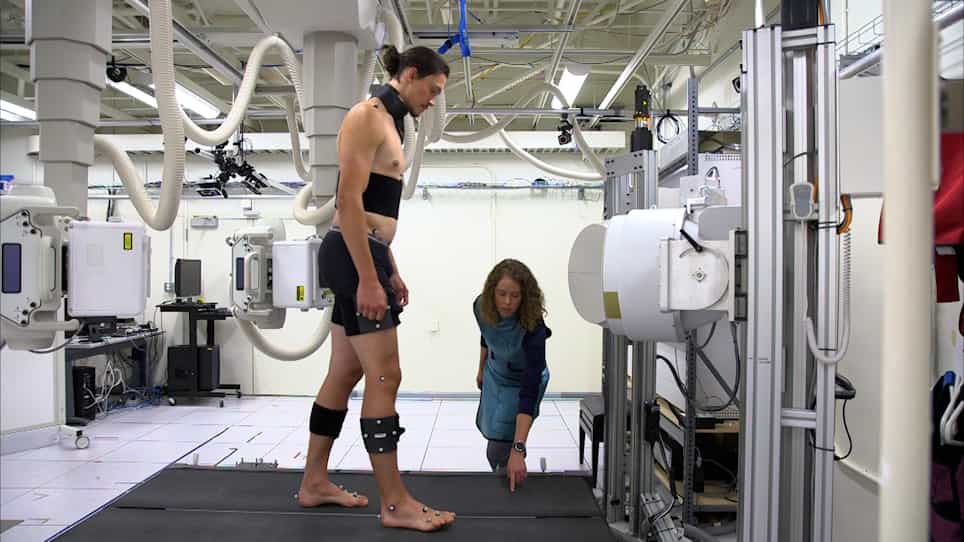
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
Arnaud Barré1,2, Kamiar Aminian3
1Laboratory of Movement Analysis and Measurement, Ecole Polytechnique Federale de Lausanne, Station 9, 1015, Lausanne, Switzerland.

Abstract:
Roentgen stereophotogrammetry analysis technique allows an accurate measurement of knee joint prosthesis position and orientation using two X-ray images. Although this technique is used generally during static procedure, it is possible to use it with a biplane fluoroscopic system to measure the prosthesis kinematics during functional tasks (e.g., gait, squat, jump) performed in a laboratory environment. However, the performance of the system in terms of errors for the measurements and the model-based matching algorithm are not well known for dynamic tasks such as walking. The goal of this study was to estimate the static and dynamic errors of a model-based biplane fluoroscopic system for a treadmill gait task and analyze the error performance according to the speed and location of the knee joint prosthesis relative to X-ray sources. The results show a static maximum error (RMSE) of 0.13° for orientation and 0.06 mm for position for prosthesis components. The dynamic errors were different for each axis of the acquisition system and each prosthesis component. The largest dynamic error was along the vertical axis for the position (RMSE = 2.42 mm) and along the medio-lateral axis (perpendicular to movement) for the orientation (RMSE = 0.95°). As expected, the error depends on the distance between the prosthesis and the source in the acquisition system as well as the linear and angular velocity of the movement. The most accurate dynamic measure was around the centroid of the acquisition system, while kinematics measurements close to the X-rays detectors gave the worst errors.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 08:08
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014