Related Experiment Video
Updated: Feb 25, 2026

Stimulating the Lip Motor Cortex with Transcranial Magnetic Stimulation
Published on: June 14, 2014
Global Mittag-Leffler stability analysis of fractional-order impulsive neural networks with one-side Lipschitz
Xinxin Zhang1, Peifeng Niu1, Yunpeng Ma1
1School of Electrical Engineering, Yanshan University, Qinhuangdao 066001, China.

Abstract:
This paper is concerned with the stability analysis issue of fractional-order impulsive neural networks. Under the one-side Lipschitz condition or the linear growth condition of activation function, the existence of solution is analyzed respectively. In addition, the existence, uniqueness and global Mittag-Leffler stability of equilibrium point of the fractional-order impulsive neural networks with one-side Lipschitz condition are investigated by the means of contraction mapping principle and Lyapunov direct method. Finally, an example with numerical simulation is given to illustrate the validity and feasibility of the proposed results.
Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:21
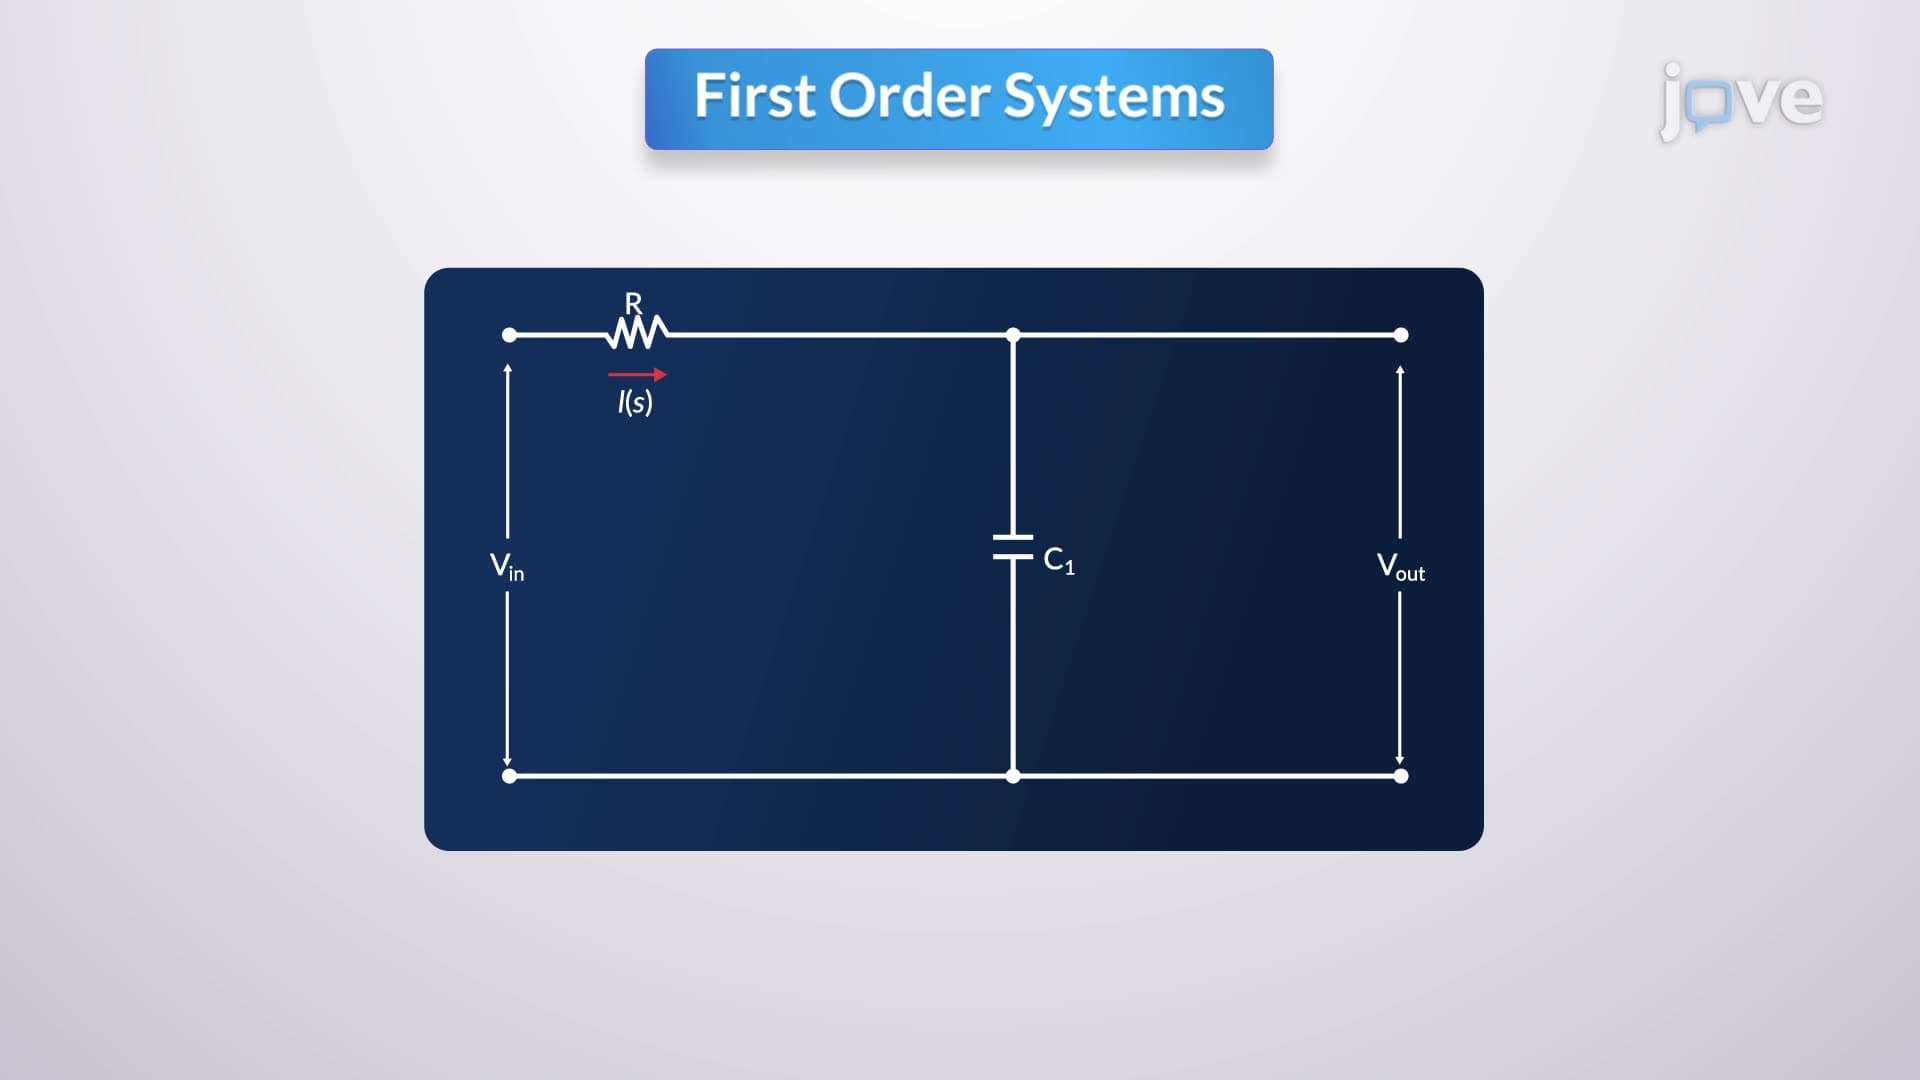
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:18
Second Order systems II
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:22
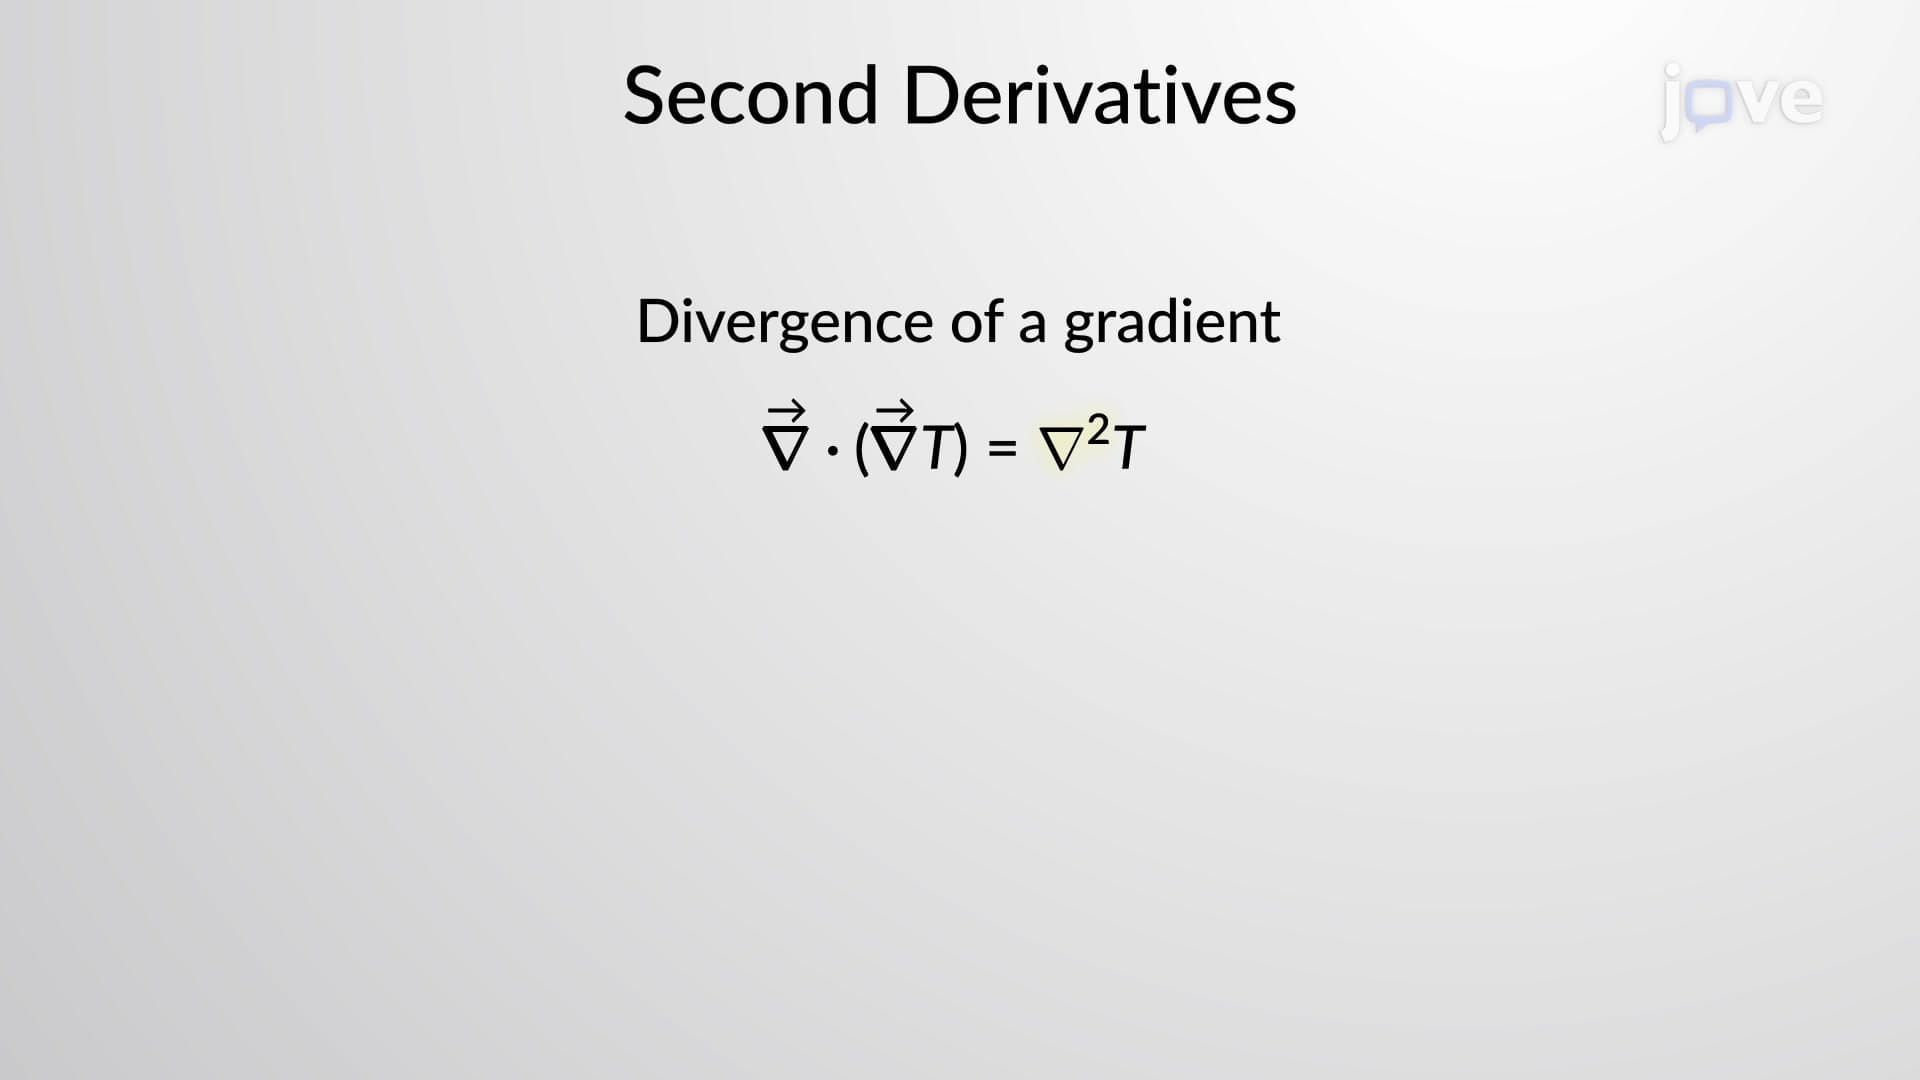
Second Derivatives and Laplace Operator
Consider a scalar function. The curl of its...