Related Experiment Video
Updated: Feb 25, 2026

Characterization of Anisotropic Leaky Mode Modulators for Holovideo
Published on: March 19, 2016
Sliding mode control for generalized robust synchronization of mismatched fractional order dynamical systems and its
P Muthukumar1, P Balasubramaniam2, K Ratnavelu3
1Department of Mathematics, Gandhigram Rural Institute - Deemed University, Gandhigram 624 302, Tamil Nadu, India; Institute of Mathematical Sciences, Faculty of Science, University of Malaya, 50603 Kuala Lumpur, Malaysia.

Abstract:
This paper proposes a generalized robust synchronization method for different dimensional fractional order dynamical systems with mismatched fractional derivatives in the presence of function uncertainty and external disturbance by a designing sliding mode controller. Based on the proposed theory of generalized robust synchronization criterion, a novel audio cryptosystem is proposed for sending or sharing voice messages secretly via insecure channel. Numerical examples are given to verify the potency of the proposed theories.
Related Concept Videos
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured from...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:16
Basic Discrete Time Signals
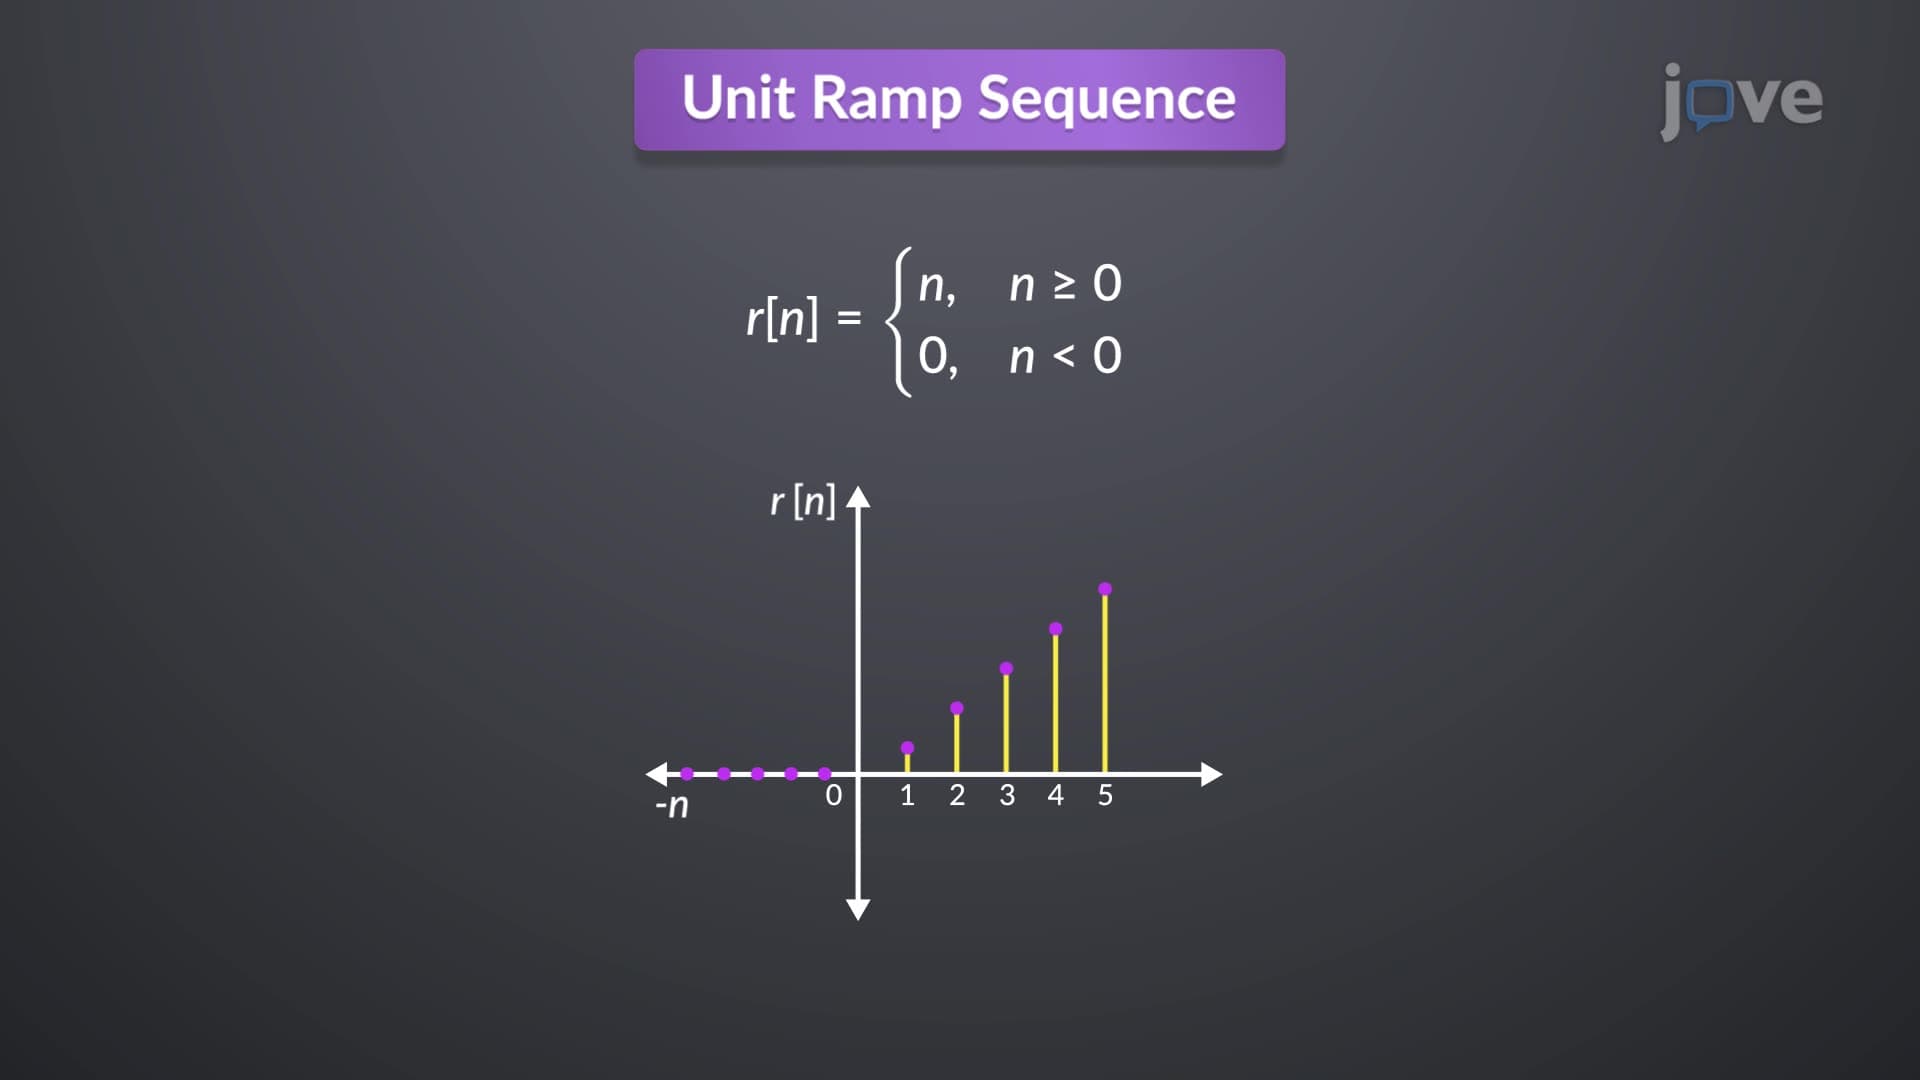
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...