Related Experiment Video
Updated: Feb 24, 2026


Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
Design of an exoskeleton ankle robot for robot-assisted gait training of stroke patients

Abstract:
Lower Limb Exoskeleton robot that can facilitate stair walking is a big challenge, most systems could only provide level ground walking. In this study, a lightweight (0.5kg at ankle, 0.5kg at waist for control box) and autonomous exoskeleton Ankle Robot was proposed to provide power assistance for gait training of chronic stroke patients and it can facilitate three walking conditions in real-time: (1) level walking, (2) stair ascending, and (3) stair descending. Chronic stroke patients (n=3) with drop foot gait deficit and moderate motor impairment were recruited to evaluate the system under different walking conditions (Functional Ambulatory Category: FAC=4.7±0.5 and Fugl-Meyer Assessment for lower-extremity: FMA-LE=13.7±2.9). The system consisted of a specially designed carbon fiber AFO, servomotor, gear transmission system, IMU and force sensors, and control box. The IMU sensors embedded in the shank measured acceleration and angular velocity to identify distinct features in leg tilting angle and leg angular velocity between the three walking conditions. The results showed the powered ankle dorsiflexion assistance could reduce dropped foot of the stroke patients in swing phase and provide better gait pattern. A demo of the ankle robot will be conducted in the conference.
More Related Videos
 06:00
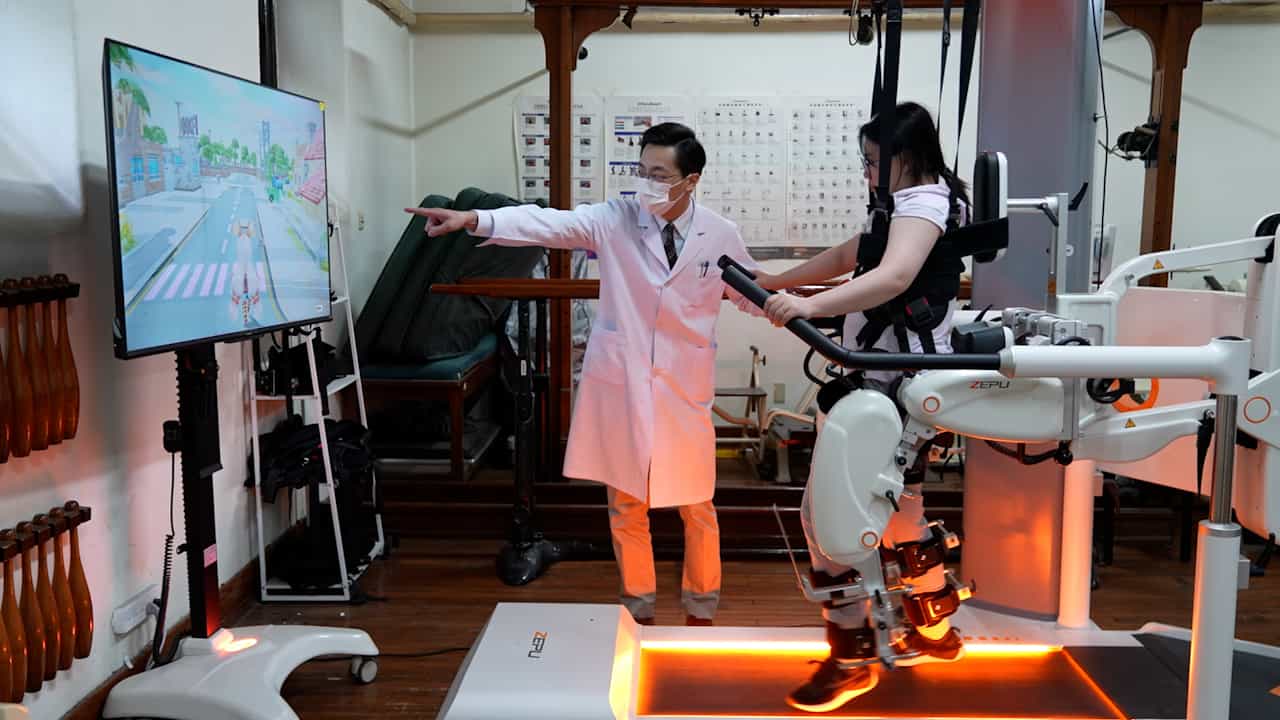
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
 06:44
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020