Related Experiment Video
Updated: Feb 24, 2026
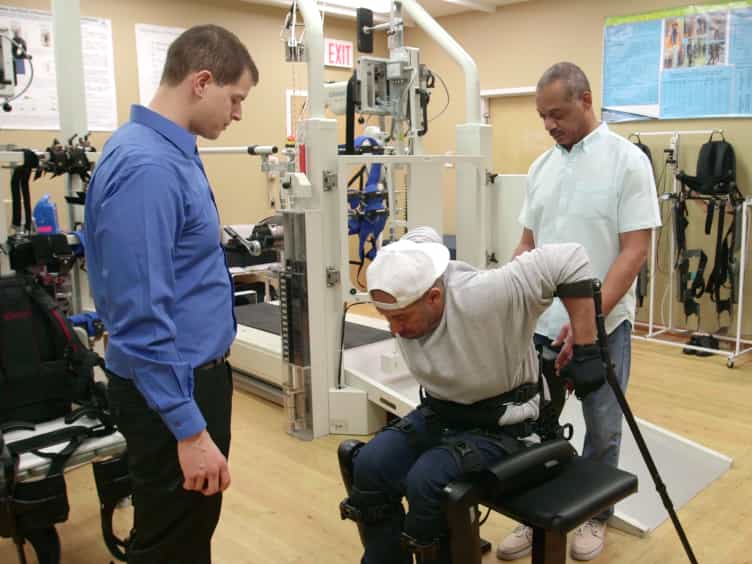
Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Cross-wire assist suit concept, for mobile and lightweight multiple degree of freedom hip assistance

Abstract:
In this paper, we present our cross-wire assist concept, for assisting a single joint in multiple degrees of freedom. It is comprised of four motor driven Bowden cable actuators (wires) per assisted joint, with the wires crossed over each other at the front and rear. Simulation results show that selectively actuating a subset of these wires allows torque to be generated in 6 directions, with the torque magnitude dependent on joint angle. We have built a fully wearable prototype of our assistance device for both hip joints, with 8 high-speed and independently controllable actuators each providing force up to 100 N. The prototype has a total mass of 9.3 kg, and is shown in motion capture testing to generate movement in 6 directions around the users joint, including internal and external rotation. Mobile, multi-degree of freedom assistance cross-wire system will enable assistive devices to better match human movement, allowing support and rehabilitation in tasks beyond straight line walking.
More Related Videos

Related Concept Videos
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:10
Ankle Joint