Related Experiment Video
Updated: Feb 24, 2026
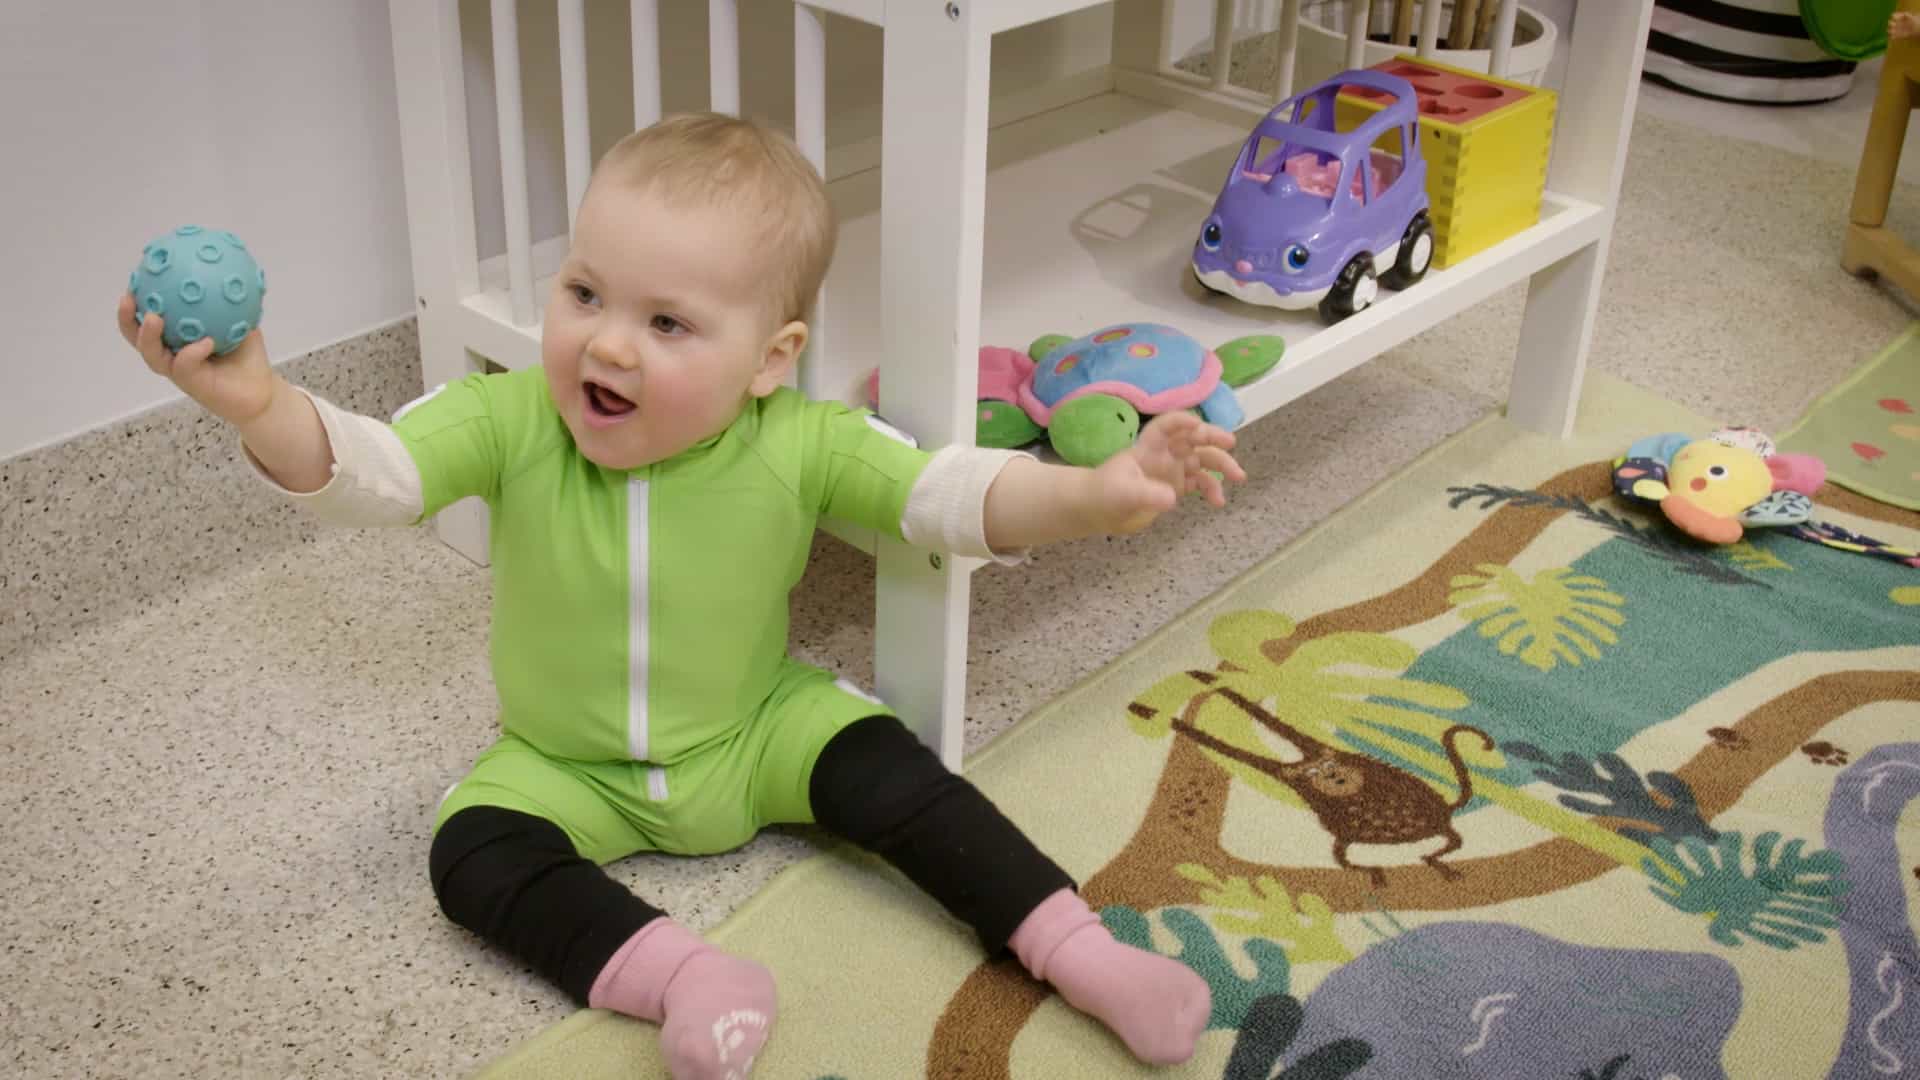

Quantified Assessment of Infant's Gross Motor Abilities Using a Multisensor Wearable
Published on: May 17, 2024
Quantifying infant physical interactions using sensorized toys in a natural play environment

Insights
Sensorized toys can track infant interactions, aiding early detection of developmental delays. This study quantifies infant-toy physical interactions using a smart elephant toy to gather data for identifying developmental differences.
Area of Science:
- Developmental Pediatrics
- Robotics
- Human-Computer Interaction
Background:
- Early detection of infant developmental delays is crucial for mitigating motor and neurological impairments.
- Sensorized toys offer a novel approach to quantify infant development through natural play interactions.
Purpose of the Study:
- To quantify how sensorized toys in a natural play environment can promote infant-toy physical interactions.
- To establish metrics for differentiating typical and atypical infant development through toy interaction data.
Main Methods:
- Development of a sensorized hanging elephant toy with an inertial measurement unit (IMU) and pressure transducer.
- Utilizing a 3 Degrees of Freedom (DoF) robotic model to calculate kinematic metrics from IMU data.
- Calculating haptic metrics from pressure transducer data to analyze infant-toy physical interactions.
Main Results:
- Six typical infants participated in the study.
- Individual infant interaction patterns varied, with the youngest showing significant toy displacement (ΔD = 27.6 cm) and the oldest exhibiting higher mean pressure (4.5 kPa).
Conclusions:
- Sensorized toys can capture valuable data on infant-toy interactions.
- Further data collection, including from atypical infants, is necessary to identify robust metrics for developmental assessment using the SmarToyGym setup.
Abstract:
Infants with developmental delays must be detected early in their development to minimize the progression of motor and neurological impairments. Our objective is to quantify how sensorized toys in a natural play environment can promote infant-toy physical interactions. We created a hanging elephant toy, equipped with an inertial measurement unit (IMU), a pressure transducer, and multiple feedback sensors, to be a hand-grasping toy. We used a 3 DoF robotic model with inputs from the IMU to calculate multiple kinematic metrics and an equation to calculate haptic metrics from the pressure transducer. Six typical infants were tested in the gym set-up. Three infants interacted with the toy for more than half the trial time. The youngest infant exhibited the largest toy displacement with ΔD = 27.6 cm, while the oldest infant squeezed the toy with the largest mean pressure of 4.5 kPa. More data on on both typical and atypical infants needs to be collected. After testing atypical infants in the SmarToyGym set-up, we will be able to identify interaction metrics that differentiate atypical and typical infants.
Related Concept Videos
 01:14
Piaget's Stage 1 of Cognitive Development
Exploration...
 01:30
Socioemotional Development during Infancy
Primary Temperament Types
 02:30
Naturalistic Observations