Related Experiment Video
Updated: Feb 24, 2026


Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Adaptive Consensus Control of Nonlinear Multiagent Systems With Unknown Control Directions Under Stochastic

Abstract:
The consensus problem over high-order nonlinear multiagent systems with the Brunovsky-type model is studied. The model parameters and control directions of agents are supposed to be unknown. Hence, based on Nussbaum-type functions, an adaptive protocol is proposed, which guarantees achieving consensus in the network when the parameters and control directions of the agents are unknown and unidentical. The main contribution of this paper (compared with the existing similar results in the literature) is to guarantee achieving consensus in networks of agents when the communication topology is not connected constantly, and communication links stochastically switch over time. It is shown that if the probability of the network connectivity is not zero, under some conditions, almost sure consensus can be achieved. Illustrative examples verify the accuracy of the proposed consensus protocol.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:13
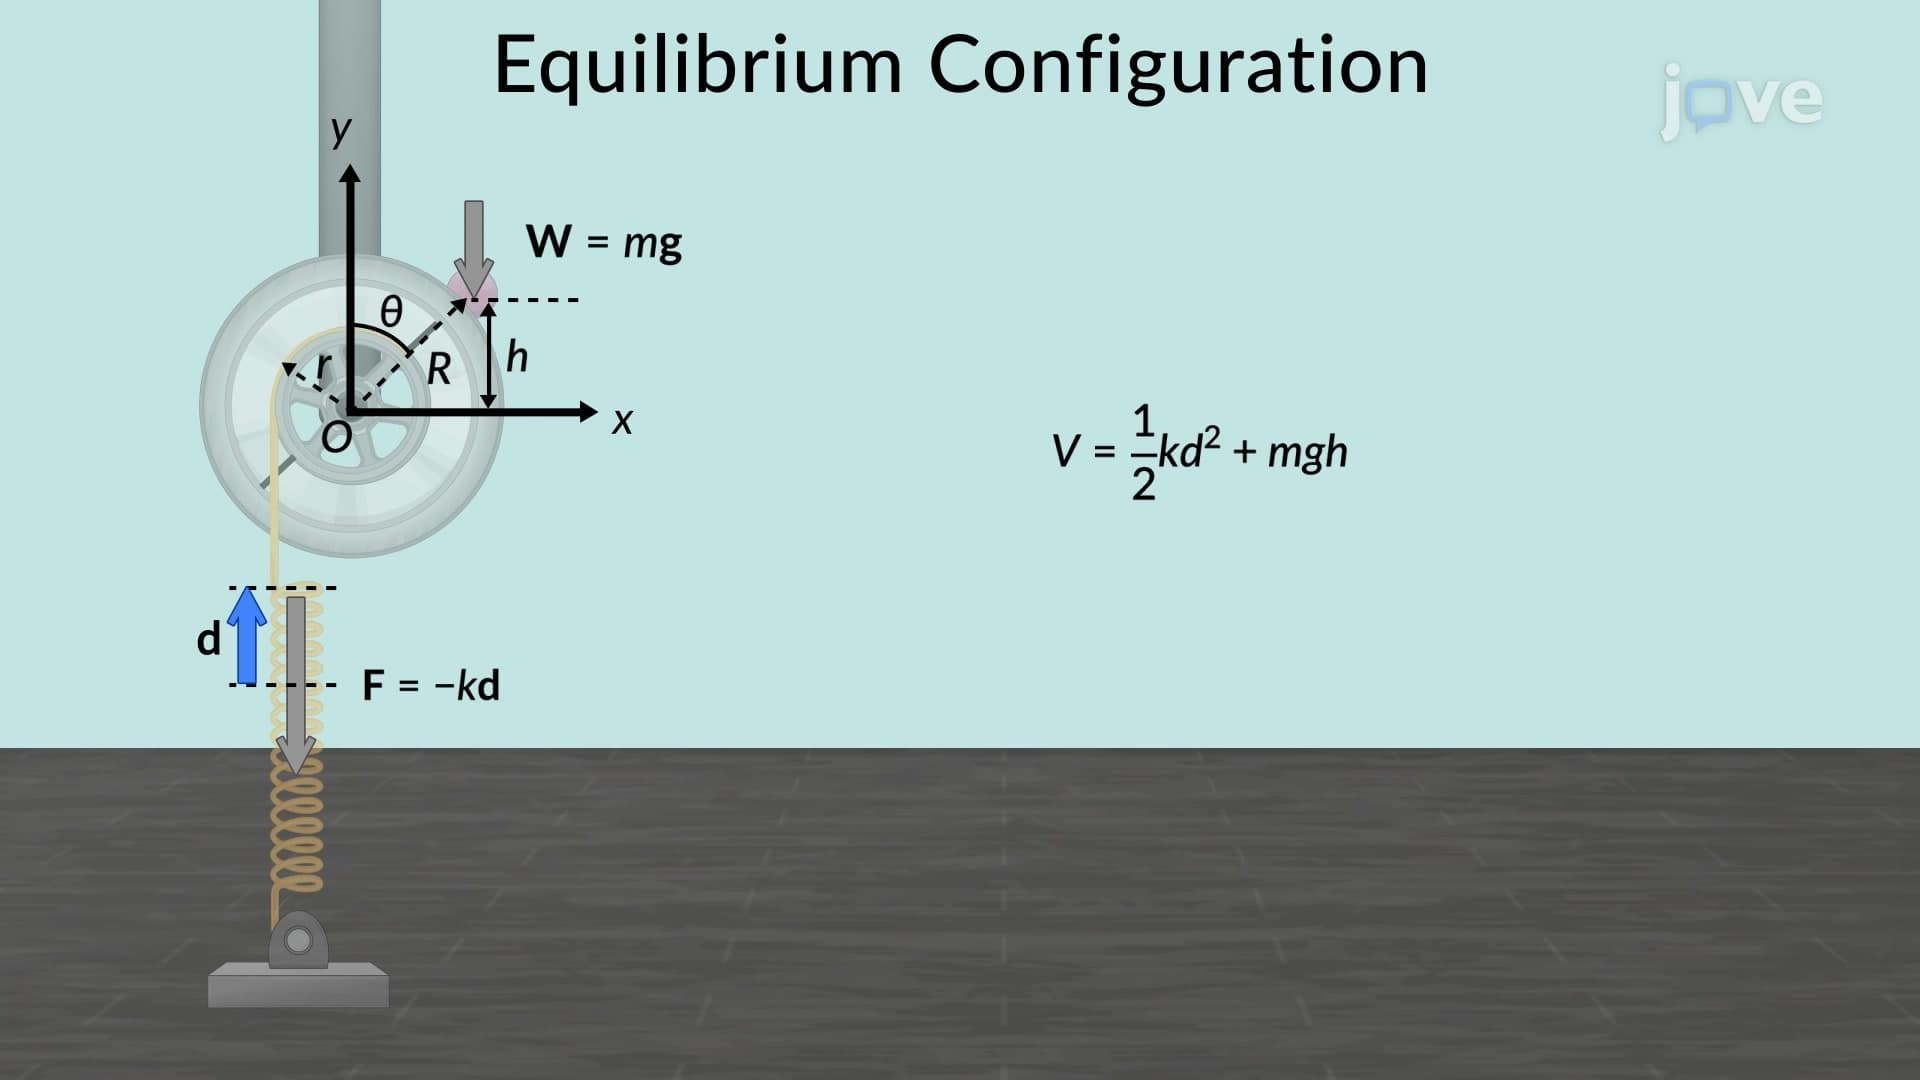
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:10
Control Systems
At the heart...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...