

A systematic delayed feedback control approach for unstable periodic orbits in chaotic systems with unknown
Hamed Rezaee1, Eckehard Schöll2, Ludovic Renson3
1School of Engineering, Newcastle University, Newcastle upon Tyne NE1 7RU, United Kingdom.

Abstract:
Delayed feedback control is a common technique for the stabilization of unstable periodic orbits in chaotic systems. Most results in this area rely on linear control techniques, which do not have guaranteed performance for nonlinear systems. Whereas nonlinear control methods have already been proposed, the existing results often rely on knowledge or partial knowledge of the system parameters and also have no mechanism for reaching the possible natural responses of the underlying uncontrolled system with embedded unstable periodic orbits. The main contribution of this paper is to propose a control method for a class of chaotic systems with entirely unknown parameters. Based on the delayed information of the system states, we develop an adaptive control strategy such that the system states converge to a periodic response with a desired time period. While infinitely many periodic responses are possible, the proposed control strategy is equipped with a mechanism that steers the dynamics toward the possible natural periodic responses of the system, such as unstable periodic orbits, where the controller is noninvasive. The proposed control strategy is demonstrated through simulation and used for revealing unstable periodic orbits inside the chaotic attractor of a Duffing oscillator.


Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:18
Second Order systems II
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:28
Stability
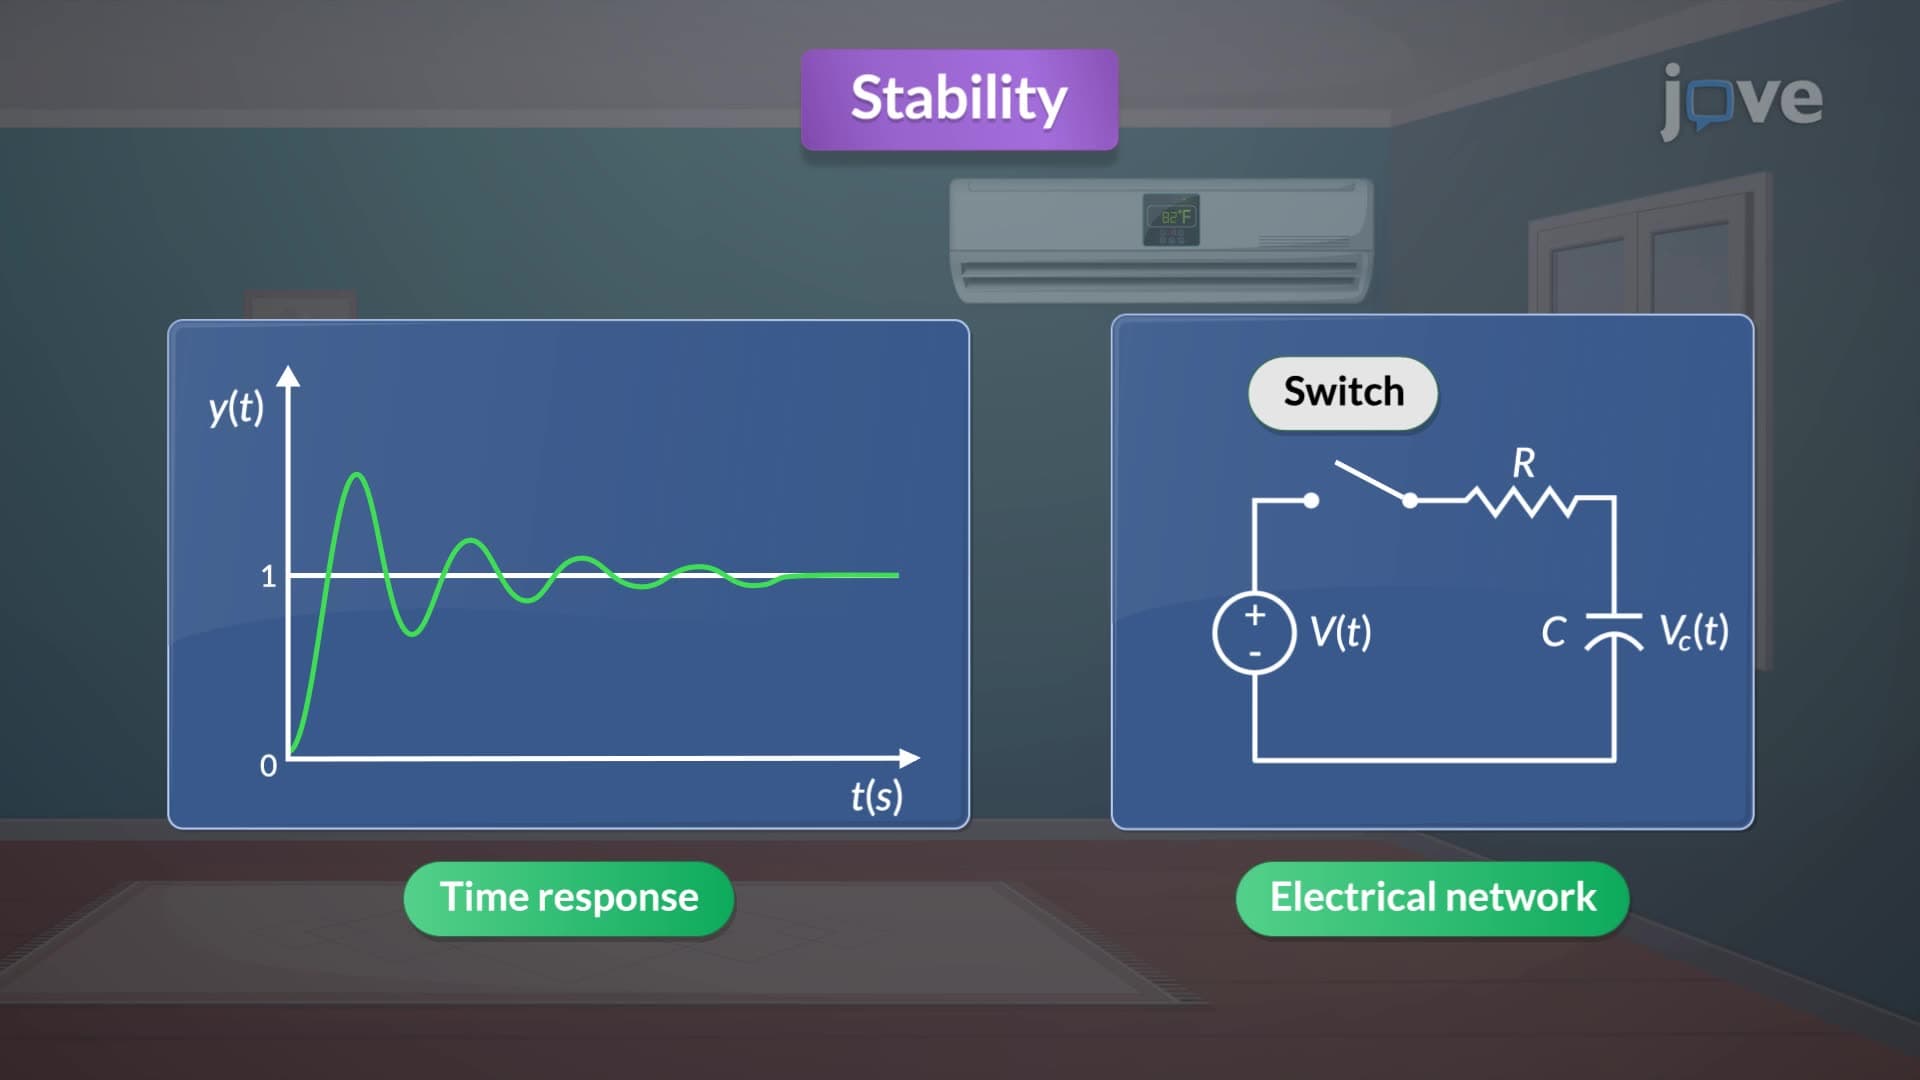
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...