Energy efficiency of mobile soft robots
Related Experiment Video
Updated: Feb 19, 2026

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Langquan Shui1, Liangliang Zhu, Zhe Yang
1International Center for Applied Mechanics, State Key Laboratory for Strength and Vibration of Mechanical Structure, School of Aerospace, Xi'an Jiaotong University, Xi'an 710049, P. R. China. yilunliu@mail.xjtu.edu.cn.

Abstract:
The performance of mobile soft robots is usually characterized by their locomotion/velocity efficiency, whereas the energy efficiency is a more intrinsic and fundamental criterion for the performance evaluation of independent or integrated soft robots. In this work, a general framework is established to evaluate the energy efficiency of mobile soft robots by considering the efficiency of the energy source, actuator and locomotion, and some insights for improving the efficiency of soft robotic systems are presented. Proposed as the ratio of the desired locomotion kinetic energy to the input mechanical energy, the energy efficiency of locomotion is found to play a critical role in determining the overall energy efficiency of soft robots. Four key factors related to the locomotion energy efficiency are identified, that is, the locomotion modes, material properties, geometric sizes, and actuation states. It is found that the energy efficiency of most mobile soft robots reported in the literature is surprisingly low (mostly below 0.1%), due to the inefficient mechanical energy that essentially does not contribute to the desired locomotion. A comparison of the locomotion energy efficiency for several representative locomotion modes in the literature is presented, showing a descending ranking as: jumping ≫ fish-like swimming > snake-like slithering > rolling > rising/turning over > inchworm-like inching > quadruped gait > earthworm-like squirming. Besides, considering the same locomotion mode, soft robots with lower stiffness, higher density and larger size tend to have higher locomotion energy efficiency. Moreover, a periodic pulse actuation instead of a continuous actuation mode may significantly reduce the input mechanical energy, thus improving the locomotion energy efficiency, especially when the pulse actuation matches the resonant states of the soft robots. The results presented herein indicate a large and necessary space for improving the locomotion energy efficiency, which is of practical significance for the future development and application of soft robots.
Related Concept Videos
 01:14
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:05
Conservation of Mechanical Energy
When a...
 01:10
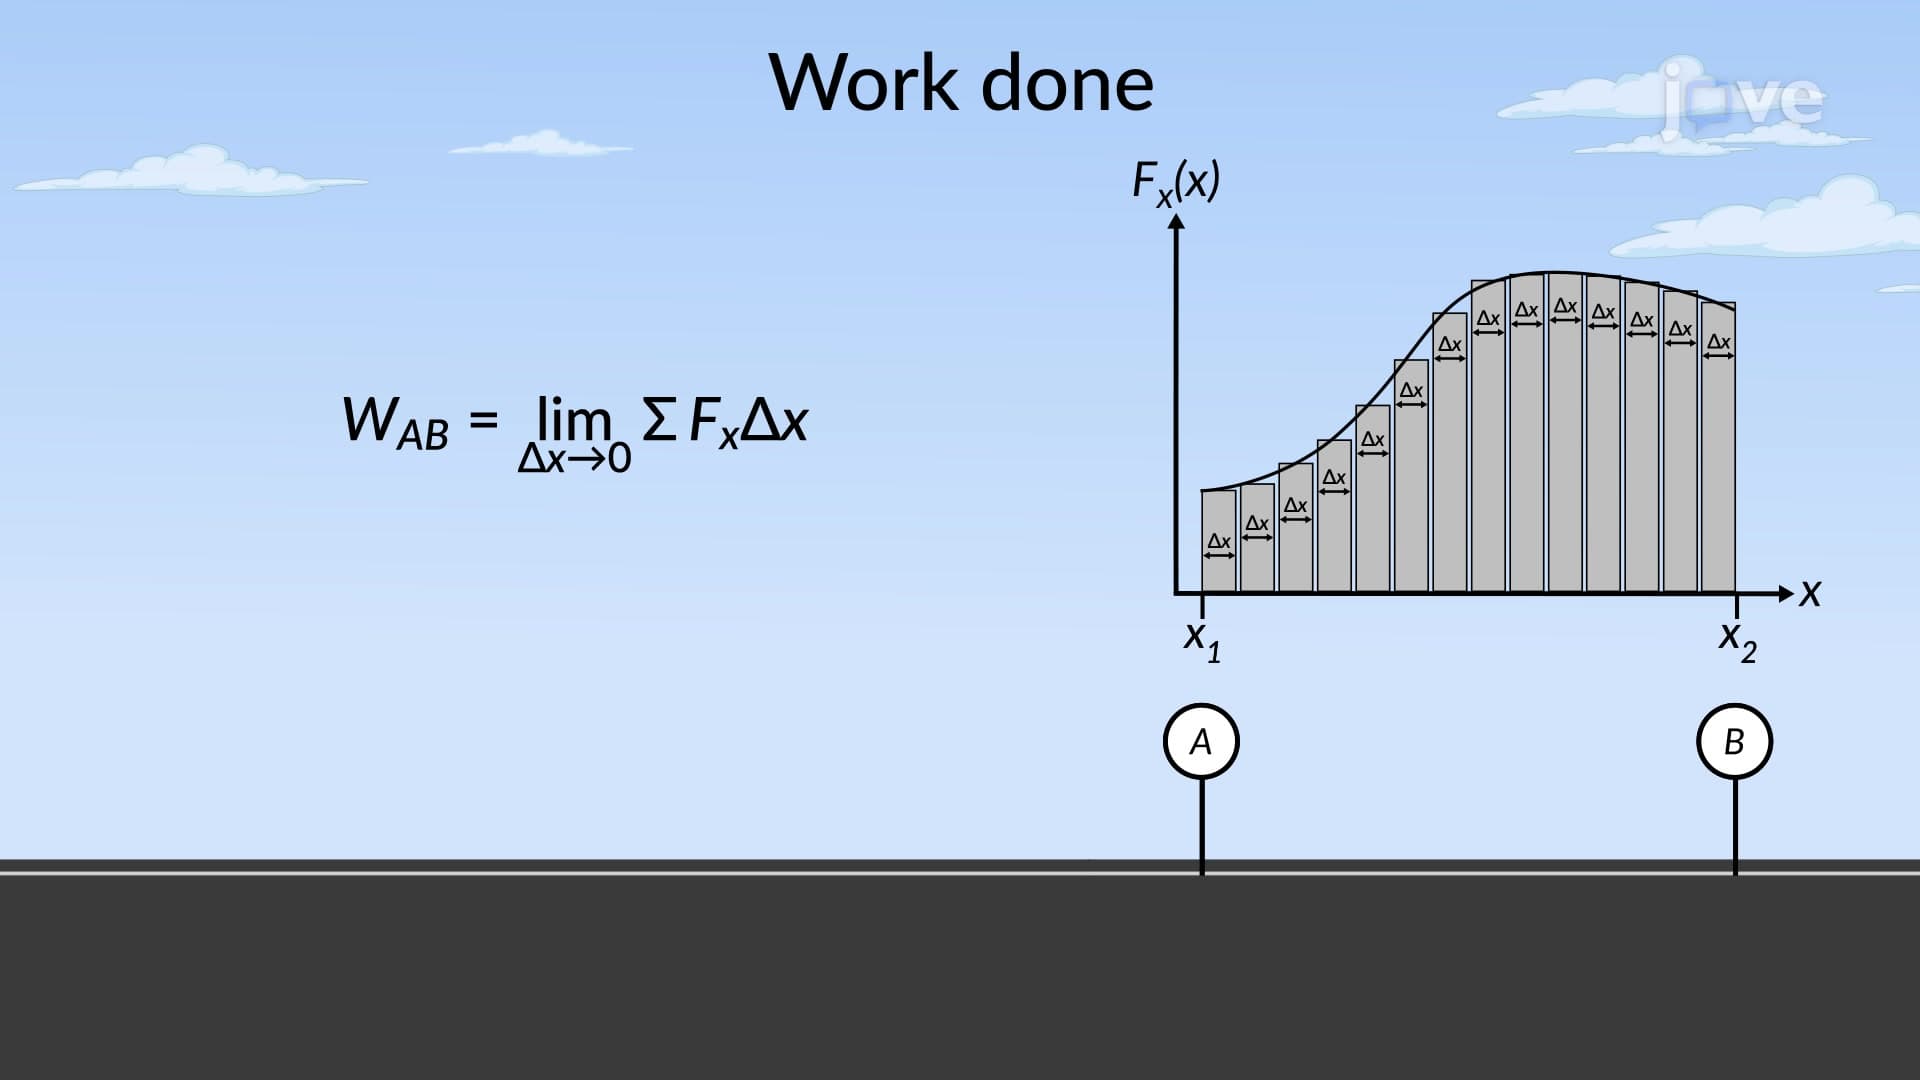
Work and Energy for Variable Forces
 01:01
Production Efficiency
 01:37
Energy to Drive Translocation
Generally, polypeptides are unfolded by two distinct...
 01:16
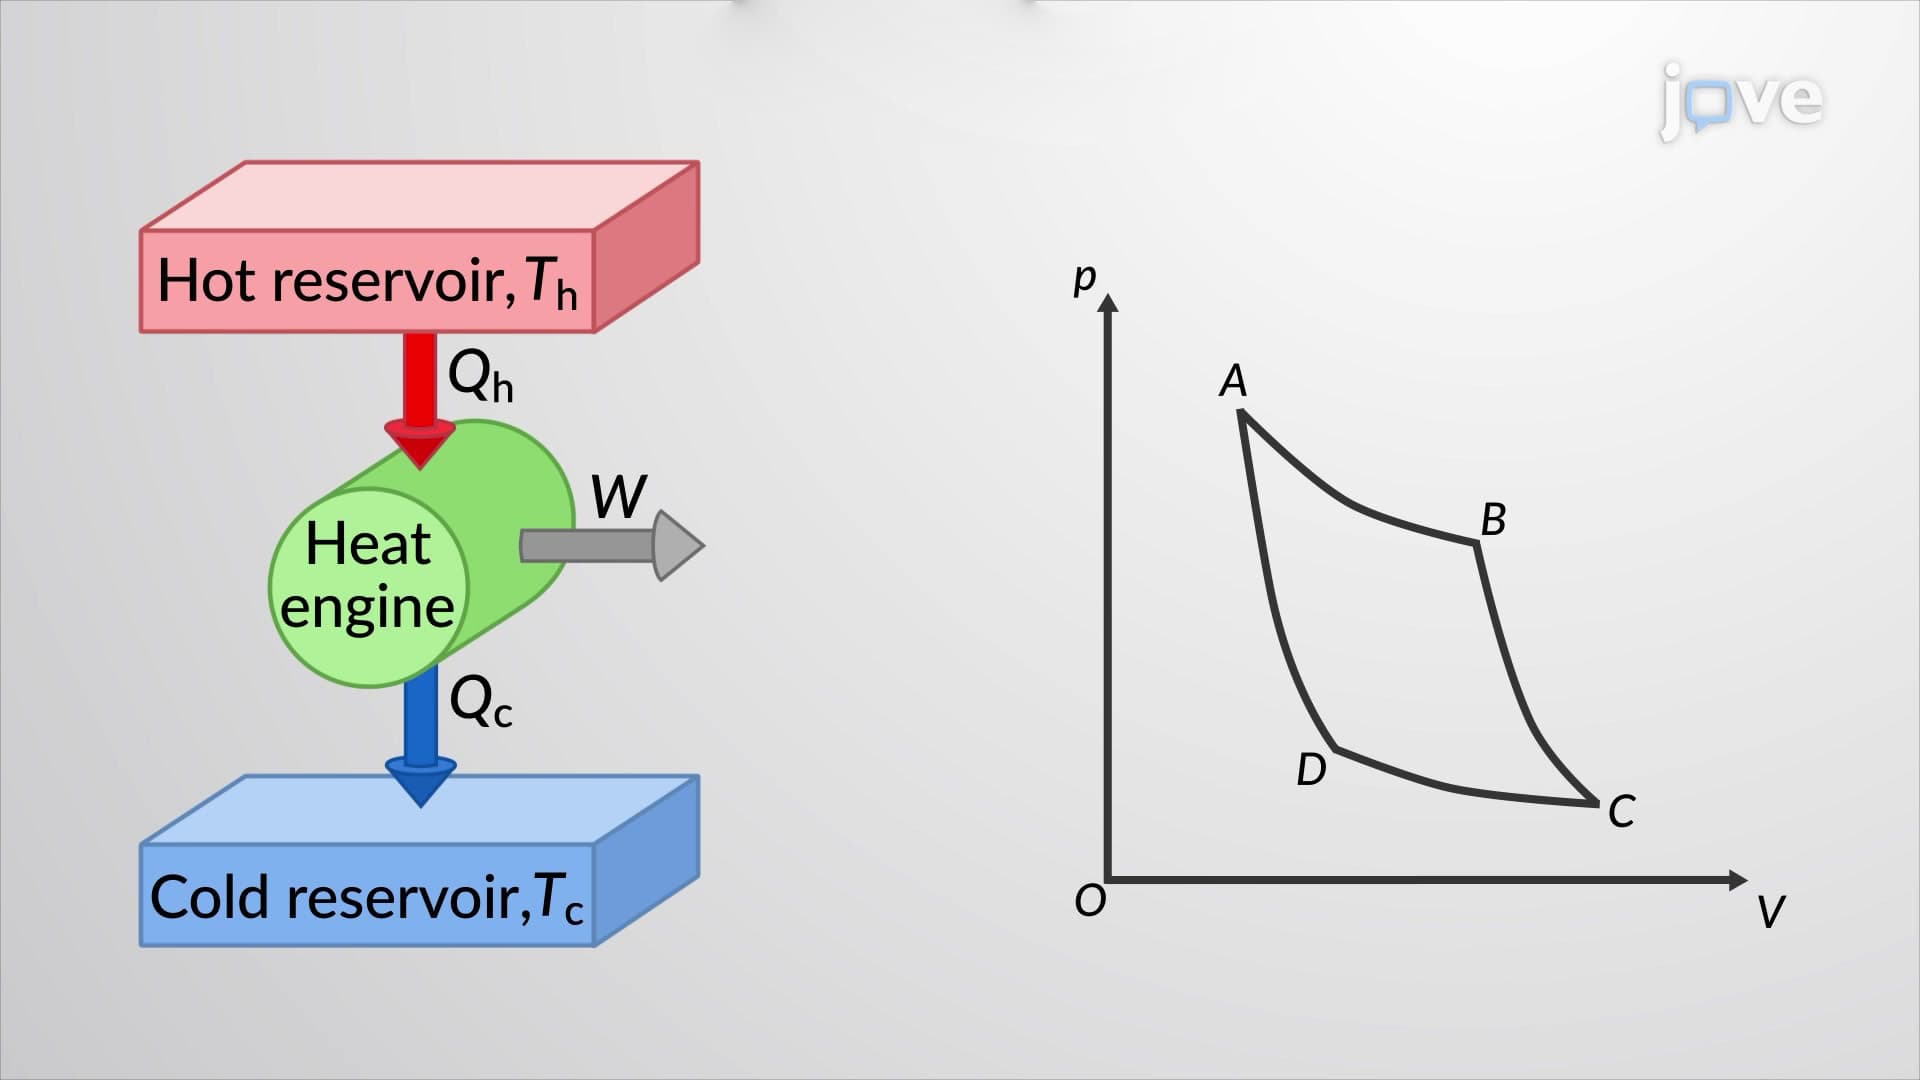
Efficiency of The Carnot Cycle