Hierarchical Shared Control of Cane-Type Walking-Aid Robot
Related Experiment Video
Updated: Feb 19, 2026
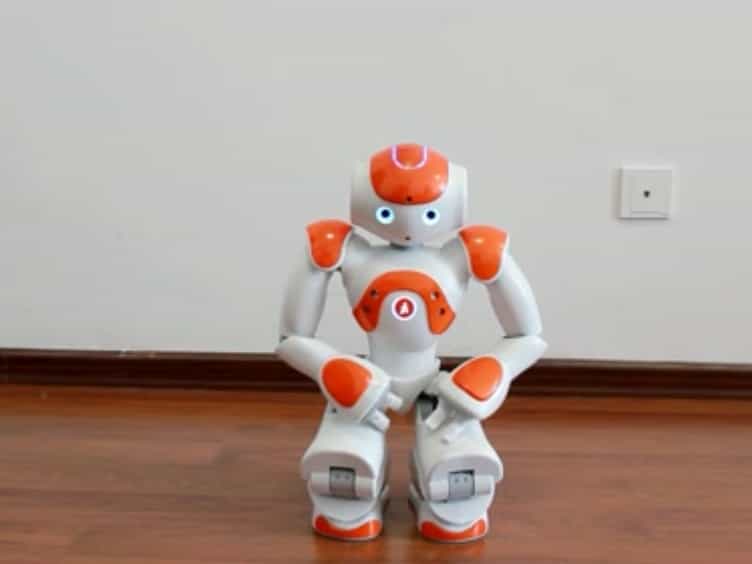
SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Chunjing Tao1, Qingyang Yan2, Yitong Li3
1Beijing Key Laboratory of Rehabilitation Technical Aids for Old-Age Disability, The National Research Centre for Rehabilitation Technical Aids, Beijing 100176, China.

Abstract:
A hierarchical shared-control method of the walking-aid robot for both human motion intention recognition and the obstacle emergency-avoidance method based on artificial potential field (APF) is proposed in this paper. The human motion intention is obtained from the interaction force measurements of the sensory system composed of 4 force-sensing registers (FSR) and a torque sensor. Meanwhile, a laser-range finder (LRF) forward is applied to detect the obstacles and try to guide the operator based on the repulsion force calculated by artificial potential field. An obstacle emergency-avoidance method which comprises different control strategies is also assumed according to the different states of obstacles or emergency cases. To ensure the user's safety, the hierarchical shared-control method combines the intention recognition method with the obstacle emergency-avoidance method based on the distance between the walking-aid robot and the obstacles. At last, experiments validate the effectiveness of the proposed hierarchical shared-control method.


Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...