Controllability of fractional higher order stochastic integrodifferential systems with fractional Brownian motion

T Sathiyaraj1, P Balasubramaniam1

  • 1Department of Mathematics, The Gandhigram Rural Institute - Deemed University, Gandhigram 624302, Dindigul, Tamil Nadu, India.

ISA Transactions
|December 5, 2017
PubMed

Related Concept Videos

BIBO stability of continuous and discrete -time systems01:24

BIBO stability of continuous and discrete -time systems

System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
950
Integration of Rational Functions Using Partial Fractions01:29

Integration of Rational Functions Using Partial Fractions
Rational functions are expressions written as the ratio of two polynomials, and their integrals are evaluated by simplifying the integrand into manageable parts. These functions are classified as proper or improper based on the degrees of the numerator and denominator.A rational function is proper when the degree of the numerator is less than the degree of the denominator. In this case, partial fraction decomposition is used to rewrite the function as a sum of simpler rational terms. The...
116
Improper Integrals: Infinite Intervals01:29

Improper Integrals: Infinite Intervals

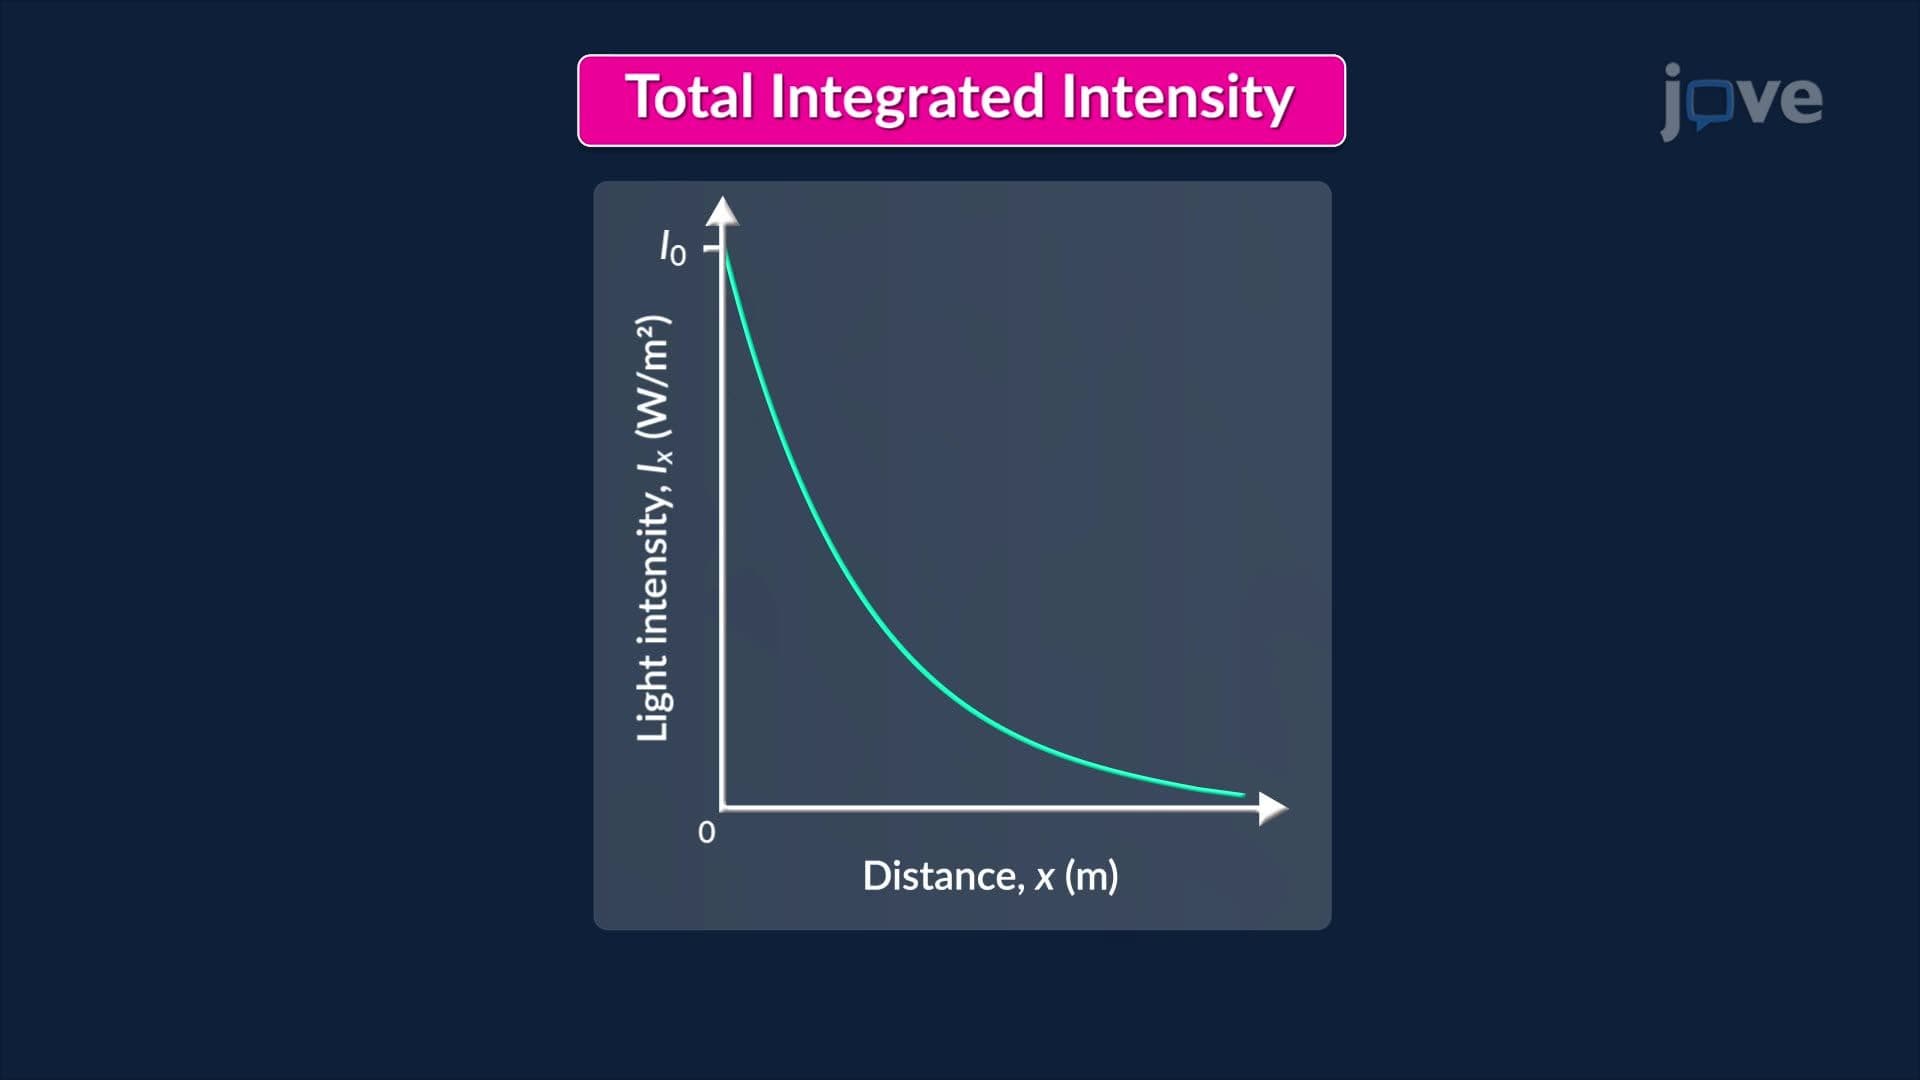
An integral is classified as improper due to an infinite interval when at least one of its limits of integration extends to positive or negative infinity. In such cases, the region under the curve is unbounded, and standard techniques for evaluating definite integrals are not directly applicable. Instead, the improper integral is defined through a limiting process that allows one to determine whether the accumulated area remains finite despite the infinite domain.Application to Exponential...
122
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
416
Linear Differential Equations01:27

Linear Differential Equations

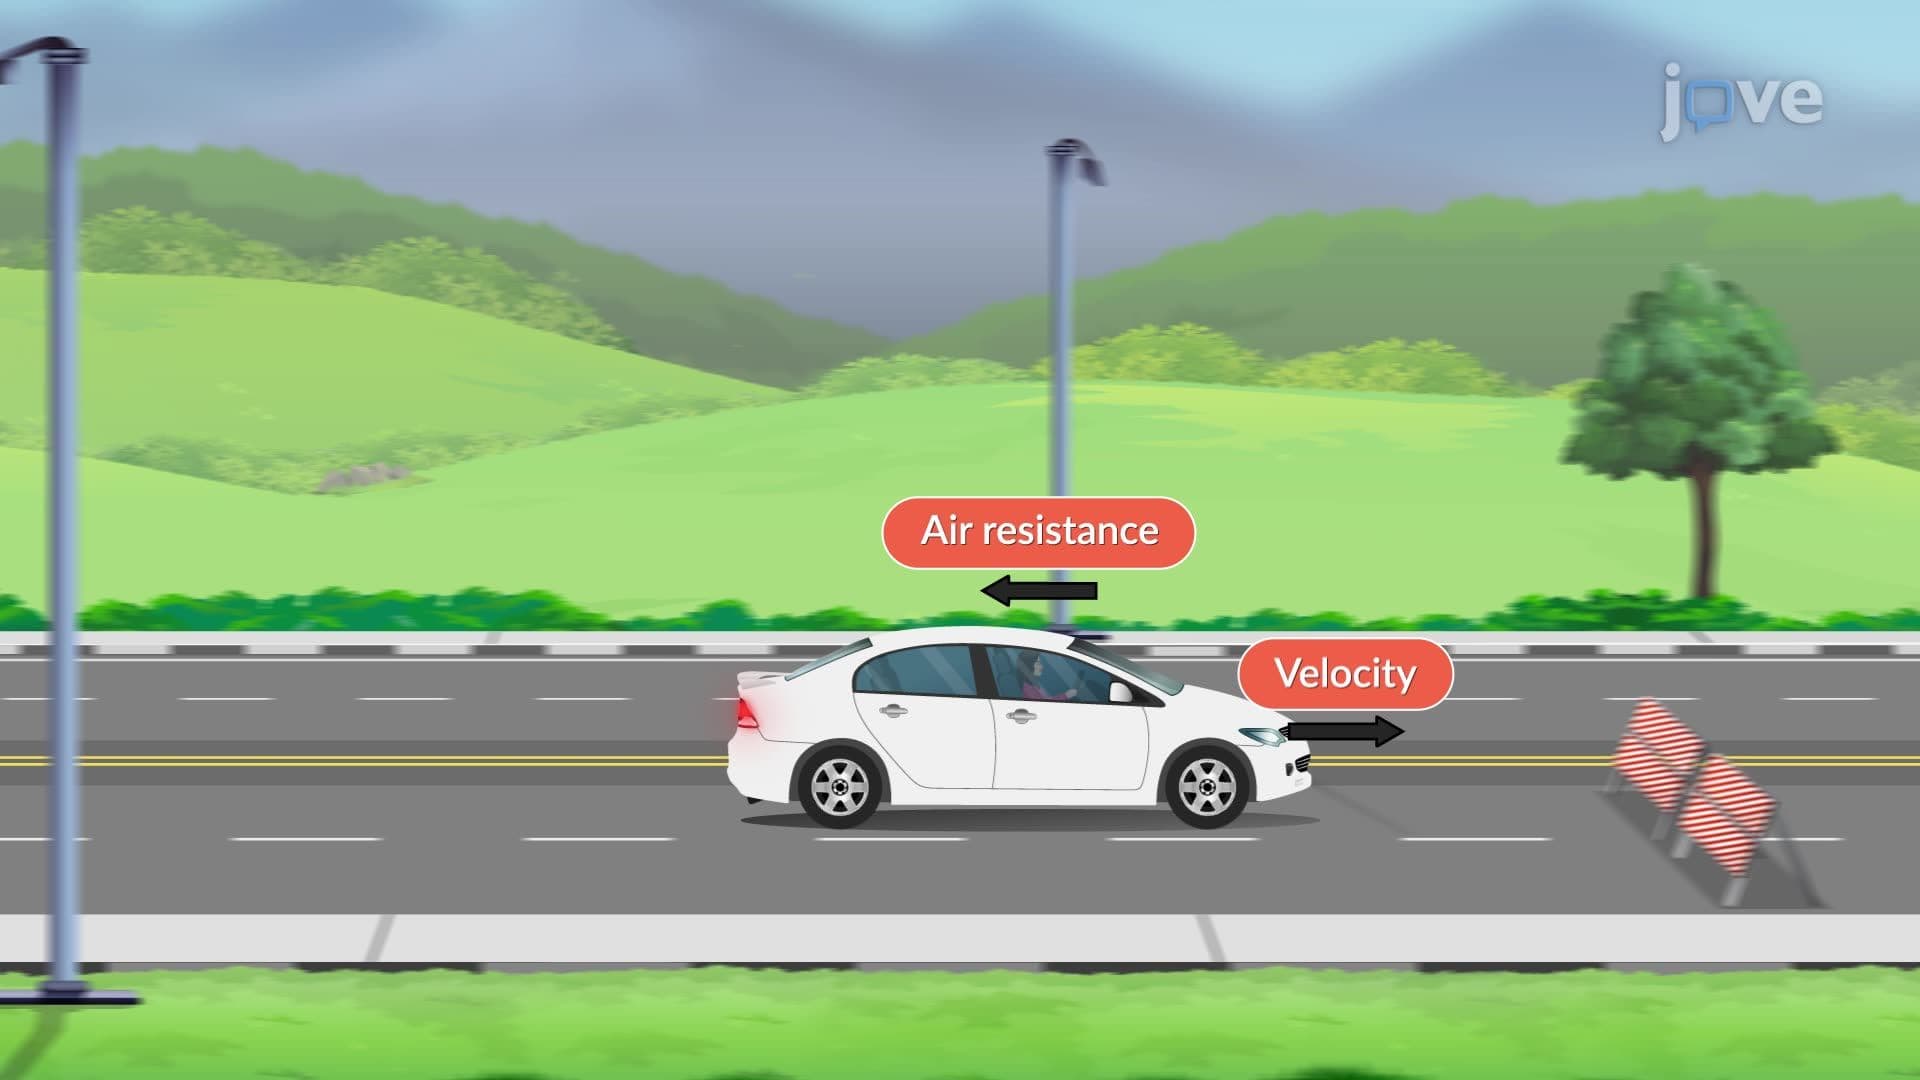
The integrating factor method provides a systematic way to solve first-order linear differential equations, especially those that cannot be handled by separation of variables. This method is particularly useful in modeling time-dependent physical systems influenced by both constant inputs and resistive forces. A common example is the motion of a car subjected to a constant engine force while experiencing air resistance proportional to its velocity.In such scenarios, Newton’s second law...
113
First Order Systems01:21

First Order Systems

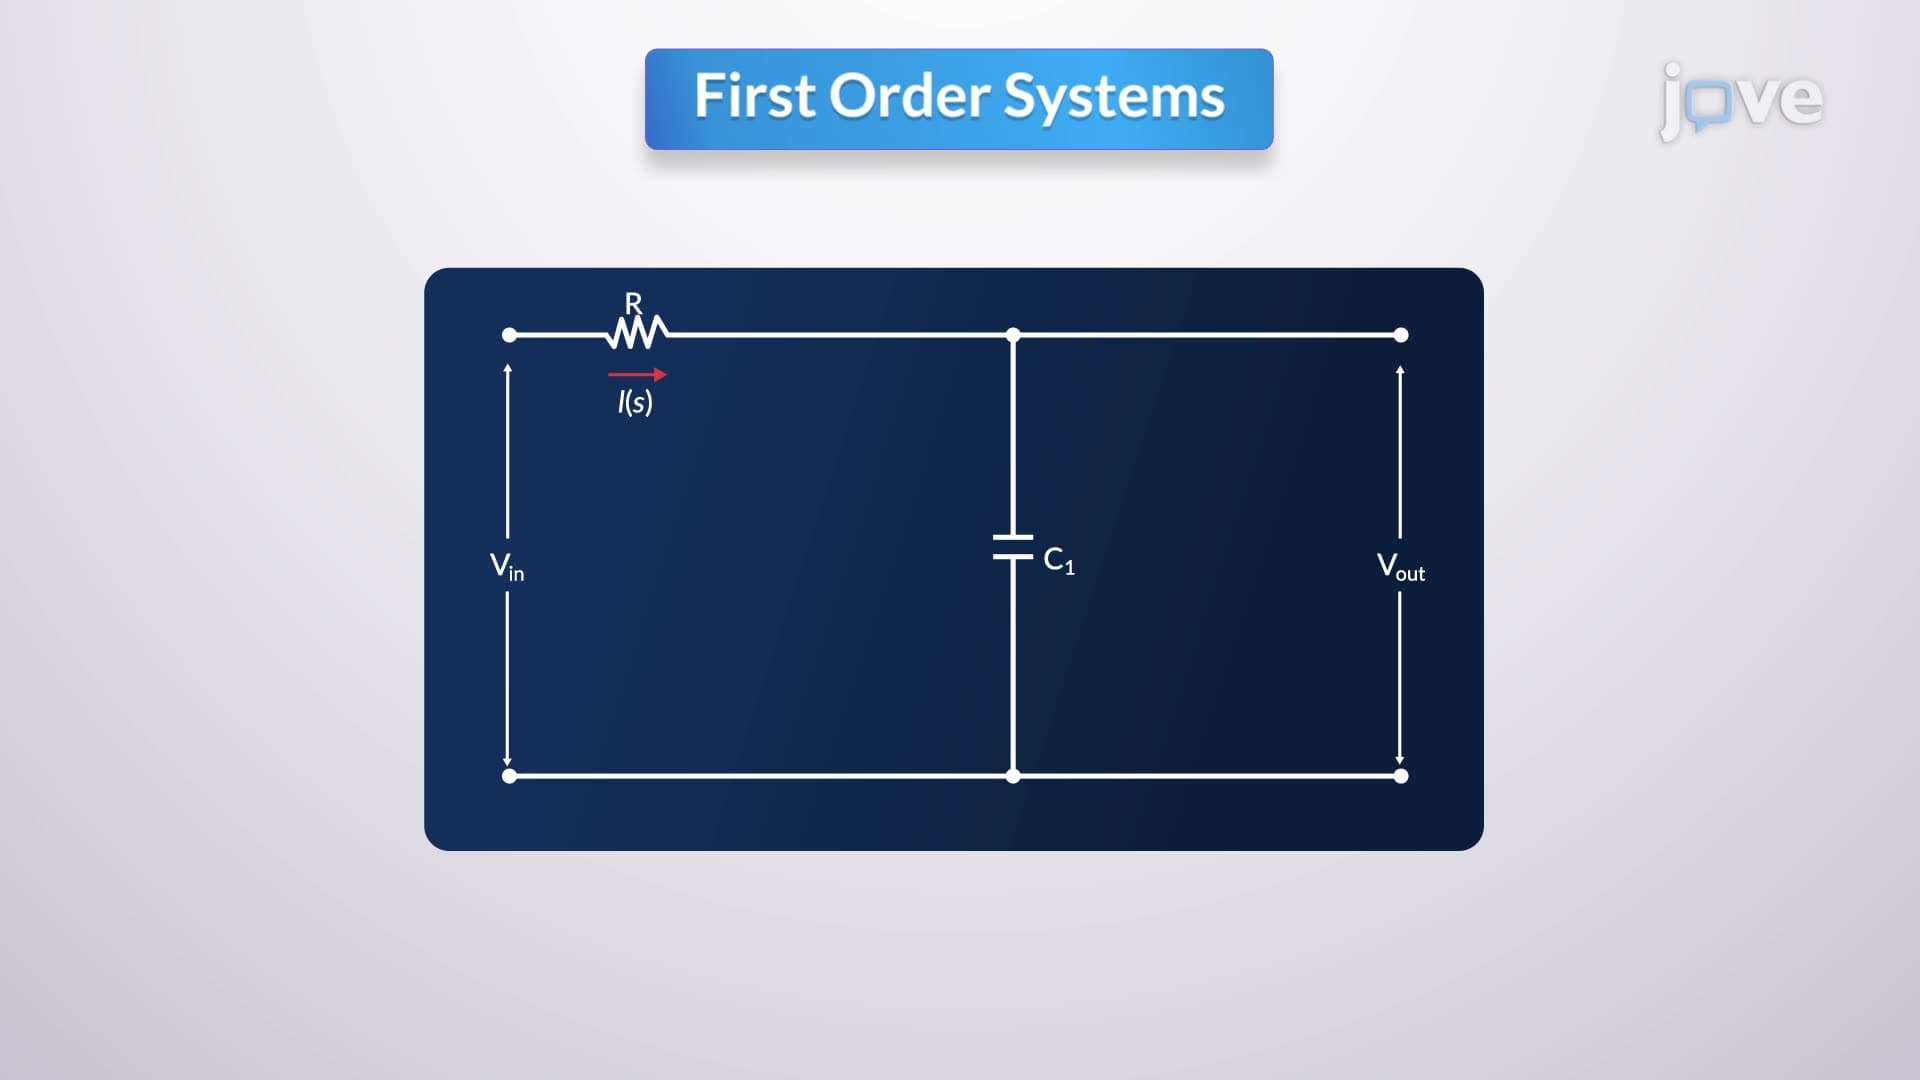
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
440