

Adaptive state observer for nonlinear systems with time-varying gain and output restrictions
Iván Hernández1, Isaac Chairez2, Luis Ibarra1
1Institute of Advanced Materials for Sustainable Manufacturing, Tecnologico de Monterrey, Tlalpan, CdMx, 14380, Mexico.

Abstract:
This paper proposes a novel adaptive state observer for nonlinear systems with uncertain mathematical models and output restrictions. The main contribution is the development of an observer architecture that does not require an accurate system model for its implementation. Instead, only a nominal reference model (A∗,B∗) defined around the operating conditions of the system is required, while the observer matrices and gain are adaptively adjusted online to compensate for modeling uncertainties and time-varying dynamics. This feature enables state estimation even when the available model differs from the actual system, overcoming a common limitation of conventional model-based observers. The proposed observer preserves a simple affine structure with a Luenberger-like gain while incorporating adaptation mechanisms for both the observer dynamics and the gain. A Lyapunov-based analysis is developed to establish sufficient conditions for boundedness, asymptotic convergence of the estimation error, and stability of the adaptive laws. The effect of output restrictions on the estimation process is also analyzed. The proposed methodology is validated through two complementary case studies. First, a time-varying linear benchmark system is employed to systematically analyze the adaptation capabilities, transient behavior, and robustness of the observer under controlled parameter variations. Second, the observer is implemented on a robotic manipulator, which constitutes a nonlinear system and provides an experimental assessment of the proposed approach. The results show that the proposed observer accurately tracks the system states despite model uncertainties and achieves faster convergence, smaller transient peaks, and greater robustness to measurement noise than a high-gain observer designed using the same reference model. These results confirm the effectiveness and practical applicability of the proposed adaptive observer for nonlinear systems under output restrictions.
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:18
Second Order systems II
If ζ...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
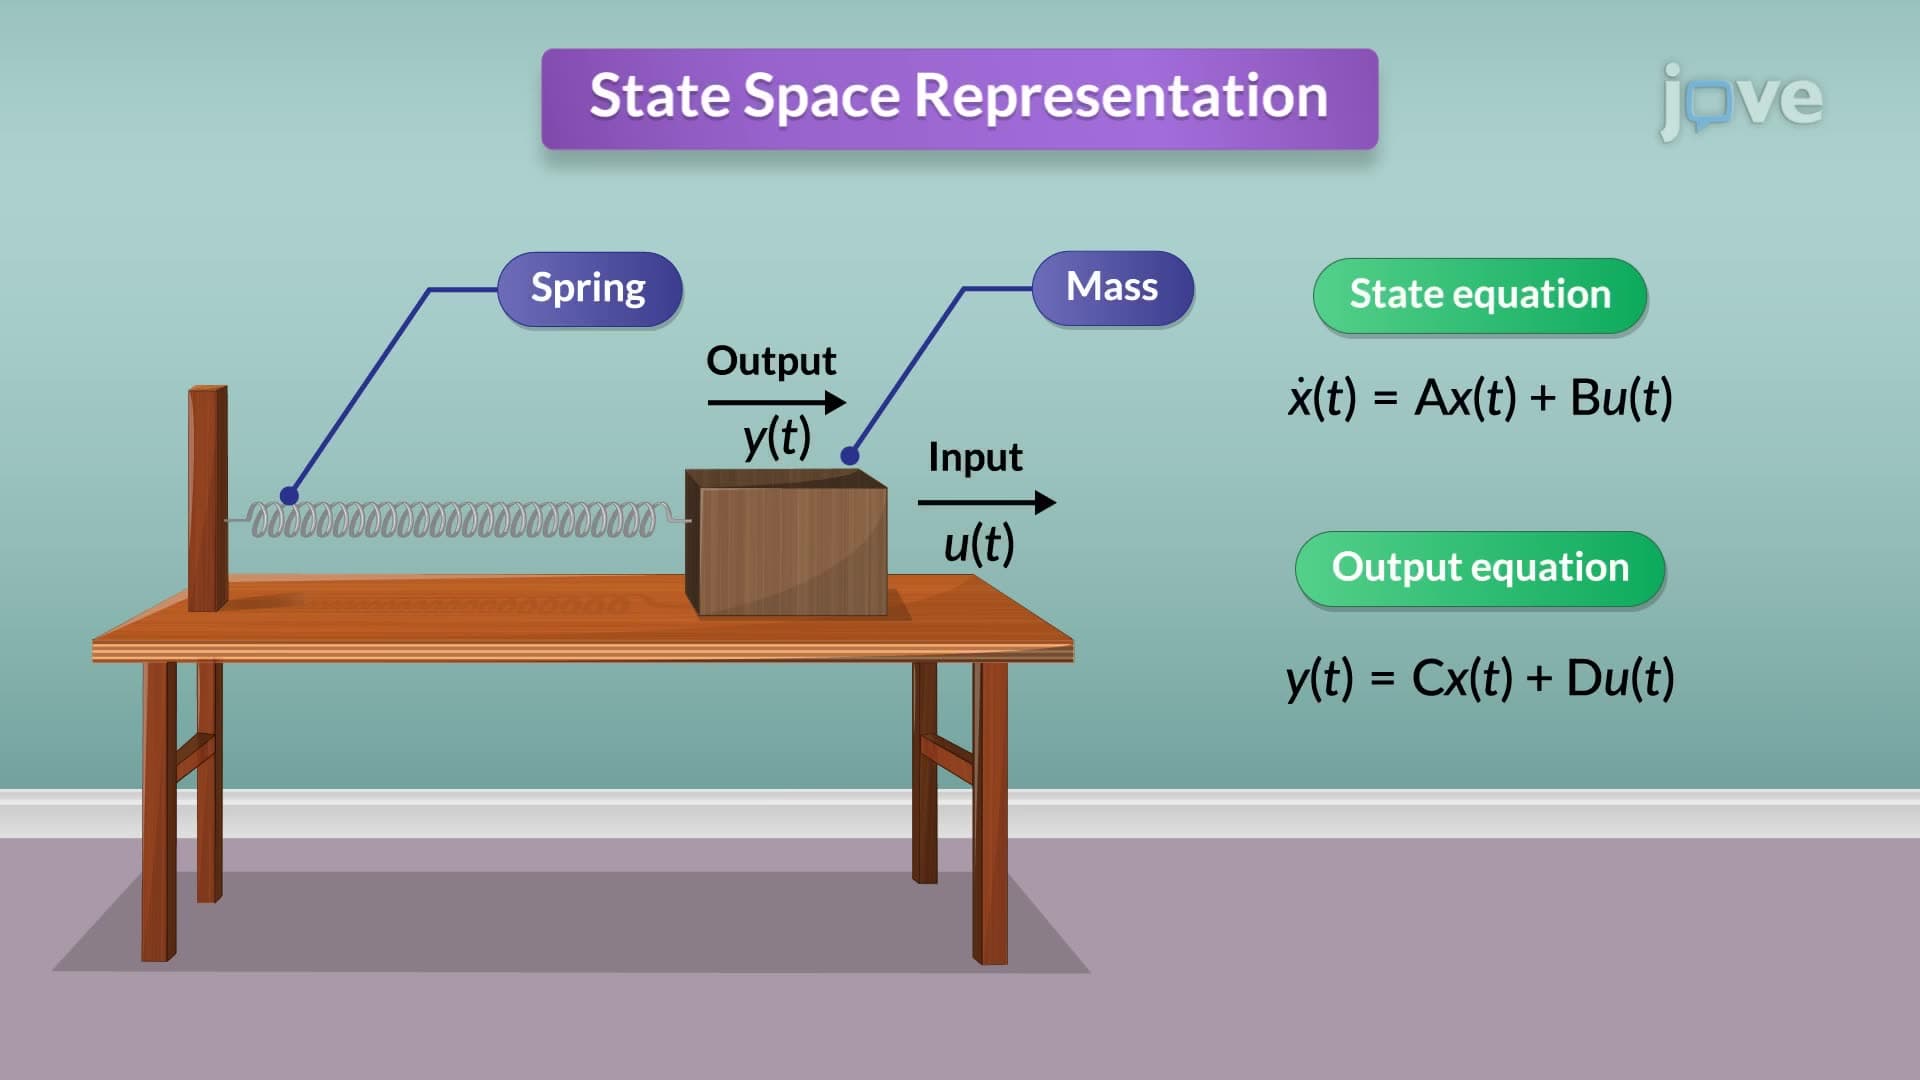
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: