Related Experiment Videos
Learning state-space models with Kolmogorov-Arnold networks: an autonomous underwater engineering perspective
Daniele Masti1, Alberto Petrucci1, Davide Grande2
1Gran Sasso Science Institute - Viale Francesco Crispi, 7 - 67100 L'Aquila AQ, Italy.

Abstract:
This paper investigates Kolmogorov-Arnold Networks (KANs) as parametrisations of learned nonlinear state-space models in control-relevant settings. We ask whether replacing standard MLP maps with KAN-based ones yields a useful trade-off between predictive accuracy and deployability-oriented properties such as compactness, smoothness, and post hoc inspectability, with particular focus on underwater robotics. To study this question, we use a common autoencoder-based identification backbone and instantiate two KAN-based identification realisations, comparing their performance with their MLP-parametrised counterparts under the same training pipeline. The evaluation covers maritime robotics benchmarks of increasing difficulty, including autonomous underwater vehicles and a disturbance-driven underwater glider, as well as standard nonlinear system-identification datasets. Across these case studies, KAN-based models remain competitive in predictive performance while often using fewer parameters and, in several settings, supporting symbolic extraction of learned nonlinear features.
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
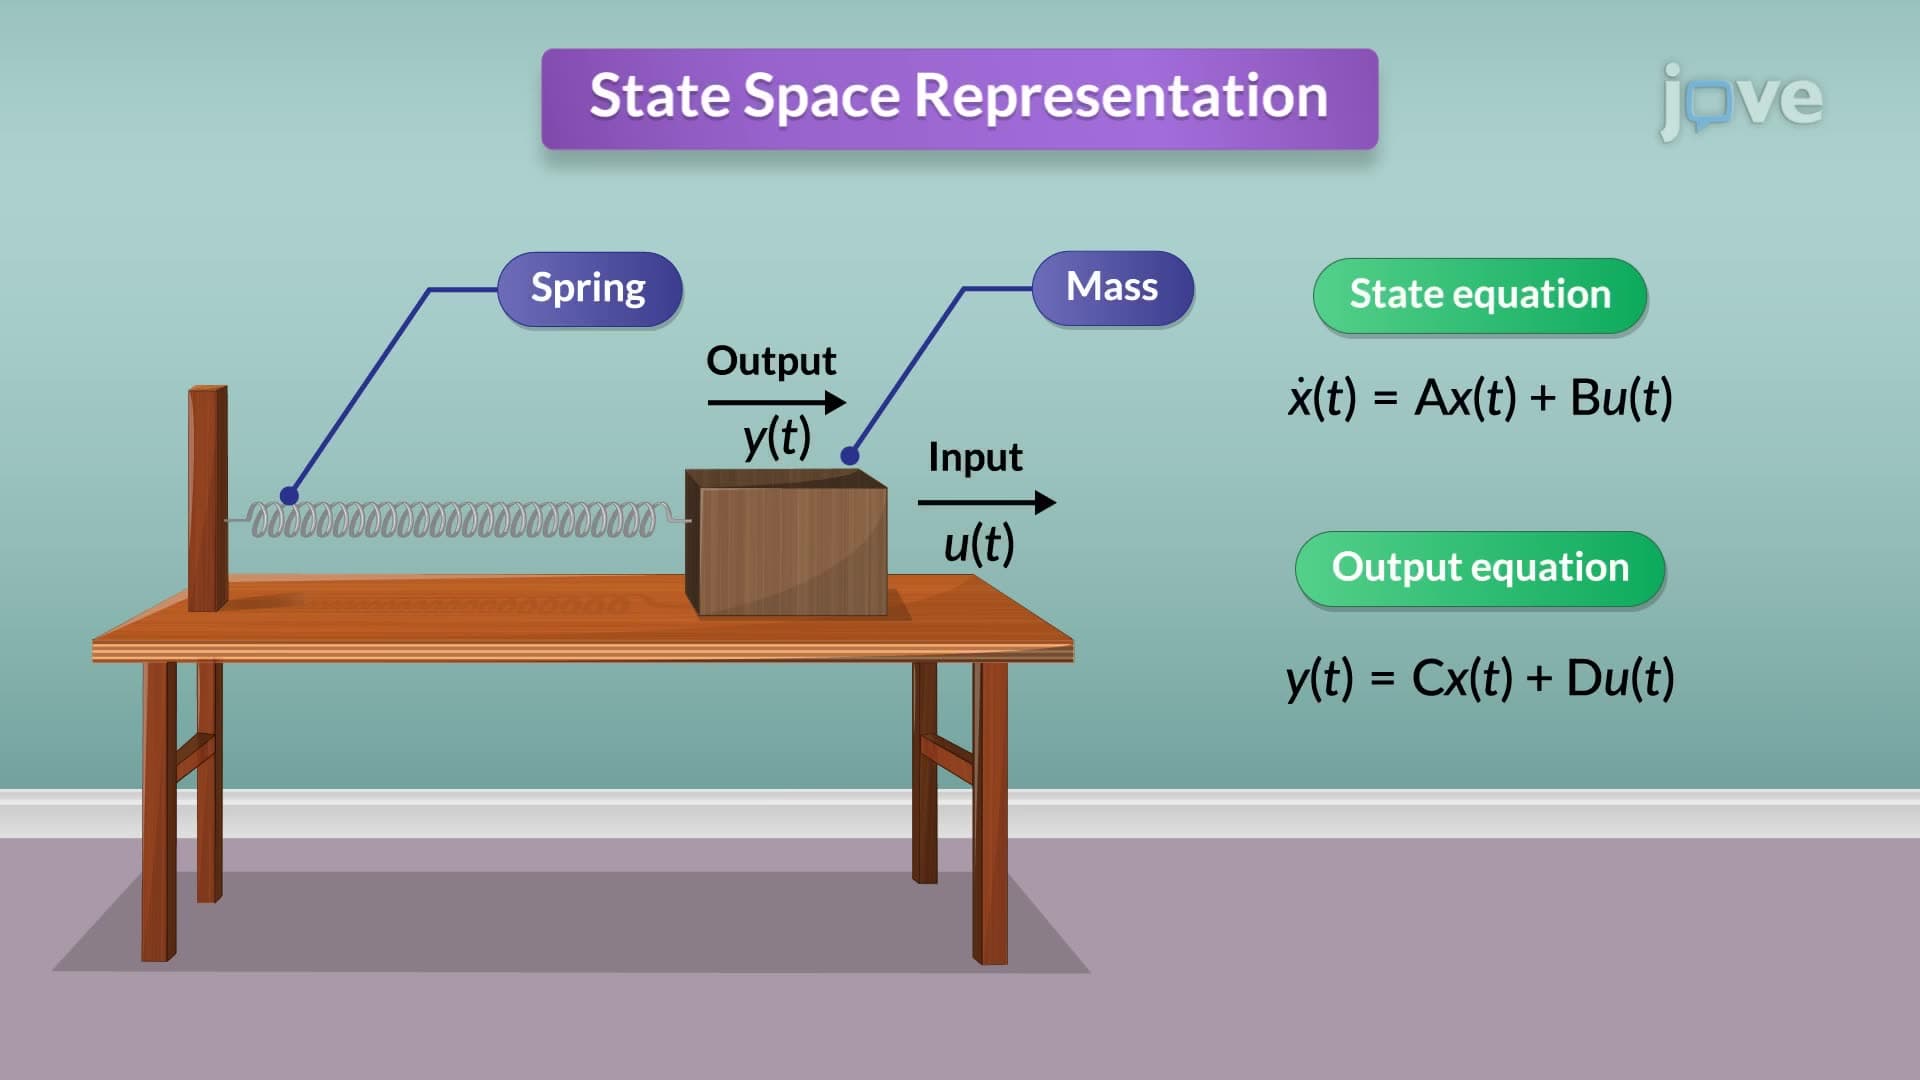 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
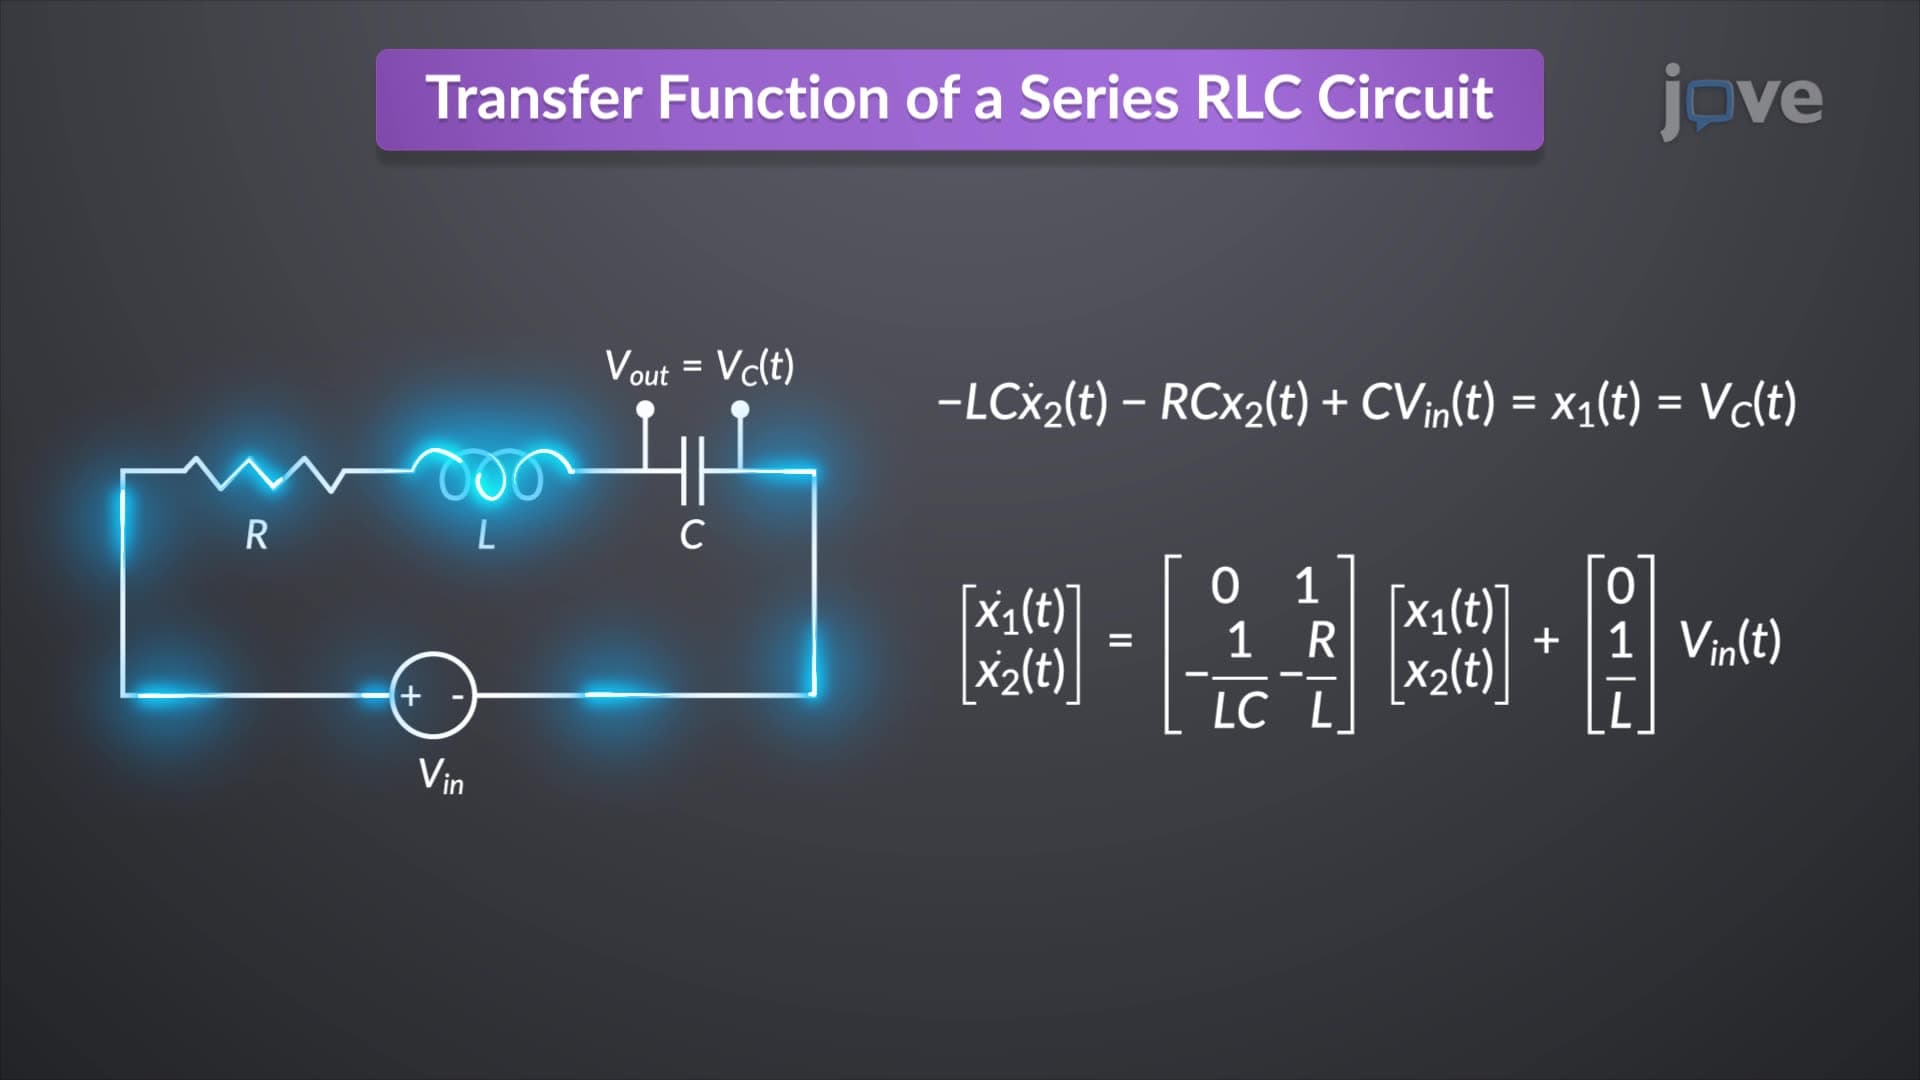
Transfer Function to State Space
In an RLC...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:25
Modeling with Differential Equations