Related Experiment Video
Updated: Feb 17, 2026
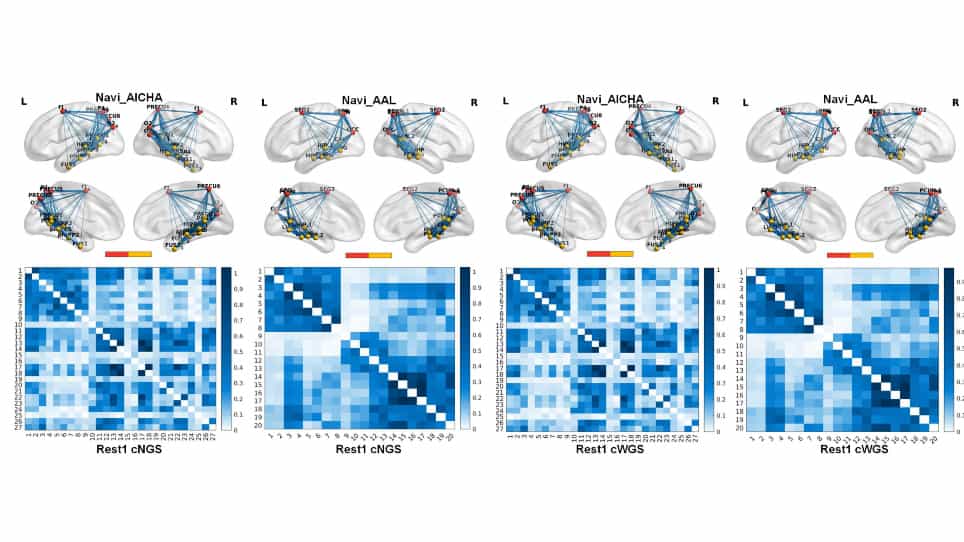

Modeling the Functional Network for Spatial Navigation in the Human Brain
Published on: October 13, 2023
An adaptive map-matching algorithm based on hierarchical fuzzy system from vehicular GPS data
Jinjun Tang1, Shen Zhang2, Yajie Zou3
1School of Traffic and Transportation Engineering, Key Laboratory of Smart Transport in Hunan Province, Central South University, Changsha, China.

Abstract:
An improved hierarchical fuzzy inference method based on C-measure map-matching algorithm is proposed in this paper, in which the C-measure represents the certainty or probability of the vehicle traveling on the actual road. A strategy is firstly introduced to use historical positioning information to employ curve-curve matching between vehicle trajectories and shapes of candidate roads. It improves matching performance by overcoming the disadvantage of traditional map-matching algorithm only considering current information. An average historical distance is used to measure similarity between vehicle trajectories and road shape. The input of system includes three variables: distance between position point and candidate roads, angle between driving heading and road direction, and average distance. As the number of fuzzy rules will increase exponentially when adding average distance as a variable, a hierarchical fuzzy inference system is then applied to reduce fuzzy rules and improve the calculation efficiency. Additionally, a learning process is updated to support the algorithm. Finally, a case study contains four different routes in Beijing city is used to validate the effectiveness and superiority of the proposed method.

Related Concept Videos
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device
 01:26
Errors in Global Positioning System
 01:28
Field Application of Global Positioning System
 01:30
Introduction to Global Positioning System
 01:21
Manipulation and Analysis
 01:25
Selected Data About Geographic Locations