Related Experiment Video
Updated: Feb 16, 2026
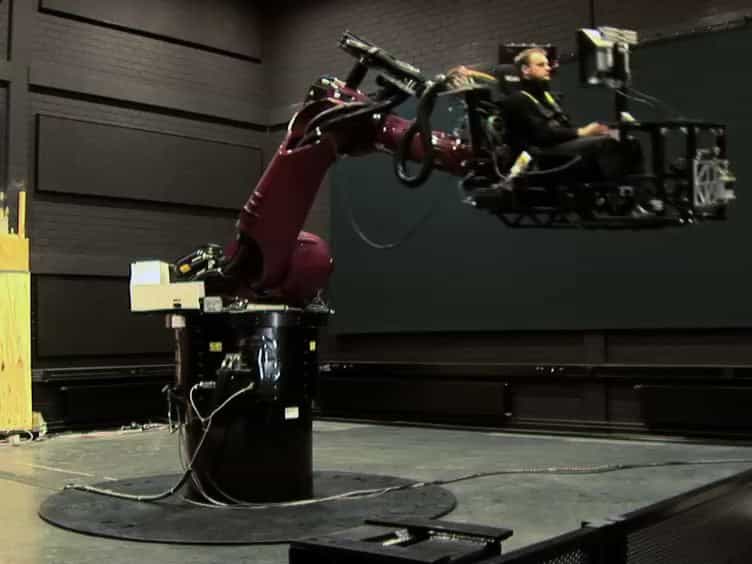

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Quantified, Interactive Simulation of AMCW ToF Camera Including Multipath Effects
David Bulczak1, Martin Lambers2, Andreas Kolb3
1Computer Graphics Group, Institute for Vision and Graphics, University of Siegen, 57076 Siegen, Germany. david.bulczak@uni-siegen.de.

Abstract:
In the last decade, Time-of-Flight (ToF) range cameras have gained increasing popularity in robotics, automotive industry, and home entertainment. Despite technological developments, ToF cameras still suffer from error sources such as multipath interference or motion artifacts. Thus, simulation of ToF cameras, including these artifacts, is important to improve camera and algorithm development. This paper presents a physically-based, interactive simulation technique for amplitude modulated continuous wave (AMCW) ToF cameras, which, among other error sources, includes single bounce indirect multipath interference based on an enhanced image-space approach. The simulation accounts for physical units down to the charge level accumulated in sensor pixels. Furthermore, we present the first quantified comparison for ToF camera simulators. We present bidirectional reference distribution function (BRDF) measurements for selected, purchasable materials in the near-infrared (NIR) range, craft real and synthetic scenes out of these materials and quantitatively compare the range sensor data.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 02:18
Interference and Diffraction
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:27
Uniform Depth Channel Flow