Related Experiment Video
Updated: Feb 15, 2026
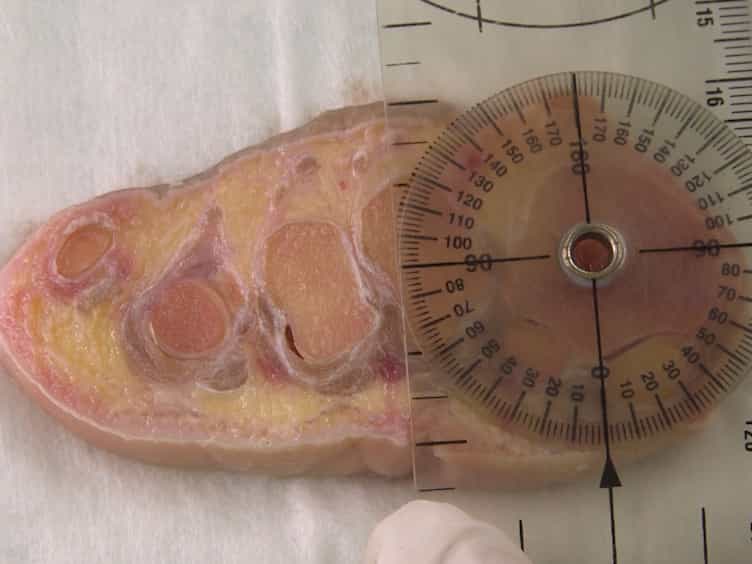

An Anatomical Study of Nerves at Risk During Minimally Invasive Hallux Valgus Surgery
Published on: February 17, 2018
Path planning for minimally-invasive knee surgery using a hybrid optimization procedure
Adam Ciszkiewicz1, Grzegorz Milewski1
1a Division of Experimental Mechanics and Biomechanics, Institute of Applied Mechanics , Cracow University of Technology , Cracow , Poland.

Abstract:
The aim of this study was to develop a procedure for medical tool path planning in minimally-invasive knee surgery. The collision-free paths for the tool were obtained using the control locations method with a hybrid optimization strategy. The tool and knee elements were described with surface meshes. The knee model allowed for bones displacement and variable incision size and location. The proposed procedure was proven to be effective in path planning for minimally-invasive surgery. It can serve as a valuable aid in surgery planning and may also be used in systems for autonomous or semi-autonomous knee surgery.
Related Concept Videos
 01:22
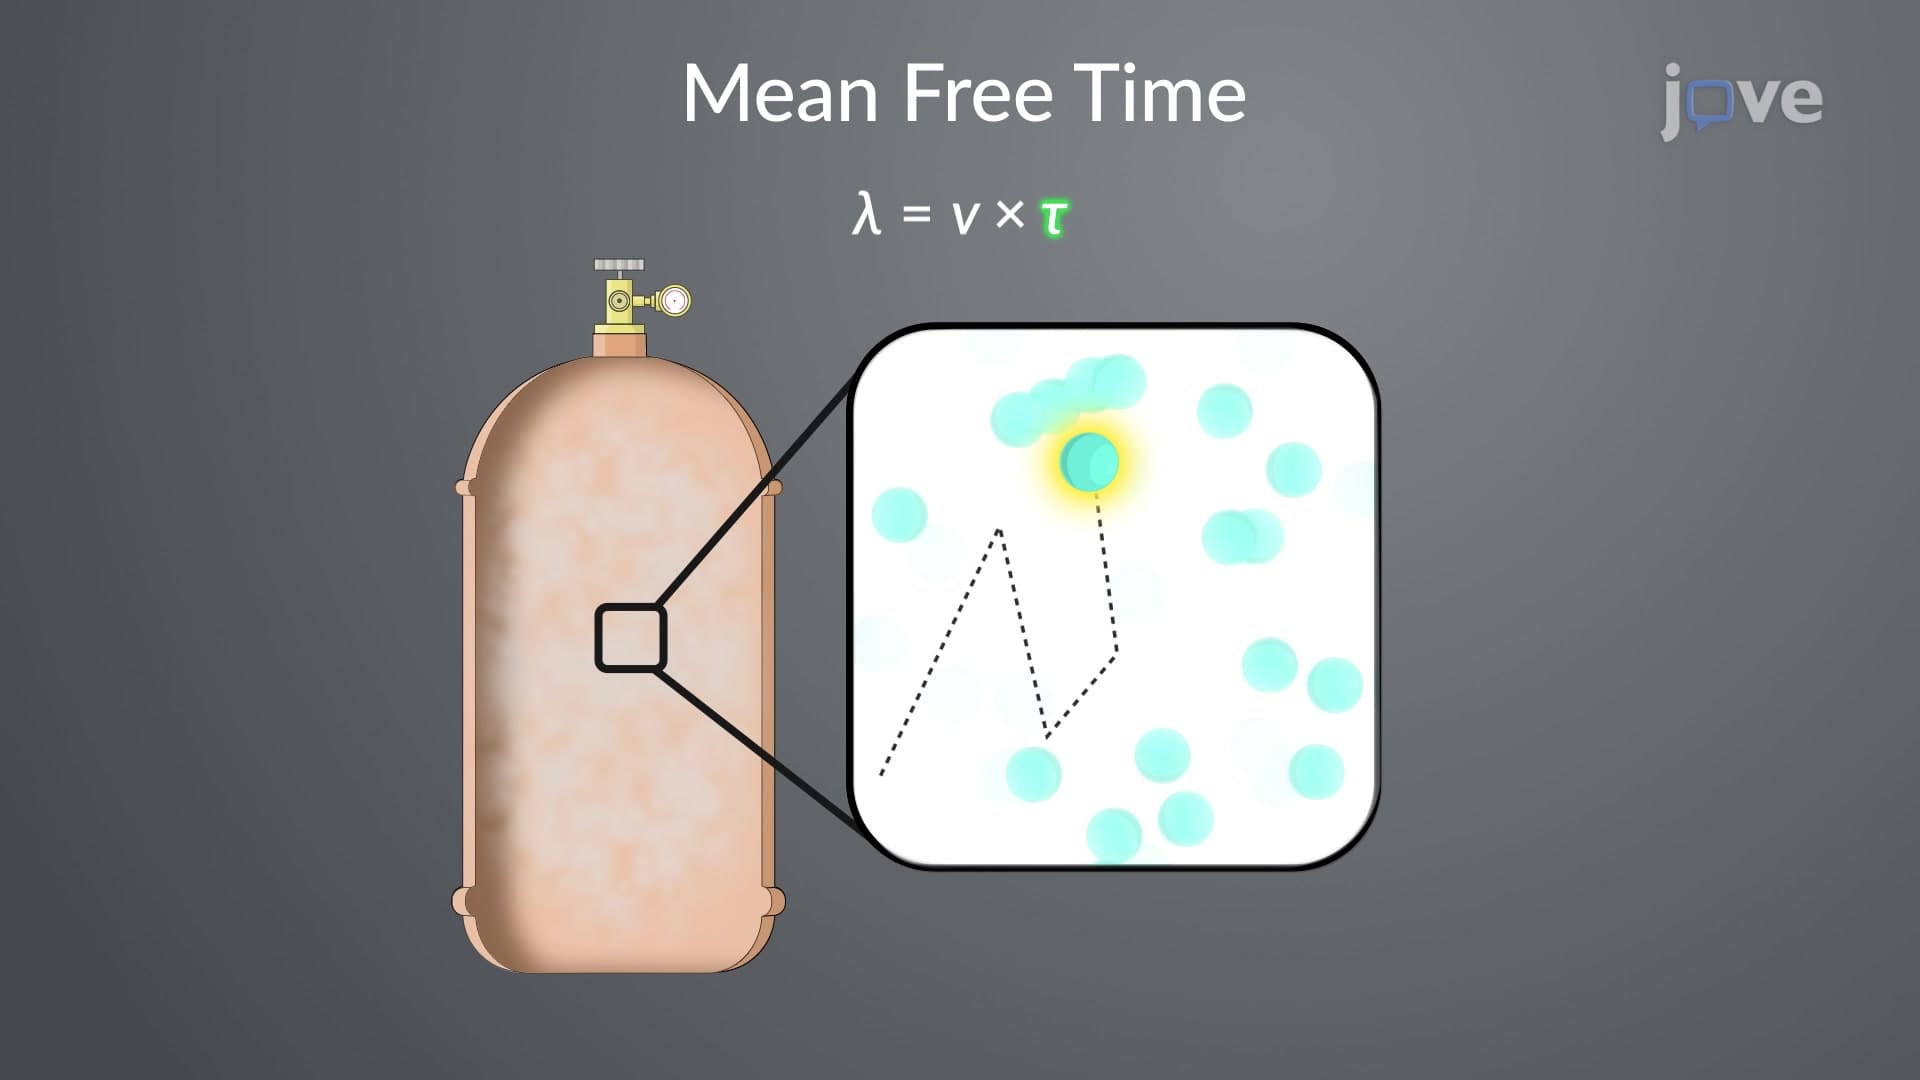
Mean free path and Mean free time
 01:21
Path Between Thermodynamics States
 01:10
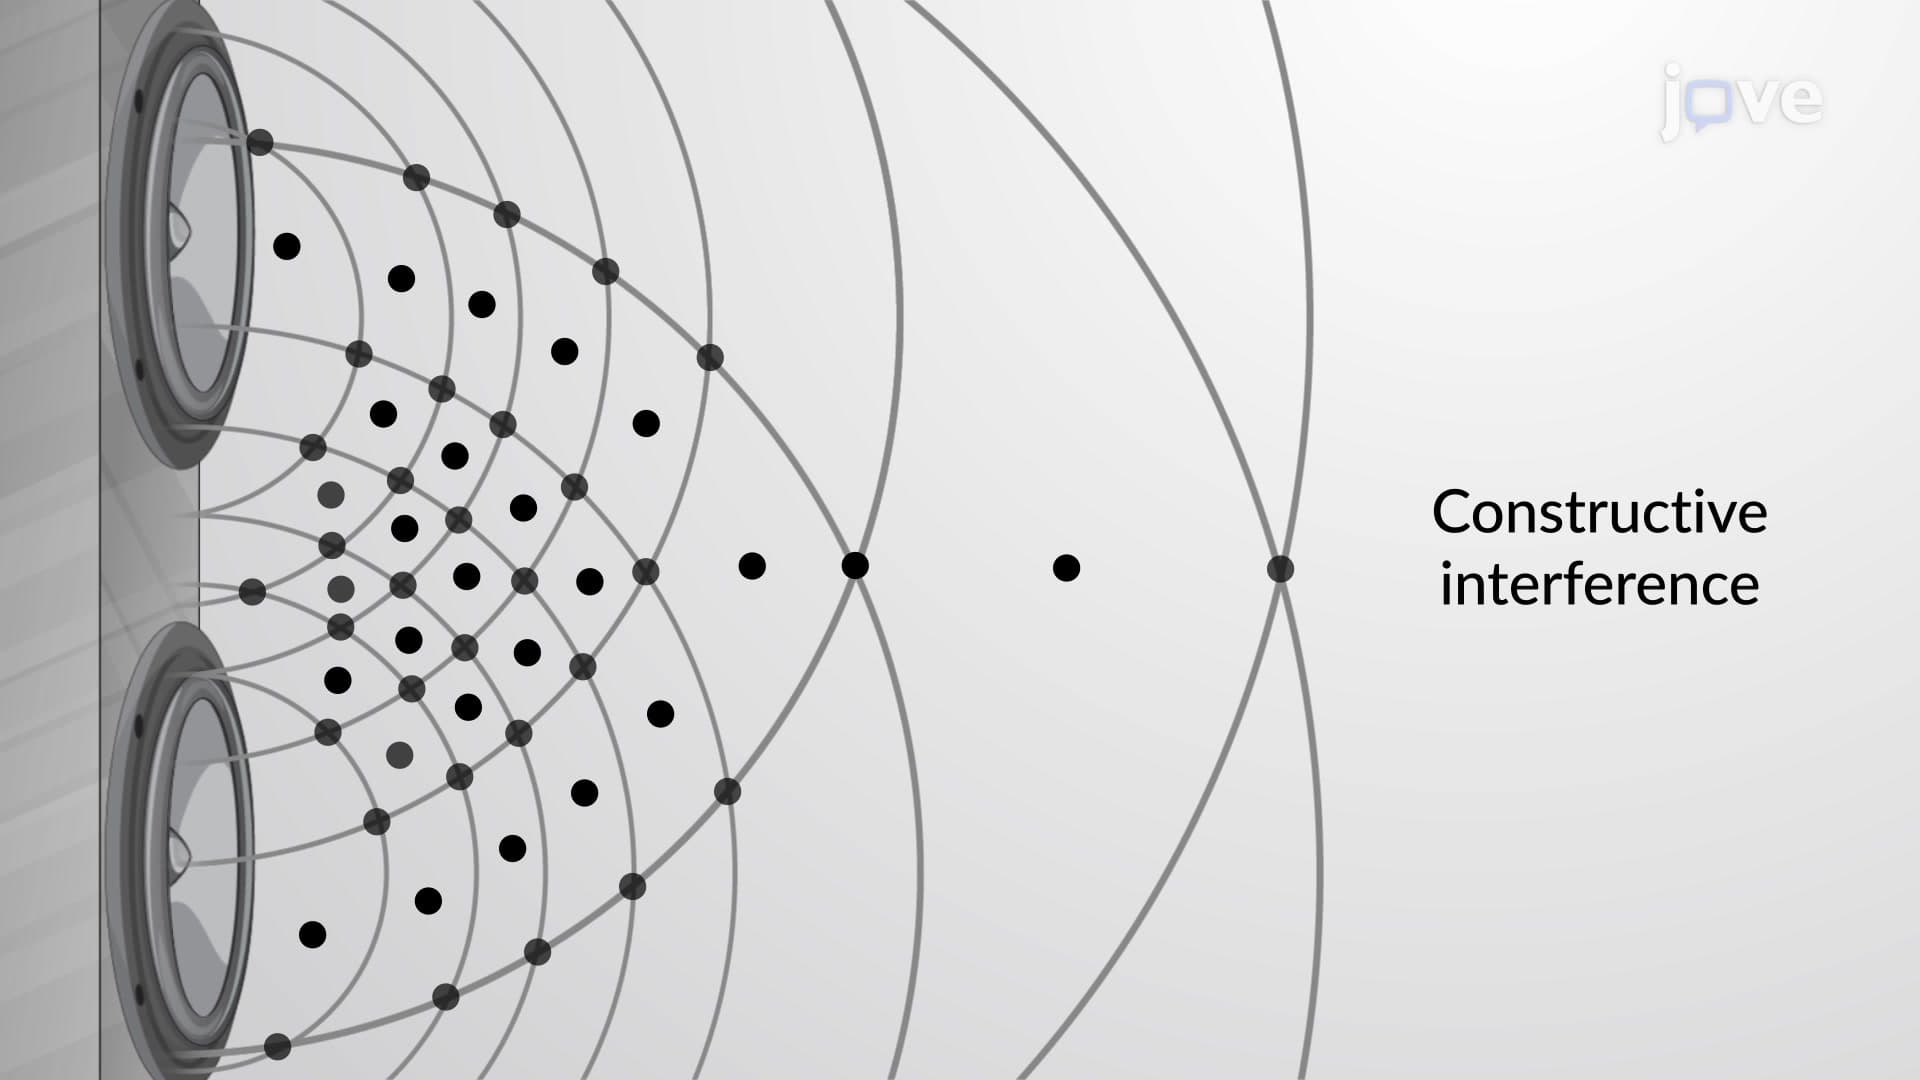
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
 02:29
Hybrid Zones
 03:48
Behavior of Gas Molecules: Molecular Diffusion, Mean Free Path, and Effusion