The Passive Series Stiffness That Optimizes Torque Tracking for a Lower-Limb Exoskeleton in Human Walking
Related Experiment Video
Updated: Feb 15, 2026
Lower-Limb Biomechanical Characteristics Associated with Unplanned Gait Termination Under Different Walking Speeds
Published on: August 25, 2020
Juanjuan Zhang1,2,3, Steven H Collins1,4,5
1Department of Mechanical Engineering, Carnegie Mellon University, Pittsburgh, PA, United States.

Abstract:
This study uses theory and experiments to investigate the relationship between the passive stiffness of series elastic actuators and torque tracking performance in lower-limb exoskeletons during human walking. Through theoretical analysis with our simplified system model, we found that the optimal passive stiffness matches the slope of the desired torque-angle relationship. We also conjectured that a bandwidth limit resulted in a maximum rate of change in torque error that can be commanded through control input, which is fixed across desired and passive stiffness conditions. This led to hypotheses about the interactions among optimal control gains, passive stiffness and desired quasi-stiffness. Walking experiments were conducted with multiple angle-based desired torque curves. The observed lowest torque tracking errors identified for each combination of desired and passive stiffnesses were shown to be linearly proportional to the magnitude of the difference between the two stiffnesses. The proportional gains corresponding to the lowest observed errors were seen inversely proportional to passive stiffness values and to desired stiffness. These findings supported our hypotheses, and provide guidance to application-specific hardware customization as well as controller design for torque-controlled robotic legged locomotion.
Related Concept Videos
 01:10
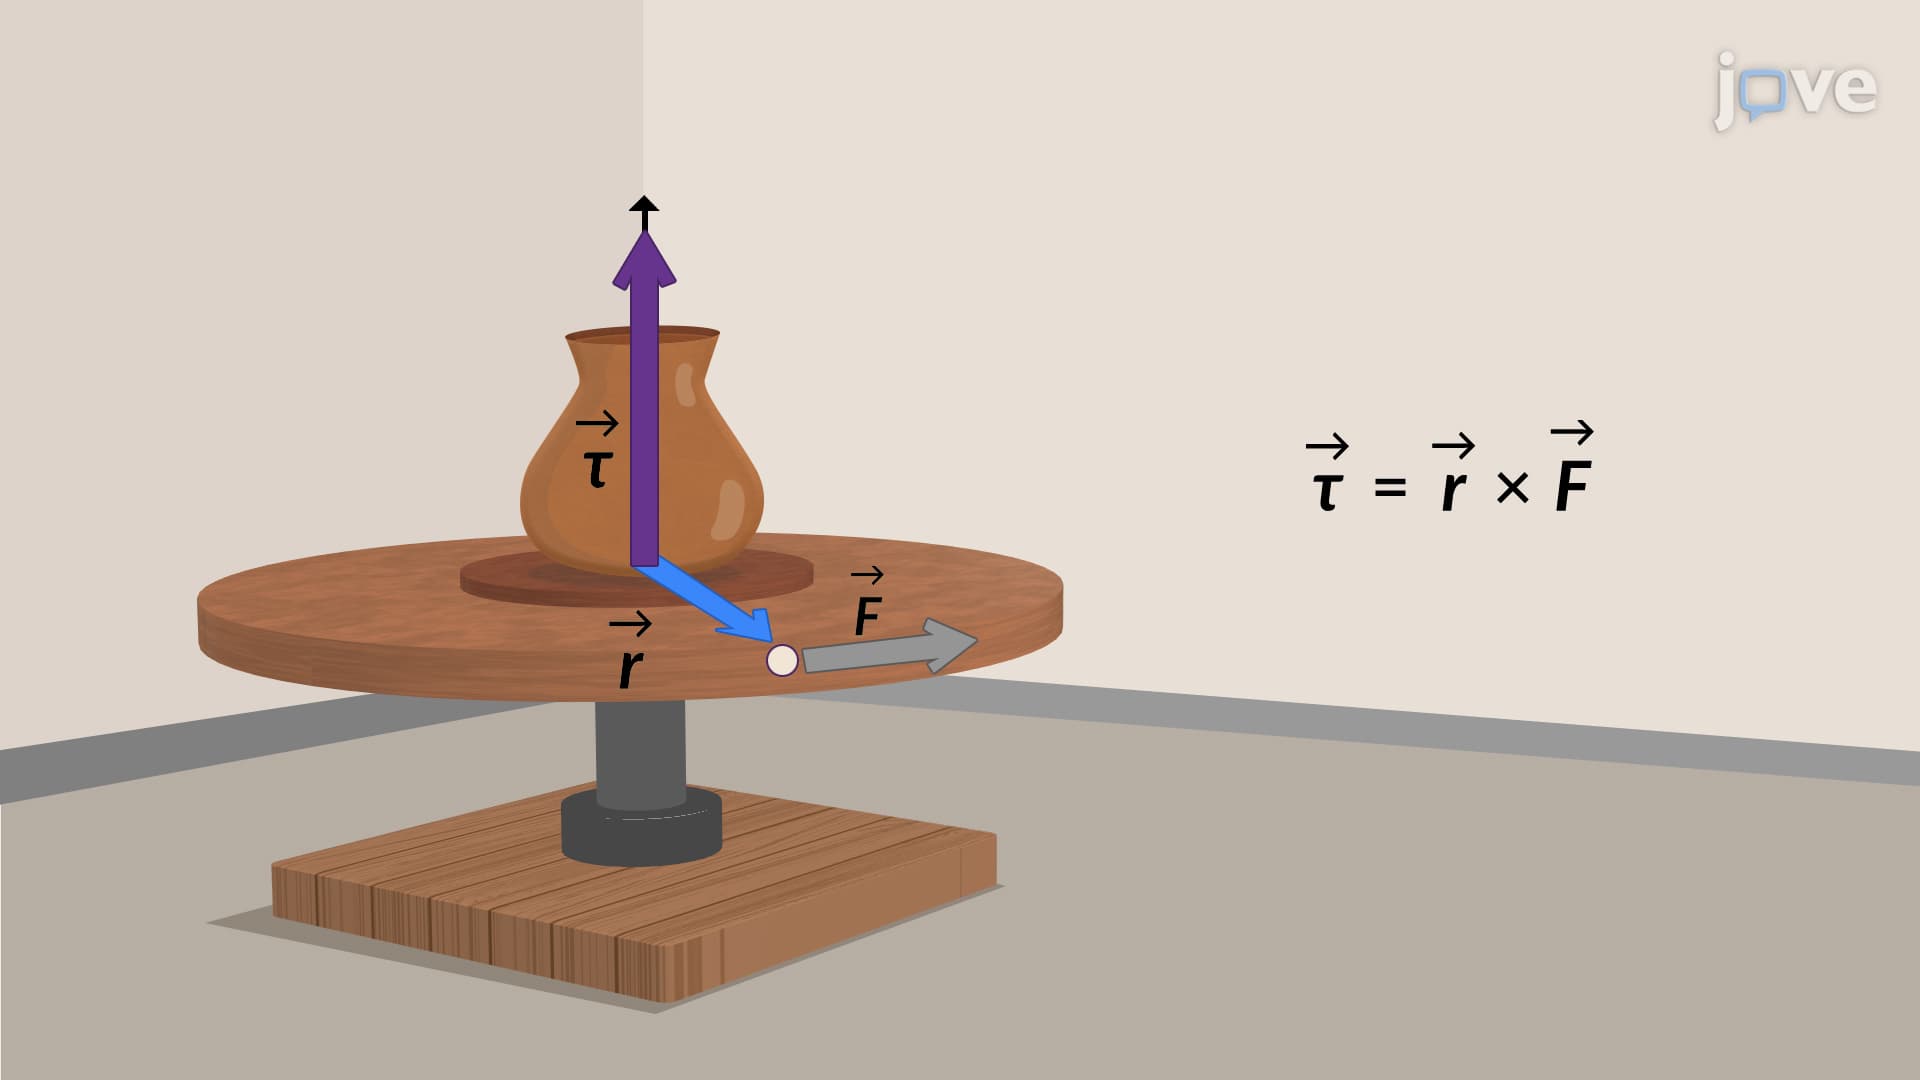
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:15
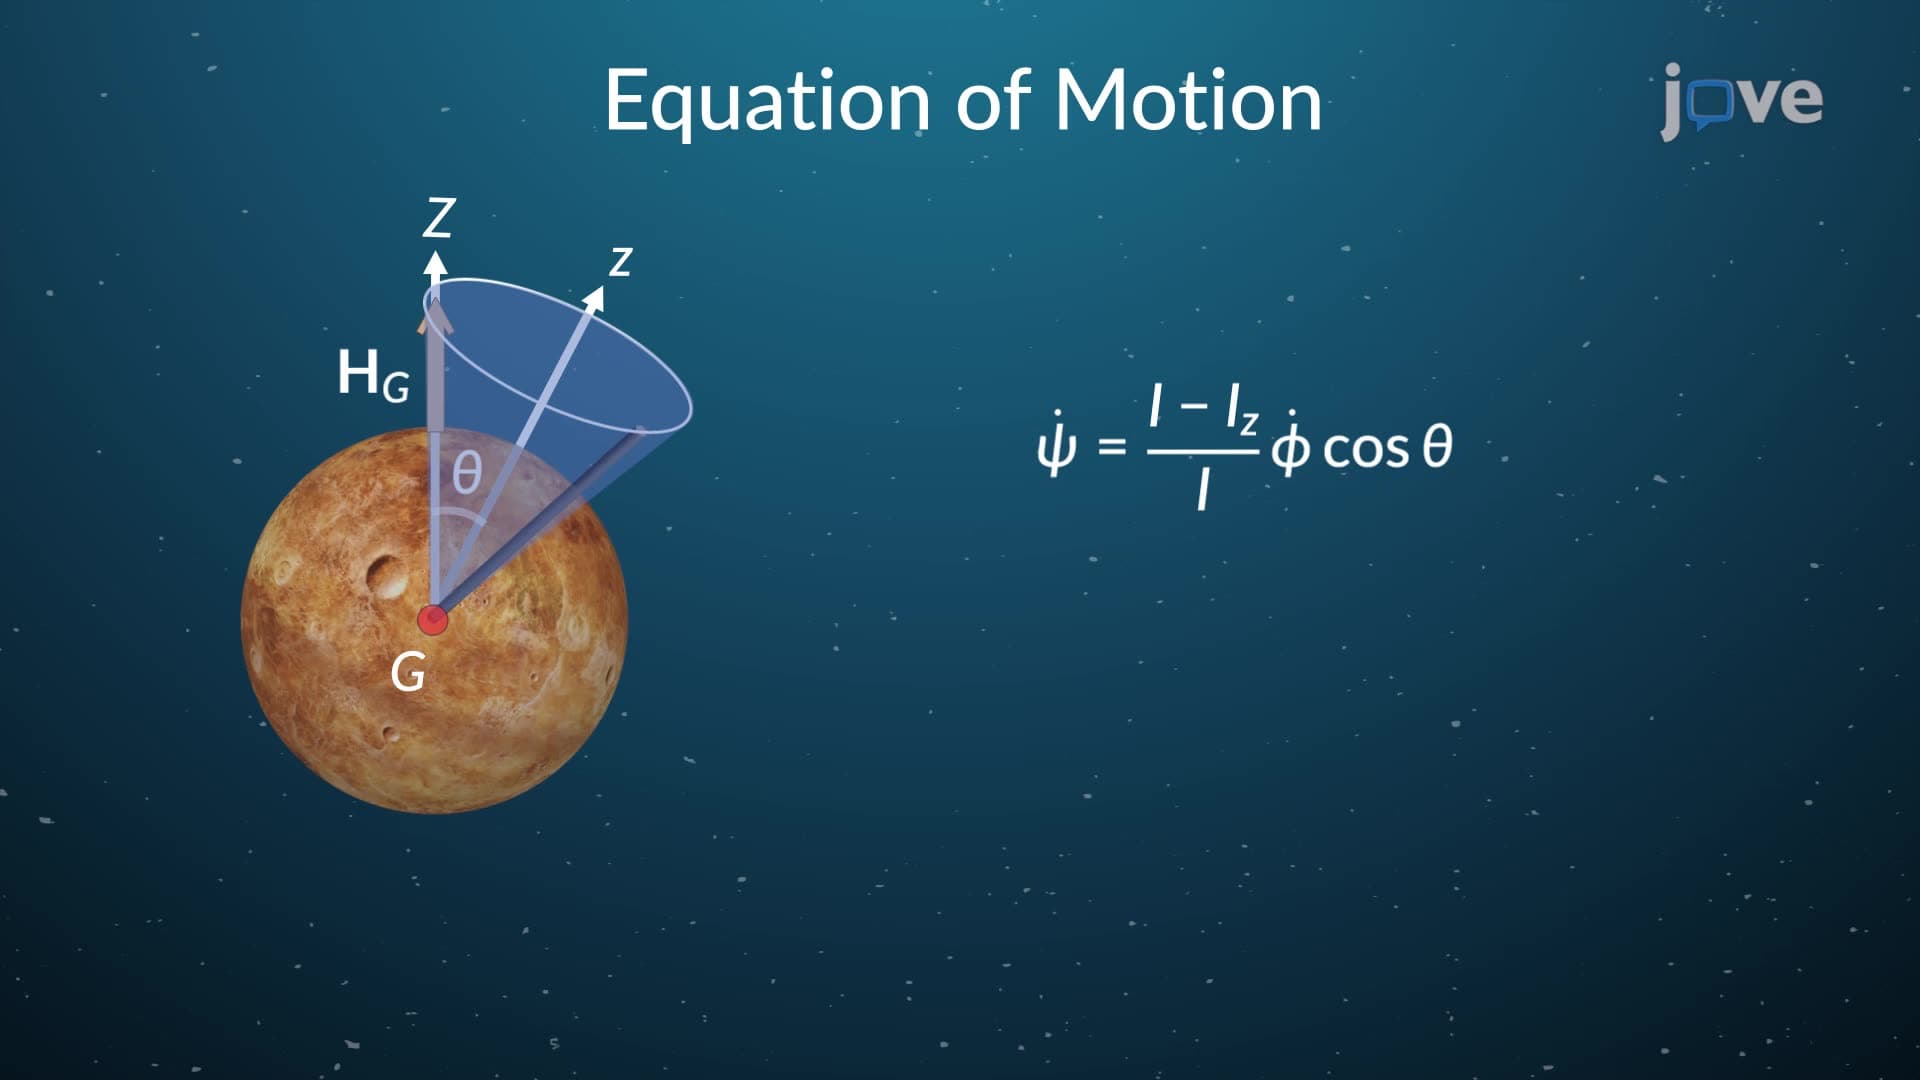
Torque Free Motion
 01:19
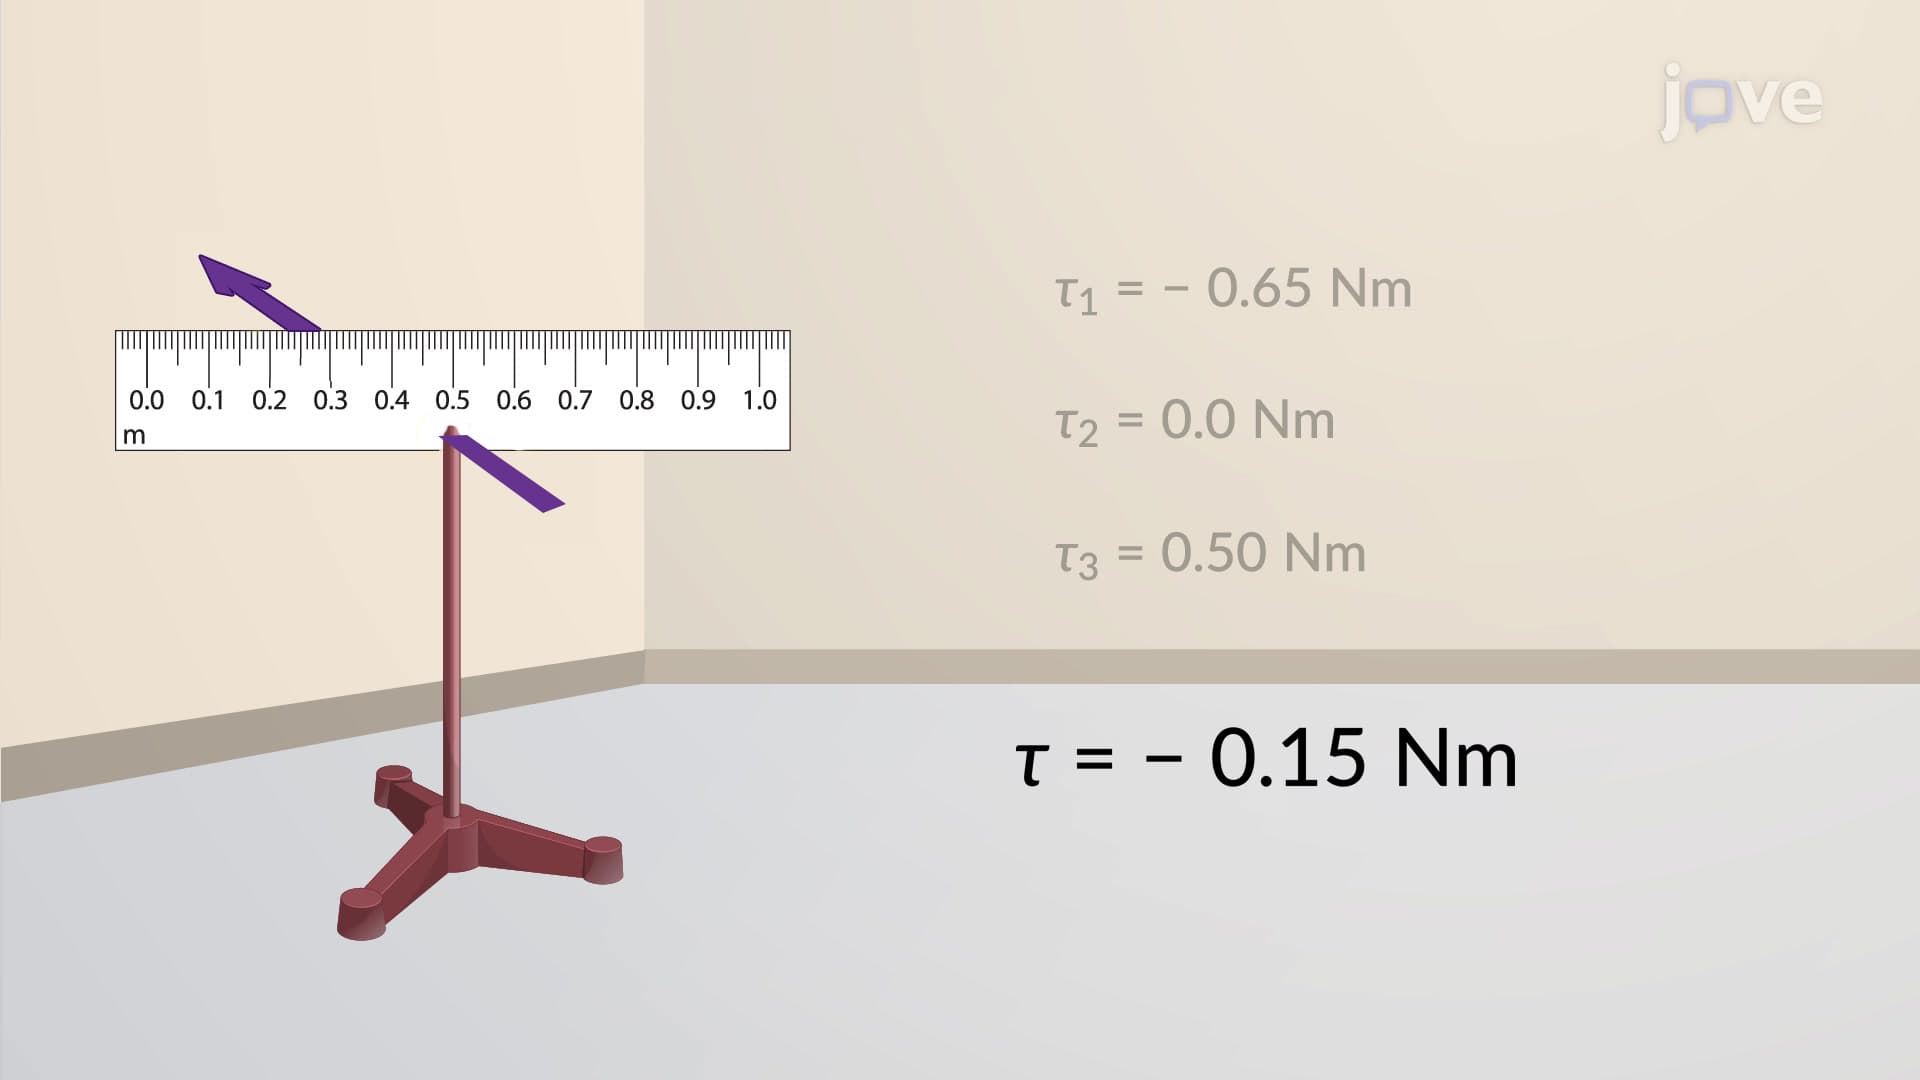
Net Torque Calculations
 01:27
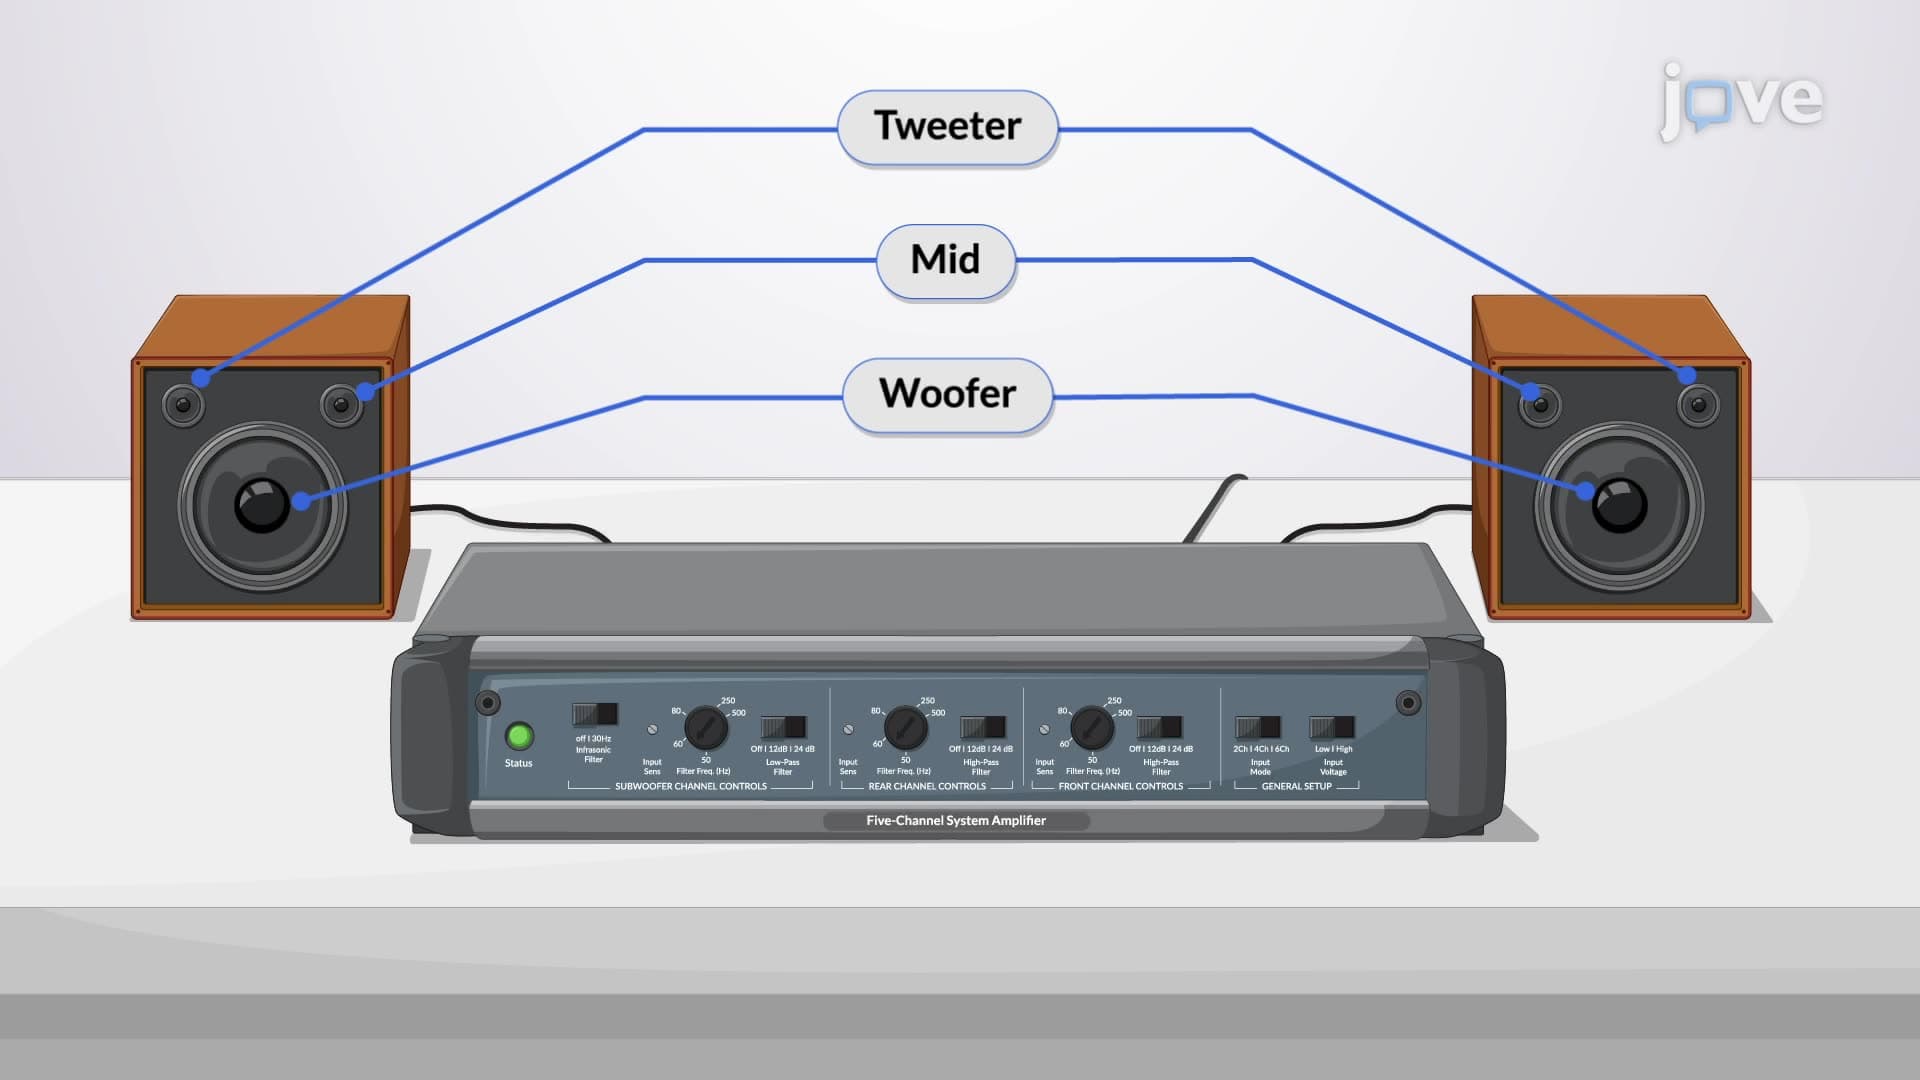
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
 01:31
Active versus Passive Immunity
Active Immunity
Active immunity refers to the resistance one develops...
 01:10
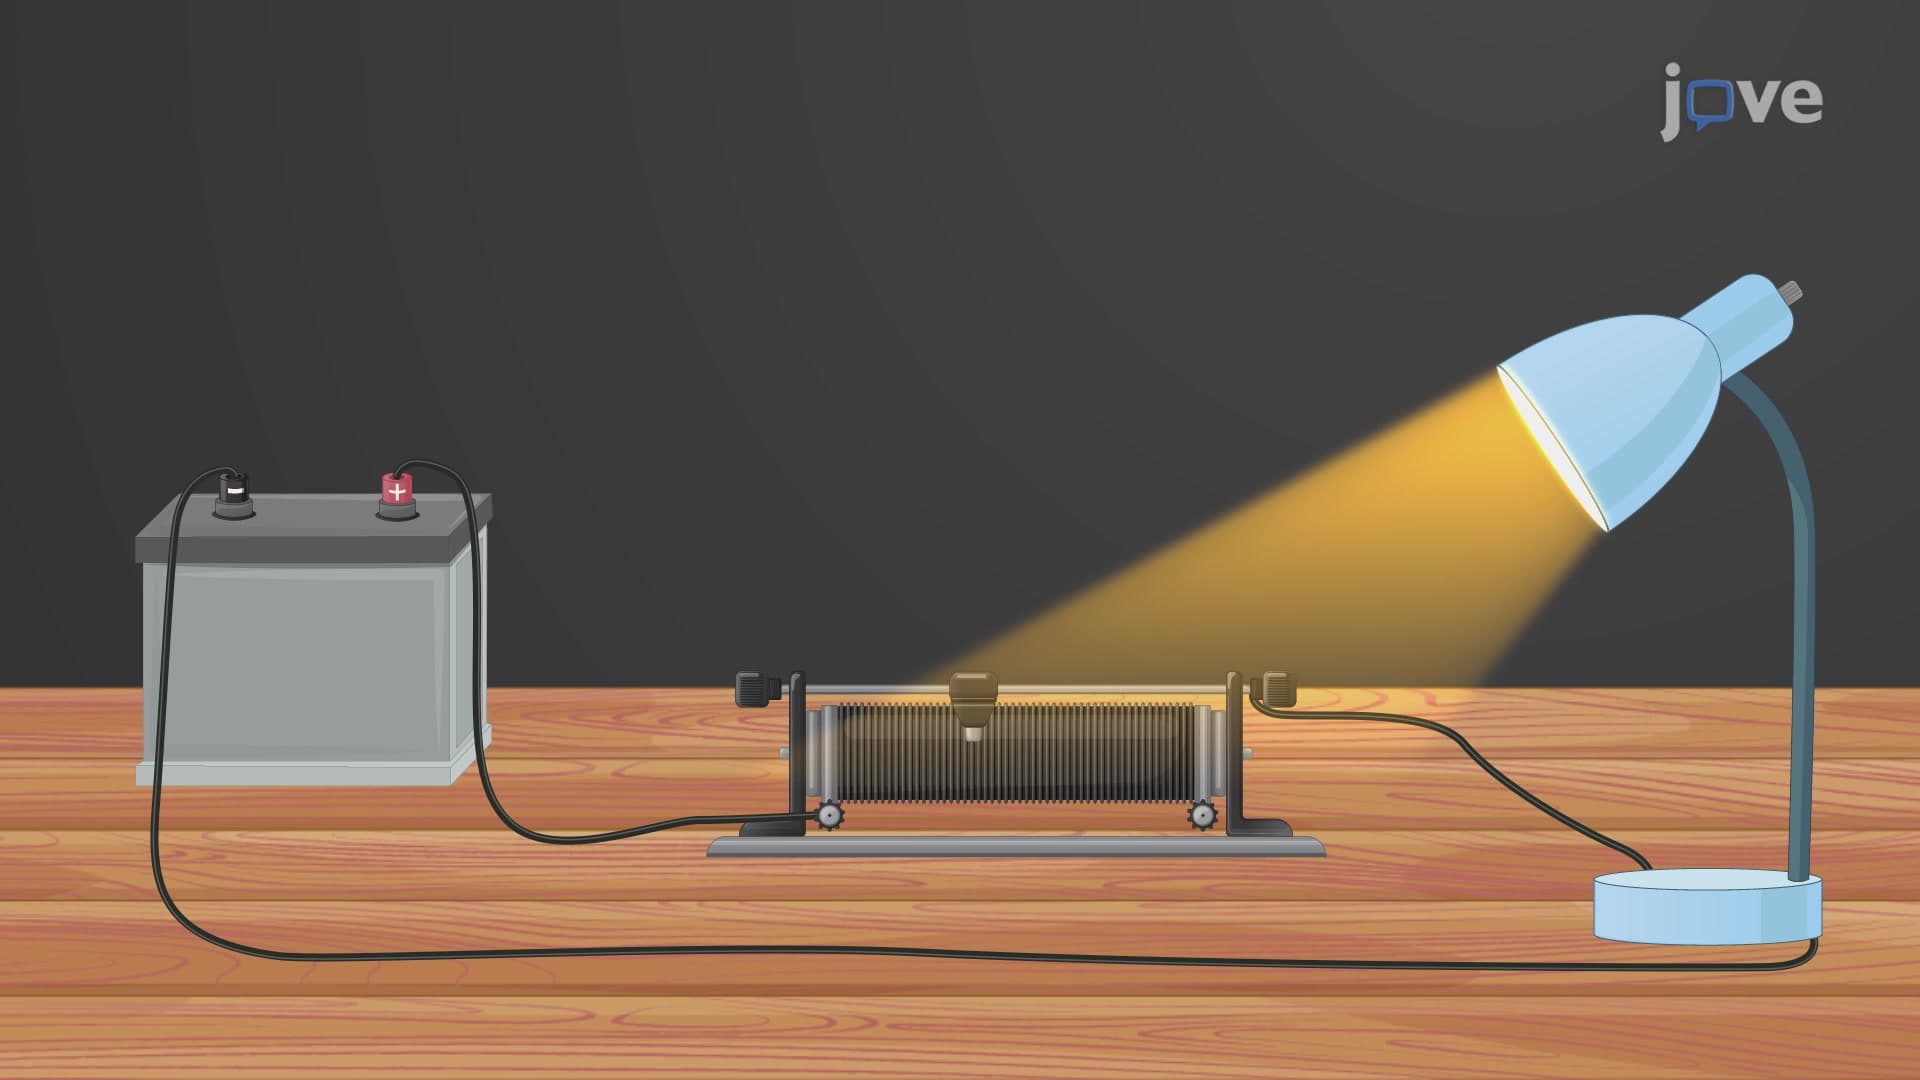
Resistors In Series
In a series circuit, the...