Broad Fuzzy Neural Network-Based Prescribed-Time Control for a Flexible Single-Link Manipulator With Multiple Constraints
Related Experiment Video
Updated: Nov 8, 2026
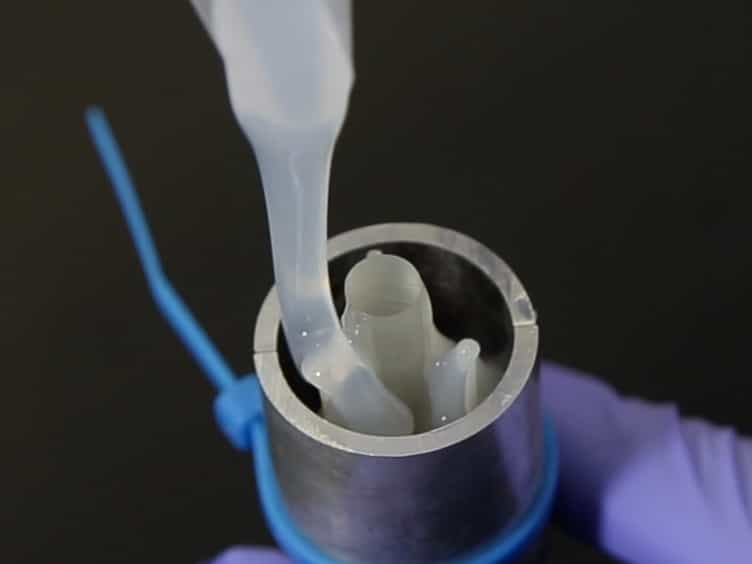
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015

Abstract:
Flexible manipulator control can be impacted by vibrations alongside input and output constraints, potentially increasing safety risks or causing serious accidents. This study develops a broad fuzzy neural network (BFNN)-based prescribed-time control (PTC) scheme for a flexible single-link manipulator (FSLM) subject to flexible-link vibration, a compound actuator nonlinearity comprising dead-zone and saturation, and output constraints. The BFNN is employed specifically to estimate and compensate for the actuator-induced mismatch between the commanded and actual control inputs. A two-domain stability analysis establishes semi-global practical finite-time stability (SGPFS) in the transformed time domain and shows that the tracking errors enter an adjustable neighborhood within the user-assigned time in the original time domain. Meanwhile, a barrier Lyapunov function (BLF) ensures that the constrained tracking errors remain within their prescribed bounds. The simulation and hardware experimental results demonstrate prescribed-time tracking, constraint satisfaction, vibration suppression, and practical implementability.
Related Concept Videos
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:28
Lagrange Multipliers: Two Constraints
 01:30
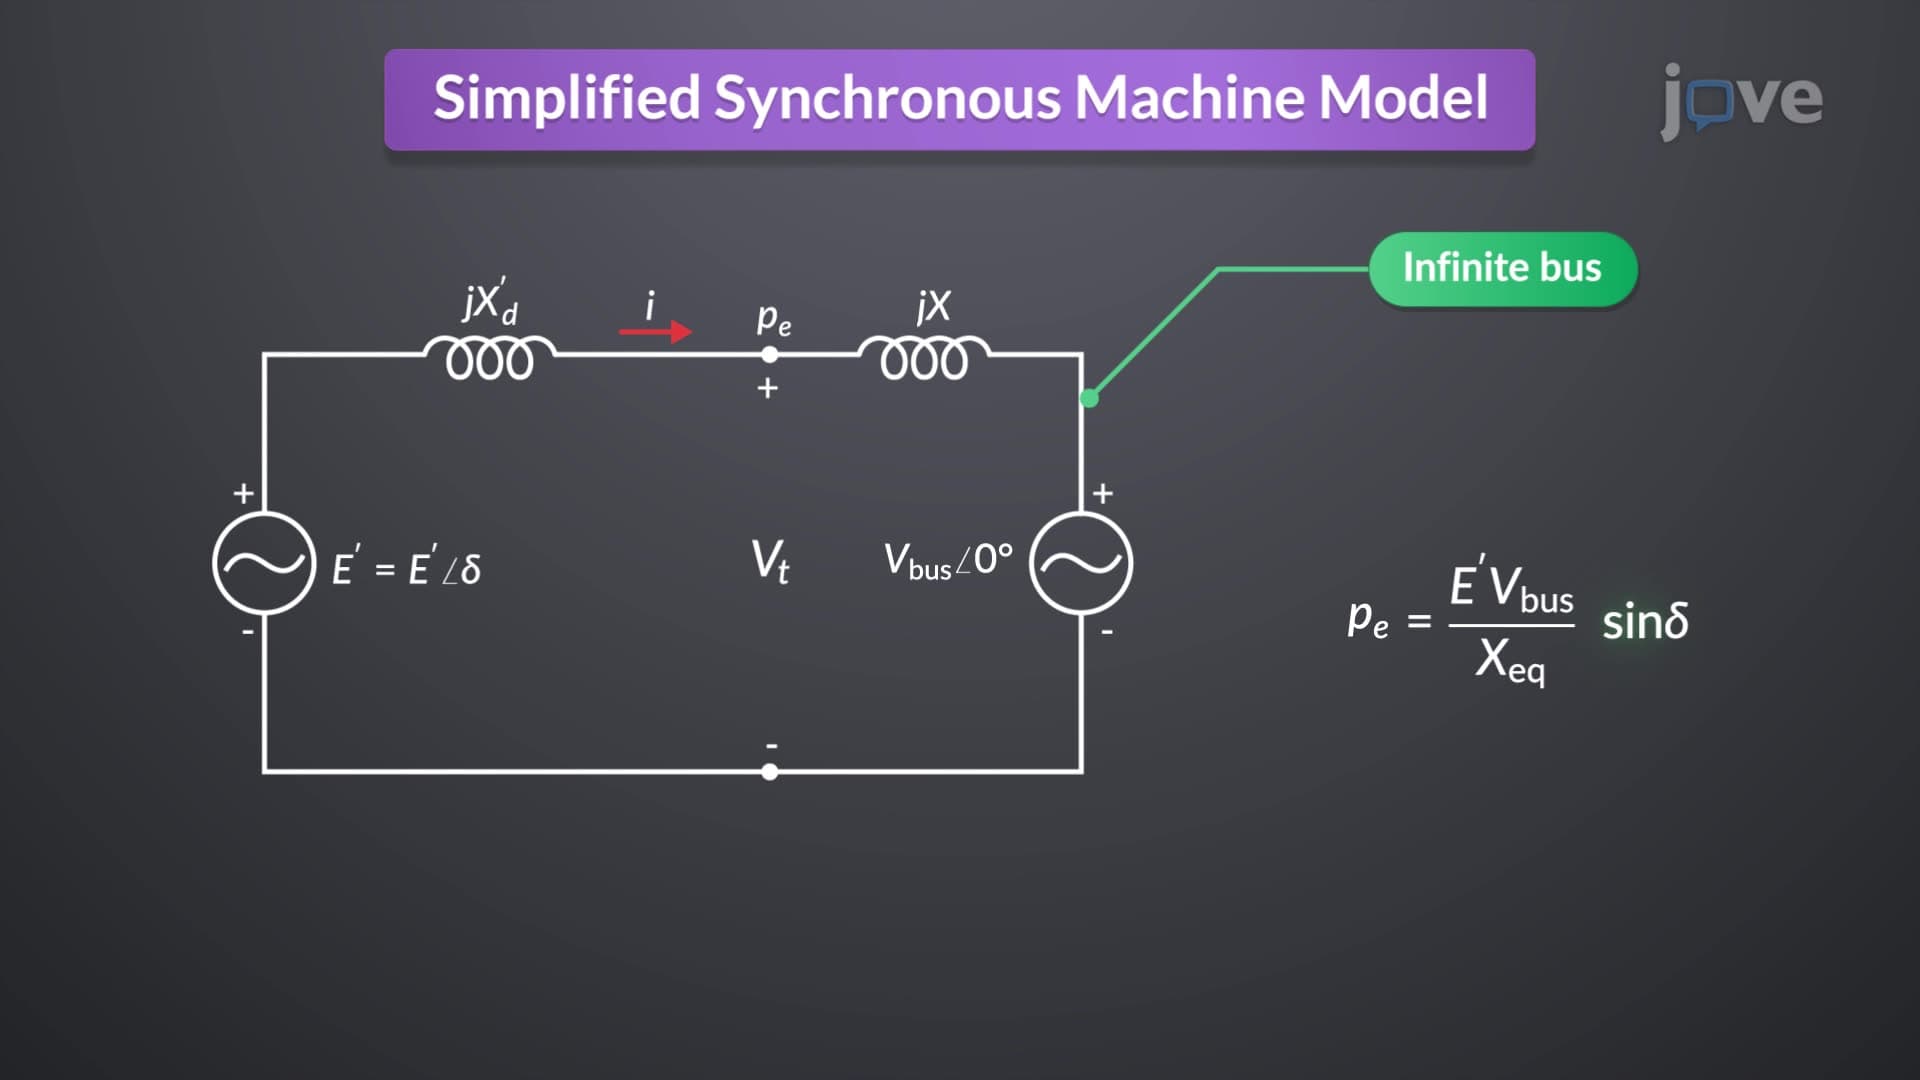
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...