Related Experiment Videos
Adaptive-Slack Prescribed-Performance Control: Achieving Safe Trajectory Tracking in Cluttered Environments via

Abstract:
Achieving high-precision trajectory tracking while ensuring collision avoidance presents a fundamental conflict for autonomous systems operating in cluttered environments. Traditional prescribed-performance control (PPC) imposes rigid shrinking funnels that may become infeasible during avoidance maneuvers, whereas soft penalty-based avoidance may sacrifice tracking recovery. To resolve this dilemma, this article proposes an adaptive-slack Hamilton-Jacobi-Bellman (HJB)-based integral reinforcement learning (IRL) framework with an explicit control-barrier-function quadratic-programming (CBF-QP) safety layer. The adaptive boundary component relaxes the PPC envelope according to the geometric clearance demand and contracts after the avoidance demand disappears. A time-varying HJB formulation is used to generate a nominal performance-oriented controller for the unknown nonlinear system, while the CBF-QP minimally modifies this nominal input to guarantee forward invariance of the safe set. The resulting architecture separates nominal optimal tracking, performance-envelope feasibility, and CBF-certified physical safety. Comparative simulations demonstrate the different failure modes of rigid PPC and soft avoidance, and show that the proposed strategy recovers high-precision tracking after safety-critical maneuvers.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:17
Rolling Resistance: Problem Solving
 01:26
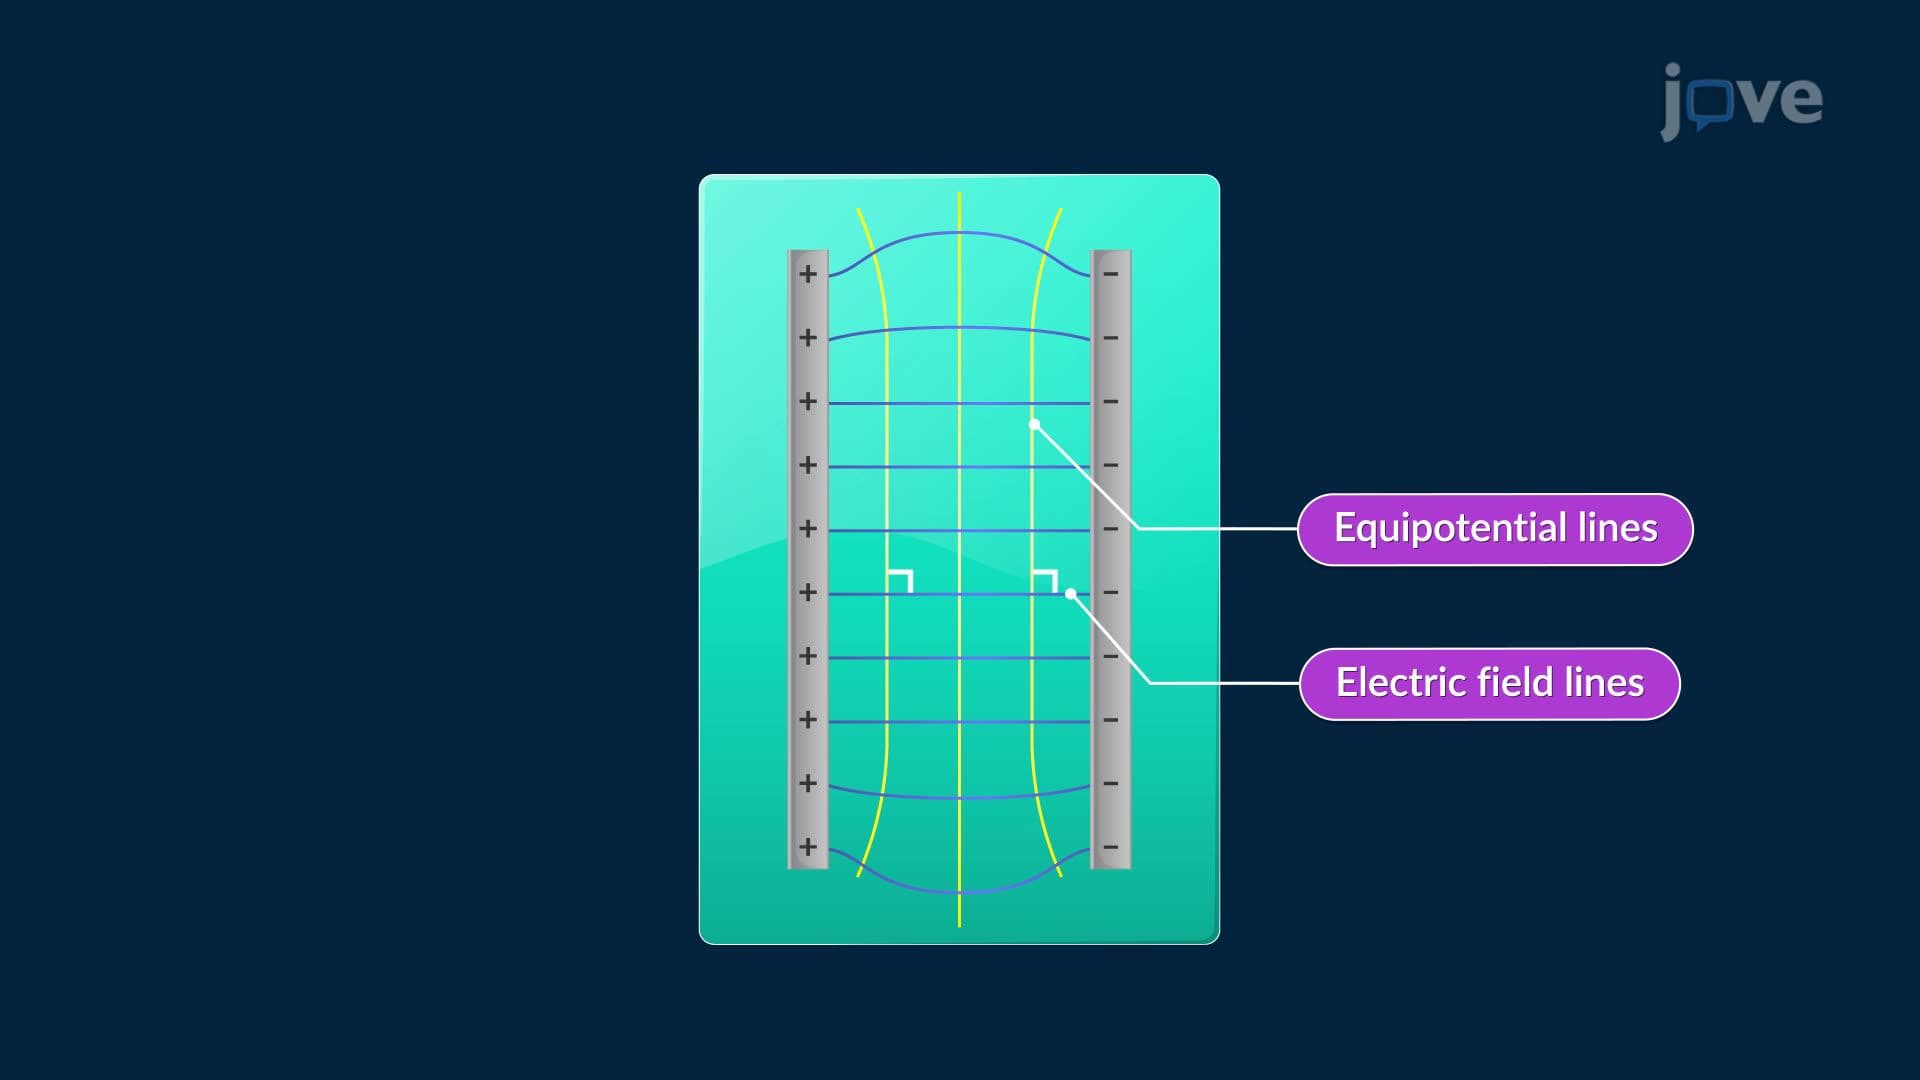
Orthogonal Trajectories
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:12
Observational Learning