Related Experiment Video
Updated: Oct 10, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Closed-Loop Dynamics Modeling and Knowledge-Based Control of Fractional-Order Systems With Output Constraints via

Abstract:
This article addresses the problem of closed-loop dynamics learning and tracking control for a class of fractional-order (FO) nonlinear strict-feedback systems subject to output constraints. To cope with the inherent nonlinear uncertainties, an adaptive FO learning control strategy is developed based on deterministic learning (DL) theory. A notable feature of the proposed method lies in its ability to accurately learn the uncertain nonlinear dynamics of the system during real-time closed-loop tracking control while ensuring both stability and convergence of the overall system. To mitigate the complexity explosion typically encountered in traditional backstepping designs due to virtual control laws, an improved adaptive FO filter is introduced. Subsequently, by incorporating the DL framework, an adaptive output-constrained control scheme is formulated using radial basis function neural networks (RBFNNs), enabling locally precise approximation of the nonlinear closed-loop dynamics while strictly satisfying the output constraints. Rigorous Lyapunov-based stability analysis demonstrates that: 1) the output of the FO system remains strictly within the prescribed constraint boundaries and achieves stable tracking of the desired reference trajectory and 2) the resulting linear time-varying (LTV) FO closed-loop system achieves exponential stability under persistent excitation (PE). This guarantees that the RBFNNs can achieve locally accurate identification of the dominant uncertain dynamics and preserve the acquired knowledge in the form of constant RBFNNs. Based on these results, an experience-based control scheme is further proposed, which leverages the previously learned dynamic knowledge to enhance control performance and reduce computational overhead while maintaining provable closed-loop stability.
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:21
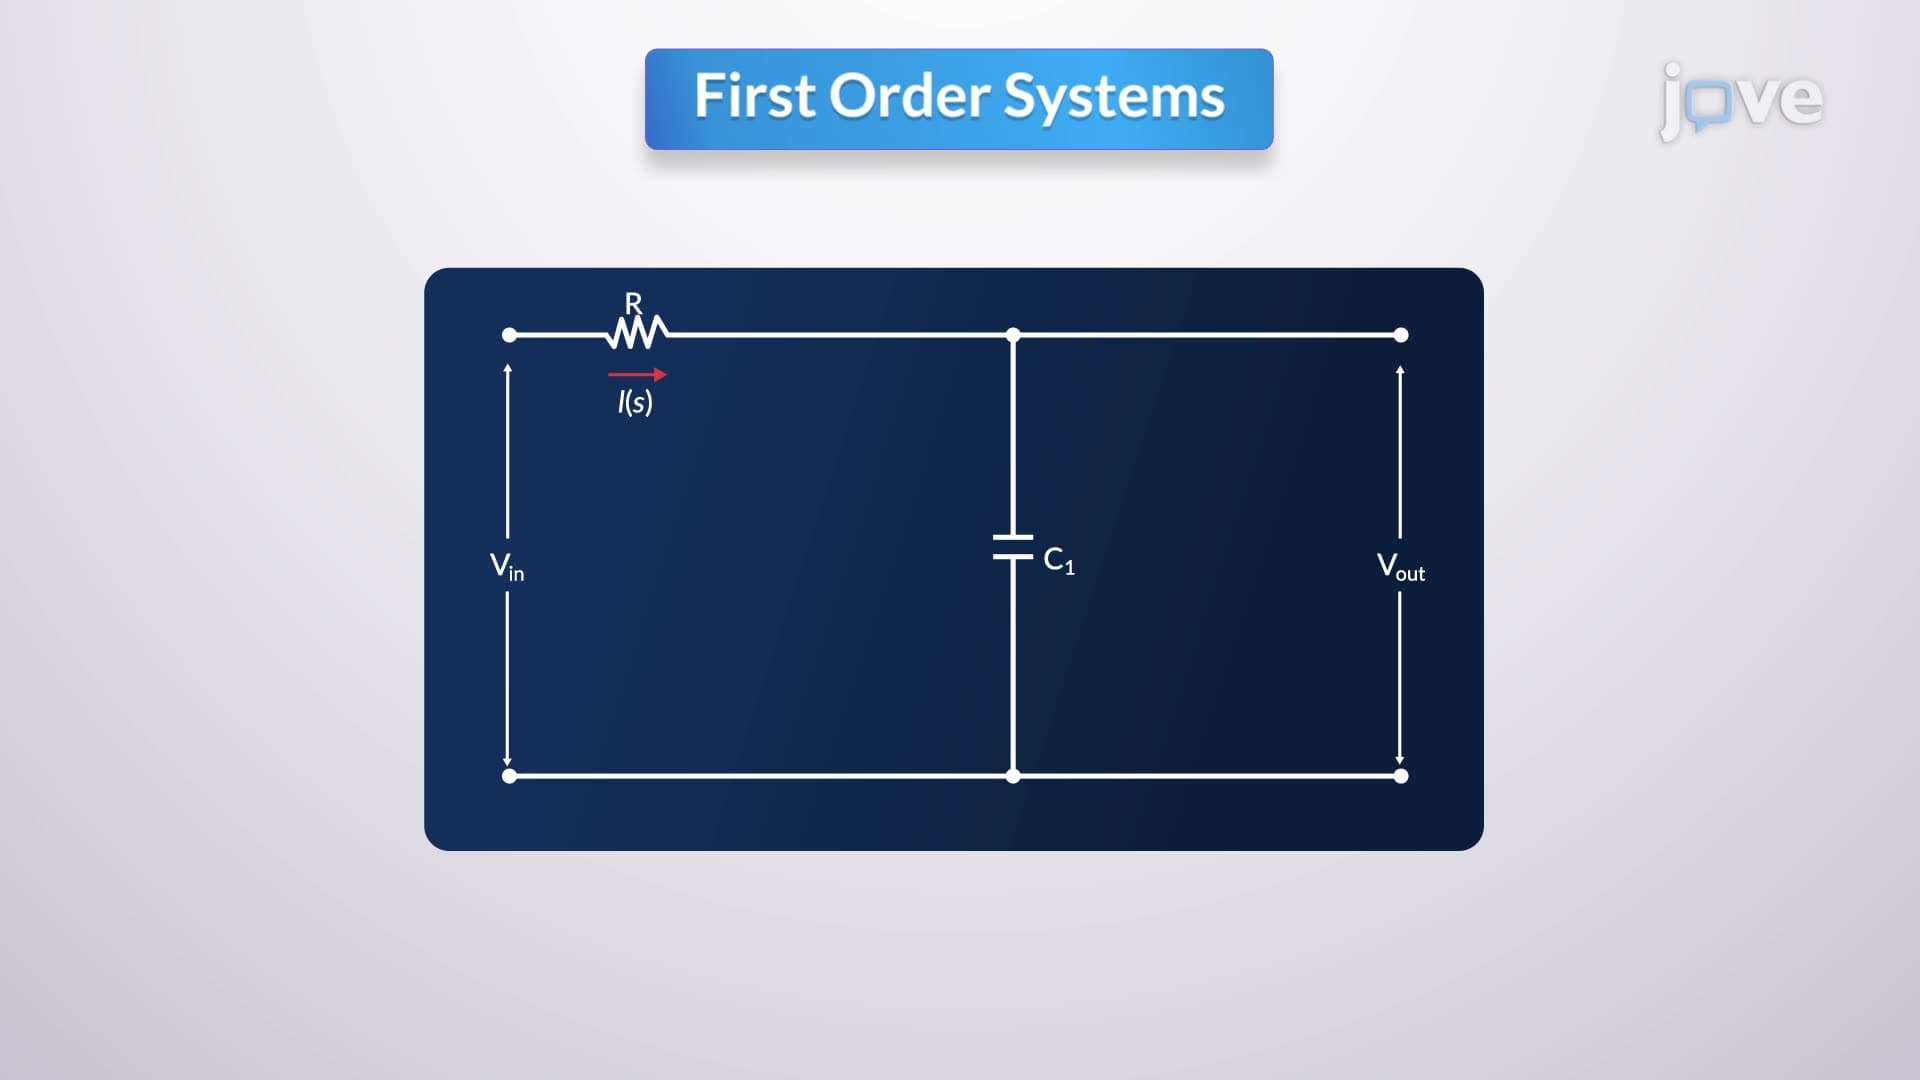
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:18
Second Order systems II
If ζ...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...