Related Experiment Video
Updated: Feb 15, 2026


Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
[Research on the stability of teaching robots of rotation-traction manipulation]
Min-Shan Feng1, Li-Guo Zhu1, Shang-Quan Wang1
1Beijing Key Laboratory of Traditional Chinese Orthopedics and Traumatology, Wangjing Hospital, China Academy of Chinese Medical Sciences, Beijing 100102, China.

Objective:
To evaluate the stability of teaching robot of rotation-traction manipulation.
Methods:
Operators were required to get the hang of rotation-traction manipulation and had clinical experience for over 5 years. The examination and data processing of the ten operators in our research were collected by the teaching robot of rotation-traction manipulation. Traction, pulling force, maximum force, pulling time, rotational amplitude and pitch range were recorded and compared for five times(G1, G2, G3, G4 and G5). The qualification rates were analyzed to evaluate the stability of teaching robot of rotation-traction manipulation.
Results:
Nonconforming items were found in G1 and G2, for instance, pulling force(P=0.074), maximum force(P=0.264) and rotational amplitude (P=0.531). There was no statistically difference. None nonconforming item was found in G3, G4 and G5. All data were processed by SPSS and One-way ANOVA was used to analysis. Pulling force was found statistically different in G1, compared with G4 and G5(P=0.015, P=0.006). Maximum force was found statistically different in G1, compared with G4 and G5 (P=0.021, P=0.012). None differences were found in other comparisons (P>0.05).
Conclusions:
The teaching robot of rotation-traction manipulation used in our research could provide objective and quantitative indices and was considered to be an effective tool of assessing the rotation-traction manipulation.
More Related Videos


Related Concept Videos
 03:18
Nuclear Stability
To hold positively charged protons together...
 01:53
RNA Stability
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:11
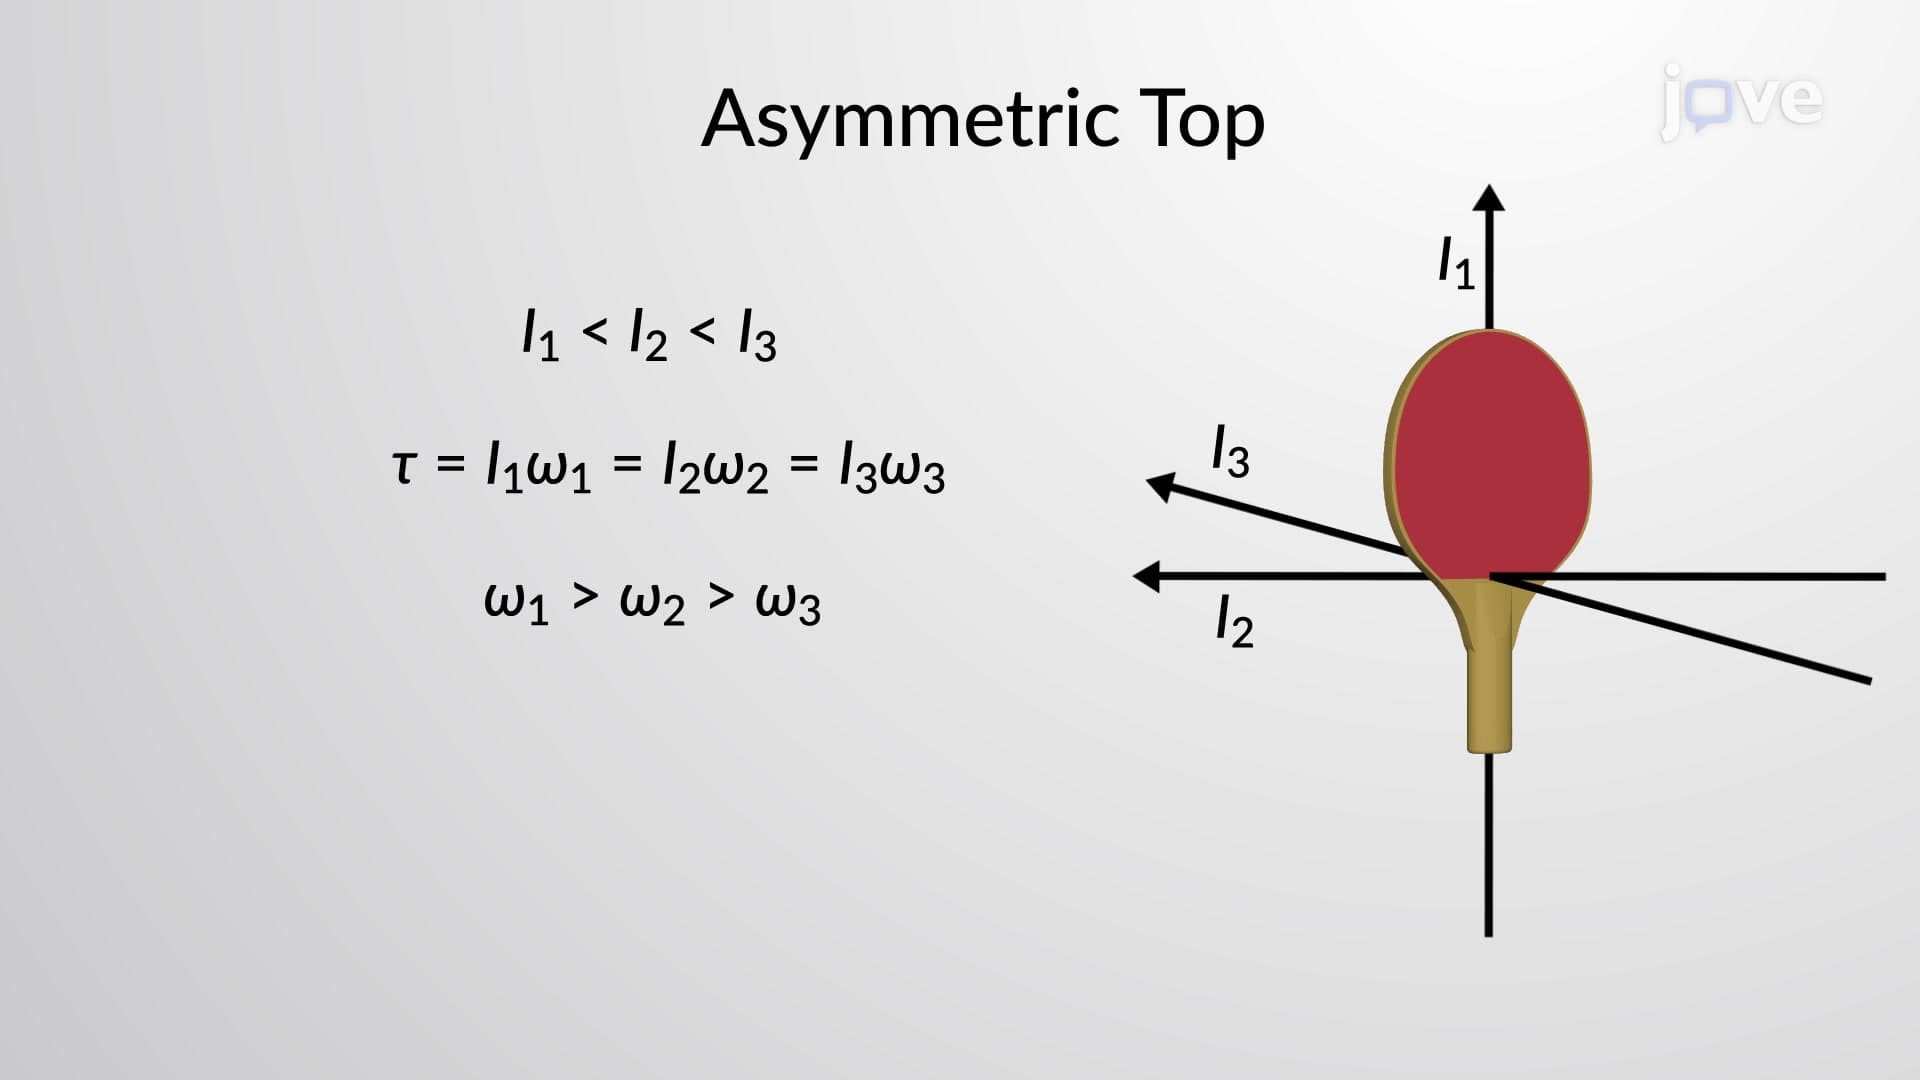
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:21
Manipulation and Analysis