Related Experiment Video
Updated: Sep 17, 2026


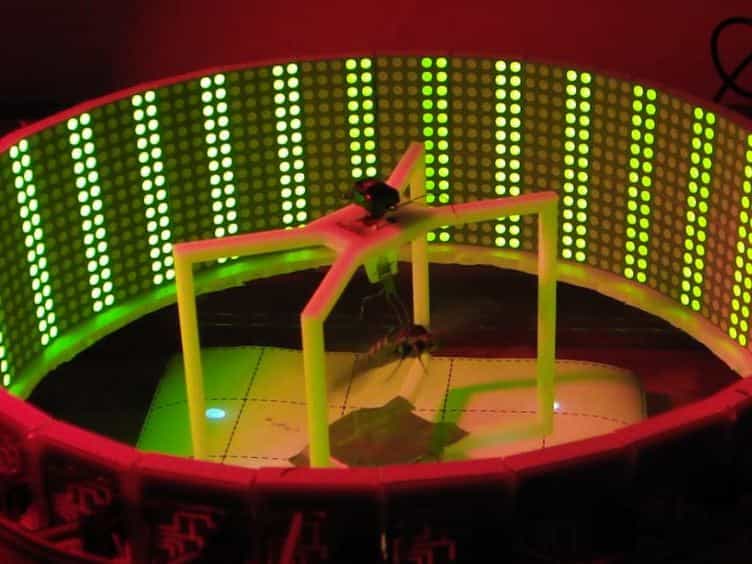
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle (Mercynorrhina torquata)
Published on: September 2, 2016
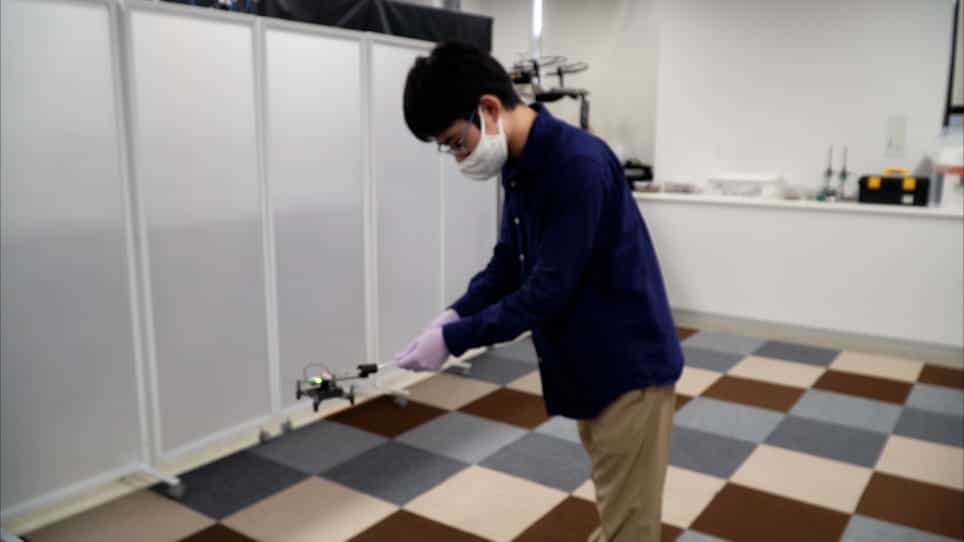
Aerial and ground locomotion of winged drones powered by a single actuator
Won Dong Shin1,2, Hoang-Vu Phan2,3, Simon L Jeger2
1Bio-inspired Robotics and Design Laboratory, Pohang Science and Technology University, Pohang, Republic of Korea.

Abstract:
Multimodal drones combining aerial and terrestrial mobility offer adaptability and extended operational range across diverse environments. However, most existing multimodal drones rely on multiple actuators that add mass and complexity while offering limited terrestrial locomotion capabilities. Here, we introduce a multimodal winged drone driven by only a single actuator, capable of ground locomotion, flight, and ground-to-air transition by either rolling or jumping. The actuator is based on a novel transmission system that enables control of its rotational direction to switch between different locomotion modes. In one direction, the actuator drives a propeller that generates forward thrust for flight and (passive) wheeled locomotion on the ground, while in the other direction it activates a spring-leg mechanism that enables jumping by storing and releasing elastic energy. We show that the winged drone can perform fast wheeled locomotion on flat surfaces, consecutive jumps across diverse terrains, as well as take-off from a runway or jumping from a spot. Experimental characterization shows that runway take-off offers greater energy efficiency, while jumping take-off is more space-efficient and less dependent on ground conditions. The proposed actuation method enables simple and effective versatility for locomotion in diverse environments, thus extending the operational range of winged drones.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:13
Motor Units
Motor units come in different sizes, with smaller units...
 00:46
Motor Units